
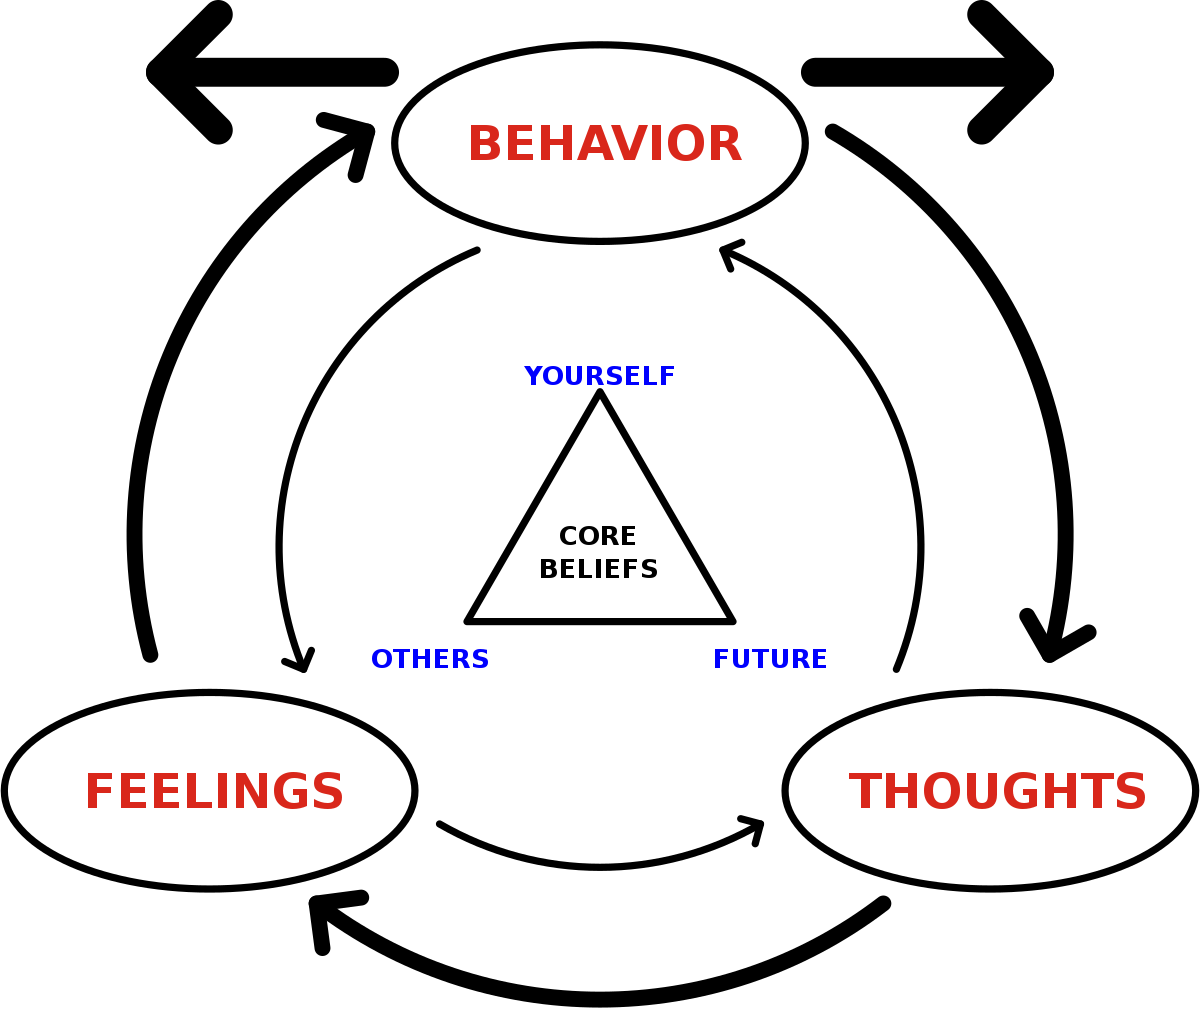
The term “cognitive behaviorism” originated in the realm of psychology, describing a school of thought that integrates cognitive processes (like thoughts, beliefs, and perceptions) with observable behaviors. However, in the rapidly advancing world of Tech & Innovation, particularly within the domain of autonomous systems and drone technology, this theoretical framework finds a compelling and transformative reinterpretation. Here, cognitive behaviorism transcends its psychological origins to become a powerful paradigm for designing artificial intelligence (AI) that can perceive, process, and react intelligently within complex environments. It is not about endowing machines with human-like consciousness, but rather about engineering systems that exhibit sophisticated learning, adaptation, and decision-making capabilities by bridging their internal computational states with their external operational behaviors.

Understanding the Behavioral-Cognitive Nexus in Autonomous Systems
In the context of AI and autonomous drones, the “cognitive” aspect refers to the internal information processing, data analysis, and decision-making algorithms that govern a system’s operation. This includes everything from sensor data interpretation and pattern recognition to path planning and strategic goal assessment. The “behavioral” aspect, conversely, encompasses the observable actions and reactions of the autonomous system—its flight maneuvers, camera adjustments, data collection routines, and interactions with its environment. Cognitive behaviorism, in this technological sphere, is about creating a robust, adaptive link between these two dimensions, enabling systems to dynamically learn and refine their operational strategies based on continuous feedback loops.
Bridging Internal States and External Actions
At the heart of cognitive behaviorism in AI lies the intricate connection between a system’s internal computational state and its external, observable actions. Consider a drone equipped with advanced AI: its “internal state” might be defined by its current navigational map, battery level, mission parameters, and real-time analysis of environmental data from its array of sensors (e.g., LiDAR, cameras, GPS). The “cognitive” process involves the AI actively interpreting this vast stream of data, updating its internal models, and predicting potential outcomes of various actions. This internal processing then dictates the “external actions” or “behaviors” of the drone—its velocity, altitude, specific flight path adjustments, or even the precise angle of its gimbal camera.
For instance, an autonomous drone performing a surveillance mission might use its internal cognitive framework to analyze incoming video feeds, identify anomalies, and update its internal map of points of interest. This cognitive update then triggers a behavioral response, such as altering its flight path to get a closer look, autonomously deploying a different sensor, or transmitting an alert to human operators. The efficacy of the system is measured by how effectively its internal cognitive model leads to appropriate and successful external behaviors, demonstrating a seamless integration that goes beyond simple programmed responses. This continuous cycle of perception, cognitive processing, and behavioral output is fundamental to the development of truly intelligent autonomous platforms.
Learning from Environmental Interactions
A key principle adapted from cognitive behaviorism is the idea of learning through interaction with the environment. For autonomous systems, this translates into advanced machine learning algorithms that allow drones to continuously gather data, process new information, and adjust their internal models and behavioral responses without explicit reprogramming. This dynamic learning process is critical for navigating unpredictable or complex scenarios.
For example, a drone tasked with inspecting wind turbines might initially operate on a pre-programmed flight path. However, using cognitive behavioral principles, the drone’s AI can learn from its environment. If it encounters unexpected turbulence or identifies a novel structural anomaly, its cognitive processing algorithms will analyze this new input. This might lead to an immediate behavioral adaptation, such as adjusting its flight pattern to compensate for wind or executing a more detailed inspection maneuver around the anomaly. Furthermore, this newly acquired knowledge is then integrated into its long-term operational model, making the drone more resilient and efficient in future similar missions. This iterative process of perception, internal adjustment, and refined action is what drives the sophisticated adaptability seen in cutting-edge autonomous technology.
Practical Applications in Drone Intelligence and Autonomous Flight
The theoretical underpinnings of cognitive behaviorism are not merely academic in the tech space; they manifest as tangible advancements in how drones operate, make decisions, and interact with their surroundings. These principles enable drones to move beyond rudimentary automation toward genuine intelligent autonomy.
Enhanced Navigation and Decision-Making Algorithms
In complex airspace or dynamic environments, drones require highly sophisticated navigation and decision-making capabilities. Cognitive behaviorism provides a framework for developing algorithms that allow drones to not just follow a pre-set course, but to dynamically interpret their surroundings and make informed choices. For instance, an autonomous delivery drone encountering unexpected airspace restrictions or sudden weather changes needs to rapidly process this new information (cognitive input) and execute an optimal evasive or alternative route (behavioral output). This involves real-time analysis of sensor data, predictive modeling of environmental changes, and the ability to weigh various factors—such as safety, mission objectives, and energy consumption—to arrive at the best possible action. Modern navigation systems leveraging these principles can even learn preferred flight corridors or adapt to patterns of human activity, optimizing efficiency and safety over time.
Adaptive Obstacle Avoidance and Predictive Behavior
One of the most critical applications of cognitive behaviorism in drones is in adaptive obstacle avoidance. Rather than simply reacting to an obstacle once it’s in range, intelligent drones employ predictive behavior models. They cognitively analyze sensor data from multiple sources (e.g., optical flow, ultrasonic, LiDAR, radar) to construct a real-time, three-dimensional understanding of their environment. This internal cognitive map allows the AI to not only detect static obstacles but also to predict the movement of dynamic ones, such as birds, other aircraft, or even sudden gusts of wind. Based on these predictions, the drone’s behavioral algorithms can then initiate smooth, anticipatory maneuvers, adjusting its trajectory well in advance to avoid collisions without disrupting its mission. This level of predictive intelligence is a direct result of integrating cognitive processing with adaptive behavioral responses, mimicking how biological systems learn to navigate complex spaces.
AI Follow Mode and Intelligent Object Tracking
AI follow mode, a popular feature in many consumer and professional drones, is a prime example of cognitive behaviorism in action. When a drone is set to follow a subject, its AI doesn’t just lock onto a visual target. It continuously processes a stream of cognitive inputs—the subject’s speed, direction, potential occlusions, and even predicted future movements. The AI builds an internal model of the subject’s behavior and the surrounding environment, allowing it to predict where the subject might move next. This cognitive analysis then informs the drone’s behavioral outputs: adjusting its speed, altitude, camera angle, and flight path to maintain optimal tracking and framing. Intelligent object tracking extends this capability to identifying, classifying, and persistently monitoring specific objects of interest within a complex visual field, even as they move or are temporarily obscured. This sophisticated interplay of perception, prediction, and responsive action is a testament to the power of integrating cognitive and behavioral principles into AI design.
Shaping Future Tech & Innovation: Beyond Basic Automation
The cognitive behavioral paradigm is propelling drone technology beyond mere automation, paving the way for systems that are truly intelligent, autonomous, and capable of operating in highly dynamic and unpredictable environments.
Remote Sensing and Mapping with Intelligent Adaptability
In applications like remote sensing and mapping, cognitive behaviorism enables drones to perform tasks with unprecedented efficiency and precision. Instead of flying pre-programmed grid patterns, an intelligent mapping drone can adapt its flight path and sensor operation based on real-time data analysis. For example, if its sensors detect an area of particular interest—such as unusual thermal signatures or specific vegetation patterns—its cognitive algorithms can immediately process this information and instruct the drone to perform a more detailed survey of that specific area, perhaps altering its altitude, slowing its speed, or switching to a higher-resolution sensor. This adaptive behavior, driven by real-time cognitive interpretation, optimizes data collection, reduces flight time, and ensures that critical information is never missed, transforming raw data into actionable intelligence more effectively.
Human-Machine Interaction and Intuitive Control
As autonomous systems become more prevalent, the interface between humans and machines must evolve. Cognitive behavioral principles are instrumental in designing drones that can interpret human intentions and adapt their behavior accordingly, leading to more intuitive control. Imagine a drone that learns a pilot’s preferred flight style, automatically adjusting sensitivity settings, or one that can interpret complex hand gestures to perform intricate maneuvers without explicit joystick commands. This requires the drone’s AI to cognitively process human inputs (e.g., control stick movements, voice commands, visual cues) and translate them into a nuanced understanding of intent, then execute behaviors that align with that understanding. The goal is to create a symbiotic relationship where the drone anticipates needs and responds in a way that feels natural and intuitive to the human operator, blurring the lines between command and collaboration.
The Evolution of Intelligent Systems: Challenges and Ethical Considerations
While cognitive behaviorism offers a robust framework for developing advanced AI in drones, its implementation presents significant challenges and raises important ethical considerations that must be addressed as these technologies evolve.
Replicating Complex Cognitive Processes
One of the primary challenges lies in replicating the sheer complexity of human-level cognitive processes within artificial systems. While AI can excel at specific tasks, emulating nuanced reasoning, abstract thinking, and common-sense understanding remains a monumental task. Drones designed with cognitive behavioral principles can learn and adapt, but their “cognition” is still narrowly focused and operates within defined parameters. Building truly generalizable intelligence that can effectively transfer learning across vastly different scenarios, akin to human flexibility, requires breakthroughs in AI architecture, learning algorithms, and computational power. The quest is to create systems that don’t just mimic behavior but exhibit a deeper, more robust understanding of their operational world.
Ensuring Robust and Predictable Behavior
Another critical challenge is ensuring that autonomous systems, particularly those that learn and adapt, exhibit robust and predictable behavior, especially in safety-critical applications. As drones gain more autonomy and their decision-making processes become more opaque due to complex learning algorithms, guaranteeing their actions will always align with safety protocols and mission objectives becomes more difficult. Unintended behaviors can emerge from subtle biases in training data or unforeseen interactions within complex environments. Developing rigorous testing methodologies, explainable AI (XAI) tools, and fail-safe mechanisms is paramount to building trust and confidence in these intelligent systems.

Data Privacy and Decision Transparency
As autonomous drones increasingly collect vast amounts of environmental and personal data to inform their cognitive models and behavioral responses, significant ethical concerns arise regarding data privacy. Who owns this data? How is it stored and used? Furthermore, the transparency of decision-making processes in cognitively driven AI is crucial. If an autonomous drone makes a critical decision, such as identifying a target or taking an evasive action, it’s essential to understand the underlying cognitive reasoning. This is not only for accountability in the event of an error but also for ensuring that biases are not inadvertently baked into the system’s learning processes. Addressing these ethical considerations through responsible AI development guidelines and regulatory frameworks is essential for the societal acceptance and safe deployment of increasingly intelligent autonomous technologies.