
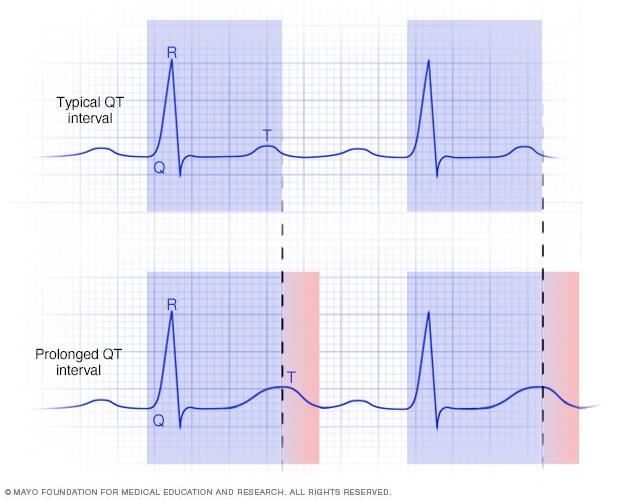
In the rapidly advancing world of drone technology, where autonomy, precision, and real-time decision-making are paramount, understanding the intricate layers of system performance is crucial. One such critical, yet often abstract, concept is “Quantum Timing,” or QT. While not a universally standardized acronym, within the context of high-performance drone tech and innovation, it represents the ultra-precise, synchronized execution of computational tasks and data exchanges that underpin a drone’s operational integrity. A “prolonged QT” signifies an undesirable delay or extended duration in these critical internal processes, posing significant challenges to the capabilities and reliability of advanced unmanned aerial systems.
Unpacking Quantum Timing (QT) in Advanced Drone Systems
The modern drone is far more than just a set of motors and propellers; it is a sophisticated, interconnected network of sensors, processors, actuators, and intelligent algorithms. Its ability to navigate complex environments, perform intricate maneuvers, and execute autonomous missions hinges on the seamless and timely interplay of these components. Quantum Timing, or QT, emerges as a conceptual framework to describe this foundational synchronicity, delineating the exactitude required for fractional-millisecond operations across the drone’s digital ecosystem.
The Foundation of Synchronized Autonomy
At its core, QT defines the internal clocking mechanisms and inter-system handshake protocols that ensure every component within a drone’s architecture operates in perfect harmony. It’s not merely about avoiding general latency, which can be externally perceived as a delay in command execution. Instead, QT delves into the micro-level synchronization of internal processes: when a sensor captures data, when the onboard AI chip processes it, when a flight controller computes a new motor command, and when that command reaches the Electronic Speed Controllers (ESCs). This precise orchestration is fundamental to features like AI Follow Mode, sophisticated sensor fusion (combining data from LiDAR, vision, and IMUs), real-time obstacle avoidance, and complex flight control algorithms that demand immediate, accurate data for decision-making.
Micro-Timings, Macro Impact
The cumulative effect of these micro-timings is profound. In fractions of milliseconds, hundreds, if not thousands, of operations occur simultaneously. The increasing complexity of modern drones, equipped with multiple high-resolution cameras, thermal imaging units, advanced LiDAR systems, and powerful edge AI processors, places immense demands on these internal timing cycles. A slight desynchronization or delay in one critical path can cascade through the entire system. For instance, if the visual odometry system’s processing is marginally slower than the inertial measurement unit’s data acquisition, the fused navigation solution can become inaccurate, leading to drift or instability. Understanding and optimizing these micro-timings is the battleground for achieving truly robust, intelligent, and autonomous drone capabilities.
The Imperative of Precision: Why Prolonged QT Threatens Performance and Safety
The concept of a prolonged QT underscores a critical vulnerability in advanced drone operations. When these internal timing cycles are extended beyond their optimal thresholds, the drone’s ability to interpret its environment and react effectively is compromised, directly impacting both its performance and the safety of its operations.
Real-Time Operational Deterioration
A prolonged QT manifests as a direct degradation in real-time operational capabilities. Imagine a drone attempting to avoid an unexpected obstacle: if the sensor data processing is delayed (prolonged QT), the drone’s perception of the obstacle’s position or trajectory will be outdated. This can lead to an inadequate evasive maneuver, or worse, a collision. Similarly, in dynamic flight conditions like strong winds, if the control loop adjustments are lagged due to prolonged QT, the drone will struggle to maintain stability, leading to erratic movements or loss of control. For professional applications such as mapping, even micro-jitters caused by asynchronous data processing can lead to blurry aerial footage or inconsistencies in photogrammetry data, rendering the output unusable. In critical inspection scenarios, a drone experiencing prolonged QT might fail to maintain a precise standoff distance, jeopardizing the integrity of the inspection or risking damage to the asset.
Compromising Autonomous Capabilities
The ramifications of prolonged QT are particularly severe for autonomous functions, which rely entirely on timely and accurate data. In AI Follow Mode, a delayed processing of subject movement (prolonged QT) means the drone will constantly be reacting to an outdated position, resulting in jerky tracking, overshoots, or even losing track of the subject entirely. Autonomous flight paths, meticulously planned for precision agriculture or infrastructure inspection, can lose their accuracy if the navigational data used for path correction is consistently behind the real-time position. This deviation can lead to inefficient flight patterns, missed data points, or even collisions with pre-programmed no-fly zones. Furthermore, in remote sensing, inconsistent data acquisition due to prolonged QT can result in gaps or inaccuracies in generated maps and 3D models, diminishing the value of the collected information. Perhaps most critically, in advanced swarm intelligence applications, where multiple drones collaborate and communicate, even a slight prolonged QT in one drone’s internal processing can disrupt the collective synchronization, potentially leading to catastrophic failures of coordinated maneuvers or communication breakdowns across the entire swarm. The reliability of these complex, interconnected systems is directly tied to the integrity of their internal timing.
Diagnosing and Understanding the Roots of Prolonged QT
Identifying the causes of a prolonged QT is a complex diagnostic challenge, as it can stem from a myriad of issues across hardware, software, and even environmental interactions. A holistic approach is essential to pinpointing and rectifying these critical delays.
Software and Firmware Bottlenecks
Inefficient software architecture and outdated firmware are frequent culprits behind prolonged QT. Poorly optimized algorithms, particularly those involved in demanding tasks like image recognition or sensor fusion, can consume excessive processing cycles, leading to delays. Operating system scheduling issues, where critical processes are not given adequate priority, or memory management problems causing frequent data swaps, can also introduce significant timing variations. Furthermore, the integration of third-party software or custom payloads that are not specifically optimized for the drone’s core timing architecture can disrupt the delicate balance of internal operations. Outdated firmware that fails to leverage the full capabilities of new hardware components or contains unaddressed timing bugs is another common source of performance degradation. Continuous software profiling and real-time operating system (RTOS) analysis are crucial for identifying these bottlenecks.
Hardware Limitations and Interactions
The physical components of a drone also play a critical role in determining QT. Processor overload, where the drone’s CPU, GPU, or dedicated AI chips are simply unable to keep up with the computational demands of their assigned tasks, directly extends processing times. Similarly, bus contention – where multiple components attempt to transmit data simultaneously over limited data pathways – can create significant communication delays. Mismatches in sensor read/write speeds versus the processing speed of the connected chips can lead to data buffering and subsequent delays. More subtle issues include electromagnetic interference (EMI) between closely packed electronic components, which can corrupt data signals, requiring retransmission and introducing delays. Thermal throttling, where components reduce their clock speed to prevent overheating under heavy load, is another common hardware-related cause of prolonged QT, especially in high-performance or small-form-factor drones.
Environmental and External Factors
Beyond the drone itself, the operational environment can also contribute to prolonged QT. Strong electromagnetic interference from power lines, communication towers, or other electronic devices can disrupt internal data buses or communication links, leading to delays. Extreme temperatures, whether hot or cold, can impact the performance of electronic components, slowing down processing speeds or affecting sensor accuracy, which in turn demands more processing time for correction. Finally, operating in exceptionally complex environments, such as dense urban areas or heavily forested regions, requires an unusually high rate of sensor data acquisition and processing for robust navigation and obstacle avoidance. If the drone’s systems are pushed beyond their designed optimal QT limits under these conditions, performance degradation is inevitable.
Strategies for Mitigating Prolonged QT and Ensuring Future Reliability
Addressing and mitigating prolonged QT is not a singular fix but an ongoing commitment to engineering excellence. It involves a multi-faceted approach encompassing advanced architectural design, sophisticated software engineering, robust diagnostic tools, and continuous innovation.
Optimized Architectures and Software Engineering
At the foundational level, mitigating prolonged QT requires meticulously optimized architectures and highly efficient software. This begins with the selection and implementation of real-time operating systems (RTOS) designed to guarantee predictable task execution and minimal latency. Software development practices must prioritize efficiency, utilizing optimized algorithms and memory management techniques to reduce computational load. A key strategy is hardware-software co-design, where software is specifically tailored to leverage the unique capabilities of dedicated chip architectures, such as Application-Specific Integrated Circuits (ASICs) or Field-Programmable Gate Arrays (FPGAs) for computationally intensive tasks like image processing or AI inference. Furthermore, employing edge computing and distributed processing, where tasks are offloaded to specialized, localized processors rather than relying on a central bottleneck, can dramatically reduce overall internal latency. The development of predictive algorithms can also help compensate for inherent, irreducible QT by anticipating future states based on current and past data, effectively “buying time” for the system to react.
Advanced Diagnostics and Monitoring
Effective mitigation of prolonged QT relies heavily on the ability to detect and diagnose it. This necessitates the development of specialized telemetry and logging tools capable of tracking internal timing metrics at a granular level in real-time. These tools should provide insights into processor utilization, bus loads, sensor read latencies, and critical software execution times. Beyond raw data, advanced machine learning models can be employed to analyze these complex timing patterns, identifying subtle anomalies indicative of impending prolonged QT issues before they manifest as critical failures or performance degradation. Establishing standardized benchmarks for QT performance across different drone systems would also allow for objective comparison, targeted improvements, and a common framework for developers to ensure robust system timing.

The Path Forward: Research and Innovation
The future of mitigating prolonged QT lies at the forefront of technological research and innovation. This includes exploring entirely new hardware paradigms, such as neuromorphic chips, which mimic the structure of the human brain for ultra-low-latency, event-driven processing, or even early-stage quantum computing applications for specific, timing-critical drone functions. Research into novel communication protocols, such as optical data transfer within the drone’s internal architecture, aims to eliminate the electrical impedance and delays inherent in current bus systems. Furthermore, a significant area of development is in adaptive timing systems. These intelligent systems could dynamically adjust processing priorities and resource allocation based on real-time mission requirements, current system load, and detected environmental factors, ensuring that critical operations always receive the necessary computational resources and timing guarantees, even under highly dynamic conditions. The pursuit of minimal and predictable Quantum Timing is an endless endeavor, foundational to unlocking the full potential of future autonomous drone capabilities.