
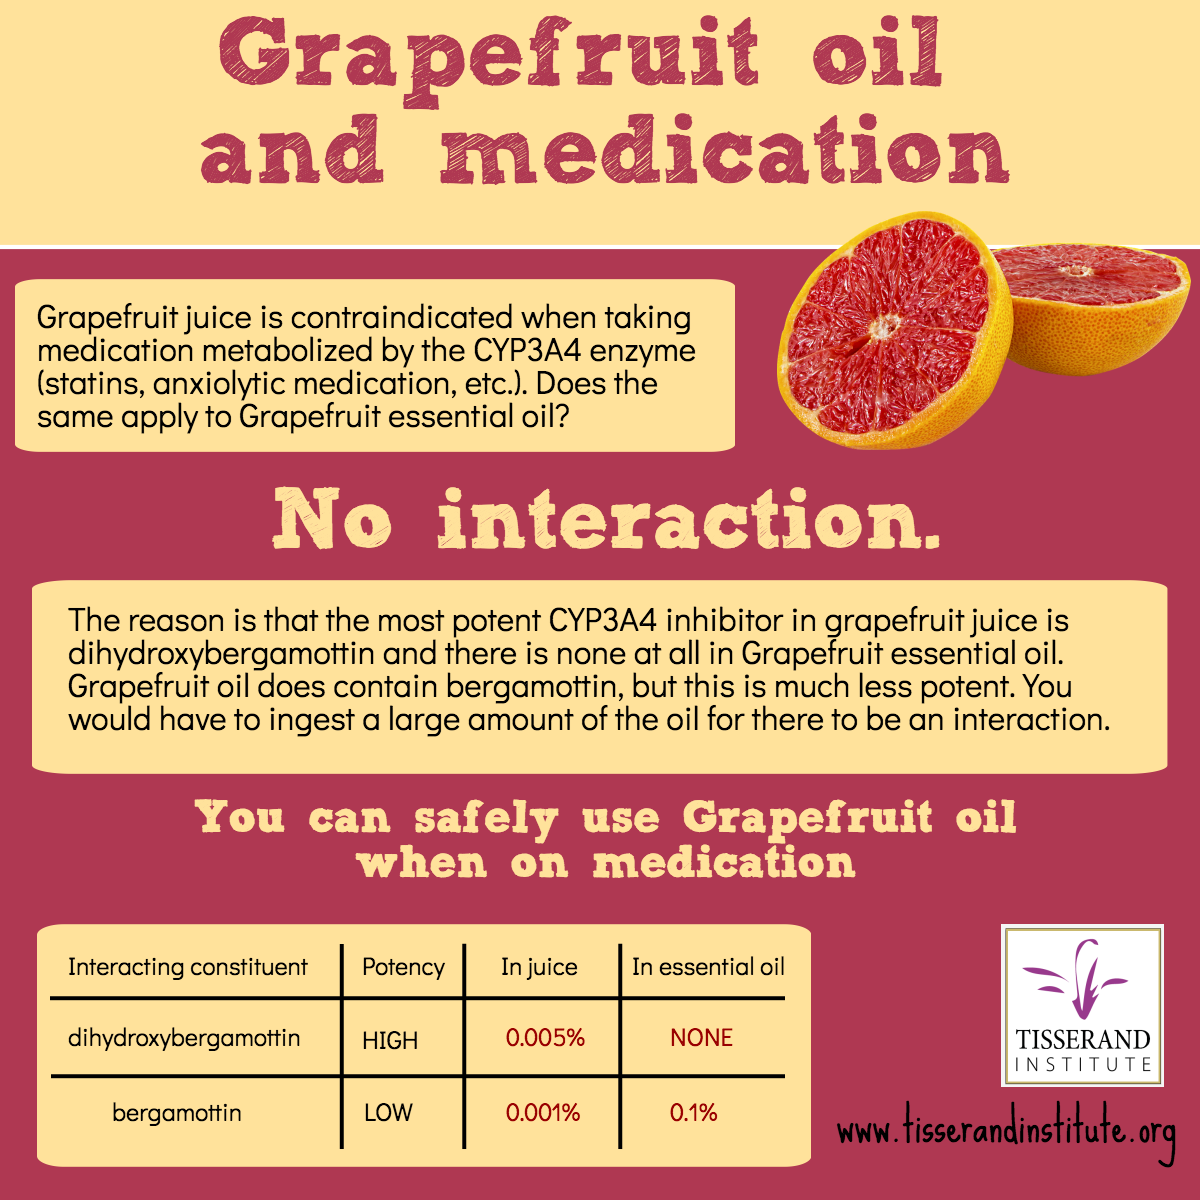
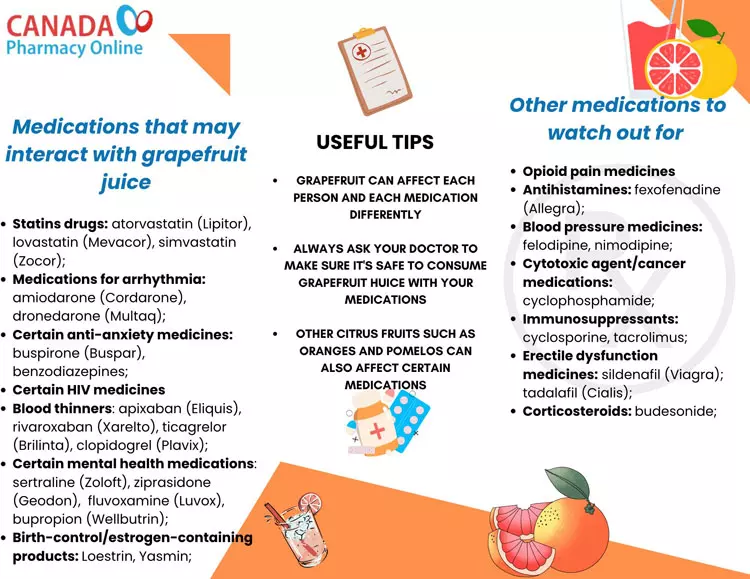
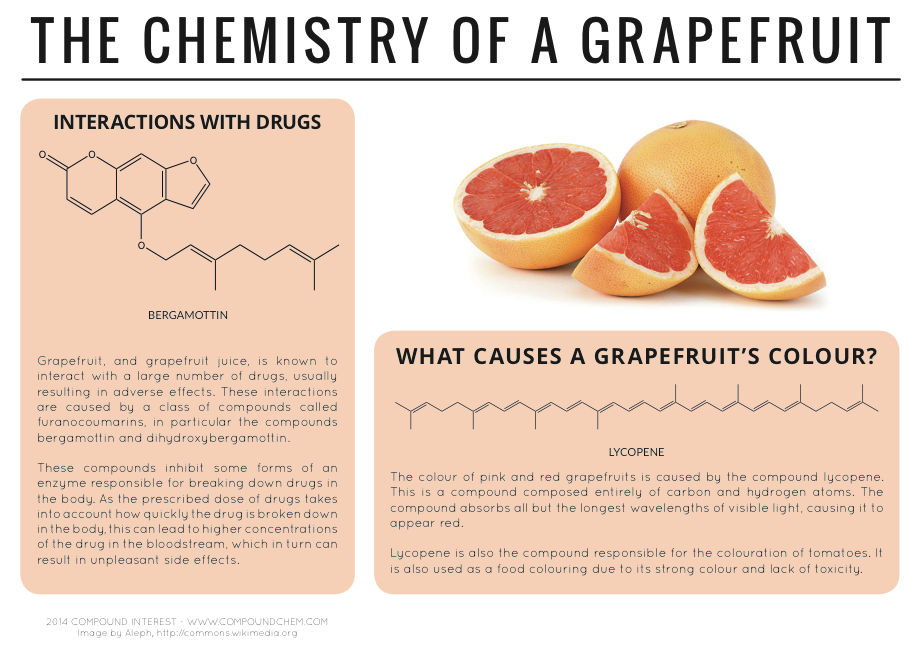
In the rapidly evolving landscape of drone technology, particularly within the realm of Tech & Innovation, engineers and developers frequently encounter complex systemic interactions that can lead to unforeseen operational challenges. While the phrase “grapefruit interaction” is colloquially understood in a pharmacological context, in the intricate world of advanced aerial systems, we can draw a potent metaphor. The “Grapefruit Effect,” in this technological paradigm, refers to subtle, often emergent, and difficult-to-predict cross-system dependencies or environmental influences that significantly alter a drone’s expected behavior or performance. Much like the biochemical interactions that complicate medical treatments, these drone-related “grapefruit” interactions demand profound understanding and innovative solutions to ensure reliable and safe operation of intelligent UAVs.
The increasing sophistication of drone platforms, integrating advanced AI, autonomous flight capabilities, precise mapping, and multifaceted remote sensing, inherently amplifies the potential for such complex interactions. As more subsystems become interconnected and algorithms grow more intricate, isolating the root cause of an unexpected behavior can become a formidable task. This article delves into the nature of these “grapefruit” interactions, exploring their impact on various aspects of drone innovation and outlining strategies for mitigation.
Understanding the “Grapefruit Effect” in Drone Innovation
The “Grapefruit Effect” in drone technology is not a single, definable component but rather an overarching metaphor for the intricate web of dependencies that govern a drone’s advanced functions. It describes how seemingly minor or indirect influences—be they from sensor noise, environmental variables, software module interactions, or even subtle electromagnetic interference—can cascade through a system, producing significant and sometimes catastrophic outcomes. This phenomenon is particularly relevant as drones move beyond simple remote control to highly autonomous operations that rely on robust data fusion, real-time decision-making, and adaptive control.
The core challenge lies in the non-linear nature of these interactions. A small change in one parameter might have no effect under most conditions but trigger an unexpected response when combined with specific values of other parameters. This makes conventional testing and debugging methodologies insufficient, as the sheer number of possible interaction states is astronomical. As AI-driven capabilities like object recognition, predictive analytics, and self-optimization become standard, understanding and predicting these emergent “grapefruit” interactions becomes paramount for the safety, reliability, and widespread adoption of drone technology.
Interplay with Autonomous Flight and Navigation Systems
Autonomous flight represents the pinnacle of drone innovation, requiring seamless integration of navigation, perception, and decision-making modules. It is here that the “Grapefruit Effect” can manifest with critical consequences, influencing everything from precise waypoint adherence to obstacle avoidance.
GPS and Sensor Fusion Anomalies
Modern drones rely heavily on Global Positioning System (GPS) data, often augmented by other sensors like Inertial Measurement Units (IMUs), barometers, magnetometers, lidar, radar, and vision systems, all integrated through sophisticated sensor fusion algorithms. A “grapefruit” interaction might occur when subtle electromagnetic interference, perhaps from an urban environment or even within the drone’s own electronics, subtly degrades GPS signal quality. This degradation might not be immediately flagged as a hard error but instead introduces a slight, intermittent drift. Concurrently, a minor calibration error in the IMU, when combined with this GPS drift and specific atmospheric conditions affecting barometer readings, could lead to cumulative positional inaccuracies far greater than any single error source would suggest.
Such complex interactions can trick the sensor fusion algorithms into believing the drone is in a slightly different location or orientation than it actually is. This seemingly minor discrepancy can have profound effects on flight paths, especially in dense environments where centimeter-level precision is required. Obstacle avoidance systems, for instance, might misinterpret their proximity to an object if their positional data is subtly skewed, potentially leading to near-misses or collisions.
AI Decision-Making Under “Grapefruit” Influence
The decision-making capabilities of AI-powered autonomous drones are highly susceptible to “grapefruit” interactions. AI models, particularly deep learning networks, are trained on vast datasets and are designed to identify patterns and make inferences. However, when presented with inputs that are subtly corrupted or contradictory due to unforeseen systemic interactions, their decision processes can become compromised.
Consider an AI follow mode, designed to track a subject through a complex environment. If the visual processing subsystem (e.g., camera sensor interacting with specific lighting conditions, lens flare, or object reflectivity) provides subtly distorted or ambiguous data to the AI’s tracking algorithm, coupled with unusual vibrations affecting the gimbal’s stabilization, the AI might misinterpret the subject’s movement. Instead of a smooth, predictable follow, the drone might exhibit erratic movements, lose lock on the target, or even attempt to follow a phantom object. These “grapefruit” interactions introduce noise and uncertainty into the AI’s perceptual and cognitive pipeline, leading to suboptimal or even dangerous autonomous behaviors.
“Grapefruit” Interactions in Mapping and Remote Sensing
Drone-based mapping and remote sensing applications leverage an array of specialized sensors to collect vast amounts of data for various analytical purposes. The integrity and accuracy of this data are paramount, and complex interactions can pose significant threats to its reliability.
Data Integrity and Accuracy Challenges
In remote sensing, different sensors—such as thermal cameras, multispectral imagers, or lidar units—operate under specific principles and are influenced by various environmental factors. A “grapefruit” interaction could arise when the calibration of a thermal sensor, which accounts for ambient temperature and emissivity, is subtly affected by an unforeseen interaction with the drone’s internal heat management system and a rapid change in external humidity. This might lead to localized hot spots or cold spots in the thermal map that do not correspond to reality, rendering the data inaccurate for applications like agricultural analysis or building inspection.
Similarly, in high-precision mapping, a lidar scanner might experience subtle angular drift due to vibrations interacting with its internal gyroscopes, while concurrently, the drone’s flight path experiences minor deviations from its planned trajectory due to external wind gusts interacting with the flight controller’s PID loops. The combination of these individually minor errors can result in significant distortions in the generated 3D point cloud or digital elevation model, impacting the accuracy of infrastructure planning, environmental monitoring, or volume calculations. Such subtle, compound errors are incredibly difficult to trace back to a single source and underscore the pervasive nature of the “Grapefruit Effect.”
Calibration Drift and System Resilience
“Grapefruit” interactions can also contribute to exacerbated calibration drift in sensor systems or lead to intermittent operational failures that defy easy diagnosis. While sensors are designed with a certain degree of resilience, prolonged exposure to interacting environmental stresses (e.g., temperature cycling, vibration, electromagnetic fields) can accelerate performance degradation. For instance, the optical components of a high-resolution camera might experience slight micro-movements when exposed to specific frequencies of drone vibration, which in turn interacts with the internal focus mechanism’s tolerances. This subtle shift might manifest as intermittent blurring or reduced image sharpness, only appearing under particular flight conditions.
Ensuring system resilience against such complex, interacting phenomena requires not just robust individual components but also an architecture that can detect, isolate, and potentially compensate for these emergent issues. This involves developing sophisticated self-monitoring capabilities and adaptive algorithms that can recalibrate or adjust sensor parameters dynamically in response to detected “grapefruit” interactions, preserving data quality and operational integrity.
Mitigating the Complexity: Strategies for Robust Drone Innovation
Addressing the “Grapefruit Effect” requires a multi-faceted approach, emphasizing predictive modeling, real-time adaptation, and robust system design. As drone technology continues its trajectory towards greater autonomy and integration, these mitigation strategies become indispensable for ensuring reliability and trust.
Advanced Simulation and Digital Twins
One of the most powerful tools for understanding and predicting complex interactions is advanced simulation. High-fidelity computational models can simulate the physical and operational environment, allowing engineers to test drone behavior under a vast array of interacting variables. Furthermore, the development of “digital twins”—virtual replicas of physical drones that mirror their real-time performance and behavior—offers an unprecedented opportunity to analyze “grapefruit” interactions. These digital twins can be subjected to extreme conditions and complex interaction scenarios that would be impractical or unsafe to replicate with physical hardware. By stress-testing the digital counterpart, developers can identify potential vulnerabilities and emergent behaviors before they manifest in real-world deployments, significantly reducing development costs and improving safety.
Real-time Anomaly Detection and Adaptive Algorithms
For interactions that cannot be fully predicted through simulation, real-time anomaly detection is crucial. Integrating AI and machine learning models directly into drone flight controllers allows the system to continuously monitor sensor inputs, system states, and behavioral outputs for deviations from expected norms. These models can learn baseline behaviors and identify subtle shifts indicative of “Grapefruit Effect” interactions. Upon detection, adaptive algorithms can then reconfigure system parameters, adjust control strategies, or even initiate fail-safe protocols. For instance, if an unexpected interaction causes a slight instability in flight, an adaptive control system could autonomously adjust propeller speeds or gimbal stabilization to compensate, maintaining stability without requiring human intervention. This proactive and reactive capability is vital for operating intelligently in dynamic and unpredictable environments.
Modular Design and Standardized Interfaces
From a design perspective, fostering modularity and employing standardized interfaces can significantly mitigate the “Grapefruit Effect.” By breaking down complex drone systems into smaller, independent modules with clearly defined functions and minimal interdependencies, engineers can reduce the surface area for unforeseen interactions. Each module can be developed and tested in isolation, and their interactions are managed through strictly enforced, standardized protocols and APIs. This approach helps prevent “cross-talk” and unintended side effects that can arise when tightly coupled components influence each other in unexpected ways. Furthermore, modularity simplifies the diagnostic process, making it easier to pinpoint the source of an issue when a “grapefruit” interaction does occur, as the problem can often be isolated to a specific module or interface.
In conclusion, while “grapefruit interaction” may seem an unusual term in the context of drones, its metaphorical application highlights a critical challenge in advanced Tech & Innovation. By recognizing the potential for complex, emergent interactions within and between sophisticated drone subsystems and their environments, developers can adopt proactive strategies. Through advanced simulation, real-time adaptive systems, and robust modular design, the industry can better anticipate, understand, and mitigate these “Grapefruit Effects,” paving the way for more reliable, autonomous, and groundbreaking aerial solutions.