
The Central Processing Unit: Core Vulnerabilities
The “brain” of any advanced aerial system, particularly a drone, is its flight control unit (FCU). This complex ensemble of hardware and software serves as the central nervous system, processing vast amounts of data from an array of sensors, making critical decisions, and executing commands to maintain stable and controlled flight. While not susceptible to literal alcoholic intoxication, this intricate “brain” faces its own set of debilitating factors—digital “alcohol” in the form of signal noise, data corruption, software anomalies, and electromagnetic interference—that can severely impair its functionality and lead to unpredictable, often catastrophic, outcomes. Understanding these vulnerabilities is paramount for designing robust and reliable flight technology.
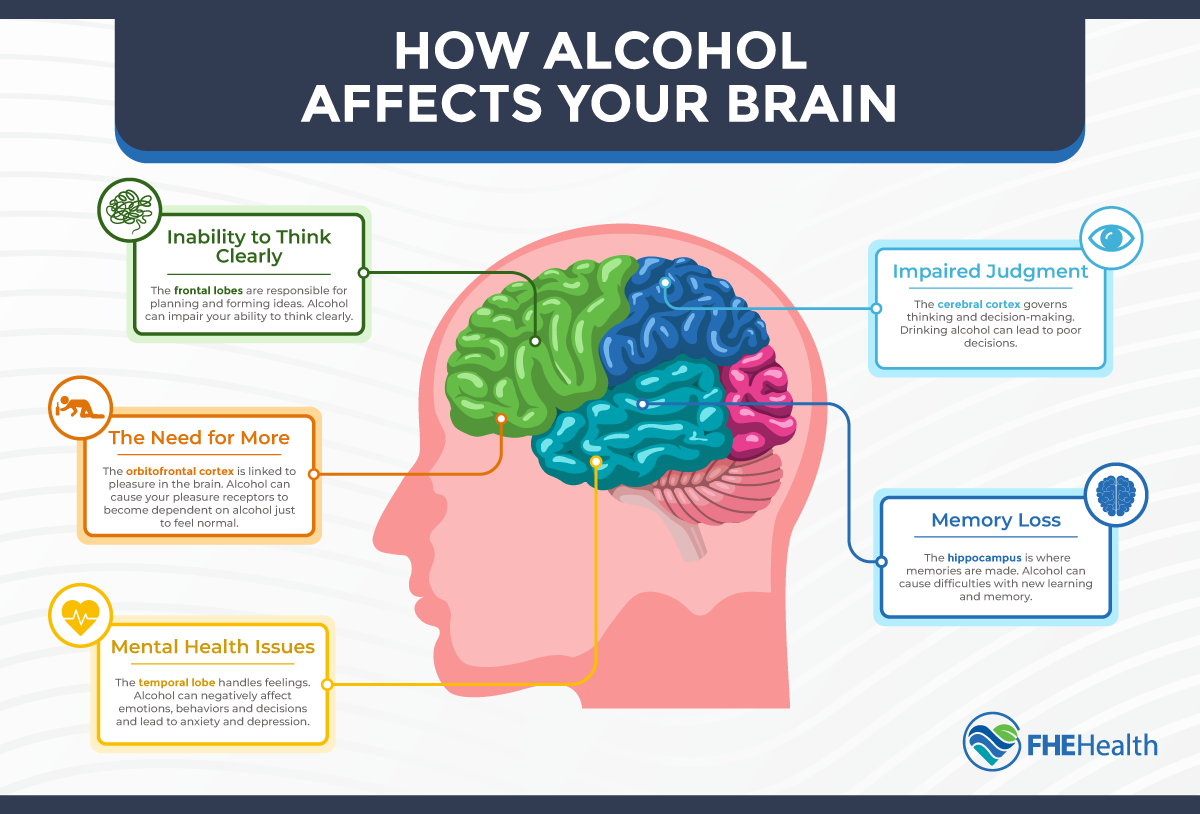
At its core, the FCU relies on precision and timely data. Any degradation in the quality or consistency of this data acts as a powerful disruptor, akin to the way alcohol impairs neural pathways. For instance, a momentary voltage dip could be interpreted as an incorrect sensor reading, or a corrupted instruction in the flight firmware could lead to erratic motor responses. Modern FCUs incorporate redundant processing cores and error-checking protocols to counteract some of these internal “intoxicants.” However, the sheer complexity of the integrated systems means that obscure interactions between different modules can still introduce unexpected vulnerabilities. Continuous monitoring of system health, real-time diagnostics, and adaptive algorithms that can detect and compensate for minor processing anomalies are crucial in preventing the FCU from entering a state of functional impairment. Furthermore, the very environment in which these devices operate, rife with electromagnetic fields and radio frequency interference, constantly bombards the FCU with potential “toxins” that can blur its digital perception and hinder its ability to execute precise control. Shielding, filtering, and robust communication protocols are essential defenses against this invisible barrage, safeguarding the FCU’s cognitive integrity.
Navigational Impairment: Drifting Through Digital Fog
One of the most profound effects of “alcohol” on the drone’s brain manifests as navigational impairment. Precise positioning is the bedrock of autonomous flight and intricate maneuvers, relying heavily on Global Positioning System (GPS) data, Inertial Measurement Units (IMUs), and often vision-based positioning systems. When these systems are subjected to interference or inaccuracies—the drone’s equivalent of consuming intoxicating substances—the ability to maintain a stable, predictable flight path is severely compromised, leading to a dangerous “digital fog.”
GPS Signal Degradation
GPS is notoriously susceptible to various forms of interference. Urban canyons, heavy foliage, atmospheric conditions, and intentional jamming or spoofing can significantly degrade signal quality or even provide erroneous location data. For a drone’s “brain,” this is like attempting to navigate through a dense fog while having an unreliable compass. Without clear and consistent GPS lock, the drone may begin to drift, misinterpret its position, or become unable to execute pre-programmed waypoints accurately. Advanced flight technology mitigates this through multi-constellation GNSS receivers (accessing GPS, GLONASS, Galileo, BeiDou), which provide more satellite coverage and redundancy. Furthermore, differential GPS (DGPS) or Real-Time Kinematic (RTK) GPS systems use ground-based reference stations to correct positional errors, significantly enhancing accuracy and making the drone’s “perception” of its location much clearer, even in challenging environments.
IMU Sensor Drift
The IMU, comprising accelerometers, gyroscopes, and magnetometers, provides crucial data on the drone’s orientation, velocity, and angular rate. However, these sensors are prone to cumulative errors known as “drift” over time, especially without regular external calibration or correction. This drift is another form of “intoxication” for the navigation system, slowly skewing the drone’s understanding of its own attitude and motion. A drone with an intoxicated IMU might incorrectly perceive itself as level when it’s tilting, or believe it’s holding a steady course when it’s actually veering. Sophisticated sensor fusion algorithms play a vital role here, intelligently combining data from the IMU with GPS, barometers, and even optical flow sensors. This fusion creates a more robust and self-correcting estimate of the drone’s state, allowing the system to filter out individual sensor noise or temporary inaccuracies, thus maintaining its navigational sobriety.
Sensory Deception: The Peril of Corrupted Inputs
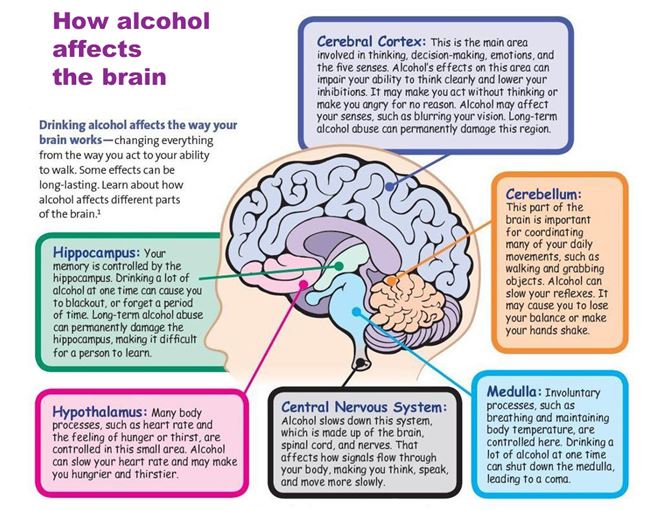
The drone’s “brain” relies heavily on its sensory organs—cameras, ultrasonic sensors, lidar, and radar—to perceive its immediate environment. These senses are critical for obstacle avoidance, precision landing, and intelligent flight modes. However, just as alcohol distorts human perception, various forms of “sensory deception” can severely compromise a drone’s ability to accurately interpret its surroundings, leading to collisions or failed missions.
Vision System Interference
Visual sensors, including standard RGB and thermal cameras, provide rich data for tasks like object recognition, mapping, and navigating complex environments. Yet, external factors such as poor lighting conditions, fog, rain, glare, or even physical obstructions like dust on a lens can act as a form of “visual impairment.” For a drone’s “brain,” this is akin to blurry vision or seeing double—it struggles to accurately identify objects, assess distances, or track targets. Advanced computer vision algorithms, including those powered by artificial intelligence, are developed to be resilient to these challenges. Techniques like dynamic range optimization, noise reduction, and robust object tracking frameworks help the system “see” more clearly despite imperfect conditions. Furthermore, integrating multiple visual sensors with different fields of view or spectral responses can provide redundant information, allowing the system to cross-reference data and detect inconsistencies, much like how a sober mind uses multiple cues to confirm reality.
Obstacle Avoidance Malfunctions
Obstacle avoidance systems are a prime example of where sensory deception can have immediate and dire consequences. Ultrasonic sensors can be confused by soft, sound-absorbing materials, while lidar and radar can struggle with transparent objects like glass or fine wires. These blind spots represent specific “intoxicants” that can lead to misjudgments. The flight technology industry addresses this by deploying multi-modal sensor arrays, combining various sensor types to overcome the limitations of any single technology. For example, a drone might use ultrasonic sensors for close-range detection, lidar for medium-range mapping, and vision cameras for object classification. The FCU then intelligently fuses this data, building a comprehensive and less fallible “mental map” of its surroundings. Robust sensor fusion helps the drone’s brain filter out misleading inputs from individual sensors, ensuring it can make sound decisions about avoiding obstacles rather than becoming disoriented by conflicting information.
Mitigating the Intoxicants: Resilience in Flight Systems
The ultimate goal of advanced flight technology is to build resilience into the drone’s “brain,” making it resistant to the many forms of “intoxication” it might encounter. This involves a multi-layered approach, from hardware design to sophisticated software algorithms and operational protocols.
Redundancy and Self-Correction
One of the most effective strategies against critical system failure is redundancy. This means having backup systems or parallel components that can take over if a primary system becomes “impaired.” For instance, some high-end drones feature dual IMUs, allowing the flight controller to cross-verify data and detect inconsistencies. If one IMU shows signs of erratic behavior (intoxication), the system can seamlessly switch to or prioritize data from the healthy sensor. Similarly, redundant power systems ensure that a single battery failure doesn’t lead to a complete loss of power, maintaining the “brain’s” ability to function. Beyond hardware, sophisticated error detection and correction algorithms in software continuously monitor data streams and system states. These algorithms are designed to identify anomalies that might signal an “intoxicated” component, isolate the issue, and, where possible, apply corrective measures or switch to a degraded but safe mode of operation.

Adaptive Control and Machine Learning
The drone’s “brain” is increasingly empowered by adaptive control systems and machine learning algorithms. These technologies allow the flight controller to learn and adapt to changing conditions and even to compensate for minor system degradations over time. An adaptive controller, for example, can adjust its control parameters in real-time to maintain stable flight even if a propeller is slightly damaged or an actuator experiences minor fatigue. Machine learning models, trained on vast datasets of flight scenarios and potential anomalies, can predict potential points of “intoxication” before they lead to critical failure. They can identify subtle patterns in sensor data that indicate an impending malfunction, allowing the system to alert the operator or initiate preventive measures. This proactive approach to managing system health makes the drone’s “brain” far more resilient, capable of maintaining clarity and function even when faced with subtle or evolving forms of impairment. By continuously refining its understanding of itself and its environment, the drone’s flight technology strives for a state of perpetual digital sobriety, ensuring reliable and safe aerial operations.