
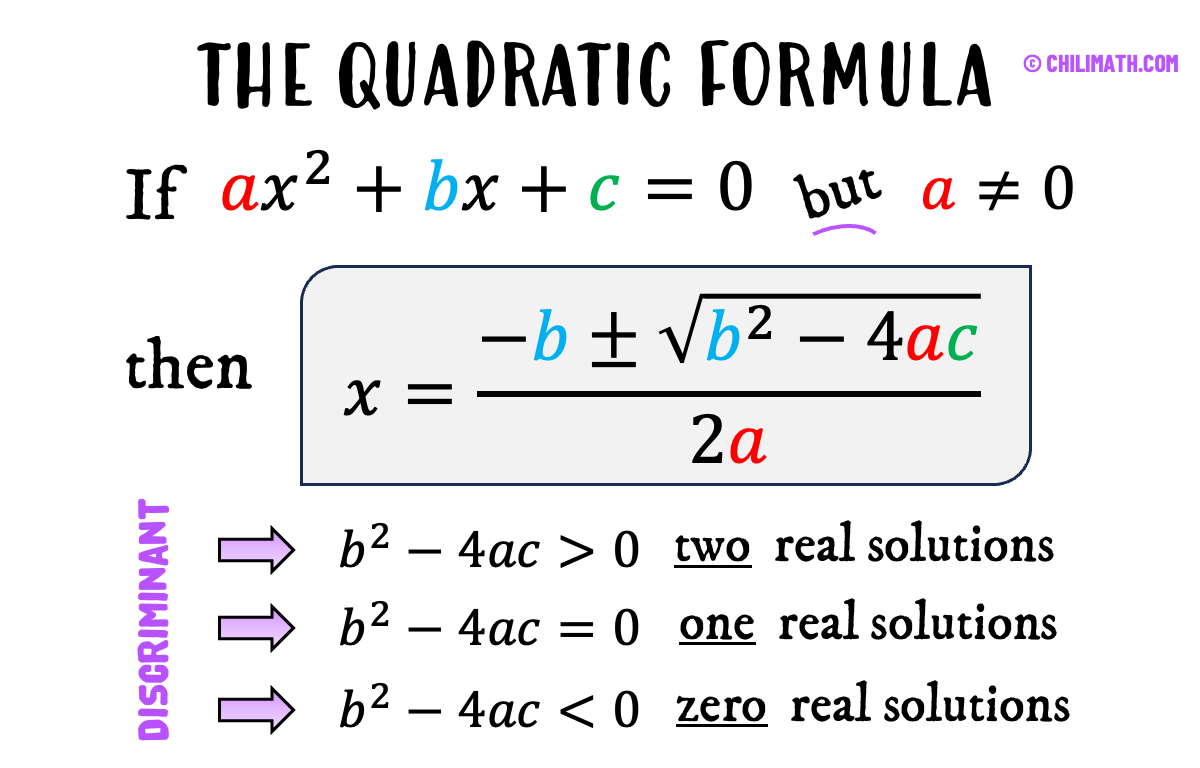
In the complex tapestry of modern drone technology and innovation, mathematical principles serve as the foundational threads, often unseen but indispensable. Among these, the quadratic equation, a seemingly simple algebraic expression of the form $ax^2 + bx + c = 0$, plays a surprisingly pervasive and critical role. Far from being confined to high school algebra textbooks, its influence extends deeply into the algorithms that power autonomous flight, sophisticated AI follow modes, precise mapping, and advanced remote sensing capabilities of unmanned aerial vehicles (UAVs). Understanding where and how these fundamental equations manifest reveals the intricate computational intelligence behind cutting-edge drone applications.
The Mathematical Backbone of Autonomous Flight
Autonomous flight, the pinnacle of drone innovation, relies heavily on predictive models and real-time optimization. At its heart, the ability of a drone to navigate, avoid obstacles, and execute complex maneuvers without human intervention is frequently underpinned by principles that trace back to quadratic equations.
Trajectory Planning and Optimization
For a drone to move from point A to point B efficiently, it must compute a trajectory. While the physical flight path of a drone is governed by complex aerodynamic forces, the underlying planning algorithms often simplify these challenges into solvable mathematical problems. Quadratic equations become crucial when dealing with motion under constant acceleration, where displacement is a quadratic function of time. More significantly, in advanced trajectory planning, especially for dynamic environments or constrained spaces, drones employ techniques like quadratic programming (QP).
Quadratic programming involves optimizing a quadratic objective function subject to linear constraints. For a drone, this objective function might represent the minimization of energy consumption, flight time, control effort (to ensure smooth motion), or the deviation from a desired path. The constraints could include limitations on velocity, acceleration, maximum climb rates, or collision avoidance boundaries. By solving these QP problems in real-time, autonomous drones can generate smooth, safe, and efficient flight paths, dynamically adjusting to changing conditions. This optimization capability is central to creating intelligent, adaptable drone behaviors, moving beyond simple waypoint navigation to genuinely dynamic autonomy.
Predictive Control Systems
The stability and precision of autonomous drones hinge on sophisticated control systems. Model Predictive Control (MPC) is a prime example where quadratic equations are fundamental. MPC works by using a dynamic model of the drone to predict its future behavior over a finite time horizon. Based on these predictions, an optimal sequence of control actions (e.g., motor speeds, gimbal adjustments) is calculated by solving an optimization problem at each time step.
Often, this optimization problem is formulated as a quadratic program, where the objective is to minimize a quadratic cost function. This cost function typically penalizes deviations from desired setpoints (e.g., maintaining altitude, heading, or target position) and excessive control efforts. The quadratic nature ensures that the problem has a unique solution and can be solved efficiently, making MPC suitable for real-time applications requiring quick, precise responses. This iterative process of prediction, optimization (via quadratic solutions), and control action is what allows drones to maintain stability, track targets accurately, and perform complex maneuvers with remarkable agility.
Sensor Fusion and State Estimation
For a drone to know its exact position, orientation, and velocity in 3D space—its “state”—it must integrate data from various onboard sensors, such as GPS, IMUs (Inertial Measurement Units: accelerometers and gyroscopes), magnetometers, and altimeters. This process of combining noisy, imperfect sensor readings to arrive at a more accurate estimate is known as sensor fusion, and quadratic mathematics plays a vital role.
Enhancing Data Accuracy with Least Squares
Many sensor fusion algorithms, particularly those based on least squares estimation, fundamentally rely on quadratic principles. The least squares method aims to find the “best fit” solution to an overdetermined system of equations by minimizing the sum of the squares of the residuals (the differences between observed and predicted values). For example, when a drone receives multiple, slightly different GPS readings, or combines accelerometer data with gyroscope readings, a least squares approach can be used to compute the most probable true position and orientation. The objective function being minimized is inherently quadratic, representing the squared error, which allows for efficient and robust solutions even with noisy data. This forms the basis for accurate localization and mapping in complex environments.

Kalman Filters and Beyond
Beyond simple least squares, advanced state estimation techniques like the Kalman Filter and its non-linear extensions (Extended Kalman Filter, Unscented Kalman Filter) also heavily incorporate quadratic concepts. These filters operate by iteratively predicting the drone’s future state and then updating that prediction with actual sensor measurements. The core of their mathematics involves propagating and updating covariance matrices, which quantify the uncertainty of the state estimate. These covariance matrices are expressed in quadratic forms, and the filter’s equations involve minimizing quadratic error terms to achieve the optimal estimate of the drone’s state. Without these quadratic foundations, achieving the level of precision and robustness required for modern autonomous drone operations, from stable flight to accurate mapping, would be significantly more challenging.
AI Follow Mode and Object Tracking
The “AI Follow Mode,” where a drone autonomously tracks a moving subject, is a compelling demonstration of integrated intelligence. This feature, central to aerial filmmaking and surveillance, relies on predicting the target’s movement and optimizing the drone’s own trajectory to maintain a stable, desired perspective.
Predicting Object Movement
To effectively follow a subject, the drone’s AI must anticipate the target’s future position. While advanced neural networks are often used for perception, simpler, effective predictive models can employ quadratic equations. For instance, if a target is moving with a relatively constant acceleration or deceleration, its future position can be modeled as a quadratic function of time. This basic kinematic prediction, often integrated into more complex probabilistic models, provides a crucial initial estimate for the drone’s tracking algorithms, allowing for smoother, more proactive following rather than reactive pursuit.
Optimization for Smooth Tracking
Once the target’s predicted position is known, the drone needs to determine its own optimal flight path to maintain the follow. This is another area where quadratic optimization comes into play. The drone’s control system sets up a cost function that typically aims to minimize the distance error to the target, maintain a specific relative angle, and ensure the drone’s own movements are smooth (i.e., minimal changes in velocity and acceleration). By formulating these objectives and constraints as a quadratic program, the drone can solve for the optimal control inputs that result in stable, cinematic tracking, avoiding jerky movements and maintaining precise perspective even when the target’s movement is erratic.
Mapping, Remote Sensing, and Data Processing
Drones equipped with high-resolution cameras and sensors are revolutionizing mapping and remote sensing, providing unprecedented levels of detail and efficiency. The conversion of raw sensor data into actionable 2D maps or 3D models involves complex computational processes where quadratic equations are foundational to accuracy and consistency.
Geometric Reconstruction and Photogrammetry
In photogrammetry, the science of making measurements from photographs, drones capture numerous overlapping images. To reconstruct a 3D model or a precise 2D orthomosaic map, these images must be accurately aligned and scaled. This involves solving a large-scale optimization problem known as bundle adjustment. At its core, bundle adjustment minimizes the sum of squared re-projection errors—the differences between the observed image points and the points projected from the 3D model. This minimization of a quadratic error function is crucial for achieving highly accurate and geometrically consistent maps and 3D models. Without the ability to efficiently solve these quadratic optimization problems, the precise geometric reconstruction necessary for applications like surveying, construction monitoring, and environmental analysis would be practically impossible.

Feature Matching and Localization
For simultaneous localization and mapping (SLAM), a key technology for autonomous drones operating in GPS-denied environments, the drone must simultaneously build a map of its surroundings while estimating its own position within that map. This process relies on identifying and matching features (distinctive points or patterns) across different sensor readings (e.g., visual features from a camera, lidar points). The process of matching these features and refining the drone’s pose (position and orientation) and the map’s features often involves minimizing error metrics that are quadratic in nature. Robust estimation techniques, such as RANSAC or M-estimators, often fit models by minimizing squared errors to filter out outliers and achieve accurate localization and mapping, even in challenging conditions.
In conclusion, while “what quadratic equation” might seem like a question divorced from the cutting edge of drone technology, its underlying principles are interwoven throughout the most innovative aspects of UAV development. From optimizing flight trajectories and enhancing navigation accuracy to enabling intelligent tracking and precise 3D mapping, the fundamental concepts rooted in quadratic mathematics empower drones with the autonomy, precision, and intelligence that define the future of aerial innovation.