The realm of modern flight technology, especially in the rapidly evolving drone sector, is built upon a bedrock of fundamental physics principles. Among these, the concept of “velocity” is not merely an academic term but a critical operational parameter that dictates everything from stable flight to precise navigation and autonomous functions. Often encountered in discussions around drone performance, sensor data, and flight planning, a clear understanding of velocity—what it is and how it functions within complex flight systems—is indispensable for anyone seeking to delve deeper into aerial technology.
The Fundamental Concept of Velocity in Flight
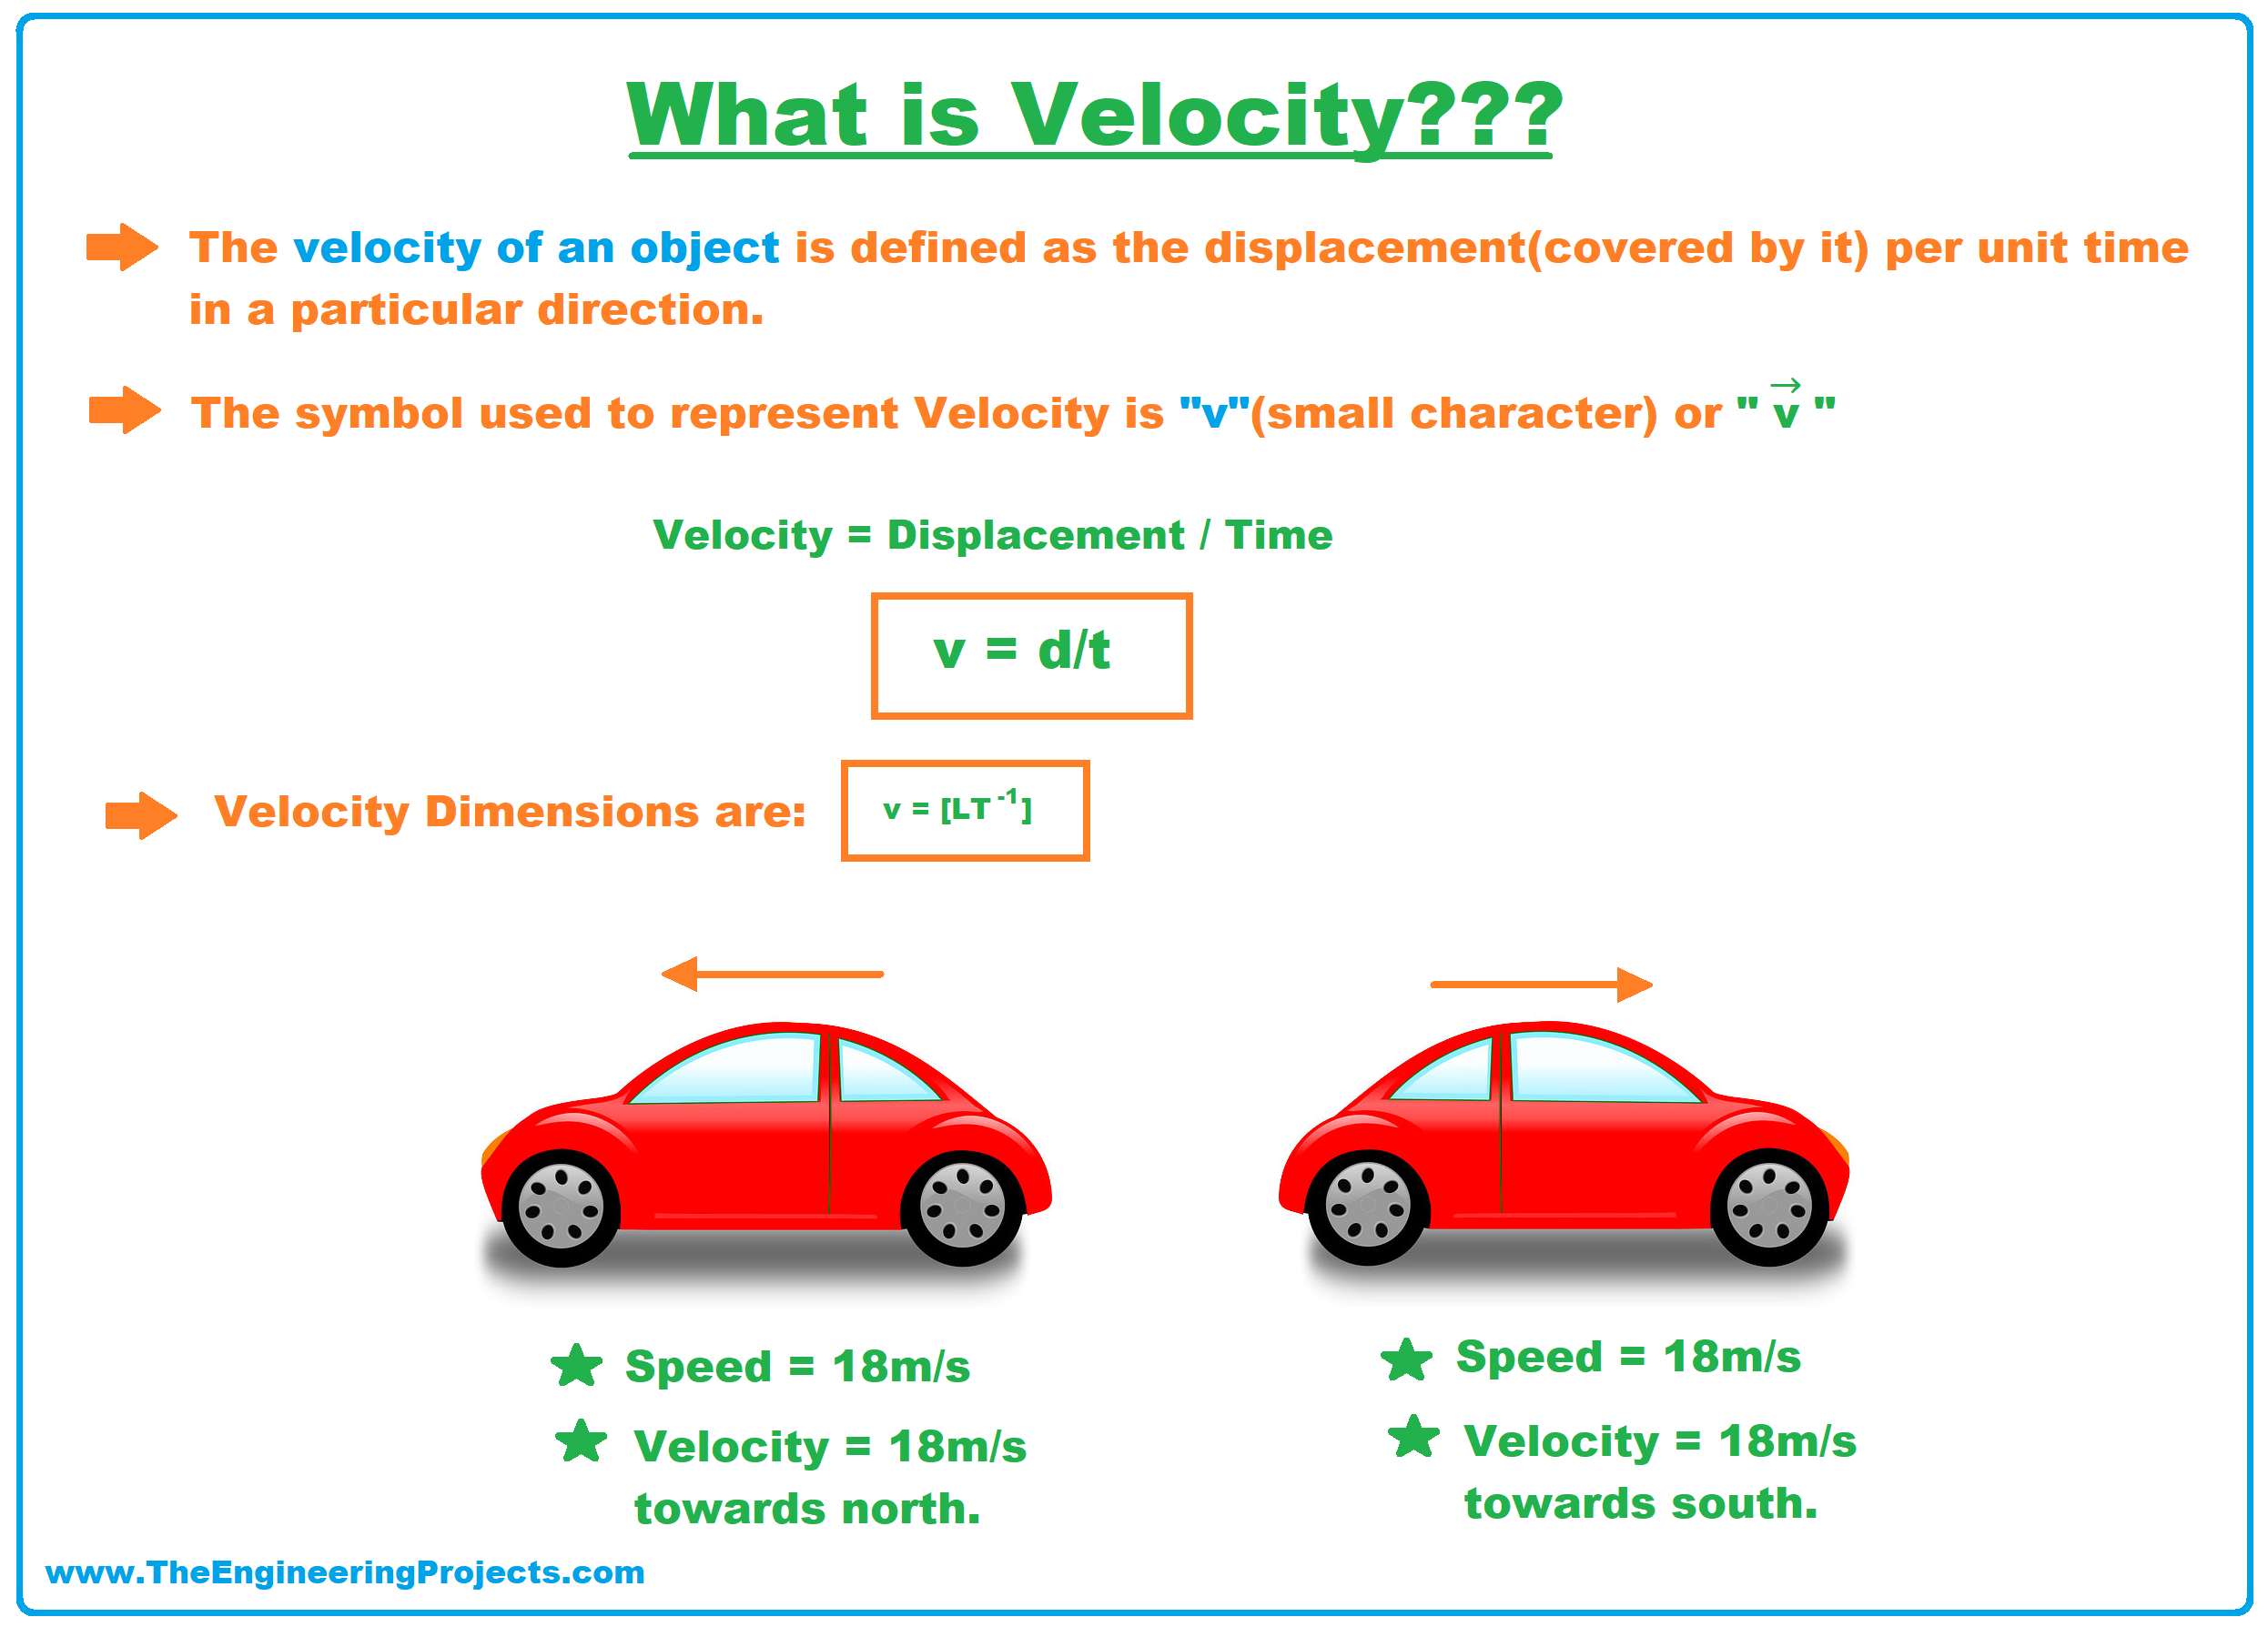
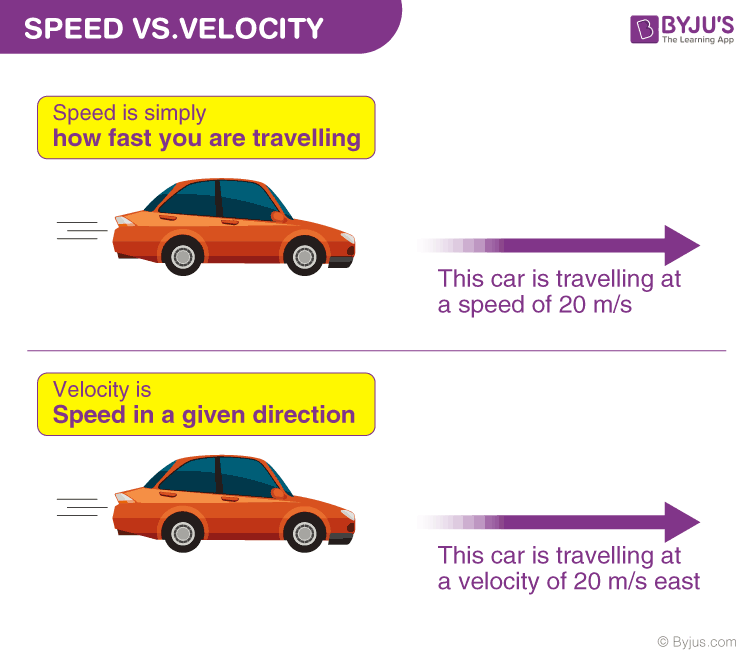
At its core, velocity describes the rate at which an object changes its position. While seemingly simple, its implications for flight technology are profound. Unlike “speed,” which is a scalar quantity indicating only magnitude (e.g., 50 mph), velocity is a vector quantity, meaning it possesses both magnitude and direction. This distinction is paramount in aviation, where knowing not just how fast an aircraft is moving, but also precisely where it is heading, is a matter of safety and mission success.
Speed vs. Velocity: A Crucial Distinction
Imagine a drone flying around a circular track at a constant rate. Its speed remains constant, say 20 meters per second. However, its velocity is continuously changing because its direction of travel is constantly altering. For an autopilot system or a navigation unit, knowing only the speed would be insufficient to keep the drone on its intended path or to predict its future position. The vector nature of velocity, encompassing both the magnitude (speed) and the specific direction (e.g., 20 m/s due North, or 20 m/s at a 45-degree angle East of North), provides the comprehensive data necessary for accurate control and prediction.
Scalar and Vector Quantities in Aviation
In aviation, nearly every critical measurement related to movement involves vectors. Position, displacement, acceleration, and forces (like lift and drag) are all vector quantities. Velocity, being a key vector, links these elements together. An Inertial Measurement Unit (IMU), for instance, measures angular velocity and linear acceleration in three dimensions. These raw vector measurements are then integrated over time to calculate the drone’s attitude (orientation) and change in velocity, ultimately contributing to an estimate of its current position and trajectory. Without considering the directional component, sophisticated flight control would be impossible, leading to unstable or unpredictable movements.
Velocity’s Role in Drone Navigation and Control
The precise control and navigation of any aerial vehicle, from a commercial airliner to a small consumer drone, hinge on an accurate understanding of its velocity. It is the primary input for path planning, stabilization, and collision avoidance algorithms. Modern flight controllers continuously calculate and adjust the drone’s velocity to maintain desired flight parameters and execute intricate maneuvers.
Inertial Measurement Units (IMUs) and Velocity
IMUs are fundamental to contemporary flight technology. Comprising accelerometers and gyroscopes, they measure linear acceleration and angular velocity, respectively. Gyroscopes directly provide angular velocity data, indicating how fast the drone is rotating around its axes (pitch, roll, yaw). Accelerometers, on the other hand, measure changes in linear velocity. By integrating these measurements over time, the flight controller can estimate the drone’s current linear velocity in three dimensions (forward/backward, left/right, up/down). This data is absolutely vital for stabilization systems, allowing the autopilot to counteract external forces like wind gusts and maintain a level, stable flight path. Without accurate velocity data from the IMU, a drone would quickly become unstable and uncontrollable.
GPS and Derived Velocity Data
Global Positioning Systems (GPS) are another cornerstone of drone navigation. While primarily known for providing precise positional coordinates (latitude, longitude, altitude), GPS receivers also provide velocity data. This velocity is typically calculated by observing the change in position over time or by measuring the Doppler shift of the satellite signals. GPS-derived velocity offers an independent and often highly accurate measurement of ground speed and direction. This external velocity source can be fused with IMU data (often via a Kalman filter) to provide an even more robust and accurate velocity estimate, improving overall navigation, particularly for long-distance flights or autonomous operations where drift must be minimized.
Airspeed vs. Ground Speed
In flight, there’s a critical distinction between airspeed and ground speed, both of which are forms of velocity.
- Airspeed refers to the speed of the aircraft relative to the surrounding air mass. This is what determines the aerodynamic forces (lift and drag) acting on the drone. For fixed-wing drones, maintaining a minimum airspeed is crucial to avoid stalling. For multirotors, while not directly related to lift generation in the same way, understanding relative air movement helps in managing thrust vectors and stability.
- Ground speed is the speed of the aircraft relative to the ground. This is what determines how quickly the drone moves from one geographical point to another and is typically what GPS reports.
The difference between airspeed and ground speed is the wind velocity. If a drone has an airspeed of 30 mph heading North and there’s a 10 mph tailwind from the South, its ground speed will be 40 mph North. If it faces a 10 mph headwind, its ground speed will be 20 mph North. Flight technology systems must account for both, especially when planning missions, managing battery life, or executing precision maneuvers where accurate ground positioning is paramount, yet aerodynamic stability relies on airspeed.
Sensors and Velocity Measurement in Flight Systems
The ability of a flight system to accurately measure its velocity is reliant on an array of sophisticated sensors. These sensors provide the raw data that flight controllers process to understand the drone’s movement through its environment. Different sensor types are optimized for measuring specific aspects of velocity, contributing to a comprehensive picture.
Pitot Tubes and Anemometers
These sensors are primarily used to measure airspeed, especially in fixed-wing aircraft and some larger, more advanced drones. A Pitot tube measures the difference between static and total air pressure, which can then be converted into an airspeed reading. Anemometers, while more common in meteorological applications, can also be adapted for drone use, particularly small propeller-based variants that measure the rotational speed of a small propeller driven by the airflow. Accurate airspeed measurement is critical for flight efficiency, safe operation within the aerodynamic envelope, and preventing stalls in fixed-wing configurations.
Doppler Radar and Lidar
For highly accurate ground speed and altitude measurement, technologies like Doppler radar and Lidar (Light Detection and Ranging) are employed, particularly in professional and military-grade UAVs.
- Doppler Radar works by emitting microwave signals and analyzing the frequency shift (Doppler effect) of the returning echoes. This frequency shift is directly proportional to the relative velocity between the drone and the ground, providing precise ground speed in various weather conditions.
- Lidar systems use pulsed laser light to measure distances. By taking multiple distance measurements rapidly, a Lidar unit can calculate the change in distance over time, thereby deriving the drone’s velocity relative to the scanned surface. Lidar is especially useful for precise altitude hold, terrain following, and generating detailed 3D maps, where highly accurate velocity relative to the terrain is crucial.
Optical Flow Sensors
Optical flow sensors are a common and cost-effective method for measuring relative velocity, especially in smaller drones for indoor flight or low-altitude outdoor operations where GPS signals may be weak or unavailable. These sensors, essentially miniature cameras, capture successive images of the ground below. By analyzing the apparent motion of textures and features between frames, the sensor can calculate the drone’s horizontal velocity relative to the surface directly beneath it. This “optical flow” data is indispensable for achieving stable hovering, precise position holding without GPS, and low-speed navigation, as it provides immediate feedback on ground-relative movement.
Impact on Flight Stability and Performance
The continuous, precise measurement and control of velocity are not just about knowing where a drone is going; they are fundamental to its stability, performance, and ability to execute complex tasks safely and efficiently. Every aspect of autonomous flight relies heavily on robust velocity data.
Autopilots and Velocity Control
Modern autopilots are sophisticated control systems that take velocity measurements as primary inputs. They use complex algorithms to compare the actual velocity (measured by IMU, GPS, optical flow, etc.) with the desired velocity (commanded by the pilot or mission plan). Any discrepancy triggers corrective actions, adjusting motor thrust or control surfaces to bring the drone back to the target velocity vector. This feedback loop is essential for maintaining a stable hover, following a specific flight path, executing turns, and performing smooth ascents and descents. The responsiveness and accuracy of the autopilot directly correlate with the quality and timeliness of velocity data.
Obstacle Avoidance and Trajectory Planning
For drones to operate safely in complex environments, particularly in autonomous modes, robust obstacle avoidance systems are critical. These systems rely heavily on velocity data. By knowing its own velocity and, if possible, the velocity of potential obstacles, a drone can calculate collision probabilities and plan evasive maneuvers. Predicting the future position of the drone and any obstacles requires vector subtraction of their respective velocities and analysis of their relative trajectories. Furthermore, for autonomous missions, trajectory planning algorithms calculate optimal flight paths, which inherently involve defining desired velocity profiles for each segment of the journey, ensuring smooth transitions and efficient energy use.
Energy Efficiency and Flight Envelope
Understanding and controlling velocity also has significant implications for energy efficiency and operating within the drone’s safe flight envelope. For any aerial vehicle, there is an optimal cruising speed (velocity magnitude) at which it achieves the best endurance or range for a given power consumption. Flight management systems use velocity data to advise or automatically adjust flight speed to maximize battery life or fuel efficiency. Additionally, respecting the drone’s maximum and minimum operational velocities (e.g., maximum speed before structural stress, minimum speed to avoid stall) is crucial for safe operation. Pushing a drone beyond its designed velocity limits can lead to structural failure, loss of control, or excessive power consumption, highlighting how fundamental velocity is to both performance optimization and operational safety.
In conclusion, “volocity” — or correctly, velocity — is far more than a simple metric; it is the cornerstone of modern flight technology. From the intricate dance of gyroscopes and accelerometers within an IMU to the global reach of GPS satellites, and the subtle interpretations of optical flow, every component contributes to a coherent understanding of an aircraft’s movement. This understanding empowers engineers to design, and pilots to operate, aerial systems that are not only capable of breathtaking maneuvers but are also remarkably stable, precise, and safe.