
Centrifugal force, often described as a “fictitious” or “inertial” force, is a concept fundamental to understanding rotational motion and its profound implications for flight technology, particularly in the realm of unmanned aerial vehicles (UAVs). While not a true force in the Newtonian sense, it represents the apparent outward force experienced by an object moving in a circular path, as perceived from a rotating reference frame. For drone flight systems, comprehending this phenomenon is critical for robust navigation, stabilization, structural integrity, and propulsion efficiency.
Understanding the Concept: The Inertial Reaction of Rotation
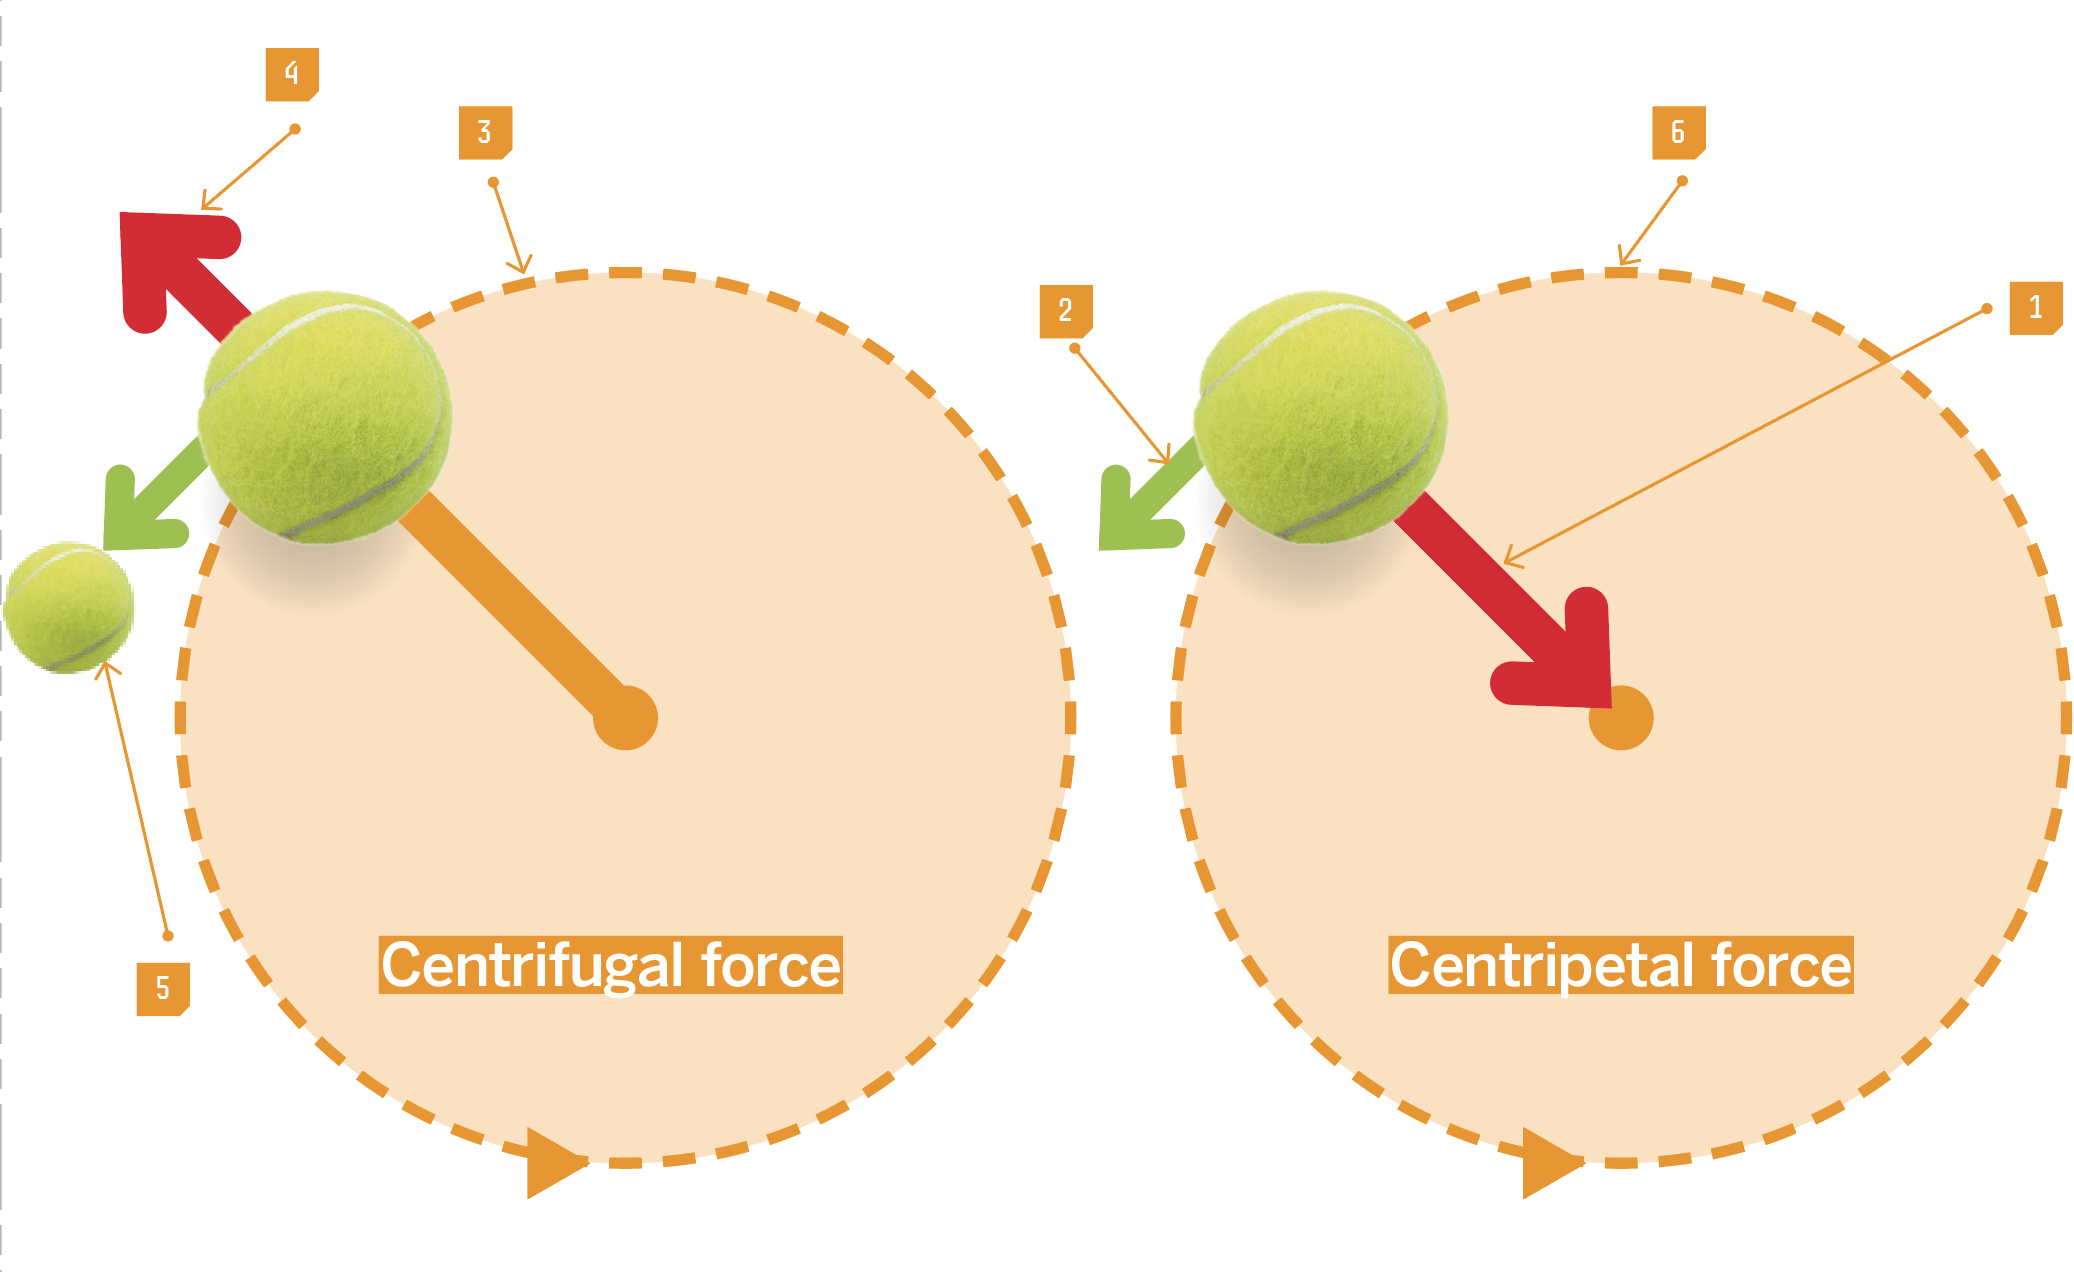
To grasp centrifugal force in the context of flight, it’s essential to first differentiate it from its real counterpart: centripetal force. Centripetal force is a real force that acts inwards, towards the center of a circular path, and is responsible for causing an object to move in a curve. Without an inward centripetal force, an object would continue in a straight line, as dictated by Newton’s first law of motion. For instance, in a turning drone, the tilted thrust vector from the propellers provides the necessary centripetal force to alter its trajectory.
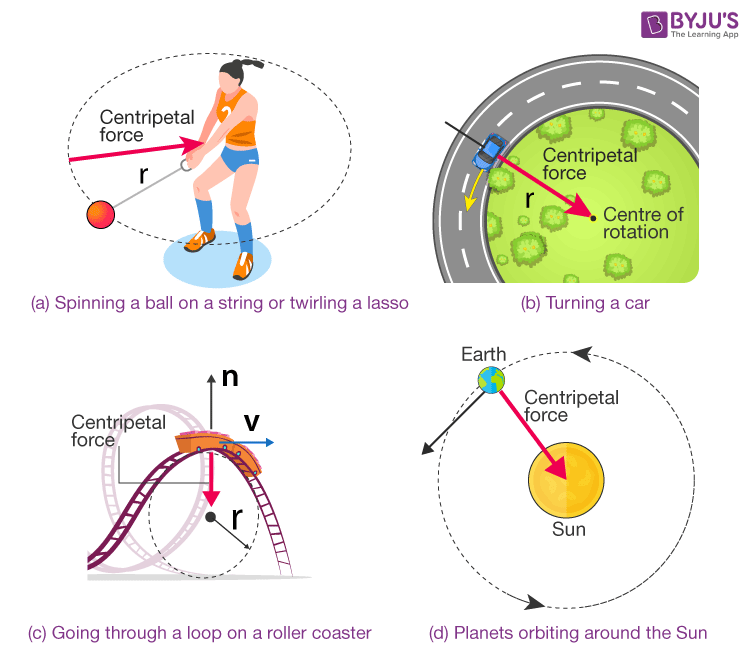
Centrifugal force, conversely, is not an interaction between objects but rather an apparent force that arises in a non-inertial (accelerating) reference frame. Imagine being inside a car making a sharp turn; you feel pushed outwards, away from the center of the turn. This outward “push” is the centrifugal force. From an external, inertial perspective, however, no such outward force exists; your body is simply trying to continue in a straight line due to inertia, while the car provides the inward centripetal force to change your direction. Thus, centrifugal force is best understood as the inertial reaction to centripetal acceleration.
For flight technology, understanding both is crucial. The drone’s flight controller, operating within the drone’s own moving reference frame, must account for these apparent forces to interpret sensor data correctly and execute precise maneuvers. The greater the mass of an object, or the higher its rotational speed or radius of rotation, the greater the magnitude of both the required centripetal force and the perceived centrifugal force. This principle directly impacts everything from a drone’s turning radius to the stress on its rotating components.
Centrifugal Force in Drone Flight Dynamics and Control
The execution of any turn or curved trajectory in drone flight inherently involves centrifugal force. When a drone banks (rolls) to turn, its thrust vector tilts, providing the necessary horizontal component of centripetal force to pull the drone’s center of mass inward. From the drone’s internal perspective, or more accurately, from the perspective of its onboard sensors and flight control algorithms, there is a perceived outward “push”—the centrifugal force—which must be accounted for to maintain stability and control.
During aggressive maneuvers, such as high-speed turns or acrobatic loops, these forces become particularly pronounced. An unmanaged or poorly compensated centrifugal effect can lead to instability, causing the drone to drift, lose altitude unexpectedly, or even tumble. Flight controllers employ sophisticated algorithms, often integrating data from Inertial Measurement Units (IMUs), to continuously calculate the drone’s attitude, velocity, and acceleration. By understanding the forces at play, including the inertial reactions associated with turns, the flight controller can precisely adjust individual motor speeds to counteract unwanted movements and maintain the desired flight path.
For optimal navigation and smooth flight, particularly in autonomous systems, the algorithms must differentiate between true gravitational acceleration, linear accelerations due to thrust, and apparent accelerations arising from rotational motion (centrifugal effects). This allows for accurate estimation of the drone’s state (position, velocity, orientation), crucial for tasks like waypoint navigation, obstacle avoidance, and precise payload delivery. Misinterpreting these forces can lead to “slip” or “skid” during turns, where the drone effectively moves sideways through the air, wasting energy and compromising control. Advanced flight control systems aim to achieve coordinated turns, where the centrifugal effect is perfectly balanced by the centripetal force, resulting in a smooth, efficient maneuver.
Impact on Propulsion Systems and Structural Integrity
Beyond the macroscopic flight dynamics, centrifugal force plays a vital role in the design and operation of a drone’s propulsion system, specifically its motors and propellers. These components rotate at extremely high revolutions per minute (RPMs), generating significant centrifugal forces that exert substantial stress on their structure.
Each individual blade of a propeller experiences an outward centrifugal force pulling it away from the propeller hub. The magnitude of this force is directly proportional to the mass of the blade section, the square of the rotational speed, and the distance from the center of rotation. At typical drone propeller speeds (e.g., 10,000+ RPM), these forces can be immense, potentially causing the blades to stretch, deform, or even fracture if not properly engineered. This necessitates the use of high-strength, lightweight materials like carbon fiber composites, which can withstand these stresses without adding excessive mass that would further amplify the force.
Similarly, within the electric motors themselves, the rotating components (the rotor and its magnets) are subject to centrifugal forces. These forces can stress the motor bearings, the adhesive holding magnets in place, and the integrity of the motor bell. Engineers must carefully design motor housings, select robust bearings, and ensure precise balancing of the rotor to minimize vibrations and uneven stress distribution caused by centrifugal forces. Imbalance, even slight, can lead to excessive vibrations, premature wear, and eventual failure of motor components. Understanding and mitigating these effects are paramount for ensuring the long-term reliability and performance of drone propulsion systems, especially for high-performance and heavy-lift applications where larger propellers and more powerful motors are employed.
Sensors and Navigation: Detecting and Utilizing Rotational Effects
The ability of a drone to fly autonomously and stably hinges on its sophisticated array of sensors, particularly those within the Inertial Measurement Unit (IMU). IMUs typically comprise accelerometers and gyroscopes, both of which are intimately involved in detecting and interpreting the effects of rotational motion, including centrifugal forces.
Accelerometers measure apparent acceleration, which is the sum of all non-gravitational forces acting on the sensor. When a drone executes a turn, an accelerometer inside the drone will detect not only changes in linear speed but also the “feeling” of being pushed outwards—the centrifugal effect. While this isn’t a true acceleration in an inertial frame, it’s a critical piece of information for the flight controller operating within the drone’s own dynamic reference frame. By knowing these apparent accelerations along with the drone’s angular velocity (measured by gyroscopes), the flight controller can distinguish between actual linear acceleration, gravitational pull, and the inertial effects arising from turns.
Gyroscopes, on the other hand, measure angular velocity, providing information about how fast the drone is rotating around its axes (roll, pitch, yaw). This direct measurement of rotation is the cause of the centripetal acceleration and, consequently, the perceived centrifugal force. By fusing the data from accelerometers and gyroscopes, often through advanced filtering techniques like Kalman filters, the flight controller can accurately determine the drone’s true orientation, angular rates, and linear acceleration relative to an inertial frame. This sensor fusion is vital for stable flight, allowing the drone to counteract disturbances, hold position, and follow complex flight paths with precision. Without a nuanced understanding of how centrifugal forces manifest in sensor readings, the drone’s navigation and stabilization systems would be prone to significant errors, leading to unstable and unreliable flight.

Designing for Endurance: Materials and Engineering Considerations
The engineering of drones necessitates a rigorous approach to counteracting and managing centrifugal forces, especially when pushing the boundaries of performance, payload capacity, and flight duration. Material selection is a primary consideration. Propellers, motor shafts, and even structural elements of the airframe must be crafted from materials that offer an optimal balance of strength-to-weight ratio. Advanced composites like carbon fiber reinforced polymers (CFRP) are favored for propellers due to their high tensile strength, stiffness, and light weight, allowing them to withstand the immense centrifugal stress at high RPMs without excessive mass that would exacerbate the force. Similarly, aerospace-grade aluminum alloys are often used for motor housings and structural joints where rigidity and strength are paramount.
Dynamic balancing is another critical engineering practice. Any slight imbalance in the mass distribution of a rotating component—be it a propeller or a motor rotor—will lead to uneven centrifugal forces, generating vibrations that can propagate throughout the drone. These vibrations not only cause discomfort in piloted flight but can also introduce noise into sensor readings, degrade flight controller performance, and lead to fatigue and premature failure of components. Precision manufacturing and post-production balancing techniques are employed to ensure rotating parts are as perfectly balanced as possible, minimizing these detrimental effects.
Furthermore, bearing design in motors is crucial. Bearings must be capable of handling not only the axial loads (thrust) but also the radial loads imposed by centrifugal forces acting on the rotor. High-quality, low-friction bearings made from durable materials are essential for ensuring motor longevity and efficiency. Finally, sophisticated structural analysis techniques, such as Finite Element Analysis (FEA), are routinely used by drone designers. These computational methods allow engineers to simulate the stresses and strains on various components under expected operational loads, including those generated by centrifugal forces, enabling them to optimize designs for maximum endurance and reliability before physical prototypes are even built. This meticulous attention to engineering detail ensures that drones can safely and effectively operate within the demanding environment of rotational flight.