
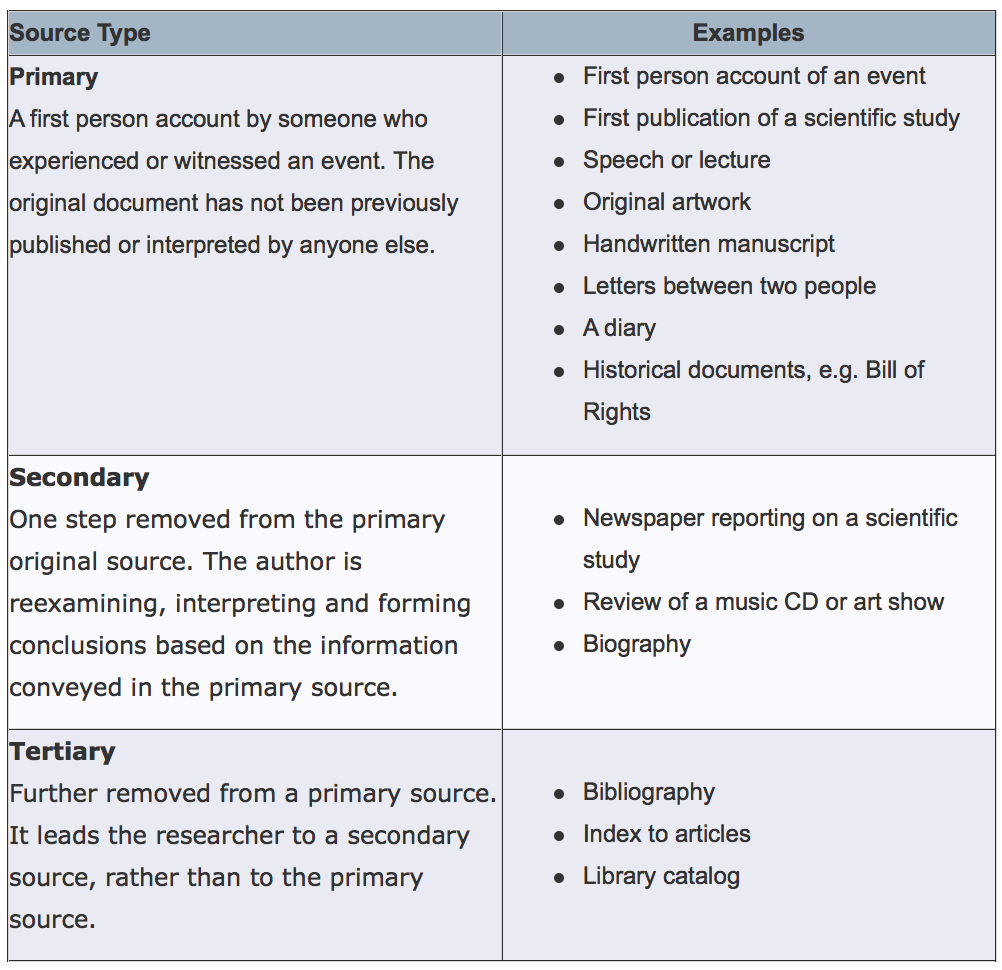
In the rapidly evolving landscape of drone technology and innovation, identifying and utilizing primary sources is crucial for research, development, validation, and understanding the foundational aspects of new systems. Unlike secondary sources, which interpret or analyze existing information, primary sources offer direct, unadulterated evidence from the origin of an event, development, or discovery. Within the realm of AI follow mode, autonomous flight, mapping, and remote sensing, these sources are indispensable for anyone seeking to push the boundaries of what drones can achieve. They provide the bedrock upon which new algorithms are built, systems are tested, and groundbreaking applications are realized.

Raw Sensor Data: The Unfiltered Lens of Innovation
The most immediate and fundamental primary sources in drone tech and innovation are the raw data streams generated by on-board sensors. These data sets provide a direct snapshot of the drone’s environment and its own state, forming the empirical basis for nearly all advanced applications.
Geospatial Data for Mapping and Remote Sensing
For applications like high-resolution mapping, 3D modeling, and environmental monitoring, raw geospatial data is paramount.
- RGB and Multispectral Imagery: Unprocessed image files (e.g., TIFF, JPEG2000) captured directly from the camera sensor, containing pixel-level brightness values across visible and invisible light spectra. This includes raw camera calibration data, lens distortion parameters, and timestamped metadata (GPS, IMU readings) that are essential for accurate photogrammetry and remote sensing analysis. The original, unstitched, and uncorrected imagery provides the most direct evidence of ground conditions and vegetation health before any radiometric or geometric corrections are applied.
- LiDAR Point Clouds: Unfiltered point cloud data (.LAS, .LAZ files) directly output from LiDAR scanners, representing millions of individual laser returns with X, Y, Z coordinates and intensity values. These raw points capture the precise 3D structure of the environment, including ground features, vegetation, and buildings, before classification, noise reduction, or surface generation algorithms are applied. Associated trajectory data from the drone’s IMU and GPS are also critical primary inputs.
- Thermal Imagery: Raw radiometric thermal images, often in formats that preserve temperature values per pixel rather than just visual representation. These provide direct measurements of surface temperatures, vital for applications like solar panel inspection, wildlife detection, and building diagnostics, uninfluenced by post-processing temperature mapping or colorization.
Kinematic and Navigational Data for Autonomous Systems
The precise movement and orientation of a drone are governed by a wealth of kinematic data, which serves as a primary source for developing and refining autonomous capabilities.
- Inertial Measurement Unit (IMU) Data: Raw accelerometer, gyroscope, and magnetometer readings that provide high-frequency information about the drone’s angular velocity, linear acceleration, and magnetic field orientation. This raw data is fundamental for sensor fusion algorithms that determine the drone’s attitude, heading, and position.
- Global Positioning System (GPS) Data: Unprocessed GPS observables, including carrier phase measurements and pseudorange data. For Real-Time Kinematic (RTK) or Post-Processed Kinematic (PPK) systems, these raw measurements from both the drone and a base station are primary inputs for achieving centimeter-level positioning accuracy, critical for autonomous navigation and precision mapping.
- Sonar and Radar Data: Raw ranging data from sonar or radar sensors, providing direct measurements of distance to obstacles. This unfiltered data is crucial for developing and testing obstacle avoidance algorithms, offering a primary representation of the surrounding environment’s geometry.
- Flight Logs: Detailed logs generated by the drone’s flight controller, recording every aspect of its operation: motor speeds, battery voltage, control inputs, sensor readings, GPS coordinates, and error messages. These logs are invaluable for debugging, performance analysis, and incident reconstruction, offering a complete, chronological record of a flight.
Algorithmic and Software Design Documentation
Beyond sensor outputs, the intellectual scaffolding of drone innovation—the algorithms and software that enable intelligence and autonomy—also constitutes a rich vein of primary sources.
Research Papers and Technical Specifications

The initial conceptualization and scientific validation of new drone technologies are often documented in scholarly publications.
- Peer-Reviewed Research Papers: Original articles published in scientific journals or conference proceedings detailing novel algorithms for AI follow mode, autonomous navigation, simultaneous localization and mapping (SLAM), object detection, or remote sensing data processing. These papers present the methods, experimental setups, raw results, and analyses directly from the researchers.
- Patents and Patent Applications: Legal documents describing new inventions in drone technology, including detailed architectural diagrams, algorithmic descriptions, and claims that define the scope of the innovation. These provide definitive proof of original ideas and their unique implementation.
- System Design Documents (SDD) and Software Requirements Specifications (SRS): Internal company documents that detail the architecture, modules, interfaces, and functional requirements of a new drone system or software component (e.g., an autonomous flight stack, an AI vision system). These are blueprints for development, outlining the initial design intent.
Source Code and Development Artifacts
The actual implementation of innovative ideas resides in the code and the processes used to create it.
- Source Code Repositories: The original programming code (e.g., Python, C++, Rust) for flight control firmware, AI models (e.g., TensorFlow, PyTorch implementations), image processing pipelines, and ground control station software. Access to the raw code allows for deep understanding of how algorithms are implemented and how systems function at a granular level.
- Simulation Data and Models: Output files from simulations (e.g., Gazebo, AirSim) that test autonomous behaviors, navigation algorithms, or sensor performance in virtual environments. This includes simulated sensor data, vehicle states, and environmental parameters, which are primary sources for validating concepts before real-world deployment.
- Training Datasets: The original, curated datasets used to train machine learning models for AI follow mode, object recognition, or semantic segmentation. These might include thousands of labeled images or videos, representing the direct input that shaped the AI’s intelligence.
Field Testing and Operational Logs
The real-world application and validation of drone technologies generate another critical category of primary sources, offering insights into performance under actual conditions.
Test Reports and Calibration Data
Every stage of development and deployment involves rigorous testing, generating a wealth of direct evidence.
- Flight Test Reports: Documents detailing the objectives, procedures, environmental conditions, observations, and raw results of actual test flights. These reports provide direct evidence of how a drone system or a new feature performed in the field, including any failures or unexpected behaviors.
- Calibration Logs: Records of sensor calibration procedures, including parameters derived from calibration routines (e.g., camera intrinsic and extrinsic parameters, IMU biases, magnetometer calibration coefficients). These logs ensure data accuracy and provide insight into sensor performance characteristics.
- Bug Reports and Issue Tracking Systems: Direct records of software defects, hardware malfunctions, or unexpected system behaviors identified during development and testing. These provide primary evidence of system vulnerabilities and areas requiring improvement.
User Feedback and Human-in-the-Loop Data
For human-centric innovations or those involving complex interaction, the direct input from users or operators is invaluable.
- Pilot Logs and Operator Notes: Handwritten or digital notes from drone pilots and operators during flights, detailing observations, challenges encountered, unusual events, or qualitative assessments of system performance (e.g., “AI follow mode was smooth in open areas but struggled with dense foliage”).
- Raw User Interface (UI) Interaction Data: Logs of how users interact with ground control station software or remote controllers, including button presses, joystick movements, and parameter changes. This provides direct insight into usability and operational workflows.
The Evolving Nature of Primary Sources in Advanced Drone Tech
As drone technology continues to advance, the nature of primary sources also evolves. Edge computing on drones will generate new forms of on-board processed data that, while processed, can still be considered primary if it’s the first instance of computation on raw sensor input. The rise of quantum sensing and advanced AI models will introduce even more complex data types, from quantum states to highly abstract neural network activations. Understanding and carefully documenting these original artifacts will remain paramount for continuous innovation, ensuring transparency, reproducibility, and robust development in the ever-expanding universe of drone applications.