
Love bugs (Plecia nearctica) are a fascinating yet often frustrating natural phenomenon, known for their synchronized emergence and swarming behavior. While seemingly a topic rooted in entomology, their actions and characteristics hold significant implications and opportunities within the realm of drone technology and innovation. From posing unique challenges to autonomous flight systems to offering bio-inspirations for novel drone designs and providing subjects for advanced remote sensing applications, understanding “what love bugs do” through a technological lens unveils critical considerations for the future of unmanned aerial systems (UAS).

Understanding Swarm Dynamics Through Remote Sensing
The synchronized emergence and dense swarming of love bugs present a compelling case study for the application of advanced remote sensing and mapping technologies. Their predictable aggregations, particularly during mating seasons, create quantifiable phenomena that drones equipped with specialized sensors can effectively monitor and analyze.
Population Monitoring and Distribution Mapping
One of the primary applications of drone technology concerning love bugs is the precise monitoring of their populations and geographical distribution. Traditional ground-based methods can be labor-intensive, geographically limited, and susceptible to observer bias. Drones, on the other hand, offer an aerial perspective that is both expansive and highly detailed. Equipped with high-resolution optical cameras and multispectral sensors, UAVs can capture data that allows researchers to:
- Estimate Population Density: By analyzing imagery, algorithms can identify and count individual love bugs or estimate swarm densities within specific areas. This provides crucial data for understanding population dynamics and seasonal fluctuations.
- Map Distribution Patterns: Drones can survey large land parcels rapidly, generating detailed maps that illustrate where love bug swarms are most concentrated. This spatial data is invaluable for agricultural planning, urban pest management, and ecological studies tracking their migratory paths and habitat preferences.
- Track Environmental Factors: Beyond just the insects themselves, drone-mounted sensors can simultaneously collect data on environmental parameters such as vegetation health, temperature gradients, and moisture levels, which are known to influence love bug behavior. Correlating this environmental data with insect distribution allows for a more holistic understanding of the factors driving their swarms. This integration of diverse data streams enhances predictive modeling capabilities, offering insights into where and when love bug events are likely to occur, allowing for proactive measures or public advisories.
Behavioral Analysis via Drone-Mounted Sensors
Beyond mere population counts, the unique behaviors of love bugs—especially their characteristic tandem flight during mating and their attraction to certain environments—can be meticulously studied using advanced drone payloads.
- Flight Path Tracking: Utilizing vision-based tracking algorithms, drones can record and analyze the flight paths of individual love bugs or small groups within a swarm. This can provide insights into their aerodynamics, navigation strategies, and interactions within the collective. Such data can inform bio-inspired designs for micro-drones or improve the efficiency of swarm robotics.
- Thermal Imaging for Activity Patterns: Love bugs are ectothermic, meaning their activity is influenced by ambient temperature. Thermal cameras on drones can detect temperature variations within swarms and their surrounding environment, potentially correlating these changes with activity levels, mating behaviors, or aggregation patterns. This allows for non-invasive monitoring of their physiological responses to environmental shifts.
- Chemical Sensor Integration: While more nascent, the integration of miniature chemical sensors on drones could potentially detect the volatile organic compounds (VOCs) that love bugs release or are attracted to. For instance, their known attraction to vehicle exhaust fumes containing specific chemicals could be studied at scale, providing data on how these airborne cues influence swarm formation and movement, thereby informing strategies for drone-based environmental monitoring of air quality or targeted pest control.
The Challenge of Bio-Interference for Autonomous Flight
While drones can be tools for studying love bugs, the insects themselves pose significant operational challenges for unmanned aerial vehicles, particularly for autonomous systems. The sheer density of love bug swarms can transform routine drone operations into complex navigation and maintenance dilemmas.
Sensor Obstruction and Contamination
One of the most immediate threats love bugs pose to drones is the obstruction and contamination of critical sensors. Swarming insects can collide with and adhere to various surfaces of a drone, including:
- Optical Sensors (Cameras): Lenses of visual and infrared cameras can become rapidly coated with love bugs, obscuring the field of view. For drones relying on computer vision for navigation, obstacle avoidance, or data collection, this can lead to system malfunction, corrupted data, or even complete loss of situational awareness.
- Lidar and Radar Sensors: While perhaps less prone to complete obstruction, the residue from love bugs can degrade the performance of Lidar (Light Detection and Ranging) and radar systems by scattering or absorbing emitted signals, reducing range and accuracy. This impacts collision avoidance algorithms and precise mapping capabilities.
- Pitot Tubes and Airflow Sensors: Essential for flight control and airspeed measurement, pitot tubes can become clogged, leading to erroneous airspeed readings and potentially unstable flight characteristics. This is a critical safety concern for larger, more complex drones that rely heavily on accurate aerodynamic data.
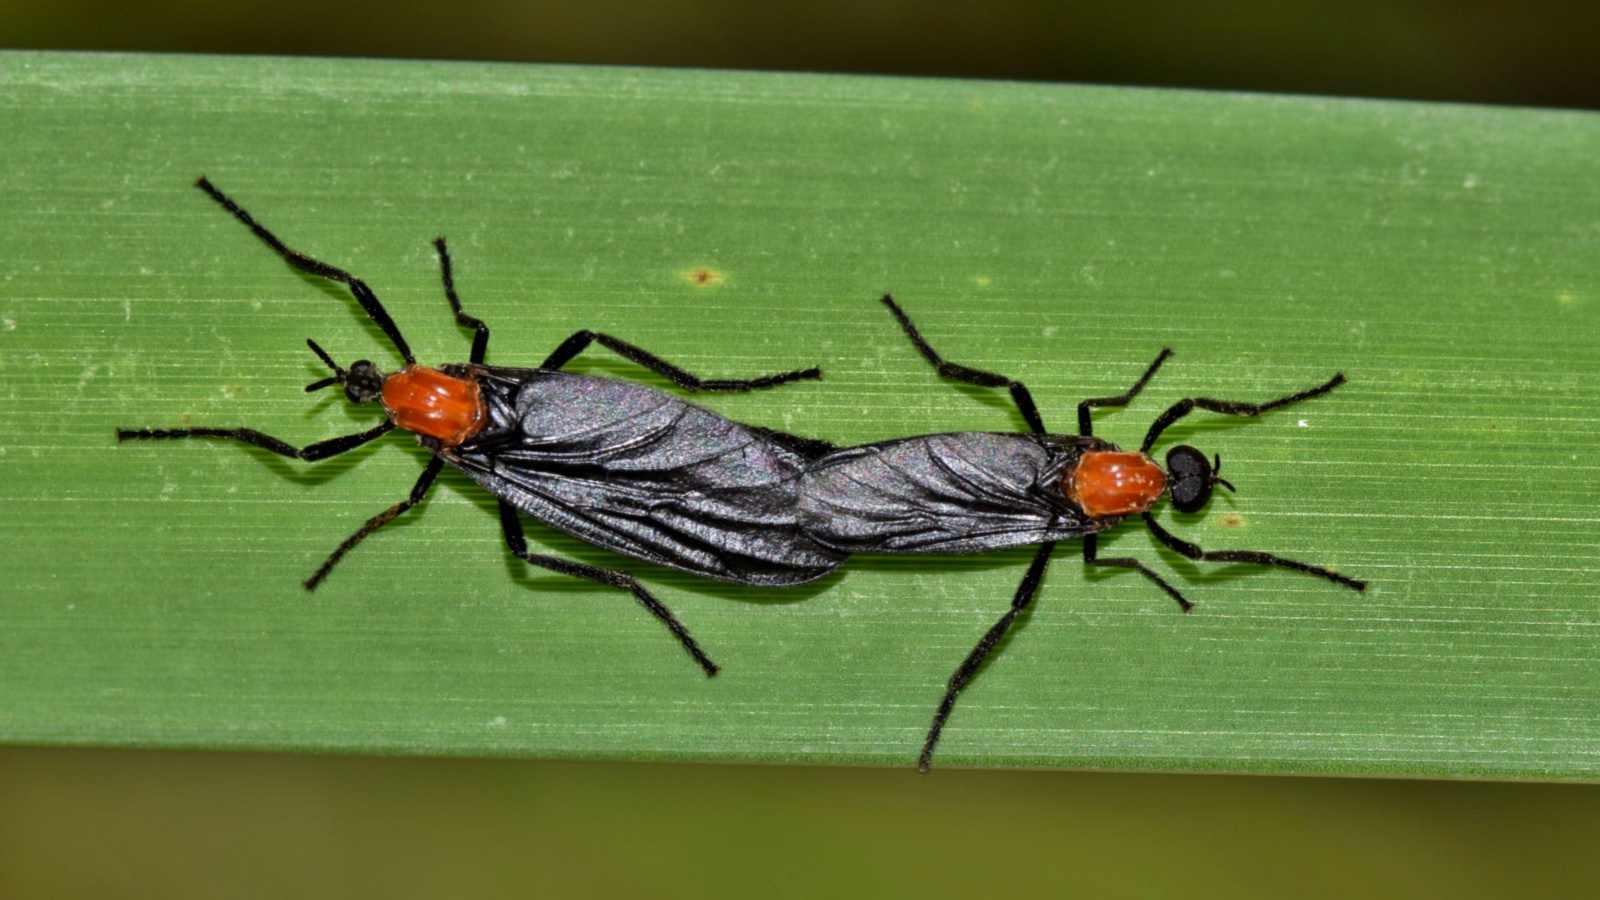
The sticky nature of love bug remnants, particularly their bodily fluids, can also cause long-term damage or require specialized cleaning processes, increasing maintenance overhead and reducing drone operational readiness.
Propeller Integrity and Aerodynamic Impact
Beyond sensors, the physical interaction of love bugs with a drone’s propulsion system can have detrimental effects:
- Propeller Fouling: Love bugs can become lodged in propeller blades or between the blades and the motor housing. This imbalance can lead to increased vibration, reduced thrust efficiency, and premature wear on motors and bearings. In severe cases, it can cause propeller damage or failure, leading to a drone crash.
- Aerodynamic Drag: Dense swarms, while individual love bugs are small, collectively present a significant increase in aerodynamic drag. A drone flying through a thick swarm requires more power to maintain altitude and speed, reducing battery life and operational range. This increased power demand also puts additional stress on the motors and ESCs (Electronic Speed Controllers), potentially leading to overheating or failure.
- Motor Overload: The continuous collision with insects and the increased power draw to overcome drag can lead to motors working beyond their optimal operating parameters, shortening their lifespan and increasing the risk of in-flight failure.
Mitigating Biological Threats to UAVs
Addressing these bio-interference challenges requires innovative solutions within drone design and operational protocols:
- Protective Coatings and Sensor Covers: Developing hydrophobic or oleophobic coatings for camera lenses and sensor housings can minimize adhesion. Retractable or self-cleaning covers for critical sensors could also be implemented.
- Aerodynamic Design and Propeller Materials: Redesigning drone frames and propeller geometries to be less susceptible to insect accumulation, or using materials that resist fouling and damage, can enhance resilience.
- Autonomous Swarm Detection and Avoidance: Advanced AI-driven vision systems capable of detecting dense insect swarms in real-time could enable drones to autonomously alter their flight paths to circumvent areas of high love bug concentration, prioritizing mission safety and equipment integrity.
- Robustness in Flight Control: Developing flight control algorithms that are more tolerant to temporary sensor degradation or fluctuating aerodynamic conditions can help maintain stable flight even when a drone encounters a swarm.
Bio-Inspiration: Learning from Nature’s Swarm Intelligence
While love bugs pose challenges, their very existence and behaviors, particularly their mass aggregation and coordinated flight, can serve as a profound source of bio-inspiration for drone technology and swarm robotics.
Collective Behavior and Distributed Systems
The seemingly chaotic yet ultimately synchronized flight of love bug swarms embodies principles of distributed intelligence. Individual insects, reacting to local cues (pheromones, visual stimuli, environmental factors), collectively generate complex large-scale behaviors without a central commander.
- Decentralized Decision-Making: This natural model inspires research into decentralized control algorithms for drone swarms, where individual UAVs make decisions based on local sensor data and communication with immediate neighbors, leading to emergent global behaviors like formation flight, synchronized movements, or optimized search patterns. This approach enhances resilience, as the failure of one unit does not cripple the entire system.
- Resource Optimization: Understanding how love bugs efficiently locate mates or suitable habitats within a large area through collective exploration can inform strategies for multi-drone systems engaged in wide-area mapping, search and rescue, or environmental monitoring, minimizing energy expenditure and maximizing coverage.

From Insect Flight to Micro-Drone Agility
The small size and agile flight of insects like love bugs continue to inspire advancements in micro-drone technology. Their ability to navigate complex environments, withstand adverse conditions, and achieve remarkable maneuverability in confined spaces offers blueprints for future UAV development.
- Aerodynamic Efficiency: Analyzing the wing kinematics and body-wing interactions of love bugs during flight can yield insights into highly efficient micro-aerodynamics, leading to more energy-efficient and quieter micro-drones.
- Resilience and Robustness: The inherent resilience of biological systems, where minor damage doesn’t necessarily lead to catastrophic failure, can inspire modular and fault-tolerant designs for drones, particularly those intended for operation in challenging or unpredictable environments.
- Perception and Navigation in Cluttered Environments: Insects excel at navigating dense foliage or crowded airspace. Studying their sensory systems and neural processing can inform the development of more sophisticated perception algorithms and navigation strategies for micro-drones operating in complex, GPS-denied environments.
By delving into “what love bugs do,” from their macroscopic swarm dynamics to their microscopic flight mechanics, drone technology can find both formidable challenges to overcome and profound inspirations to emulate, pushing the boundaries of autonomous flight and robotic intelligence.