
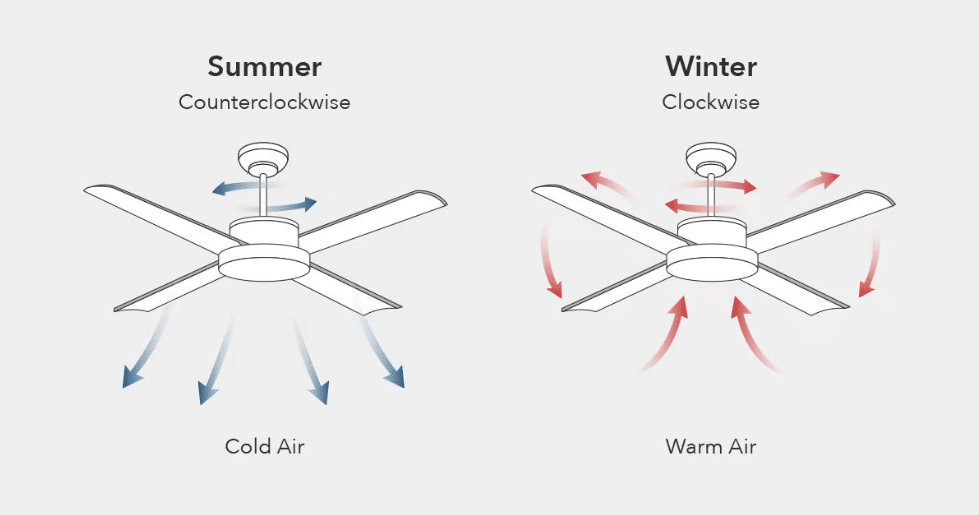
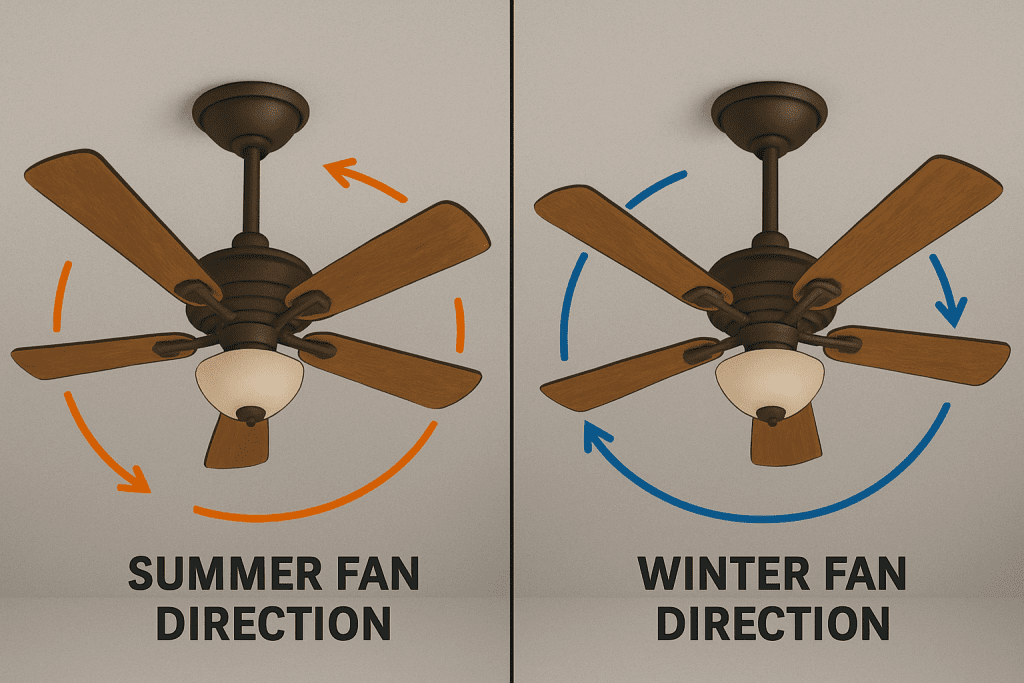
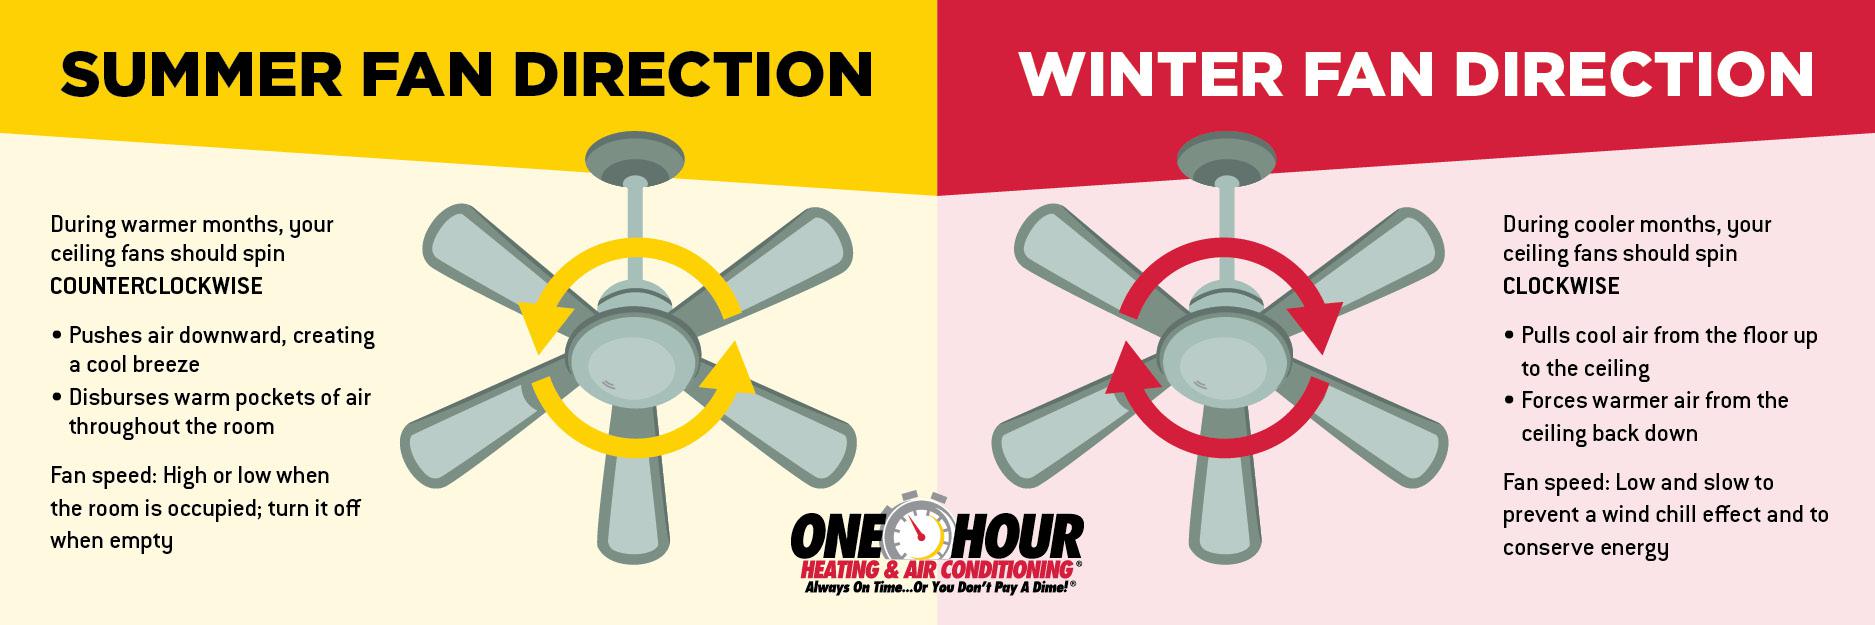
The seemingly simple question, “what direction for a ceiling fan,” opens a surprisingly intricate discussion when transposed into the realm of advanced drone flight technology. Far from merely optimizing room comfort, understanding the directional forces, aerodynamic disturbances, and dynamic physical challenges presented by rapidly rotating objects, such as a domestic ceiling fan, provides crucial insights into the sophisticated flight technology required for safe, efficient, and truly autonomous UAV operation in complex indoor environments. This article delves into how cutting-edge flight technology addresses the unique navigational and stabilization demands posed by such ubiquitous, yet challenging, obstacles.
Navigating the Complexities of Indoor Aerodynamics and Dynamic Obstacles
Indoor drone flight inherently presents a different set of challenges compared to open-air operations. GPS signals are often unavailable or unreliable, lighting can be inconsistent, and the environment is typically cluttered with static and dynamic obstacles. Among these, a running ceiling fan represents a particularly potent combination of challenges for a drone’s flight technology.
The Ceiling Fan as a Micro-Turbulence Generator
An operating ceiling fan isn’t just a physical barrier; it’s a dynamic system generating localized airflow disturbances. The rotating blades create intricate vortices and areas of varying pressure, transforming the air around it into a micro-turbulent zone. For a lightweight drone, even subtle changes in air pressure and velocity can significantly impact its stability and require continuous, precise adjustments to maintain a desired flight path and orientation. A drone flying too close could be buffeted, losing altitude or veering off course, potentially leading to a collision. The ‘direction’ a drone needs to take must account not just for the fan’s physical presence, but also for the invisible, disruptive currents it produces. This necessitates advanced aerodynamic models and adaptive control systems that can interpret and react to these transient forces in real-time.
Dynamic Obstacle Perception and Prediction
Detecting and avoiding static obstacles, while challenging, is a more straightforward task for a drone’s sensors and algorithms. A ceiling fan, however, is a rapidly moving, rotating obstacle. Its blades are often thin, potentially reflective, and can move at high speeds, blurring into a perceptual challenge for many sensor types. The ‘direction’ of the fan’s rotation, the speed of its blades, and its exact position in three-dimensional space must be accurately and continuously perceived. This demands high refresh rates from vision systems and often requires predictive algorithms that can anticipate the blade’s future position to ensure the drone’s chosen flight direction avoids interception. The drone must not only register the fan’s existence but also understand its temporal behavior to plan a safe trajectory through or around the affected airspace.
Precision Sensing and Environmental Mapping in Confined Spaces
To effectively navigate around a ceiling fan or other complex indoor obstacles, drones rely on a sophisticated array of sensors and algorithms for environmental perception and mapping. The goal is to build a real-time, high-fidelity 3D representation of the operational space.
Multi-Sensor Fusion for 3D Environment Reconstruction
Modern drones integrate data from various sensor modalities to achieve robust environmental understanding. Vision-based systems, including stereo cameras and monocular visual Simultaneous Localization and Mapping (SLAM), provide rich textural and depth information, crucial for identifying objects and their relative positions. LiDAR (Light Detection and Ranging) sensors emit pulsed laser light to measure distances, generating precise point clouds that define the geometry of the environment, even in low light. Ultrasonic sensors offer short-range distance measurements, acting as a reliable last-resort collision avoidance system. The true power lies in sensor fusion, where data from these disparate sources are combined and correlated. For an object like a ceiling fan, vision systems can identify its form and track its rotation, while LiDAR provides precise spatial boundaries, and ultrasonic sensors ensure proximity warnings. This holistic approach ensures that the drone has the most comprehensive understanding of the fan’s precise location, size, and its ‘direction’ of movement within the mapped space.
Overcoming Sensor Limitations and Perceptual Challenges
Operating near a ceiling fan highlights specific sensor limitations. Vision systems can struggle with rapidly moving fan blades that appear as motion blur, or with reflective surfaces that cause glare. LiDAR can be less effective on transparent or highly absorbent materials, and its point cloud density might not capture the thinness of a blade. Therefore, robust algorithms are critical. These include filtering techniques to remove noise, object recognition models trained on diverse datasets (including moving parts), and temporal integration methods that build a consistent understanding of dynamic elements over time. The ‘direction’ of a drone’s sensor suite itself, including optimal placement and field of view, is also engineered to maximize coverage and minimize blind spots, especially when operating in close proximity to complex, moving obstacles.
Intelligent Path Planning and Real-time Collision Avoidance
Once the environment is accurately perceived, the drone’s flight technology must determine the safest and most efficient ‘direction’ to take. This involves sophisticated path planning and real-time collision avoidance strategies.
Predictive Trajectory Generation
Autonomous drones employ algorithms that don’t just react to the present, but predict the future. When encountering a dynamic obstacle like a ceiling fan, these algorithms calculate a safe flight trajectory by considering several factors: the drone’s current position and velocity (kinematics), the detected position and velocity of the fan’s blades, and crucially, their predicted future path. This involves modeling the fan’s rotation and using this model to anticipate where its blades will be at any given moment. The drone then computes a safe evasion maneuver, ensuring its own trajectory does not intersect with the predicted trajectory of any fan blade. This involves calculating precise turn angles, speed adjustments, and altitude changes—determining the optimal ‘direction’ for evasion.
Reactive vs. Proactive Avoidance
Collision avoidance systems can broadly be categorized as reactive or proactive. Reactive systems perform immediate evasive maneuvers upon detecting an imminent collision, often leveraging ultrasonic or short-range vision sensors. While essential for unexpected encounters, they can be abrupt and less energy-efficient. Proactive systems, which are vital for navigating complex environments with known dynamic obstacles, continuously monitor the environment and integrate predictive models. They plan smoother, more efficient evasive actions well in advance, based on a comprehensive understanding of the scene. For a ceiling fan, a proactive system might choose a wider, more stable ‘direction’ of approach, or plan a temporary hover outside the fan’s operational radius until a clear path is available, minimizing energy expenditure and maintaining mission continuity. This blend of foresight and immediate response defines advanced drone autonomy.
Advanced Flight Control and Stabilization in Turbulent Environments
Beyond perception and planning, the drone’s physical ability to maintain its intended ‘direction’ and stability in the face of challenging conditions is paramount. This is where advanced flight control systems come into play.
Adaptive Control Systems for Counteracting Turbulent Airflows
The localized turbulence generated by a ceiling fan can significantly destabilize a drone. Traditional fixed-gain control systems, while effective in calm air, may struggle to cope with these dynamic disturbances. Advanced flight controllers employ adaptive control algorithms that can dynamically adjust the drone’s motor speeds and propeller thrust vectors in real-time. These systems continuously monitor the drone’s attitude (roll, pitch, yaw) and compare it to the desired state. If a sudden gust from a fan blade pushes the drone, the adaptive controller instantly calculates and applies counter-thrust to maintain stability and the intended ‘direction’, effectively riding out the turbulence. This requires high-frequency sensor readings (IMUs – Inertial Measurement Units) and rapid processing capabilities.
Robust Estimators for State Prediction and Positional Accuracy
To enable adaptive control, drones rely on robust state estimators, such as Kalman filters or Extended Kalman Filters (EKFs). These algorithms fuse data from various sensors (accelerometers, gyroscopes, magnetometers, barometers, vision sensors) to provide the most accurate possible estimate of the drone’s current position, velocity, and orientation. This accurate state estimation is crucial for precise directional control. In the presence of turbulent airflow from a ceiling fan, these estimators help to distinguish between sensor noise, intended motion, and external disturbances. By accurately knowing its own state, the drone can apply corrective forces with precision, ensuring that its intended ‘direction’ is maintained despite external influences, enabling it to successfully navigate past or through challenging airspaces.
The Future of Autonomous Indoor Flight and Persistent Sensing
The progression in flight technology continues to push the boundaries of what drones can achieve in complex, obstacle-rich environments like those containing ceiling fans. The ‘direction’ of innovation points towards even greater autonomy and versatility.
Swarm Robotics and Collaborative Mapping
Future advancements envision swarms of drones collaborating to map and navigate intricate indoor spaces. Instead of a single drone tackling a vast, cluttered environment, multiple smaller drones could share sensor data, collectively building a more complete and resilient 3D map. This collaborative approach would allow for more efficient detection and avoidance of obstacles like multiple ceiling fans, with individual drones specializing in specific tasks or areas, or providing redundant data for enhanced robustness. If one drone’s sensors are momentarily obscured, others in the swarm can compensate, ensuring continuous environmental understanding and collective ‘directional’ awareness.
Enhanced Perception and AI-Driven Decision Making
The integration of advanced artificial intelligence, particularly deep learning, promises to revolutionize indoor drone navigation. AI-driven perception systems will not only identify objects but also understand their function and potential impact on drone flight. For instance, an AI might learn that a ceiling fan is a rotating air-disturbance generator and automatically adjust flight parameters even before entering its direct vicinity. AI can also enhance predictive capabilities, anticipating not just the mechanical motion of an object, but also subtle cues in the environment to make instantaneous, intelligent ‘directional’ decisions, moving beyond simple avoidance to more nuanced interaction.
Beyond Simple Avoidance: Interaction and Inspection
Ultimately, flight technology aims to move beyond merely avoiding obstacles like ceiling fans towards enabling drones to interact with or even inspect them. Imagine a drone autonomously navigating a factory, inspecting the precise ‘direction’ and speed of industrial fans for maintenance, or assessing blade integrity. This requires an even higher degree of precision in navigation, stability, and fine-grained control, coupled with specialized sensor payloads. Such capabilities underscore the ongoing evolution of flight technology, continuously refining the understanding of ‘what direction’ a drone should take to operate safely, efficiently, and intelligently in any given environment.