
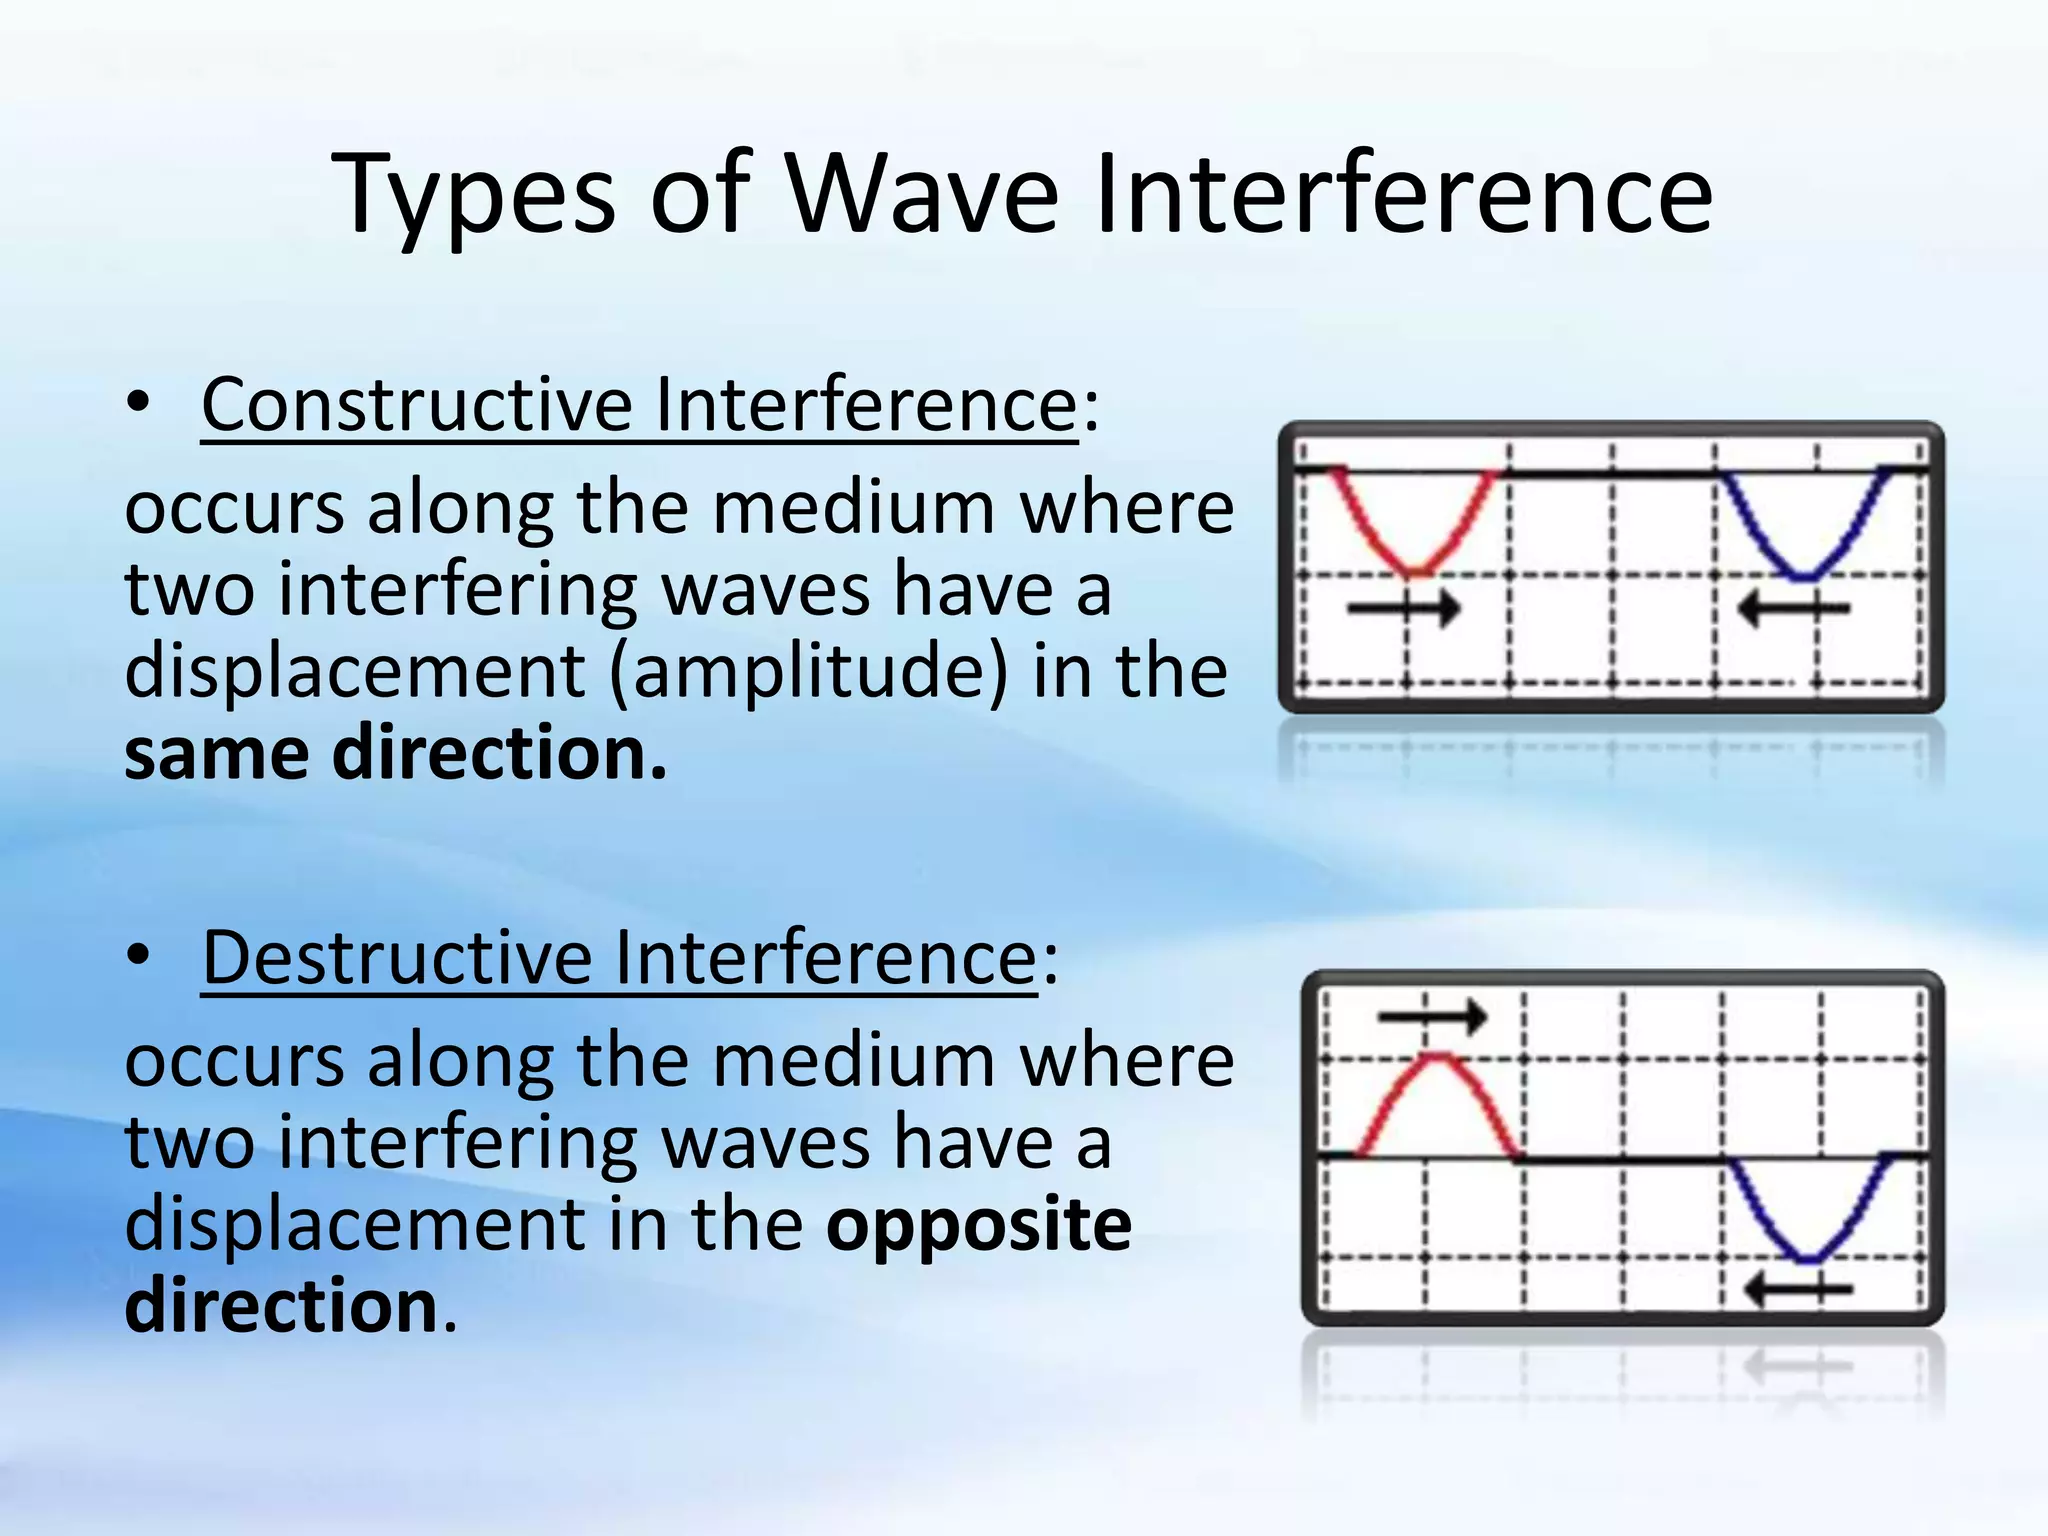
The sophisticated world of drone flight technology relies heavily on seamless communication, precise navigation, and accurate sensor data. Any disruption to these fundamental pillars can compromise mission success, lead to loss of valuable equipment, or even pose significant safety risks. Understanding the various forms of interference that can affect unmanned aerial vehicles (UAVs) is paramount for operators, developers, and regulatory bodies alike. While many types of interference exist, two broad categories stand out due to their pervasive impact on a drone’s core flight systems: Radio Frequency (RF) Interference and Global Navigation Satellite System (GNSS) Interference. These two forms directly challenge the stability, navigability, and control of modern drones, necessitating robust technological countermeasures and informed operational practices.
Understanding the Impact of Interference on Drone Flight Technology
Interference, in the context of drone flight, refers to any external signal or environmental factor that disrupts the normal operation of a drone’s electronic systems. For systems designed to operate with millisecond precision and depend on clear, unobstructed data streams, even minor interference can have significant repercussions. These disruptions can manifest in various ways, from subtle navigational inaccuracies to complete loss of control, underscoring the critical need for advanced flight technology that is resilient to such challenges. The ongoing evolution of drone capabilities, including autonomous flight and beyond visual line of sight (BVLOS) operations, further amplifies the importance of mitigating interference effectively, as these applications demand even higher levels of reliability and signal integrity.
Radio Frequency (RF) Interference: The Silent Threat to Control and Communication
Radio Frequency (RF) interference is perhaps the most commonly encountered and significant threat to a drone’s operational integrity. Modern drones communicate with their ground control stations (GCS) and transmit vital telemetry and video feeds using various radio frequency bands. When these signals are disrupted by other RF emissions, the drone’s ability to receive commands or relay information back to the operator can be severely compromised.
Control Link Disruption
The control link is the lifeline between the drone pilot and the aircraft. It’s the pathway through which commands for ascent, descent, yaw, pitch, roll, and other maneuvers are transmitted. RF interference can manifest as a weakening, distortion, or complete blocking of these critical command signals. Sources of such interference are ubiquitous in modern environments, ranging from Wi-Fi networks operating on similar frequencies (e.g., 2.4 GHz, 5.8 GHz) to industrial equipment, cellular towers, other active drones in the vicinity, or even natural phenomena like solar flares or strong atmospheric events.
When the control link experiences significant interference, several critical consequences can ensue. The most immediate and dangerous is a loss of control, where the drone may become unresponsive to pilot inputs. Many sophisticated flight control systems incorporate “failsafe” mechanisms designed to activate in such scenarios. These might include an automatic return-to-home (RTH) function, initiating a controlled landing at the current location, or simply hovering in place until the signal is re-established. However, if interference persists or is severe, even failsafe procedures can be compromised, leading to uncontrolled descent, collisions, or what is commonly known as a “flyaway,” where the drone drifts or flies off uncontrollably. This underscores the need for flight controllers to employ robust RF communication protocols, such as frequency hopping spread spectrum (FHSS) or direct sequence spread spectrum (DSSS), which are inherently more resistant to narrow-band interference.
Data Link Compromise
Beyond basic control, drones also rely on RF links to transmit a wealth of data, including real-time video feeds (critical for FPV piloting and aerial observation), telemetry data (altitude, speed, battery status, GPS coordinates), and payload-specific information. RF interference can significantly degrade these data links, leading to a host of operational issues.
For First Person View (FPV) drones or those used for inspection and surveillance, interference in the video link can cause lag, pixelation, or a complete loss of visual feed. This makes precise maneuvering or detailed observation virtually impossible and can lead to disorientation for the pilot. Similarly, interference affecting telemetry data transmission can result in the pilot receiving outdated or incorrect information about the drone’s status, making informed decision-making challenging. For instance, an inaccurate battery readout due to interference could lead to the drone running out of power unexpectedly mid-flight. Advanced flight technology often integrates multiple antennas and digital data transmission techniques with error correction codes to enhance resilience against data link compromise, but the threat remains persistent, especially in electromagnetically dense environments.
Global Navigation Satellite System (GNSS) Interference: Undermining Precision and Autonomy
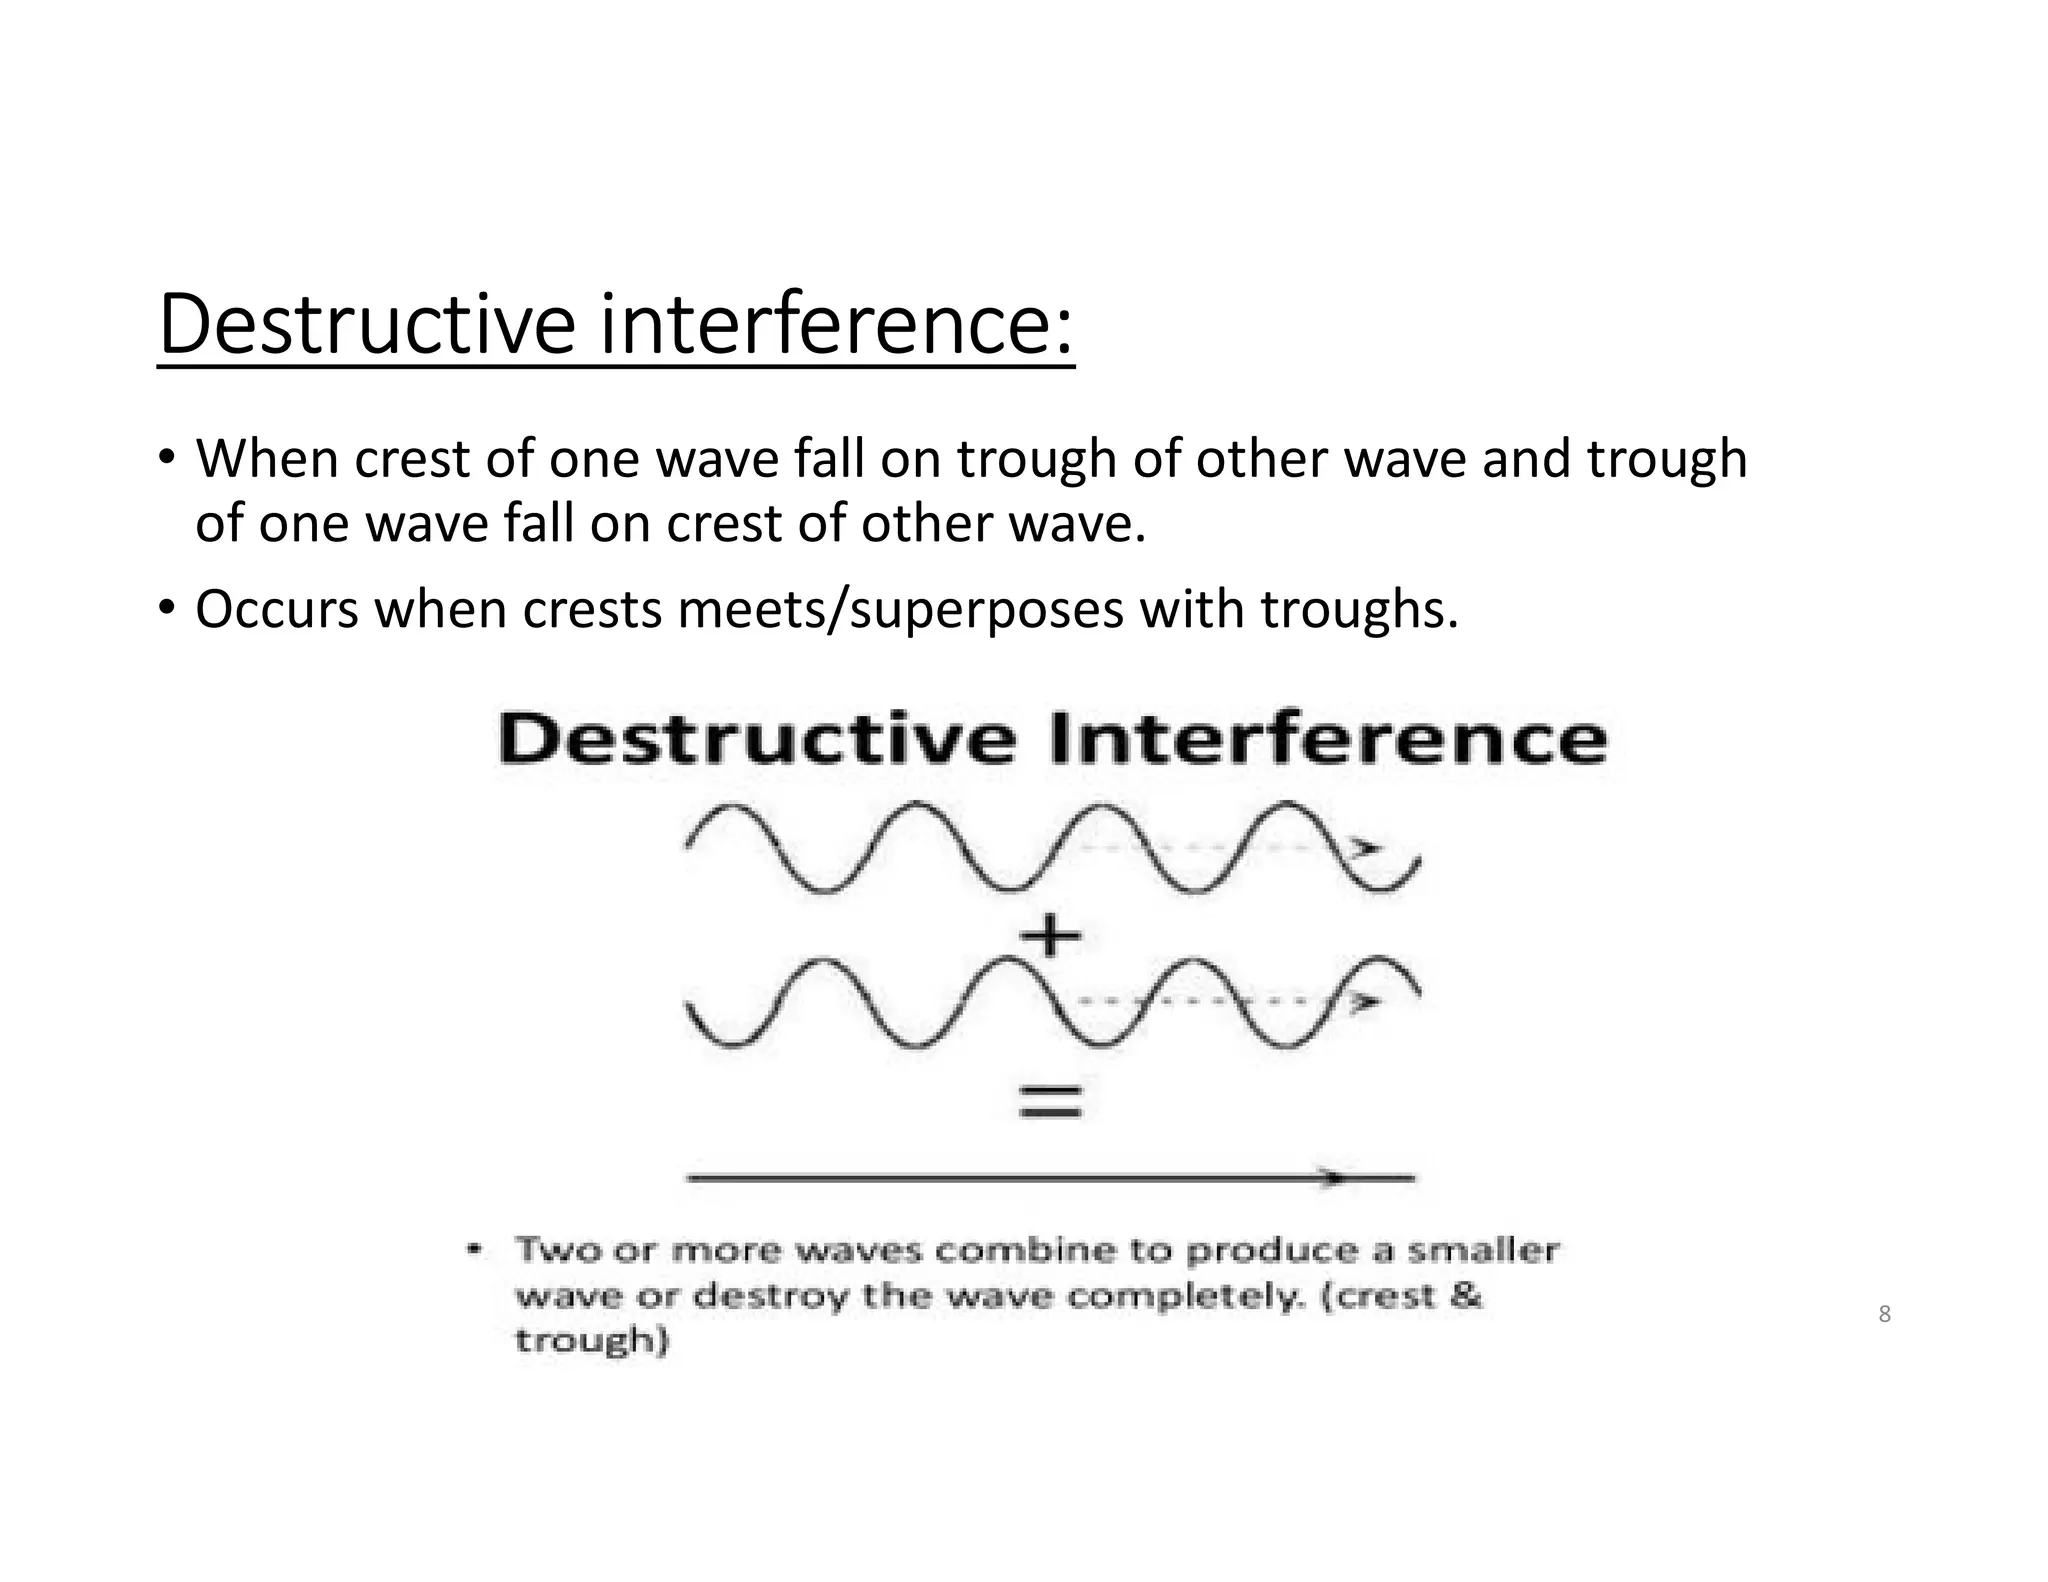
GNSS, which includes GPS (Global Positioning System) and other constellations like GLONASS, Galileo, and BeiDou, is the backbone of modern drone navigation and autonomous flight. Drones use GNSS signals to determine their precise position, altitude, and velocity, enabling features like position hold, waypoint navigation, and autonomous return-to-home. Interference targeting these faint satellite signals represents a profound threat to a drone’s ability to maintain stable flight and execute predetermined missions.
GPS Signal Jamming
GPS signal jamming involves overwhelming the weak signals from GNSS satellites with stronger, localized radio noise on the same frequency bands. This can be intentional, using dedicated jamming devices often employed for security or military purposes, or unintentional, arising from powerful radio transmitters, faulty electronic equipment, or even personal privacy devices designed to block location tracking in vehicles.
When a drone’s GNSS receiver is jammed, it loses its ability to lock onto enough satellite signals to calculate an accurate position. The consequences are immediate and severe for flight technology that relies on precise positioning. The drone may lose its position hold capability, beginning to drift uncontrollably. Autonomous waypoint navigation becomes impossible, as the drone cannot determine its current location relative to its programmed path. Return-to-home functions, which typically rely on a pre-recorded GPS coordinate, will fail or lead the drone astray. Modern flight controllers attempt to compensate for GPS jamming by switching to alternative positioning methods, such as relying more heavily on Inertial Measurement Units (IMUs) and barometer data for relative positioning, or activating visual positioning systems (VPS) in conjunction with downward-facing cameras for ground-relative stability. However, these backups have limitations, particularly at higher altitudes or over featureless terrain.
GPS Signal Spoofing
GPS signal spoofing is a more insidious form of GNSS interference, where a drone’s receiver is tricked into believing it is at a different location or moving at a different velocity than it actually is. Instead of merely blocking signals, spoofing involves generating false, but convincing, GNSS signals that mimic legitimate satellite transmissions. These fake signals can be stronger than the authentic ones, causing the drone’s receiver to lock onto them.
The implications of GPS spoofing for flight technology are particularly alarming, especially for drones involved in critical infrastructure inspection, surveillance, or autonomous delivery. A spoofed drone could be stealthily diverted from its intended flight path to an unauthorized location, potentially flying into restricted airspace, crashing into obstacles, or even landing at an enemy’s designated site. For example, a drone tasked with inspecting a power line could be made to believe it is flying correctly while subtly being rerouted away from its mission or towards a collision. Detecting spoofing is significantly more challenging than detecting jamming, as the drone’s receiver still perceives strong, seemingly valid signals. Advanced GNSS receivers in high-end flight technology employ techniques such as cryptographic authentication of satellite signals, multi-frequency reception (to compare signals across different bands), and cross-referencing with other sensor data (like IMU, compass, and visual odometry) to identify and reject spoofed signals. However, robust protection against sophisticated spoofing attacks remains an active area of research and development in drone flight technology.

Mitigation Strategies and Advanced Flight Systems
Addressing the multifaceted challenges posed by RF and GNSS interference requires a multi-pronged approach, encompassing both technological advancements in flight systems and responsible operational practices. Modern drone flight technology continuously evolves to build resilience against these threats.
On the RF interference front, techniques like spread spectrum communication (FHSS, DSSS) ensure signals are robust and less susceptible to narrow-band jamming. Adaptive frequency hopping allows the drone and controller to dynamically switch to clearer channels when interference is detected. Furthermore, specialized directional antennas and signal filtering can help isolate desired signals from ambient noise. For critical applications, redundant communication links operating on different frequency bands provide an invaluable backup.
To combat GNSS interference, advanced flight systems often integrate multi-constellation GNSS receivers, capable of tracking signals from GPS, GLONASS, Galileo, and BeiDou simultaneously. This diversity increases the likelihood of maintaining a satellite lock even if one constellation is jammed or spoofed. Beyond GNSS, drones are increasingly equipped with sophisticated sensor fusion capabilities. Inertial Measurement Units (IMUs) provide short-term stability and relative positioning, while magnetometers assist with heading. Visual Positioning Systems (VPS) using downward-facing cameras allow for precise hovering and navigation in GNSS-denied environments at low altitudes. Lidar and radar sensors contribute to obstacle avoidance and terrain following, further reducing reliance on external navigation signals.
From an operational perspective, pre-flight site assessments to identify potential sources of interference, adherence to local RF regulations, and maintaining optimal line-of-sight between the drone and controller are crucial. Pilots must be trained to recognize the signs of interference and know how to react, whether by activating failsafe modes, adjusting flight paths, or performing emergency landings. As drone technology continues to push the boundaries of autonomy and capability, the ongoing development of resilient, intelligent flight systems that can detect, adapt to, and mitigate interference will remain a critical focus for ensuring safe and reliable operations.