
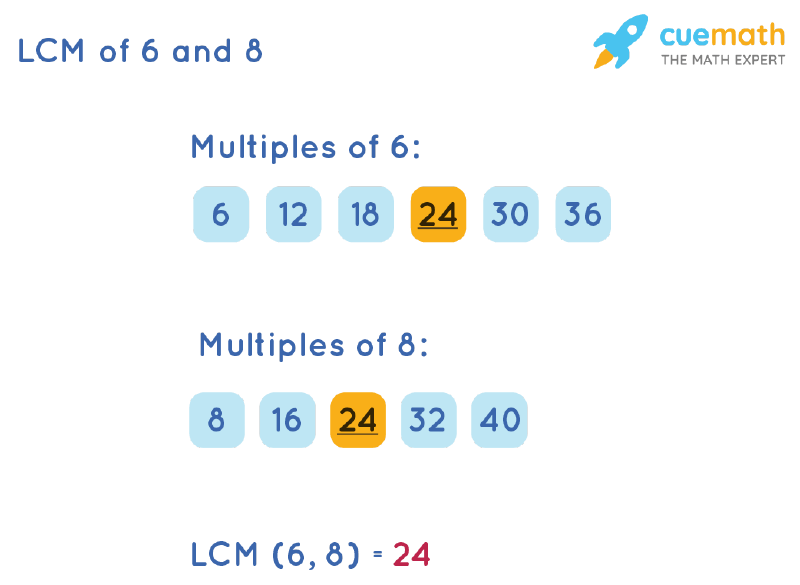
In the realm of advanced drone technology and innovation, seemingly simple mathematical concepts often underpin complex autonomous systems and sophisticated operational strategies. While the direct answer to “what is the LCM for 8 and 6?” is 24, its relevance extends far beyond basic arithmetic. In the context of cutting-edge drone applications, the Least Common Multiple (LCM) emerges as a fundamental principle for synchronizing disparate systems, optimizing multi-drone operations, and enhancing the reliability of intelligent flight platforms. This seemingly modest mathematical idea is, in fact, a cornerstone for managing periodicity, alignment, and convergence in systems where multiple components or agents operate on varying cycles, frequencies, or timelines. Understanding and applying LCM principles allows engineers and innovators to design more efficient, robust, and truly autonomous drone solutions, from seamless sensor data fusion to intricate swarm coordination.
The Unseen Mathematics of Drone Autonomy
The drive towards fully autonomous drones, capable of complex tasks without constant human intervention, relies heavily on precise timing and synchronization. Modern drones are sophisticated ecosystems of sensors, processors, communication modules, and flight control systems, each often operating at its own independent frequency or cycle. The ability to understand when these disparate cycles align is crucial for maintaining situational awareness, executing critical maneuvers, and processing vast amounts of data effectively. This is where the underlying logic of the LCM finds its powerful application.
Synchronizing Multi-Sensor Data Streams
Autonomous drones rely on a rich tapestry of sensor data to perceive their environment, navigate, and make intelligent decisions. These sensors, such as GPS, IMUs (Inertial Measurement Units), LiDAR, optical cameras, and ultrasonic sensors, often have different refresh rates or sampling frequencies. For instance, an IMU might provide data at 100Hz, a GPS module at 8Hz, and a high-resolution camera at 6 frames per second (6Hz). For an AI-powered flight controller or a mapping algorithm to fuse this data accurately, it needs to understand the temporal relationship between these incoming streams.
Consider a scenario where a drone’s navigation system combines inputs from a GPS module updating at 8Hz and an optical flow sensor updating at 6Hz. To achieve optimal sensor fusion and provide the most accurate real-time position estimate, the system needs to know when both sensors deliver new data points simultaneously. The LCM of 8 and 6, which is 24, indicates that every 24th unit of time (e.g., 240 milliseconds if operating in tenths of a second, or 24 seconds if operating in seconds), a perfect alignment of data points occurs. This knowledge is vital for developing efficient data fusion algorithms, where data from different sources can be combined precisely without introducing latency or errors due to temporal misalignment. Engineers can use the LCM to determine the most effective interval for reading and integrating data from all critical sensors, ensuring that the AI algorithms receive a coherent and synchronized snapshot of the drone’s state and environment. This minimizes computational overhead by processing fused data only when all relevant inputs are available, rather than constantly resampling or interpolating less frequent data streams.
Orchestrating Swarm Robotics
The future of many drone applications lies in swarm robotics, where multiple drones collaborate to achieve a common goal that a single drone cannot. This ranges from large-scale mapping and inspection to search and rescue operations or coordinated payload delivery. The synchronization challenges in swarm operations are exponential, encompassing not just individual drone systems but also the interactions between drones.
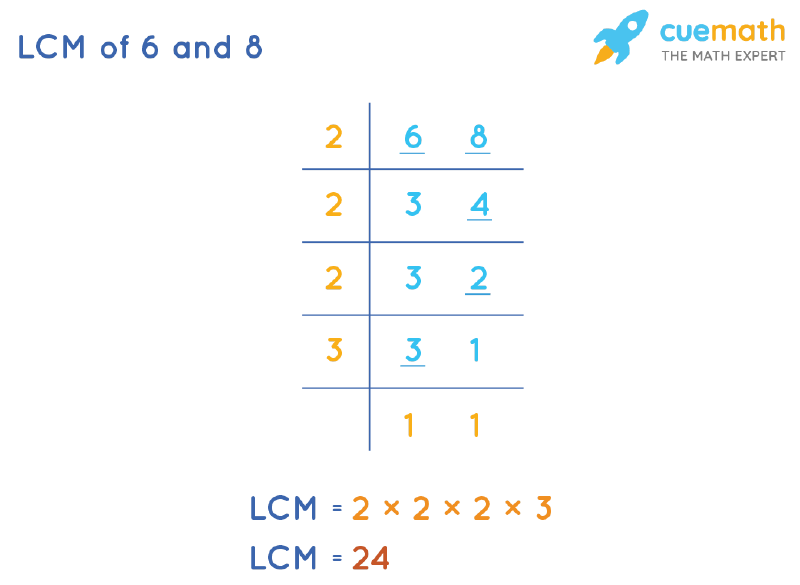
Imagine a swarm where Drone A completes a segment of its mapping pattern every 8 minutes, while Drone B completes its segment every 6 minutes. If these drones need to periodically rendezvous for data transfer, battery swap, or to perform a synchronized action at a specific point, knowing when their individual cycles will align is paramount. The LCM of 8 and 6, 24, dictates that every 24 minutes, both drones will simultaneously complete their respective segments and be at their designated rendezvous point. This understanding allows for precise mission planning, efficient resource allocation, and crucial collision avoidance strategies within a multi-agent system.
For larger swarms, managing communication schedules, coordinated maneuvers, or distributed sensing tasks with drones operating on different patrol routes or data collection cycles becomes even more intricate. The application of LCM extends to optimizing communication protocols, ensuring that all drones are available to transmit or receive critical data at predetermined intervals, thus preventing network congestion and ensuring mission integrity. It enables the development of robust algorithms for collective behavior, ensuring that drones can predict and align their actions, thereby enhancing the overall efficiency and safety of the swarm.
Beyond Simple Cycles: Optimizing Drone Operations
The principles embodied by the LCM are not limited to immediate operational synchronization but also extend to broader aspects of drone technology and innovation, impacting resource management, predictive maintenance, and the overall design of autonomous systems. The ability to identify common periodicities allows for a more holistic approach to system optimization.
Resource Allocation and Predictive Maintenance
In advanced drone systems, efficient resource allocation is critical. This includes managing processing cycles, power consumption, and data storage. Different background tasks, such as navigation computations, obstacle avoidance algorithms, and data logging, might run on various internal schedules. By identifying the LCM of these operational cycles, developers can design more intelligent schedulers that optimize power usage by minimizing peak demands or ensuring that critical processing resources are available when multiple tasks converge. For example, if a heavy processing task needs to run every 8 seconds and a data offload task every 6 seconds, scheduling them to align at the 24-second mark might be more efficient, or strategically staggered to avoid contention, based on the understanding provided by their LCM.
Furthermore, predictive maintenance strategies for complex drone components can benefit from LCM principles. If different components have recommended inspection or service intervals – perhaps a motor bearing check every 8 flight hours and a propeller balance check every 6 flight hours – the LCM of 24 flight hours indicates when a comprehensive maintenance overhaul, covering both items, would be most efficient. This proactive approach minimizes downtime, extends the lifespan of critical components, and enhances the overall reliability and safety of the drone fleet, moving beyond reactive repairs to a more strategic, data-driven maintenance schedule.
The Foundation of Intelligent Flight: When Fundamental Math Powers Innovation
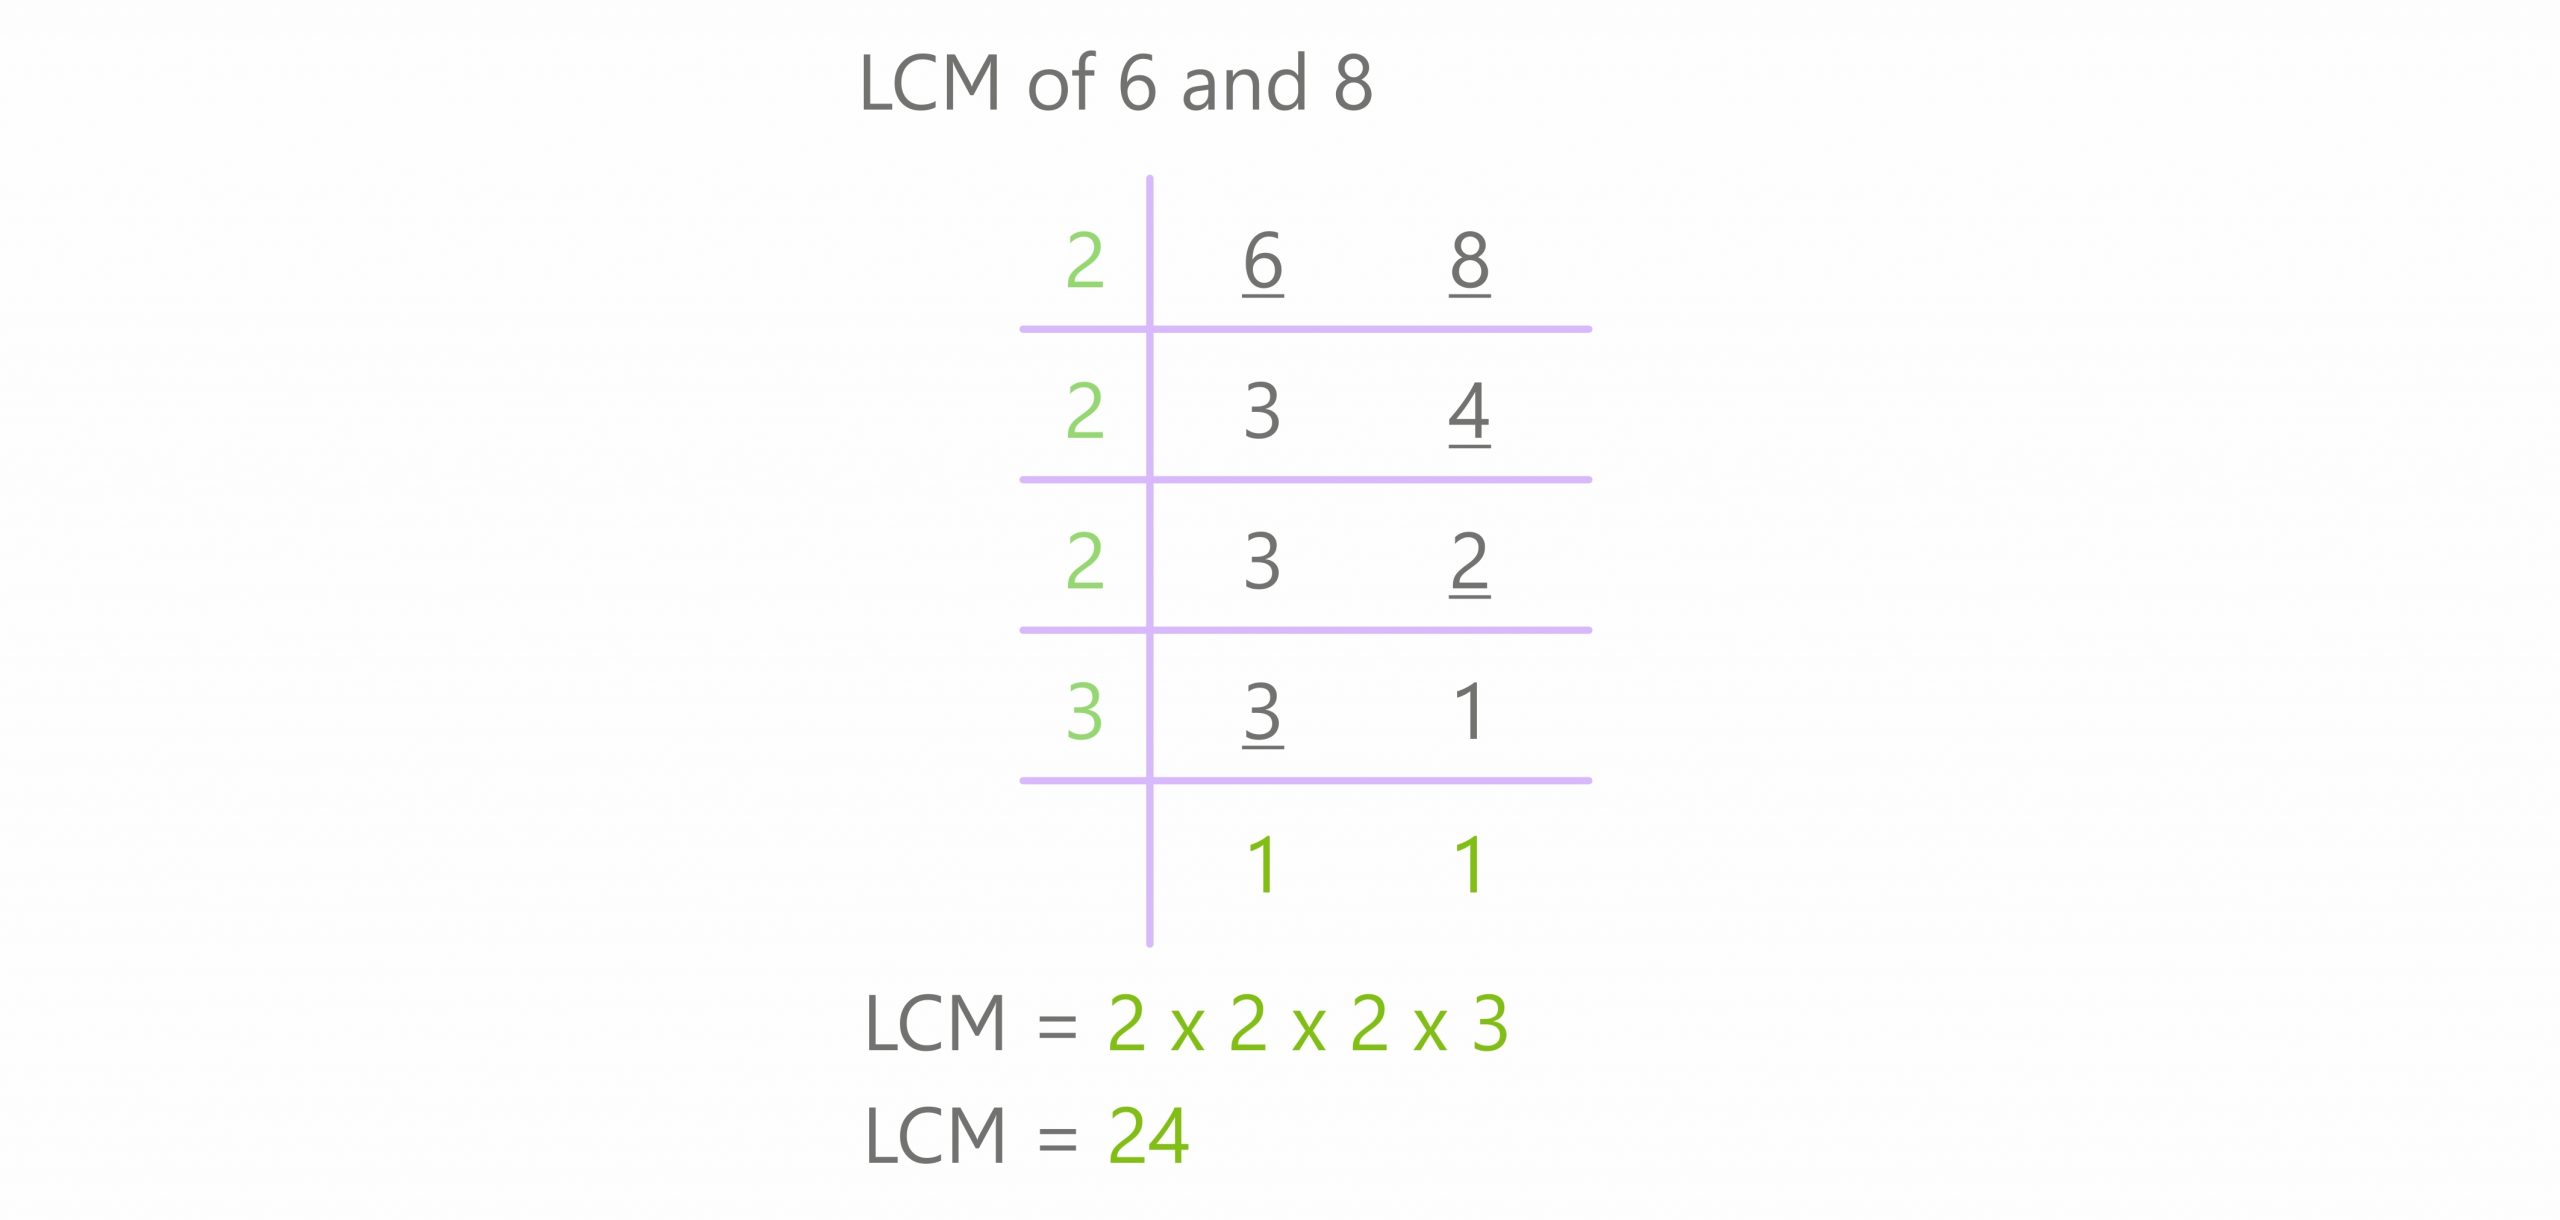
The question “what is the LCM for 8 and 6” serves as a reminder that at the heart of groundbreaking technological innovation often lies a deep understanding and clever application of fundamental mathematical principles. For drones, especially in the evolving fields of AI, autonomous flight, advanced mapping, and remote sensing, the ability to manage and synchronize periodicity is not merely an optimization; it is a necessity for achieving reliable, safe, and truly intelligent operation.
From ensuring that an AI vision system receives perfectly aligned data from multiple sensors to coordinating complex maneuvers across a swarm of autonomous vehicles, the concept of the Least Common Multiple plays an indispensable role. It enables developers to design algorithms that are robust to asynchronous inputs, plan multi-agent missions with precision, and optimize the lifecycle management of intricate drone systems. By integrating such foundational mathematical insights, engineers are pushing the boundaries of what drones can achieve, transforming them from mere remote-controlled devices into sophisticated, self-sufficient aerial robots capable of unprecedented levels of autonomy and collaboration. The LCM of 24 for 8 and 6 is thus more than a numerical answer; it symbolizes the essential harmony and predictive power that mathematics brings to the dynamic and complex world of drone technology and innovation.