
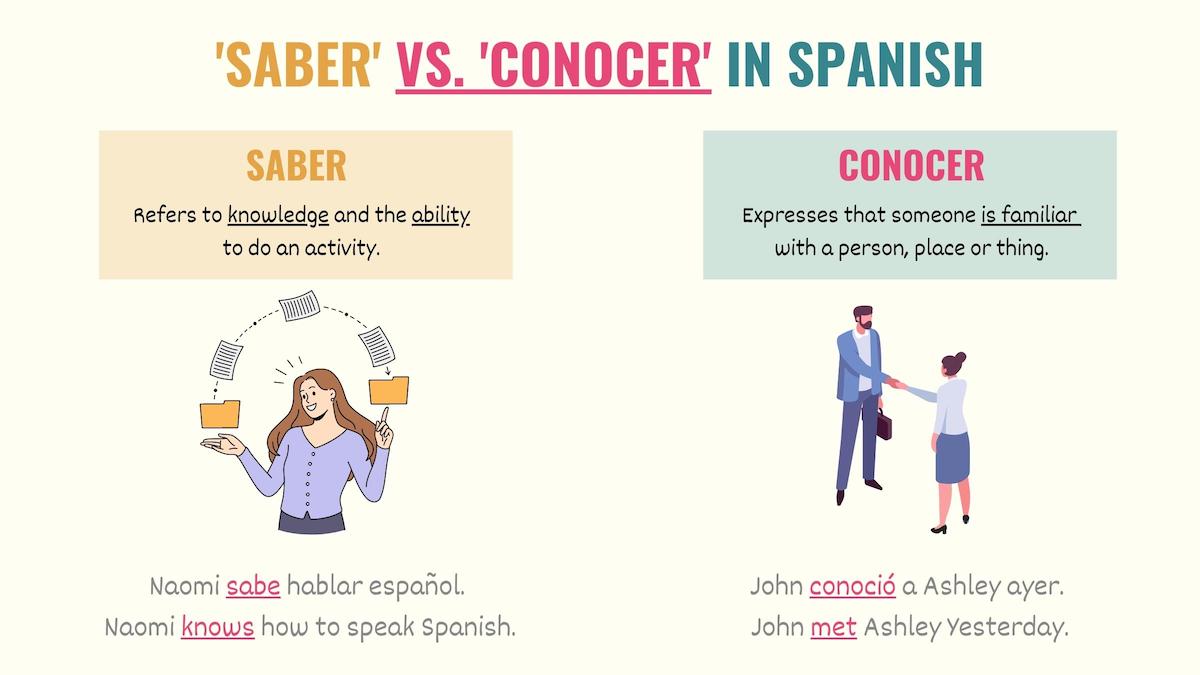
In the rapidly evolving landscape of drone technology and innovation, the concept of “knowing” for an autonomous system transcends simple data processing. While human understanding distinguishes between knowing a fact (“saber”) and being familiar with a person or place (“conocer”), a parallel distinction proves incredibly useful when analyzing the intelligence of drones, particularly in areas like AI follow mode, autonomous flight, mapping, and remote sensing. For an advanced drone, “saber” often refers to explicit, algorithmic knowledge and factual data, while “conocer” represents an experiential, learned familiarity with its environment and operational nuances. Understanding this distinction is key to appreciating the sophistication of modern unmanned aerial vehicles (UAVs).
The Foundation of “Saber”: Explicit Knowledge and Algorithmic Certainty
When an autonomous drone “sabes,” it possesses concrete, quantifiable data and operates according to predefined rules and explicit programming. This form of knowledge is foundational, comprising the hard-coded logic and direct sensor inputs that enable basic and advanced flight functions. It’s the kind of knowledge that can be precisely defined, measured, and replicated across countless systems.
Pre-programmed Directives and Sensor Interpretation
Every autonomous drone begins with a robust set of pre-programmed directives. These include flight parameters like maximum altitude, speed limits, geofencing boundaries, and failsafe protocols. The drone “sabes” these rules because they are explicitly written into its firmware and software. For instance, a drone “sabes” its current GPS coordinates, the battery voltage, the target waypoint, and the distance to the ground as reported by its altimeter. These are facts – undeniable pieces of information directly fed into its computational core.
Sensor interpretation falls squarely within the realm of “saber.” LIDAR sensors “saben” the precise distance to objects by measuring time-of-flight for laser pulses. Vision systems, when performing basic object detection, “saben” that a certain pixel pattern corresponds to a tree, a building, or a human based on pre-trained data sets and direct comparisons. These are not interpretations based on experience, but rather the execution of algorithms that process raw sensor data into actionable, factual information. The drone “sabes” the precise wind speed reported by an anemometer, or the temperature and humidity from environmental sensors, because it is explicitly designed to read and interpret these digital inputs. This form of knowing is precise, deterministic, and forms the bedrock of predictable and safe autonomous operations.
Rule-Based Logic in Flight Control
The core of autonomous flight control relies heavily on rule-based logic – the very essence of “saber.” When a drone is commanded to fly to a specific set of GPS coordinates, it “sabes” the mathematical calculations required to adjust its motor speeds and gimbal angles to achieve that trajectory. Proportional-Integral-Derivative (PID) controllers, fundamental to drone stabilization, “saben” how to minimize error between desired and actual orientations based on established control theory. If an obstacle is detected within a certain proximity, the system “sabes” to initiate an avoidance maneuver based on a predefined set of rules: either stopping, ascending, descending, or moving around it.
Consider a drone tasked with mapping a specific area. It “sabes” the grid pattern it needs to follow, the overlap required between images, and the altitude necessary to achieve a certain ground sample distance (GSD). These are all explicit instructions and parameters that are part of its operational “saber.” This form of knowledge is essential for repeatability, precision, and adherence to operational standards, ensuring that autonomous missions are executed consistently and reliably based on a known set of variables and outcomes.
The Nuance of “Conocer”: Experiential Learning and Environmental Familiarity
While “saber” provides the foundational rules and facts, “conocer” elevates an autonomous drone’s intelligence by introducing adaptive, learned, and contextual understanding. This form of knowledge is not explicitly programmed but is acquired through experience, interaction with the environment, and continuous learning. It allows drones to move beyond rigid rules and react intelligently to novel or dynamic situations, making them more resilient and versatile.
Machine Learning for Pattern Recognition
The ability of a drone to “conocer” its environment is largely driven by advanced machine learning (ML) algorithms, particularly deep learning. Instead of being explicitly told “this is a tree,” an ML model, through exposure to vast datasets of images and experiences, learns to “conocer” what a tree looks like in various lighting conditions, angles, and distances. This is a subtle but profound difference: it’s not a direct fact but a learned familiarity with patterns.
In object recognition, a drone “conoces” a human figure not by processing pre-defined pixel maps, but by recognizing complex, emergent features learned from millions of examples. This allows for robust identification even when objects are partially obscured, viewed from unusual angles, or in varying environments. Similarly, a drone operating an AI follow mode doesn’t just “saber” the target’s GPS coordinates; it “conoces” the target’s typical movement patterns, speed variations, and even subtle gestures, allowing it to predict future movements and maintain a smoother, more natural follow trajectory. This experiential “conocer” enables the drone to interpret complex scenes and make decisions that go beyond simple rule application.

Adaptive Behavior and Contextual Understanding
True autonomy often hinges on a drone’s capacity for adaptive behavior and contextual understanding – attributes of “conocer.” An autonomous system that merely “sabes” to avoid an obstacle by ascending might fail if the obstacle is a low-hanging power line in a dense forest. A system that “conoces” the nuances of the environment, however, might recognize the context (dense forest, potential power lines) and opt for a different avoidance strategy, perhaps a lateral maneuver or a slower, more cautious ascent.
This contextual understanding comes from accumulated experience and learned models of the world. A drone performing long-term environmental monitoring might “conocer” the typical wind patterns of a specific valley, having learned these over many flights. It doesn’t just “saber” the current wind speed; it “conoces” how these winds typically behave and how they might affect flight stability and energy consumption in that particular area, allowing for more efficient and safer mission planning. Similarly, in remote sensing, a drone might “conocer” the spectral signature of a particular plant disease, not from explicit programming, but from having processed and correlated countless images with ground-truth data, leading to a more intuitive and accurate diagnosis.
The Symbiosis: Elevating Autonomous Capabilities
The most sophisticated autonomous systems operate not by relying solely on “saber” or “conocer,” but through a powerful synergy of both. The explicit, rule-based knowledge (“saber”) provides the safety net and foundational capabilities, while the experiential, learned familiarity (“conocer”) imbues the system with intelligence, adaptability, and resilience. This harmonious interplay is what truly pushes the boundaries of drone technology.
Enhanced AI Follow Mode and Dynamic Obstacle Avoidance
Consider an advanced AI follow mode. The drone “sabes” the fundamental principles of flight, its current position relative to the subject, and pre-set safety distances. But it “conoces” the subject’s typical gait, acceleration profile, and even how they might navigate complex terrain from prior observations. This allows for a more fluid, predictive, and less jerky follow experience. If the subject suddenly moves into a dense area, the drone’s “conocer” of potential obstacles from previously flown missions or learned environmental models might override a simple “saber” rule to maintain a fixed distance, instead prompting a more cautious, adaptive trajectory.
For dynamic obstacle avoidance, the drone “sabes” the raw distance measurements from its sensors. But its ability to “conocer” a particular type of moving object (e.g., a bird, another drone, a human) through learned visual patterns allows it to predict its trajectory and react more intelligently than simply braking or making an arbitrary evasive maneuver. This combined intelligence leads to safer and more effective navigation in complex and unpredictable environments.
Advanced Mapping and Remote Sensing Through Learned Insight
In mapping and remote sensing, the drone “sabes” the precise flight path, camera settings, and georeferencing algorithms. This ensures accurate data collection. However, its capacity to “conocer” patterns in the collected data allows for unprecedented insights. For instance, in agricultural remote sensing, the drone might “conocer” the subtle visual cues indicating early crop stress or nutrient deficiencies, even before they are visible to the human eye, having learned these correlations from vast historical datasets.
Similarly, for structural inspections, a drone “sabes” the standard dimensions of a bridge or tower. But through “conocer,” it can identify anomalies or signs of wear that deviate from learned normal patterns, flagging areas for closer inspection without explicit programming for every possible defect. This experiential knowledge significantly enhances the analytical power of remote sensing data.
Implications for Future Drone Innovation
The ongoing quest to deepen both “saber” and “conocer” in autonomous drones is driving significant innovation across the tech sector. As AI and machine learning models become more sophisticated, the drone’s ability to “conocer” its world will continue to expand, leading to increasingly intelligent and robust systems.

Towards Truly Intelligent Autonomous Flights
The future of autonomous flight will see drones that are not just excellent at executing pre-defined missions (“saber”) but are also highly adept at adapting, learning, and improvising in dynamic, unstructured environments (“conocer”). This will manifest in drones that can navigate completely unknown territories, perform complex tasks with minimal human intervention, and even collaborate intelligently with other autonomous systems. From complex logistical operations to environmental conservation, the symbiotic relationship between “saber” and “conocer” is fundamental to unlocking the next generation of truly intelligent, self-sufficient drone technology, transforming how we interact with and utilize aerial platforms.