
The acronym ROV, standing for Remotely Operated Vehicle, designates a class of tethered underwater mobile devices that allow operators to perform complex tasks in aquatic environments without direct human presence. While the term “drone” often conjures images of aerial quadcopters soaring through the sky, the concept of an unmanned, remotely controlled vehicle extends far beyond the atmosphere. ROVs are, in essence, the underwater counterparts to aerial drones, serving critical functions in industries and research where human divers face insurmountable risks, depths, or endurance limitations. They are sophisticated robotic platforms equipped with a suite of sensors, cameras, and manipulators, all controlled from a surface vessel or land-based station via an umbilical cable.

Defining Remotely Operated Vehicles
At its core, an ROV is a robotic submarine connected to a control station by a tether, or umbilical cable. This cable serves as the lifeline for the ROV, transmitting power, data, and video signals between the vehicle and the operator. Unlike Autonomous Underwater Vehicles (AUVs), which operate independently based on pre-programmed missions, ROVs require constant human input, allowing for real-time control and adaptation to dynamic underwater conditions. This distinction is crucial, as the human-in-the-loop operation provides unparalleled flexibility and precision for intricate tasks.
The ROV in the Unmanned Vehicle Ecosystem
The evolution of ROVs has run parallel to that of aerial drones and other unmanned systems. All these technologies share the common goal of extending human capabilities into environments that are dangerous, inaccessible, or simply too tedious for direct human interaction. Just as a drone can inspect a wind turbine blade or deliver a package, an ROV can inspect underwater pipelines, retrieve lost objects from the seabed, or survey delicate marine ecosystems. They represent a specialized segment within the broader unmanned vehicle ecosystem, emphasizing the challenges and opportunities presented by the aquatic domain. While aerial drones navigate air currents and complex airspace regulations, ROVs contend with crushing pressures, limited visibility, and strong underwater currents. Their design principles, however, often mirror those of their aerial cousins: propulsion for mobility, sensors for data acquisition, cameras for visual feedback, and a control system for human interface.
Key Components and Design Principles
The construction of an ROV is a testament to engineering ingenuity, designed to withstand the harsh realities of the underwater world while executing precise tasks. Each component plays a vital role in the ROV’s operational success and safety.
Thrusters and Propulsion Systems
The primary means of locomotion for an ROV is a series of electric or hydraulic thrusters. These propellers, strategically positioned around the vehicle’s body, enable movement in all six degrees of freedom: forward/backward, up/down, left/right, and rotation about all three axes (pitch, roll, yaw). The number and configuration of thrusters vary widely depending on the ROV’s size and intended application. Smaller observation-class ROVs might have four to six thrusters for basic maneuverability, while larger work-class ROVs can boast eight or more powerful thrusters to combat strong currents and handle heavy loads. The efficiency and power of these thrusters are paramount for stable positioning and precise movement in dynamic underwater environments.
Umbilical and Control Systems
The umbilical cable is arguably the most critical component, serving as the physical and digital link between the ROV and the surface. It typically bundles power conductors, fiber optic cables for high-bandwidth data transmission (video, sensor data), and sometimes even pneumatic or hydraulic lines. The length and robustness of the umbilical dictate the ROV’s operational depth and range. Managing this cable, especially in deep water or complex subsea structures, is a significant operational challenge.
The control system, housed on the surface vessel or shore, translates operator commands into actions by the ROV. This usually involves joysticks, keyboards, and specialized software interfaces that display real-time video feeds, sonar data, depth, heading, and other telemetry. Advanced control systems often incorporate auto-heading, auto-depth, and dynamic positioning features, which assist the pilot in maintaining stability and executing precise maneuvers, much like flight stabilization systems in aerial drones.
Sensors, Cameras, and Payloads
ROVs are sensory powerhouses, equipped to gather a wide array of data from the underwater environment. High-definition cameras, often mounted on pan-and-tilt units and accompanied by powerful lights, provide the primary visual feedback, essential for navigation, inspection, and task execution. Beyond visual spectrum cameras, many ROVs integrate sonar systems (e.g., multibeam, side-scan) for mapping the seabed, identifying objects in low visibility, or obstacle avoidance. Other common sensors include depth gauges, magnetometers, altimeters, and various environmental sensors to measure parameters like temperature, salinity, and turbidity.
The term “payload” refers to the specialized tools and equipment an ROV carries to perform its mission. This can include:
- Manipulator arms: Robotic arms with various end-effectors (grippers, cutters, specialized tools) for dexterity and interaction with subsea infrastructure.
- Sampling tools: Devices for collecting water, sediment, or biological samples.
- Measurement tools: Such as cathodic protection probes for inspecting corrosion on metal structures.
- Acoustic positioning systems: For precise navigation and tracking relative to the surface vessel or fixed transponders.
The modularity of payload systems allows ROVs to be reconfigured for different missions, making them versatile tools across various industries.
Types of ROVs and Their Applications
ROVs are categorized based on their size, power, and operational capabilities, each type serving distinct purposes across a multitude of industries.
Micro and Mini ROVs
These are the smallest and most agile ROVs, typically weighing less than 50 kg and designed for shallow water inspections, confined space entry (e.g., inside pipes, tanks), and light observation tasks. They are often battery-powered or draw minimal power via a thin umbilical, making them highly portable and deployable from small boats or even from shore. Their ease of use and affordability have led to their adoption in aquaculture, recreational diving support, and basic scientific surveys.
Observation-Class ROVs
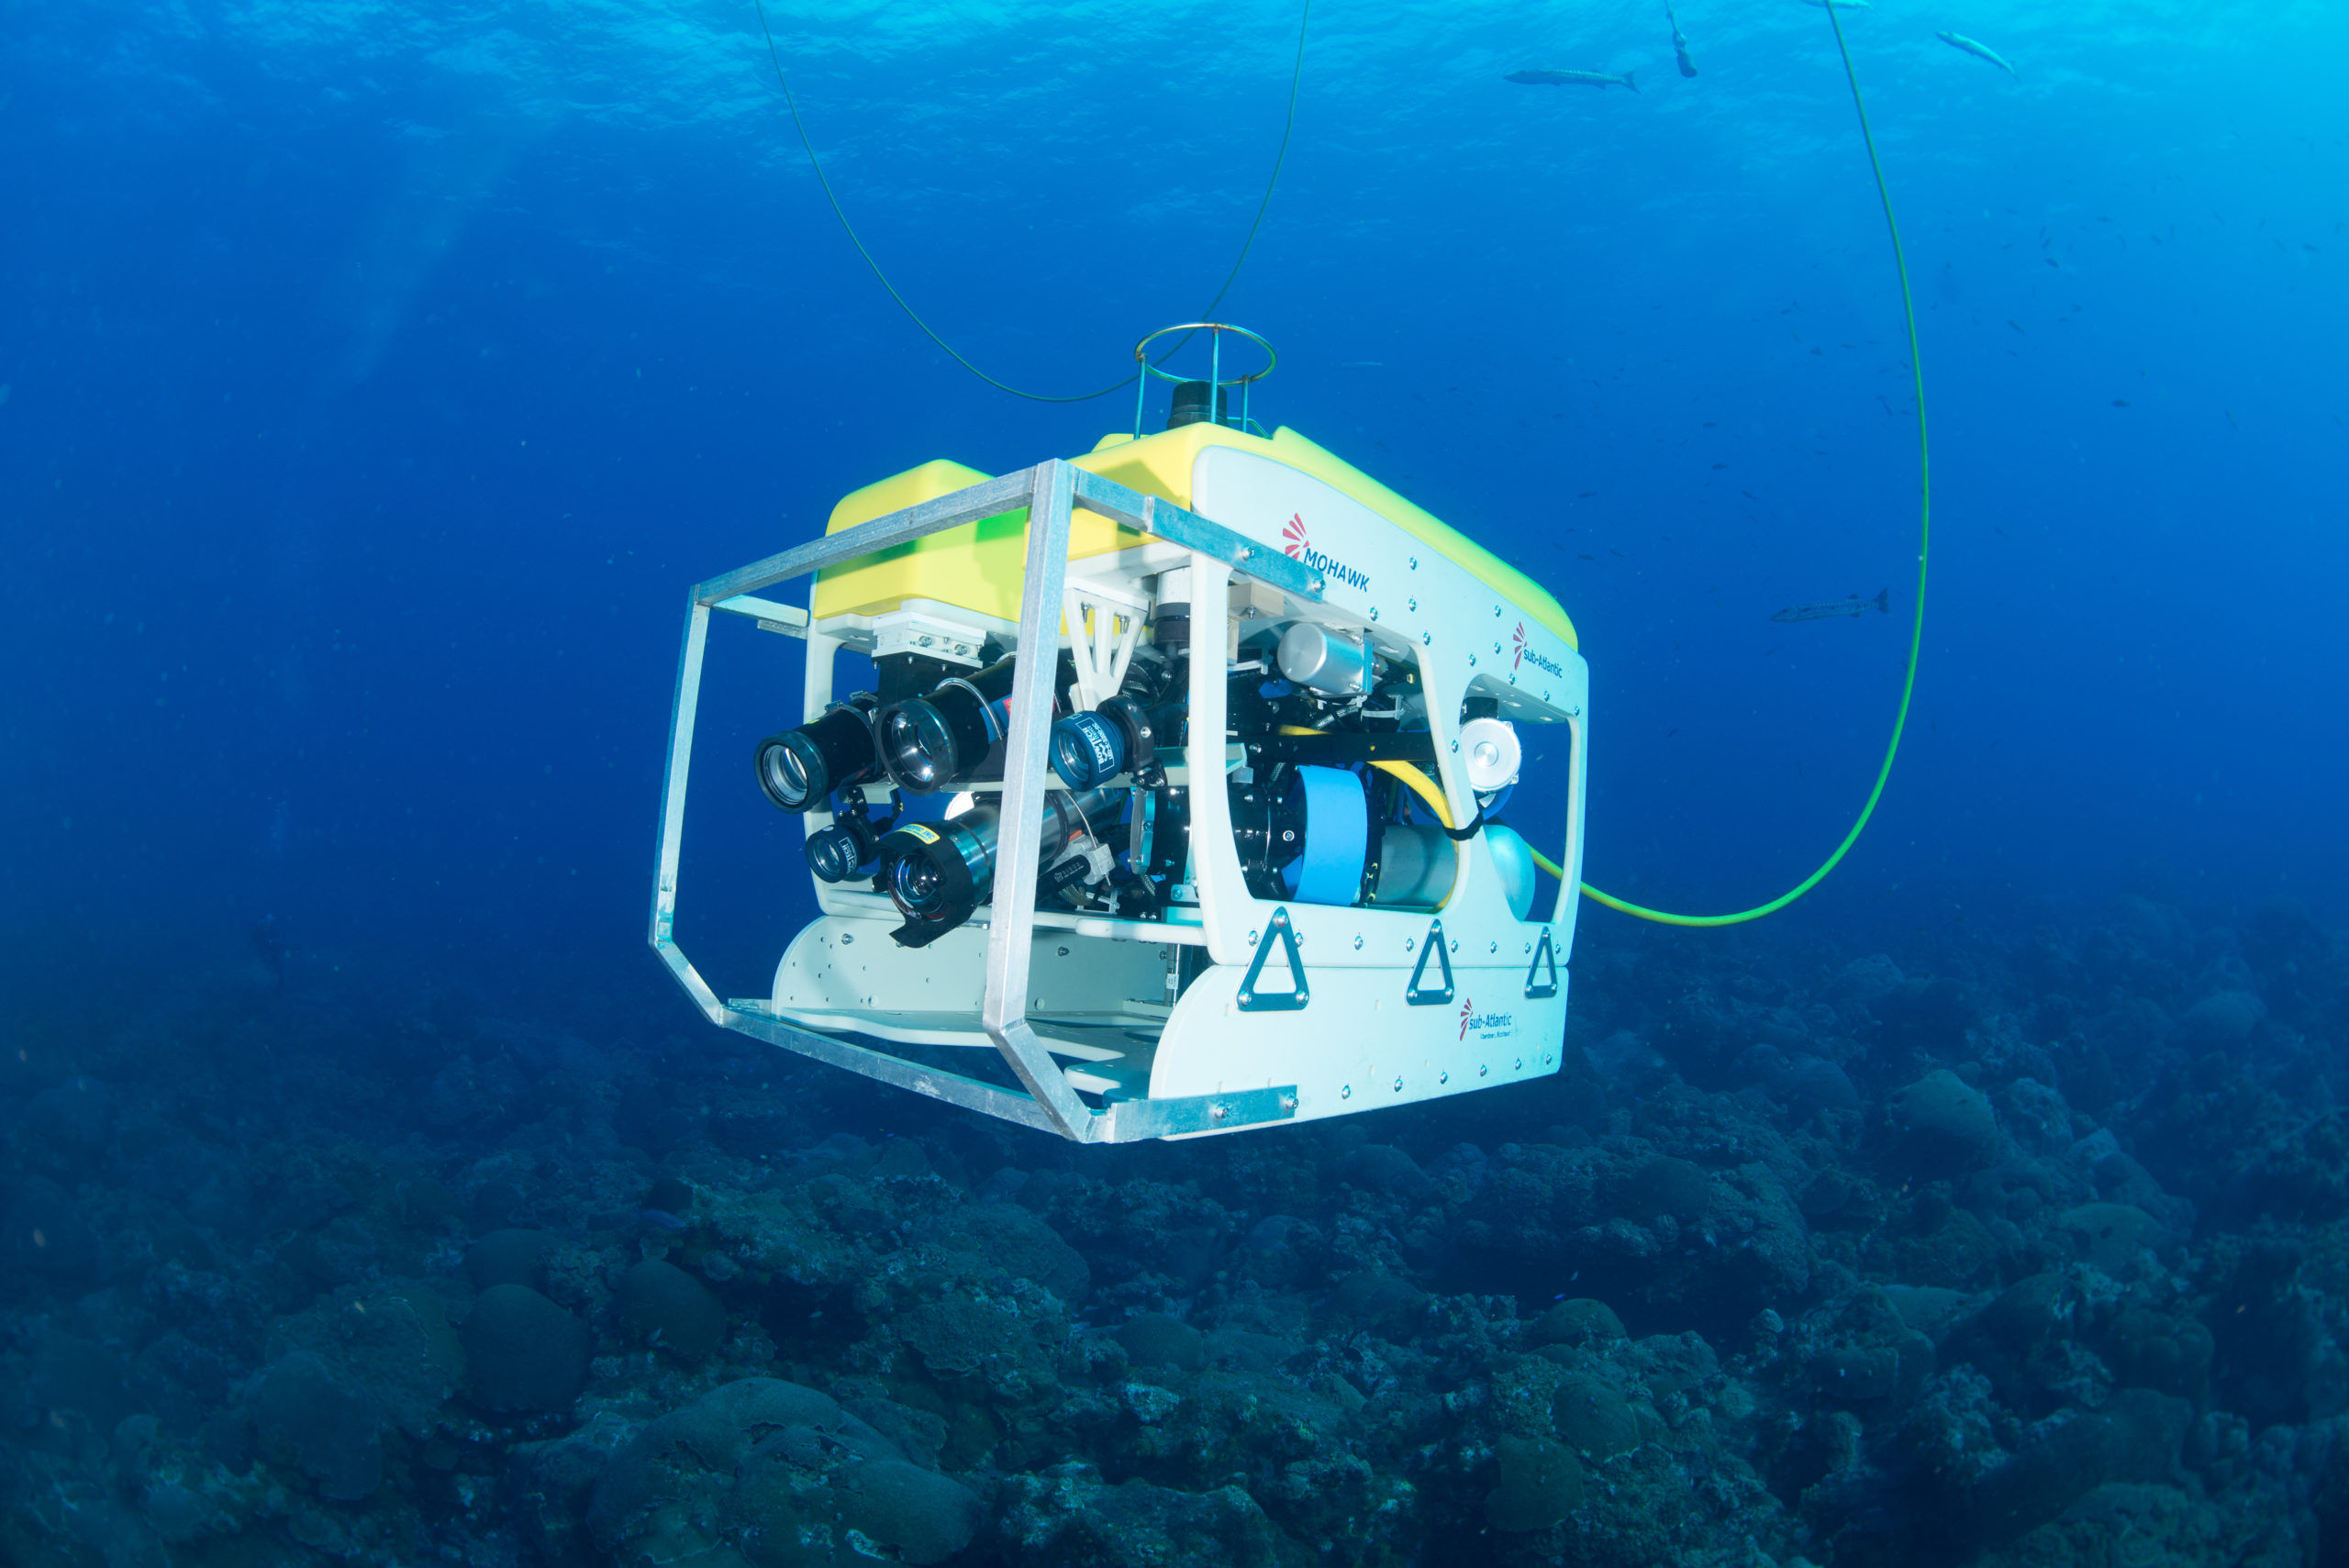
Larger and more robust than micro/mini ROVs, observation-class vehicles are designed for general inspection, survey, and light intervention tasks. They weigh from 50 kg to several hundred kilograms and are equipped with more powerful thrusters, higher-quality cameras, and the ability to carry a wider range of sensors. They are workhorses for offshore oil and gas pipeline inspections, structural integrity assessments of subsea installations, environmental monitoring, and support for saturation divers.
Work-Class ROVs
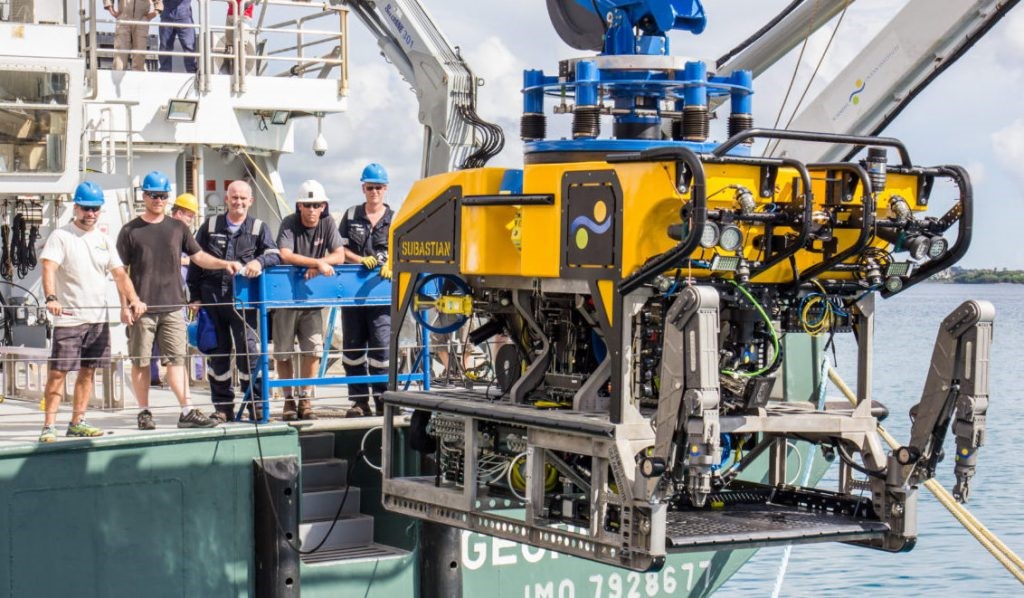
These are the titans of the ROV world, massive and powerful vehicles weighing thousands of kilograms, often exceeding 100 horsepower. Work-class ROVs are designed for heavy construction, intervention, and maintenance tasks at extreme depths. They feature powerful hydraulic manipulator arms capable of lifting heavy objects, operating valves, cutting cables, and deploying specialized tools. These ROVs are indispensable in the deep-sea oil and gas industry for drilling support, Christmas tree installations, pipeline repair, and decommissioning. Their complex power and control systems require dedicated launch and recovery systems (LARS) and a team of highly skilled pilots and technicians.
Intervention-Class ROVs
A specialized subset, often overlapping with work-class ROVs, intervention ROVs are tailored for highly specific and complex tasks. This can include precise subsea well intervention, deep-sea mining exploration, or the recovery of sensitive equipment from extreme depths. They often incorporate advanced automation features, custom tooling, and highly specialized sensors for their unique missions.
Primary Applications and Industries
The utility of ROVs spans a vast array of sectors, demonstrating their crucial role in managing and exploring the underwater world.
Offshore Energy (Oil & Gas, Renewables)
The oil and gas industry is the largest consumer of ROV services. ROVs are used extensively for inspecting pipelines, platforms, and subsea production systems; assisting with drilling operations; installing and maintaining equipment; and performing complex repairs. In the burgeoning offshore wind energy sector, ROVs inspect turbine foundations, cables, and conduct environmental impact assessments.
Scientific Research and Exploration
ROVs are invaluable tools for oceanographers, marine biologists, and geologists. They enable scientists to explore deep-sea hydrothermal vents, observe elusive marine life in its natural habitat, collect samples from the seabed, map unknown territories, and study geological formations without disturbing delicate ecosystems or risking human lives.
Search and Recovery
From locating sunken ships and aircraft to recovering black boxes and debris, ROVs play a critical role in search and recovery operations. Their ability to operate at significant depths and transmit real-time video makes them ideal for systematically surveying large underwater areas and identifying targets for retrieval. Military and law enforcement agencies also utilize ROVs for mine countermeasures, port security, and forensic investigations.
Infrastructure Inspection and Maintenance
Beyond offshore energy, ROVs are used to inspect underwater infrastructure such as dams, bridges, harbors, and municipal water systems. They can identify structural damage, sediment buildup, and other issues that could compromise safety or operational efficiency, often reducing the need for costly and hazardous human diving operations.
Advantages and Limitations
ROVs offer distinct advantages over human divers and other subsea technologies, but they also come with their own set of limitations and operational challenges.
Enhanced Safety and Access
The foremost advantage of ROVs is their ability to perform tasks in environments too dangerous for human divers. They can operate at extreme depths and pressures, in contaminated waters, or in areas with strong currents or hazardous marine life. This significantly enhances safety for personnel and allows access to previously unreachable locations. ROVs also offer extended operational endurance, as they are not limited by human bottom times, decompression sickness risks, or fatigue.
Operational Challenges
Despite their capabilities, ROVs face inherent limitations. The umbilical cable, while essential, can be a major hindrance. It can snag on subsea structures, limit maneuverability, and introduce drag, especially in strong currents. The logistics of deploying and recovering ROVs, particularly work-class systems, require specialized vessels and equipment, adding to operational complexity and cost. Furthermore, operator skill is paramount; effective ROV piloting and manipulation require extensive training and experience to navigate complex environments and execute precise tasks. The clarity of underwater vision is also a constant challenge, as turbidity and lighting conditions can severely impact visibility, necessitating reliance on sonar and other sensors.
In conclusion, ROVs represent a sophisticated and indispensable segment of the unmanned vehicle landscape. By extending human reach into the silent, immense, and often hostile underwater world, they unlock possibilities for industry, science, and safety that were once confined to the realm of imagination, proving that the drone revolution is as profound below the waves as it is in the skies.