
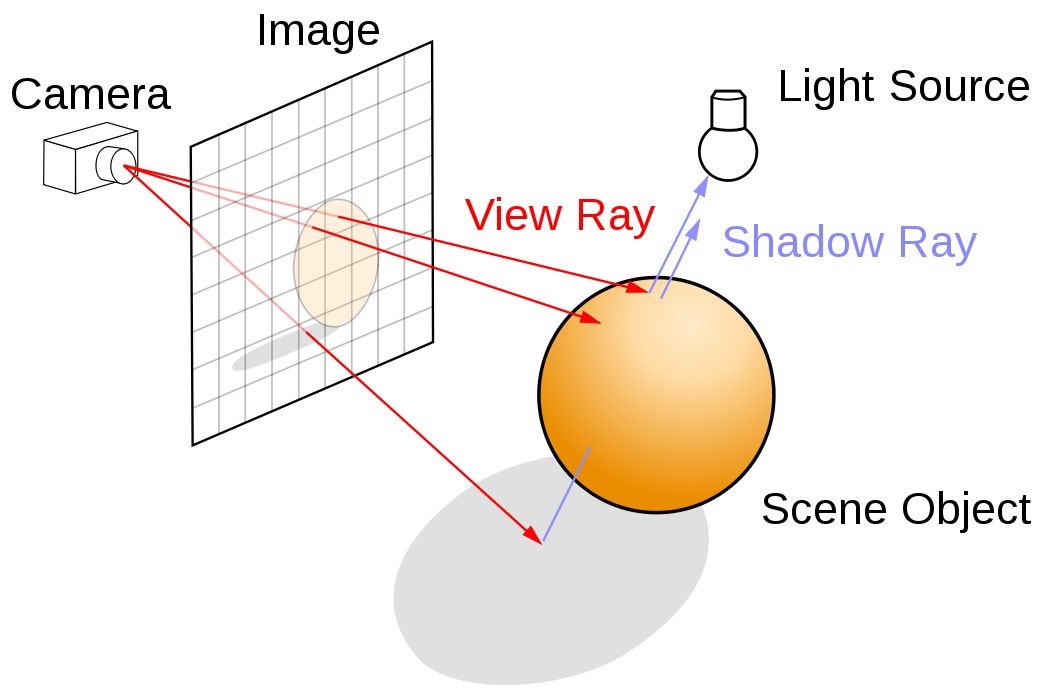
Ray casting is a fundamental computational geometry technique that plays an increasingly critical role in the advanced capabilities of modern flight technology, particularly in autonomous drones. At its core, ray casting involves projecting an imaginary ray from a specific point in space into a simulated or real environment and determining what object, if any, that ray intersects first. While originally a computer graphics rendering method, its underlying principles are directly analogous to how many sophisticated drone sensors perceive and interact with their surroundings, forming the bedrock for sophisticated navigation, mapping, and, most crucially, obstacle avoidance systems.
The Foundational Principle in Flight Technology Sensing
The concept of ray casting is deceptively simple: imagine a point in space, which could represent a drone’s sensor, and a direction in which it “looks.” A ray is then extended indefinitely in that direction. The primary goal is to find the closest object this ray encounters. In the realm of computer graphics, this process is used to determine the color of a pixel by tracing a ray from the camera through that pixel into a virtual scene. However, in flight technology, particularly for unmanned aerial vehicles (UAVs), this paradigm shifts from “seeing” to “sensing.”
Instead of rendering pixels, drone systems employ hardware that performs actions akin to ray casting to gather data about the physical world. A sensor emits a signal—be it a laser pulse, a sound wave, or structured light—and then “listens” or “looks” for its return or reflection. The time it takes for the signal to return, or the way it is reflected, provides critical information about the distance and nature of objects in the drone’s environment. This effectively mirrors the ray casting principle: a ray (the emitted signal) travels in a specific direction, interacts with an object, and the drone’s onboard systems interpret this interaction to understand its surroundings. This principle moves beyond theoretical simulation, becoming an active process of environmental probing that fuels real-time decision-making.
Ray Casting through Drone Sensors: Perceiving the Airspace
The integration of ray casting principles into drone sensors enables UAVs to build a dynamic, real-time understanding of their operational environment. Different sensor technologies achieve this in distinct ways, each with its own advantages and limitations, but all fundamentally rely on the concept of projecting and interpreting “rays.”
Lidar Systems and Point Clouds
Light Detection and Ranging (Lidar) is perhaps the most direct embodiment of ray casting in practical drone applications. Lidar sensors emit thousands, or even hundreds of thousands, of laser pulses (rays) per second. Each pulse travels outward, strikes an object, and reflects back to the sensor. By precisely measuring the “time of flight” (TOF) for each pulse – the duration from emission to return – the lidar system calculates the exact distance to the object that reflected the ray.
As the drone moves and the lidar sensor rapidly scans its surroundings (often through a rotating mirror or solid-state array), these individual distance measurements coalesce into a “point cloud.” A point cloud is a collection of data points in a 3D coordinate system, where each point represents a location in space where a laser ray intersected a physical surface. This dense, precise 3D map of the environment is invaluable for autonomous flight, allowing the drone to understand not just where objects are, but their shape and relative position, crucial for advanced mapping and navigation.
Sonar and Ultrasonic Sensors
Similar in principle but operating with sound waves rather than light, sonar (Sound Navigation and Ranging) and ultrasonic sensors perform a form of ray casting particularly suited for short-range detection and specific environmental conditions. These sensors emit high-frequency sound pulses (the “rays”) and measure the time it takes for the echo to return. Like lidar, the time of flight directly correlates to the distance of an object.
While typically less precise and having a shorter range than lidar, sonar and ultrasonic sensors are incredibly robust in environments where optical sensors struggle, such as in fog, smoke, or very dusty conditions, or when dealing with highly reflective or transparent surfaces. For smaller drones, or for specific tasks like precision landing or ground proximity detection, these sound-based ray casting systems provide a reliable layer of environmental awareness, contributing to a multi-sensor fusion approach for comprehensive obstacle avoidance.
Depth Cameras and Structured Light

Depth cameras, encompassing technologies like stereo vision, structured light, and Time-of-Flight (ToF) cameras, offer another sophisticated method of environmental perception that aligns with ray casting principles.
- Stereo Vision cameras mimic human eyesight, using two cameras spaced apart to capture slightly different images of the same scene. By comparing the discrepancies between these two images (parallax), the drone’s processing unit can triangulate the distance to various points in the scene, effectively determining the “depth” of each pixel. While not emitting explicit “rays,” the calculation of depth for each point in the image is analogous to determining the intersection point of an imagined ray from the camera through that pixel.
- Structured Light systems project a known pattern of light (e.g., a grid or dots) onto a scene. A camera then captures the distorted pattern, and by analyzing how the pattern has been deformed by the surfaces of objects, the system can calculate a detailed depth map. Here, each point of projected light can be considered a “ray” that carries depth information back to the sensor.
- Time-of-Flight (ToF) cameras operate on a similar principle to lidar, but for every pixel simultaneously. They emit modulated light and measure the phase shift or intensity decay of the returning light for each pixel, calculating a full depth map in real-time. This provides a dense array of “rays” originating from the camera, each returning distance information.
These depth-sensing camera technologies provide rich, detailed spatial data, forming the basis for highly granular object detection, classification, and precise relative positioning, essential for intricate flight maneuvers and human-robot interaction tasks.
Obstacle Avoidance: Navigating Complex Airspaces with Ray-Casted Data
The primary, life-saving application of ray casting principles in drone flight technology is obstacle avoidance. By continuously generating and interpreting “ray” data from multiple sensors, drones can build a dynamic mental model of their environment, enabling them to detect, evaluate, and react to potential collisions in real-time.
The process typically involves:
- Data Acquisition: Sensors (Lidar, Sonar, Depth Cameras) constantly cast their “rays” to gather raw distance and depth information.
- Environmental Mapping: This raw data is fused and processed to construct a real-time 3D representation of the drone’s immediate surroundings. This map highlights obstacles, their shapes, and their distances from the drone.
- Collision Detection: Algorithms analyze the generated map to identify objects that pose a potential collision threat based on the drone’s current trajectory, speed, and predefined safety margins.
- Path Planning and Re-routing: Upon detecting an imminent obstacle, the drone’s flight control system, leveraging the environmental map, dynamically calculates an alternative, collision-free flight path. This could involve small adjustments, such as shifting horizontally or vertically, or more significant re-routing to bypass larger obstructions.
- Execution and Control: The calculated avoidance maneuver is translated into commands for the drone’s motors and control surfaces, executing the evasion in fractions of a second. This continuous loop of sensing, mapping, detecting, planning, and executing ensures that the drone can navigate complex and dynamic airspaces safely and autonomously.
Enhancing Autonomous Flight and Navigation
Beyond immediate obstacle avoidance, the principles of ray casting are integral to broader aspects of autonomous flight and advanced navigation capabilities.
Simultaneous Localization and Mapping (SLAM)
SLAM algorithms are crucial for drones operating in environments where GPS signals are unreliable or unavailable (e.g., indoors, under dense canopy). Ray-casting-derived sensor data, particularly from lidar and depth cameras, is a cornerstone of SLAM. As the drone moves, it uses the incoming “ray” information to simultaneously build a map of the unknown environment while also precisely tracking its own position within that newly created map. Each “ray” provides a piece of the puzzle, helping to resolve the drone’s location relative to detected features and incrementally extend the environmental map. This fusion of self-location and environment mapping is what truly unlocks sophisticated indoor and GPS-denied autonomous flight.
Precision Landing and Terrain Following
For tasks requiring high accuracy, ray-casting principles enable precision landing and terrain following. During landing, depth sensors can provide extremely accurate measurements of the distance to the ground and detect subtle changes in terrain, allowing the drone to adjust its descent for a soft, accurate touchdown, even on uneven surfaces or landing pads. For terrain following, sensors continuously map the contours of the ground below, allowing the drone to maintain a consistent, safe altitude above varied topography, essential for applications like pipeline inspection or precision agriculture over hilly terrain.

Challenges and Future Directions
Despite its immense utility, the application of ray casting in drone flight technology faces ongoing challenges. Computational demands are high, especially for real-time processing of vast point clouds or depth maps from multiple high-resolution sensors. Environmental factors like heavy rain, dense fog, or highly reflective surfaces can interfere with sensor performance.
The future of ray casting in flight technology points towards enhanced sensor fusion, combining the strengths of lidar, radar, ultrasonic, and vision-based systems to create a more robust and redundant environmental awareness. Advances in AI and machine learning will play a crucial role in interpreting complex sensor data more effectively, differentiating between benign and threatening objects, and predicting their movements. Furthermore, miniaturization and increased energy efficiency of these sensors will enable their deployment on smaller, more agile drones, pushing the boundaries of autonomous navigation and safety in an ever-expanding range of applications.