
In the rapidly evolving landscape of drone technology, where artificial intelligence, autonomous flight, and sophisticated remote sensing capabilities are becoming standard, the underlying software that orchestrates these marvels is paramount. At the heart of this software lies fundamental programming concepts, and among the most crucial is the “variable.” For anyone delving into drone development, understanding what a Python variable is, and how it functions, provides a foundational insight into the intelligence that powers modern UAVs. It’s not merely a theoretical construct; variables are the digital vessels carrying every piece of information a drone processes, from its current GPS coordinates to the instructions for an AI follow mode.

The Foundation of Drone Intelligence: Understanding Python Variables
Python, renowned for its readability and vast libraries, has emerged as a preferred language for developing complex drone applications, particularly within the Tech & Innovation domain. Before diving into its specific applications in drones, it’s essential to grasp the core concept of a variable itself.
What is a Variable?
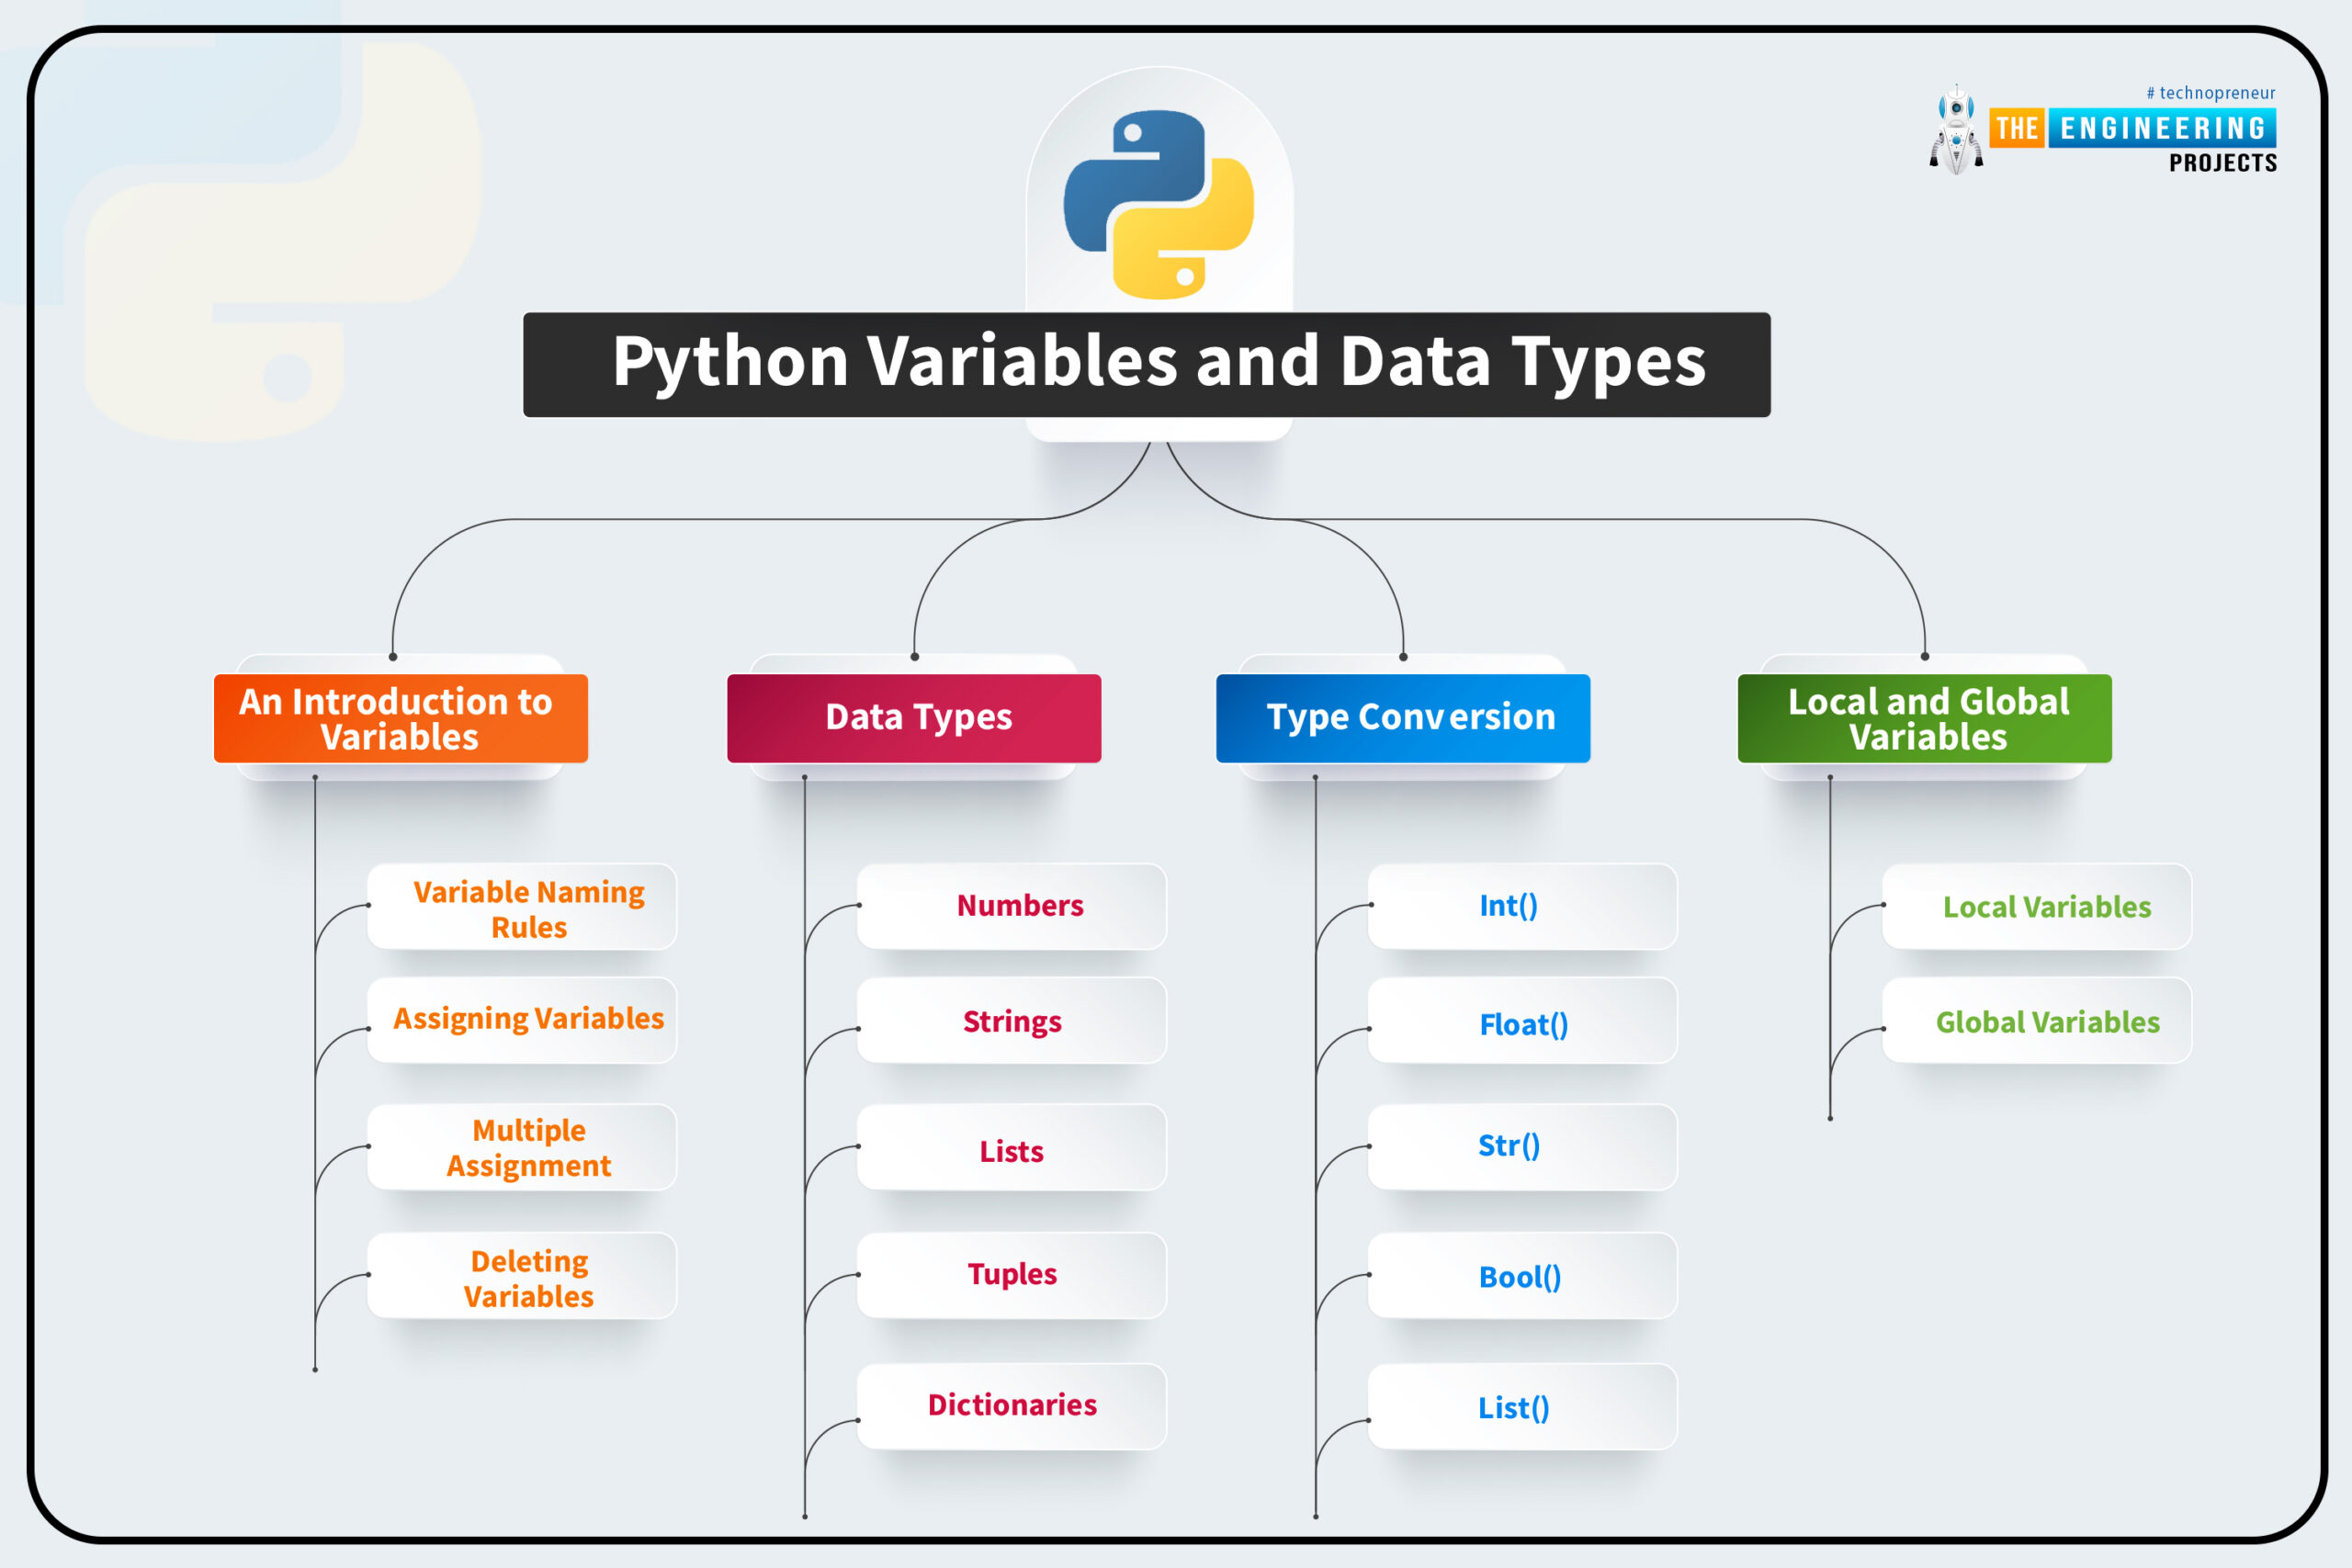
At its simplest, a variable in Python is a named storage location that holds a value. Think of it as a labeled box where you can put different kinds of information. This information could be a number (like a drone’s altitude), a piece of text (like the name of a mission), a true/false statement (like whether an obstacle is detected), or even a complex data structure representing a flight plan.
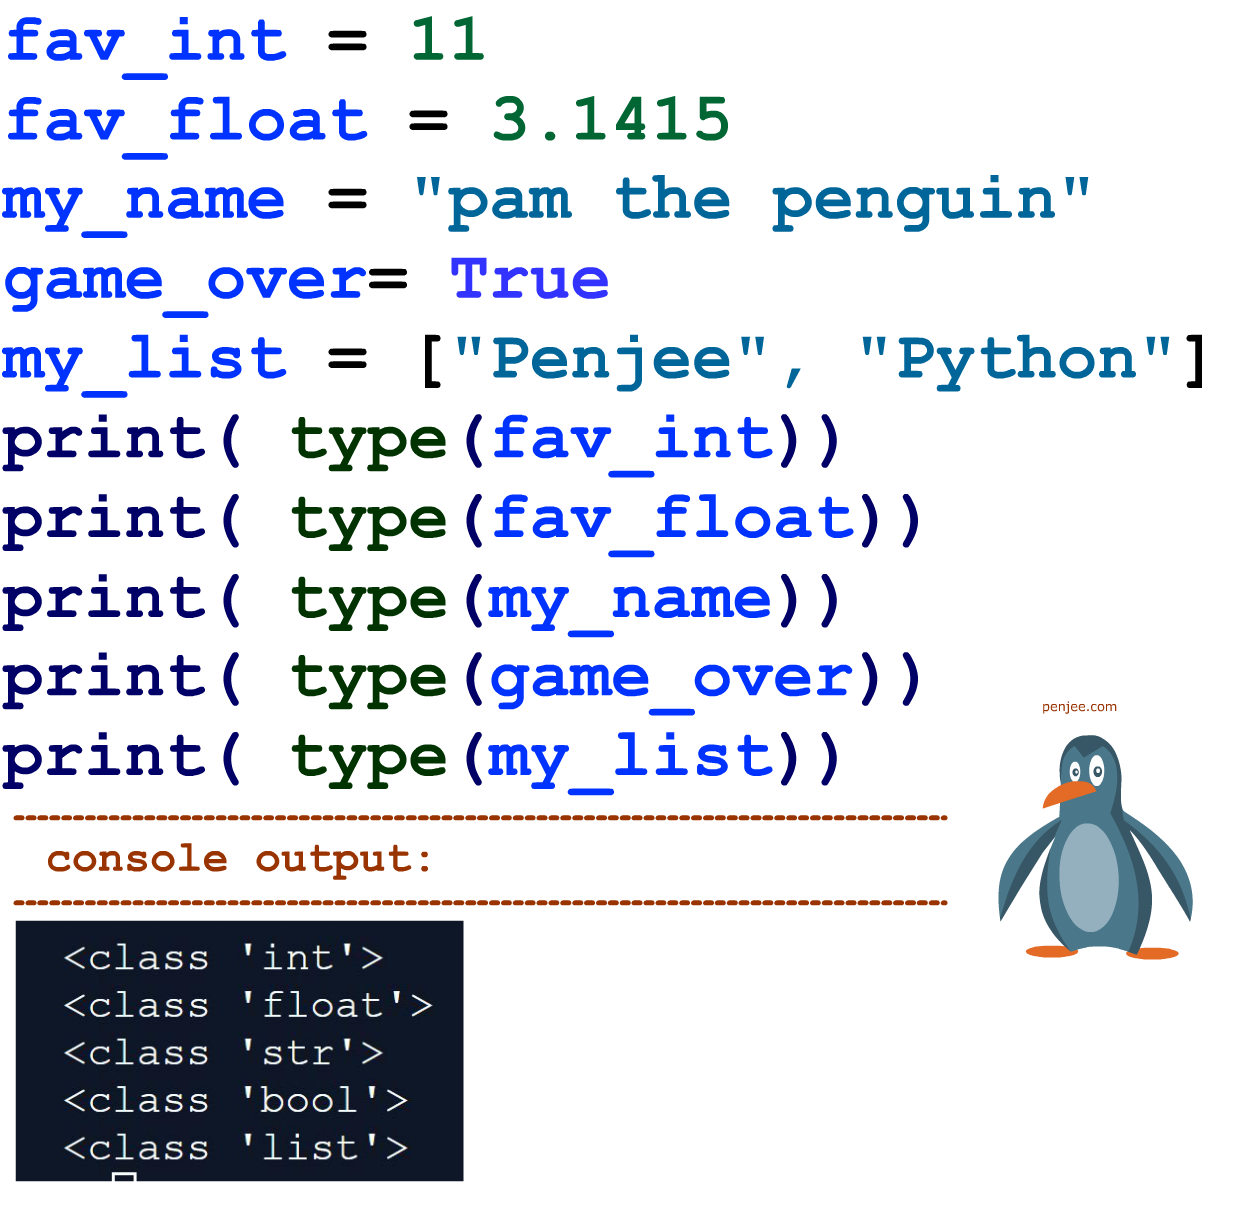
When you declare a variable in Python, you give it a name and assign it a value using the assignment operator (=). For example:
current_altitude = 50.0 # Stores a floating-point number
mission_status = "active" # Stores a string of text
obstacle_detected = False # Stores a boolean value (True/False)
gps_coordinates = (34.0522, -118.2437) # Stores a tuple of numbers
The beauty of variables is their mutability; the value they hold can be changed (or ‘varied’) throughout the execution of a program. This dynamic nature is precisely what makes them indispensable for controlling complex, real-time systems like drones. A drone’s altitude isn’t static; it changes constantly, and a variable is used to track that evolving value.
Why Python for Drone Tech?
Python’s suitability for drone innovation stems from several key attributes. Its simplicity allows developers to focus on algorithms and logic rather than intricate syntax. More importantly, Python boasts an extensive ecosystem of libraries and frameworks tailored for areas critical to drone tech:
- Data Science & Machine Learning: Libraries like NumPy, Pandas, TensorFlow, and PyTorch are vital for developing AI models for object recognition, predictive maintenance, and autonomous decision-making.
- Computer Vision: OpenCV integration allows for real-time image processing, crucial for navigation, obstacle avoidance, and visual inspections.
- Robotics & Control Systems: Frameworks like ROS (Robot Operating System) often integrate heavily with Python, providing tools for sensor fusion, path planning, and motor control.
- Networking & Communication: Python’s robust networking capabilities are essential for establishing communication between the drone, ground control stations, and cloud services.
In all these areas, variables serve as the conduits for data—be it sensor readings, model parameters, or network packets—making them the backbone of any intelligent drone system.
Variables at the Helm: Guiding Autonomous Flight
Autonomous flight, the pinnacle of modern drone technology, relies heavily on the continuous processing and manipulation of vast amounts of data. Variables are the unsung heroes, storing and updating every critical piece of information that guides a drone through the skies without human intervention.
Storing Navigational Data
A drone’s ability to navigate autonomously hinges on accurately knowing its position, velocity, and orientation. Python variables are used to store this critical navigational data:
latitude,longitude,altitude: These variables continuously hold the drone’s current geographical position, updated multiple times per second by GPS receivers.heading: Tracks the drone’s directional orientation, often derived from a compass or IMU (Inertial Measurement Unit).airspeed,groundspeed: Store velocity vectors, crucial for path planning and wind compensation.target_waypoint: A variable that might hold the coordinates of the next point in a predefined flight path. As the drone reaches one waypoint, this variable updates to the next.
These variables aren’t just static storage; they are actively read by the flight controller’s algorithms to compare current state against desired state, triggering corrective actions when deviations occur.
Processing Sensor Inputs
Drones are equipped with a suite of sensors—accelerometers, gyroscopes, magnetometers, barometers, LiDAR, ultrasonic, and vision sensors. The raw data from each of these is channeled into Python variables for processing.
accelerometer_x,accelerometer_y,accelerometer_z: Variables holding raw acceleration values, used to detect changes in velocity.gyro_pitch,gyro_roll,gyro_yaw: Store rotational rates, fundamental for maintaining stable flight.lidar_distance: A variable that might hold the distance to the nearest obstacle detected by a LiDAR sensor, updated in real-time.camera_feed: While not a simple number, this variable could reference a stream of image data, which is then processed by computer vision algorithms to identify objects or features.
These raw inputs are often processed through complex filters and algorithms (like Kalman filters) where intermediate results are also stored in variables, eventually contributing to a refined understanding of the drone’s environment and state.
Dynamic Flight Parameter Adjustment
Autonomous missions often require drones to adapt to changing conditions. Variables facilitate this dynamic adjustment:
battery_level: Tracks the remaining power, influencing decisions about returning to home or finding a charging station.wind_speed,wind_direction: Environmental variables that can be fed into the flight controller to adjust power and attitude for stable flight.payload_weight: If a drone is equipped with dynamic payload capabilities, this variable might adjust flight performance parameters accordingly.mission_mode: A variable that dictates the drone’s current operational mode (e.g., “loiter,” “follow_path,” “land”), switching between modes based on mission progress or external commands.
Through these dynamic variables, drones can exhibit true adaptability, ensuring mission success even in unpredictable circumstances.
Fueling AI and Machine Learning in Drones
The cutting edge of drone technology—AI follow modes, intelligent obstacle avoidance, real-time object detection, and predictive analytics—is entirely built upon machine learning models. Python variables are fundamental to every stage of this AI pipeline, from data preparation to model deployment and inference.
Training Data and Model Parameters
Developing an AI model begins with data. Variables are used extensively to store and manipulate this data during the training phase:
training_images: Variables holding arrays of pixel data from thousands of images used to teach a drone to recognize objects (e.g., people, vehicles, specific agricultural pests).labels: Corresponding variables that store the correct classification for each training image.learning_rate,epochs: Hyperparameters of an AI model, stored in variables, which dictate how the model learns from the data.weights,biases: The internal parameters of a neural network, represented by large arrays or matrices (which are essentially complex variables), that are updated during training to optimize the model’s performance.
Without variables, the intricate process of feeding data to a model, adjusting its internal logic, and evaluating its performance would be impossible.
Real-time Object Detection and Classification
Once an AI model is trained, it’s deployed on the drone (or a powerful edge device connected to it) to perform real-time inference. Here, variables process live sensor data to make intelligent decisions:
current_frame: A variable that continuously receives new image frames from the drone’s camera.detected_objects: After the AI model processescurrent_frame, this variable might store a list of identified objects, their bounding box coordinates, and their confidence scores. For example,[{'type': 'person', 'confidence': 0.95, 'bbox': (x1, y1, x2, y2)}].threat_level: A variable updated based ondetected_objectsto determine if an identified object poses a threat, influencing the drone’s evasive maneuvers.
These variables enable a drone to “see” and “understand” its environment, reacting intelligently to what it perceives.
Adaptive Behavior and AI Follow Modes
AI-driven behaviors, such as following a moving subject while maintaining a safe distance, are orchestrated by variables that track targets and manage drone movements.
target_position: Continuously updated variable holding the coordinates of the person or object being followed.follow_distance: A configurable variable dictating the desired separation from the target.tracking_state: A boolean or string variable indicating whether the AI is currently locked onto a target.avoidance_vector: If an obstacle is detected while following, this variable might store a temporary flight adjustment to steer clear.
The interplay of these variables allows for smooth, adaptive, and intelligent interactions with the environment, transcending pre-programmed flight paths.
Data-Centric Operations: Mapping, Sensing, and Beyond
Beyond flight control and AI, drones are powerful platforms for data collection and analysis. From creating detailed maps to monitoring environmental changes, Python variables are critical for managing, processing, and transmitting the vast datasets generated by these operations.
Managing Geospatial Data
Drones equipped with high-resolution cameras and LiDAR sensors are invaluable for mapping and surveying. The data collected is inherently geospatial, and variables are essential for its organization.
image_metadata: Variables storing geographic tags (geotags) for each captured image, including latitude, longitude, altitude, and timestamp.point_cloud_data: Complex variables (often arrays or data structures) that hold millions of 3D points representing the terrain or structures being mapped, each point having X, Y, Z coordinates and possibly color information.tile_boundaries: Variables defining the geographical extent of individual map tiles, used for efficient data processing and rendering.
These variables form the digital backbone of photogrammetry and remote sensing applications, enabling the reconstruction of 3D models and detailed maps.
Environmental Monitoring and Remote Sensing
Drones are increasingly deployed for tasks like agricultural monitoring, wildlife tracking, and infrastructure inspection. Variables facilitate the collection and analysis of specific sensor data relevant to these fields.
ndvi_value: A variable holding the Normalized Difference Vegetation Index for a specific area, derived from multispectral sensor data to assess plant health.thermal_signature: Stores temperature readings from thermal cameras, used for detecting anomalies in industrial equipment or tracking animal heat signatures.gas_concentration: If equipped with gas sensors, variables storing readings of specific gas levels (e.g., methane, CO2) for environmental hazard detection.
By continuously updating these variables with sensor inputs, drones provide unprecedented insights into complex environments, enabling proactive management and rapid response.
Fleet Management and Telemetry
For organizations operating multiple drones, efficient fleet management and real-time telemetry are crucial. Variables play a key role in centralizing this information.
drone_id: A unique identifier for each drone in a fleet.fleet_status: A dictionary or list of variables, where each entry represents a drone and its current operational status (e.g.,{'drone_001': 'flying', 'drone_002': 'charging'}).telemetry_log: A complex variable storing a continuous stream of flight data (GPS, battery, speed, altitude) from all active drones for monitoring and post-flight analysis.alert_thresholds: Variables defining limits for critical parameters (e.g., minimum battery, maximum wind speed) that, if exceeded, trigger an alert.
These variables enable operators to have a comprehensive overview of their drone assets, optimizing deployment, ensuring safety, and responding promptly to any operational issues.
The Developer’s Toolkit: Python Variables in Practice
For developers building the next generation of drone applications, a solid grasp of Python variables is more than just academic knowledge; it’s a practical necessity that underpins effective code writing, debugging, and system integration.
Debugging and Iteration
Variables are invaluable tools during the development and debugging phases. By inspecting the values held within variables at different points in a program, developers can trace the flow of data, identify where unexpected values are introduced, and pinpoint errors. Print statements, breakpoints, and integrated debugger tools all leverage the ability to view and manipulate variable contents. Rapid iteration—making small changes and testing their impact—is significantly streamlined when developers can quickly modify variable values to simulate different scenarios (e.g., changing a wind_speed variable to test how the drone compensates).
Scalability and System Integration
As drone systems grow in complexity, encompassing multiple sensors, AI models, and communication protocols, the structured use of variables becomes critical for managing data flow between different modules. Functions and classes often rely on variables to pass data between them, ensuring that the right information reaches the right component at the right time. For instance, a variable containing a target_object detected by a computer vision module can be passed to a flight control module that then updates target_waypoint variables to initiate a follow sequence. This modularity, heavily dependent on variables, allows for scalable architectures where new features can be added without disrupting existing functionalities, paving the way for increasingly sophisticated and integrated drone solutions.