
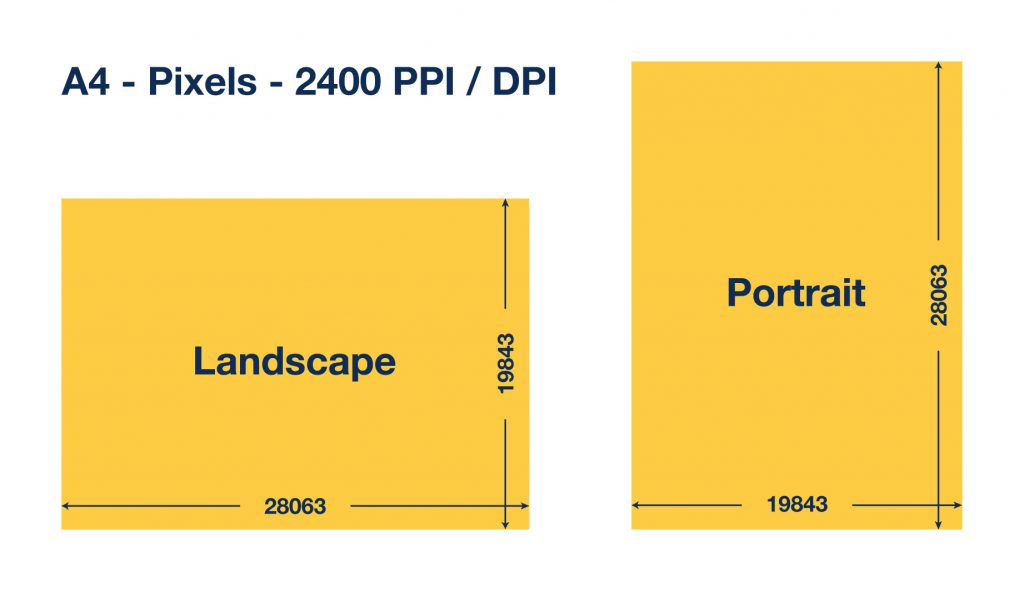
The term “px size”, often abbreviated from “pixel size,” is a fundamental concept in the realm of digital imaging and cameras, particularly critical for understanding the performance and capabilities of the sophisticated camera systems integrated into modern drones. At its core, a pixel (picture element) is the smallest individual point of information in a raster image or on a digital sensor. While “px size” can sometimes refer to the dimensions of an image in pixels (e.g., 1920×1080 px), within the context of cameras and imaging, it most frequently denotes the physical dimension of an individual light-sensitive element on a camera’s sensor. This physical size, typically measured in micrometers (µm), profoundly influences a camera’s ability to capture light, resolve detail, and manage noise, making it a cornerstone for evaluating image quality across various aerial applications.
The Fundamental Unit of Digital Imagery
To truly grasp the significance of px size, one must first understand its role as the building block of any digital image. Unlike traditional film, which uses chemical reactions across a continuous emulsion, digital sensors convert light into discrete electrical signals using millions of tiny photosites—each corresponding to a single pixel.
Pixels in Sensor Technology
A camera sensor is a grid of these photosites, often made of silicon. When light photons strike a photosite, they are converted into an electrical charge. The amount of charge collected is proportional to the intensity of the light. This charge is then read out and converted into a digital value, representing the brightness and color information for that specific point in the image. The physical dimensions of these individual photosites are what we refer to as pixel size. For instance, a sensor might have pixels that are 2.4µm x 2.4µm or 3.76µm x 3.76µm.
The size of these individual pixels has direct implications for their light-gathering capability. A larger pixel has a greater surface area to collect photons. This is analogous to having a larger bucket to catch raindrops; a bigger bucket collects more water in the same amount of time. Consequently, cameras with larger individual pixels generally perform better in low-light conditions, as each pixel can gather more light before the signal is amplified, thus reducing the relative impact of electronic noise. Conversely, smaller pixels, while allowing for more pixels on a given sensor size, can struggle in dim environments, producing noisier images.
Defining Resolution and Image Detail
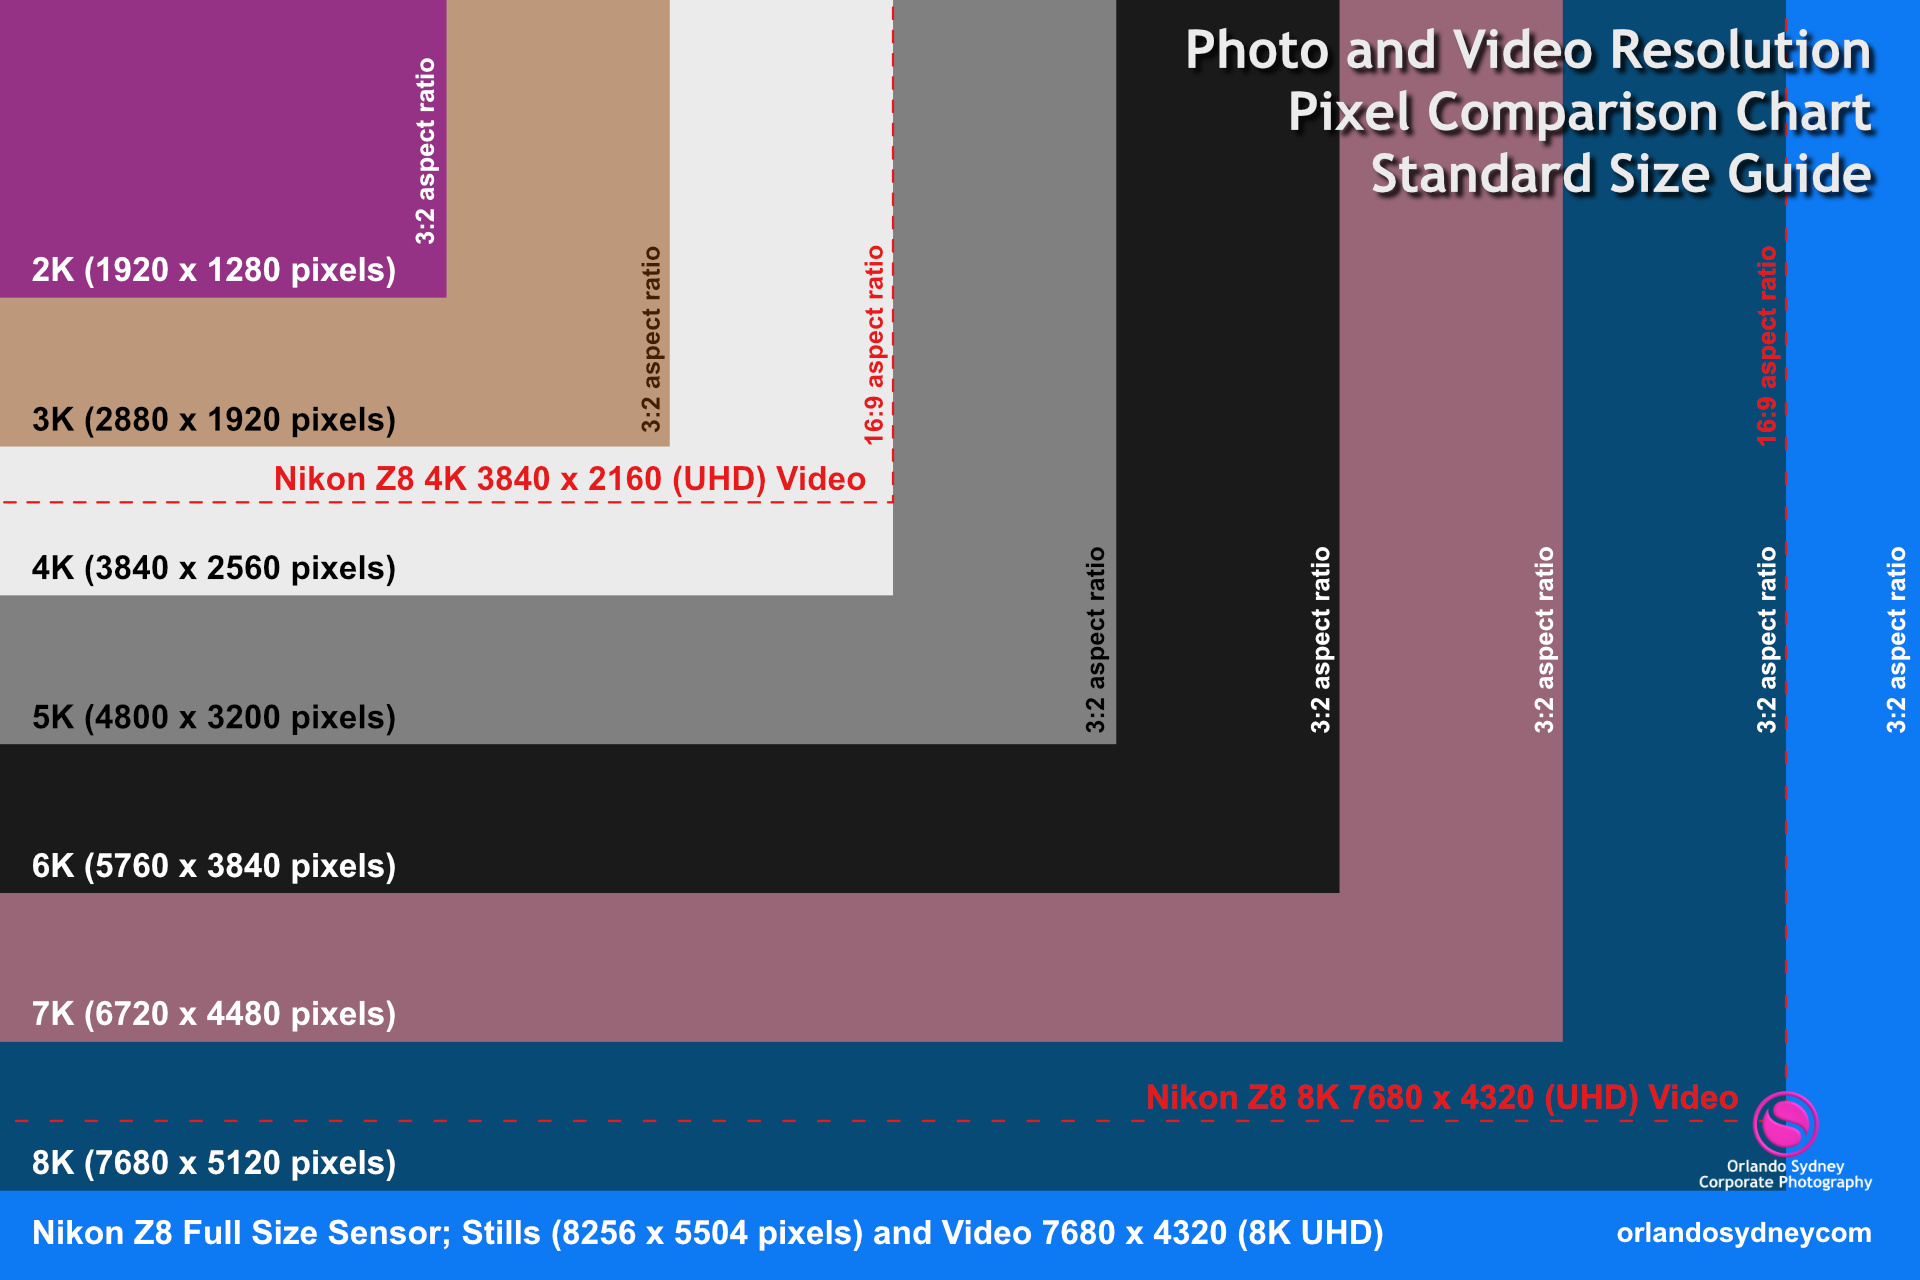
Resolution, often expressed in megapixels (MP), refers to the total number of pixels on a sensor (e.g., 12MP, 20MP, 48MP). While it’s tempting to equate higher megapixels directly with better image quality, the physical px size plays a crucial moderating role. A sensor with many small pixels might offer a very high numerical resolution, meaning it can capture a vast amount of discrete data points. However, if those pixels are too small, they may not gather enough light efficiently, leading to poor signal-to-noise ratio (SNR) and a loss of effective detail, especially in challenging lighting.
On the other hand, a sensor with fewer but larger pixels might yield a lower megapixel count but can produce images with superior clarity, color accuracy, and less noise, particularly under suboptimal lighting. This trade-off between the sheer number of pixels (resolution) and the quality of light collected by each pixel (dictated by px size) is a fundamental consideration in camera design for drone applications. For example, a 20MP camera with 2.4µm pixels on a smaller sensor might theoretically capture more detail than a 12MP camera with 3.76µm pixels on a slightly larger sensor, but the 12MP camera would likely outperform it in dynamic range and low-light noise.
Understanding Pixel Dimensions in Drone Cameras
The unique operating environment of drones, from high altitudes to varying light conditions and rapid movement, makes the choice of camera sensor and its associated pixel size particularly critical. Drone cameras are often constrained by size, weight, and power consumption, which inevitably influences sensor dimensions and pixel design.
Sensor Size vs. Pixel Size
It’s vital to distinguish between sensor size and pixel size, as they are related but distinct concepts. Sensor size refers to the overall physical dimensions of the image sensor itself (e.g., 1/2.3-inch, 1-inch, Four Thirds). A larger sensor can physically accommodate more pixels or larger pixels than a smaller sensor. For example, a 1-inch sensor (with a diagonal of about 16mm) can typically host larger pixels or more pixels than a 1/2.3-inch sensor (with a diagonal of about 7.7mm), given the same generation of sensor technology.
When designing a drone camera, manufacturers make strategic decisions about the optimal balance. A smaller sensor with tiny pixels might be chosen for compact, lightweight drones where maximum resolution is desired under ideal lighting conditions (e.g., for mapping applications where detail matters). Conversely, a larger sensor with larger pixels might be selected for professional cinematography drones where low-light performance, dynamic range, and image fidelity are paramount, even if it means a heavier, more expensive camera system.
Impact on Low-Light Performance and Dynamic Range
One of the most significant impacts of px size on drone camera performance is its effect on low-light capability and dynamic range. As discussed, larger pixels are more efficient light gatherers. This means that in dim environments—like flying a drone at dusk, dawn, or indoors—cameras with larger pixels can capture a stronger signal relative to the electronic noise inherent in the sensor. This results in cleaner images with less visible grain or “noise.”
Dynamic range refers to the camera’s ability to capture detail in both the brightest highlights and the darkest shadows of a scene simultaneously. Larger pixels, by collecting more light, generally have a higher “well capacity”—the maximum amount of electrical charge a photosite can hold before it saturates. A higher well capacity translates to a greater ability to distinguish between very bright and very dark areas, resulting in images with richer tonal gradations and fewer blown-out highlights or crushed shadows, which is highly beneficial for aerial photography that often encounters vast contrasts between sky and ground.
Megapixels: Quantity vs. Quality
The megapixel count has long been a primary marketing metric for cameras. However, for drone operators, understanding the role of px size reveals that more megapixels do not automatically equate to better image quality. A 48MP camera on a tiny sensor with very small pixels might produce images that look highly detailed on paper, but when viewed closely, they may exhibit significant noise, especially in shadows, and a reduced dynamic range compared to a 20MP camera with larger pixels on a bigger sensor.
For applications like detailed inspection or precision mapping, a higher megapixel count can be advantageous for capturing fine details over large areas. However, for cinematic aerial filmmaking, where aesthetic quality, clean shadows, and smooth gradations are paramount, a camera with fewer but larger pixels (and often a larger overall sensor) might be preferred, even if it means sacrificing some raw numerical resolution. The “quality” derived from larger pixels often manifests as superior color rendition, better noise performance at higher ISOs, and greater flexibility in post-production.
Px Size and its Role in Image Quality for Aerial Applications
Beyond the basic principles, the specific px size on a drone’s camera sensor directly influences critical aspects of image quality such as sharpness, noise, and even how well certain imaging artifacts are controlled.
Sharpness, Noise, and Aliasing
Sharpness: While lens quality plays a huge role, pixel size also contributes to perceived sharpness. If pixels are too small relative to the lens’s resolving power, or if they are too small to gather sufficient light without significant noise, the resulting image can lack true sharpness, appearing soft or mushy when enlarged. The camera’s internal processing often attempts to compensate for noise by smoothing the image, which can further reduce fine detail and perceived sharpness.
Noise: The most obvious impact of small pixels is increased noise, especially in low light or high ISO settings. When individual pixels collect less light, the electronic signal they produce is weaker. To make the image visible, this signal must be amplified, which also amplifies any random electronic fluctuations (noise). This manifests as grain or speckles in the image, degrading overall quality. Drones often operate in variable lighting conditions, making robust noise performance (favored by larger pixels) essential.
Aliasing: This is an imaging artifact that occurs when the spatial frequency of the detail in a scene exceeds the sensor’s ability to resolve it cleanly. It often appears as jagged edges, moiré patterns (strange color patterns), or false colors in finely textured areas. While anti-aliasing filters are used, smaller pixels are inherently more susceptible to aliasing because they are attempting to resolve finer details, and if the input pattern is too close to the pixel grid’s frequency, misinterpretation can occur. Larger pixels, by nature, “sample” a slightly broader area, which can sometimes mitigate certain types of aliasing, though not always eliminate it entirely.
The Nyquist-Shannon Theorem in Drone Photography
The Nyquist-Shannon sampling theorem, a cornerstone of digital signal processing, has direct relevance to pixel size in drone photography. In simplified terms, it states that to accurately reconstruct a signal, the sampling rate (in this case, the pixel density) must be at least twice the highest frequency present in the original signal. In practical terms for cameras, this means that to resolve a certain level of detail in an image without aliasing, the pixels must be small enough and numerous enough to “sample” that detail sufficiently.
For drone mapping or inspection, where resolving fine ground detail is critical, this theorem guides sensor selection. If you need to identify objects with a ground sampling distance (GSD) of 1cm/pixel (meaning each pixel represents 1cm on the ground), the sensor’s individual pixels and the lens’s resolving power must be able to distinguish features smaller than 1cm to accurately render them. This often pushes towards higher megapixel counts and, consequently, smaller pixels to achieve the necessary spatial resolution. However, the balance with noise and dynamic range remains a constant challenge.
Optimizing for Specific Imaging Tasks (e.g., Mapping vs. Cinematography)
The understanding of px size allows drone operators and manufacturers to optimize camera choices for specific aerial imaging tasks:
- Aerial Mapping and Surveying: These applications prioritize high spatial resolution to create detailed orthomosaics, 3D models, and point clouds. Here, a higher megapixel count, often achieved with smaller pixels on a relatively large sensor (or a smaller sensor if lightweight is paramount), is typically favored to capture immense detail over vast areas. The trade-off in low-light performance is often acceptable as these operations are usually conducted in bright daylight.
- Cinematic Aerial Filmmaking: For stunning cinematic shots, dynamic range, color depth, and low-noise performance are paramount. Filmmakers often prefer cameras with larger sensors and larger individual pixels (even if it means a lower megapixel count) to achieve a “cleaner” image, better performance in varied lighting, and a more pleasing aesthetic with smooth transitions and richer tones. The ability to shoot at higher ISOs without excessive noise allows for greater creative flexibility.
- Inspection and Surveillance: Depending on the specific requirements, these tasks might lean towards high resolution for identifying tiny defects or larger pixels for clarity in challenging industrial environments with poor lighting.
Navigating Px Size in Advanced Imaging Systems
The concept of px size extends beyond standard visible light cameras, playing an equally vital role in specialized drone imaging technologies that are increasingly prevalent.
Thermal Imaging and Pixel Density
Thermal cameras, which detect infrared radiation rather than visible light, also rely on an array of sensor elements (microbolometers) that effectively act as “thermal pixels.” The size of these thermal pixels (often referred to as pixel pitch) is a critical specification. Larger thermal pixels can detect smaller temperature differences more sensitively, leading to higher thermal resolution and better image quality in terms of distinguishing objects from their background. However, larger pixels also mean a larger sensor overall for a given resolution, increasing cost and size. For applications like search and rescue, industrial inspection, or security, the pixel pitch of the thermal sensor directly impacts the ability to discern heat signatures from a distance. A camera with a smaller pixel pitch (e.g., 12µm vs. 17µm) can pack more “thermal pixels” into a given sensor area, potentially offering higher resolution, but might require more advanced calibration to maintain thermal sensitivity.
Multispectral and Hyperspectral Sensors
Drone-mounted multispectral and hyperspectral cameras are crucial for agriculture, environmental monitoring, and geology. These systems capture images across specific narrow bands of the electromagnetic spectrum, providing data invisible to the human eye. Each pixel in these sensors records not just color (like RGB) but intensity across multiple spectral bands. The physical px size of these detectors dictates the spatial resolution of the spectral data. For precision agriculture, for example, having adequately sized pixels ensures that individual plants or small areas of crops can be analyzed for health, water stress, or nutrient deficiencies, enabling targeted intervention. The trade-off between the number of spectral bands, spatial resolution (driven by pixel size), and temporal resolution is a complex balance for these specialized drone payloads.

Future Trends: Computational Imaging and Pixel Binning
As sensor technology continues to evolve, new techniques are emerging that manipulate pixel data to overcome traditional limitations. Pixel binning is one such technique, where data from multiple adjacent pixels (e.g., 2×2 or 4×4) are combined into a single, larger “super-pixel” during image capture. This effectively simulates a larger pixel, increasing light sensitivity and reducing noise, particularly useful in low-light conditions. While it reduces the effective resolution, it can drastically improve image quality. Many modern drone cameras, especially those with high megapixel counts on smaller sensors, employ pixel binning for video recording or specific photo modes.
Computational imaging represents a broader trend where advanced algorithms and processing power are used to extract more information from sensor data than traditionally possible. This includes techniques like multi-frame noise reduction, HDR (High Dynamic Range) stitching, and super-resolution, where multiple slightly shifted images are combined to synthesize a higher-resolution image than the sensor’s native pixel count. These advancements often aim to mitigate the inherent limitations of small pixels or to enhance the capabilities of larger pixels, continually pushing the boundaries of what’s achievable with drone-mounted cameras. The interplay between physical pixel size and intelligent computational processing will define the next generation of aerial imaging systems.