
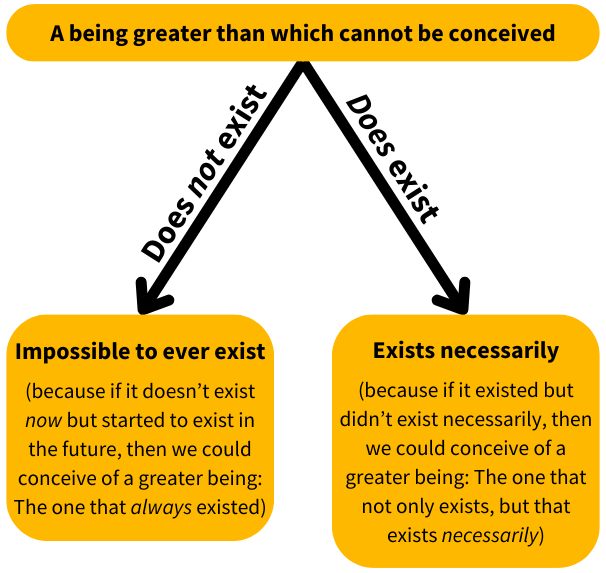
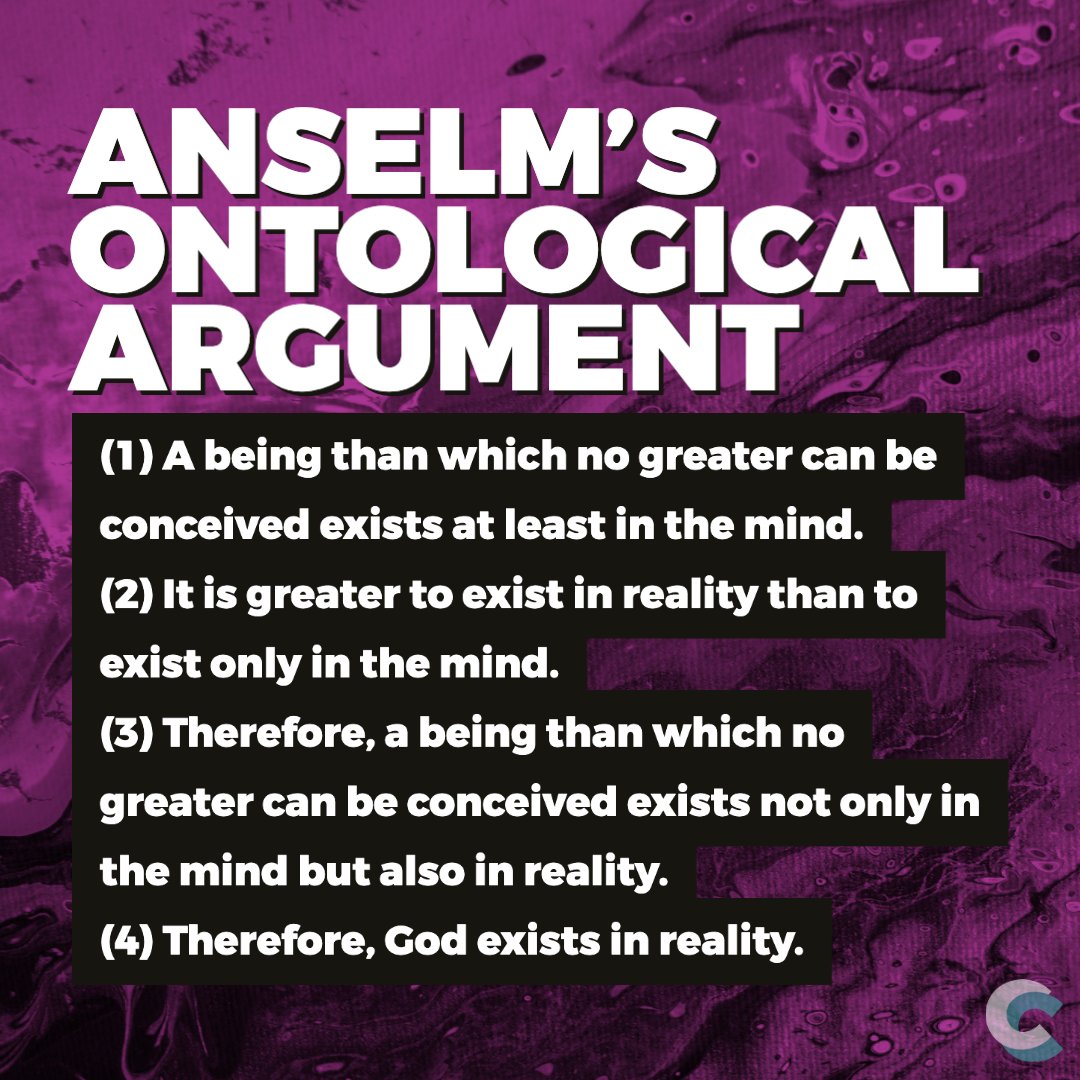
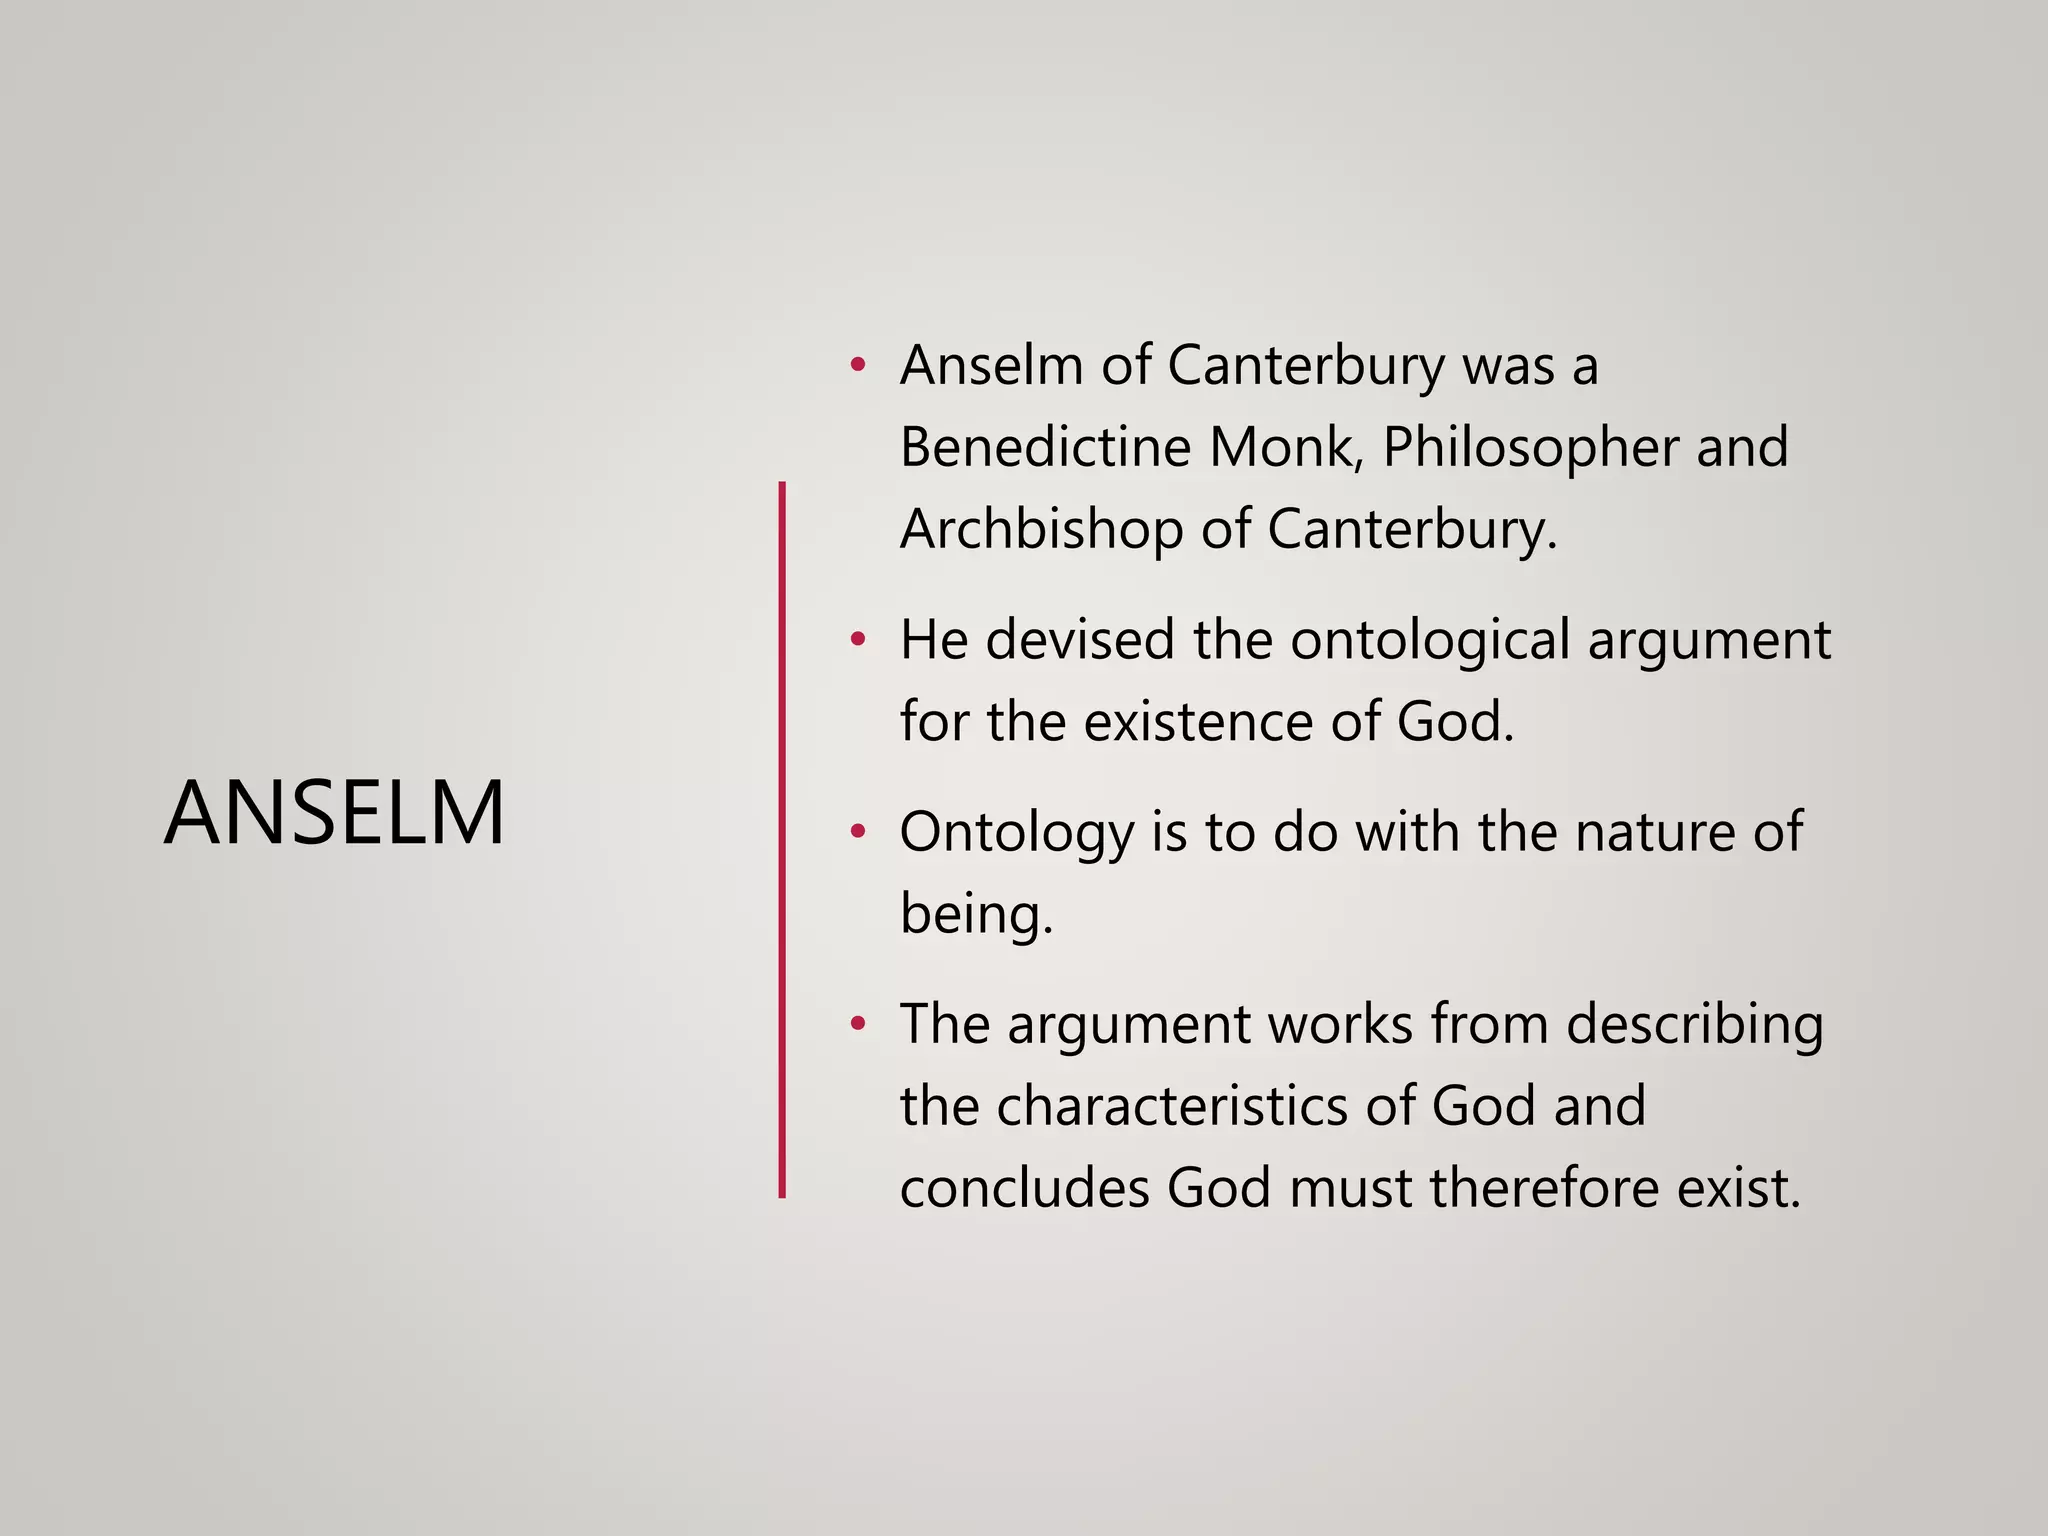
The ontological argument, a cornerstone of philosophical inquiry, traditionally posits the existence of God based on conceptual analysis alone. Originating with St. Anselm of Canterbury in the 11th century, it attempts to demonstrate that the very concept of God, understood as “that than which no greater can be conceived,” logically necessitates God’s existence. The core premise hinges on the idea that existence in reality is a “perfection” or a “great-making property.” If one can conceive of a being than which no greater can be conceived, and if that being did not exist in reality, then a greater being could be conceived—namely, one that does exist in reality. This creates a contradiction, thus concluding that the greatest conceivable being must exist.
While deeply rooted in metaphysics and theology, the spirit of the ontological argument—its method of reasoning about fundamental existence, necessary properties, and ultimate perfection—finds fascinating, albeit metaphorical, parallels in the cutting-edge discussions surrounding Tech & Innovation. In the realm of advanced drone technology, the pursuit of ultimate autonomy, unerring precision, and indispensable utility often involves a form of “ontological” reasoning: arguing for the inherent necessity and supreme capabilities of these evolving systems based on their conceptual design and functional imperatives.
Ontological Echoes in Autonomous Flight
The development of autonomous flight systems for drones represents a continuous quest for a “perfect” operational state, a system so robust and capable that its non-existence would imply a less optimal reality for many applications. This aspiration mirrors the “greatest conceivable being” tenet of the traditional ontological argument, translated into the domain of engineering and artificial intelligence.
The Argument for Necessary Autonomy
Consider the argument for truly autonomous drones. In many critical applications—such as inspecting hazardous infrastructure, delivering essential supplies to remote or disaster-stricken areas, or conducting large-scale environmental monitoring—human piloted flight introduces inherent limitations. These include operator fatigue, bandwidth constraints for remote control, susceptibility to jamming, and the sheer logistical complexity of managing fleets of human-controlled vehicles. From this perspective, the concept of a drone that can plan its own missions, execute them without constant human intervention, adapt to dynamic environments, and return safely, presents itself as not merely desirable, but conceptually necessary for these tasks to be performed at their most effective and efficient level.
An “ontological argument” for necessary autonomy would contend that a drone system without true autonomy for these specific, demanding scenarios is an inferior concept. The truly “greatest conceivable” drone system for such applications must possess full autonomy because the absence of this property would inherently make it less capable, less reliable, and therefore, “less great.” The very definition of optimized drone operations in these contexts conceptually entails self-sufficiency, thus logically compelling the development and existence of robust autonomous capabilities. This is not about the drone existing in a metaphysical sense, but about the concept of an optimal drone system necessarily including autonomy as an inherent, perfection-making attribute.
AI’s Pursuit of Perfection in Navigation
Furthering this parallel, the AI algorithms governing drone navigation systems are constantly striving towards a state of “perfection.” Systems are designed to minimize errors, optimize flight paths, conserve energy, avoid obstacles with absolute certainty, and adapt to unforeseen circumstances with seamless fluidity. When an AI-powered drone executes a complex mission—navigating through dense urban canyons, maintaining precise altitude over undulating terrain, or intercepting a fast-moving target—it is performing an intricate dance of sensors, processors, and actuators that, in its ideal form, achieves a level of precision and responsiveness beyond human capacity.
The “ontological argument” here is embedded in the iterative development cycle: each generation of navigation AI aims to be “that than which no greater [navigation system] can be conceived.” If a current system has a flaw, a more perfect system (one without that flaw) is conceivable. This relentless pursuit suggests an implicit belief that an ultimate, flawless navigation AI must exist as a conceptual ideal, driving engineers to bring it into reality. This ideal state of navigation perfection, characterized by zero-error pathfinding, instant obstacle avoidance, and optimal energy use, becomes the conceptual ‘greatest’ form, and its inherent conceptual superiority compels its eventual realization in the physical world of drone technology.
Mapping, Sensing, and the Essence of Data
The capabilities of modern drones extend far beyond mere flight; they are sophisticated mobile data collection platforms, transforming how we understand and interact with our physical environment. Remote sensing and mapping technologies embody another facet of this conceptual “ontological” pursuit, focused on the inherent value and necessary comprehensiveness of spatial data.
The Inherent Value of Comprehensive Sensing
Consider the “argument” for the necessary existence of multi-spectral, hyperspectral, LiDAR, and thermal imaging sensors on advanced mapping drones. For applications like precision agriculture, geological surveying, or urban planning, a single RGB camera provides only a fraction of the necessary information. A truly comprehensive understanding of crop health, mineral deposits, structural integrity, or thermal anomalies requires data across multiple electromagnetic spectra.
The “ontological argument” here posits that a truly perfect drone mapping solution must inherently integrate a diverse suite of sensors. If a drone platform merely provides visual data, it is a “lesser” mapping system, as a more capable one (with additional sensing modalities) is easily conceivable. The very concept of “comprehensive mapping” for many industrial and scientific applications logically necessitates the inclusion of these advanced sensors, making their presence a defining characteristic of the “greatest conceivable” mapping drone. Their absence would denote an incompleteness, an imperfection, in the conceptual ideal of a fully capable remote sensing platform.
Predictive Analytics as an Existential Imperative
The data collected by drones isn’t static; it fuels sophisticated analytical models, particularly in fields like predictive maintenance, environmental forecasting, and resource management. Here, the “ontological argument” shifts to the inherent necessity of extracting actionable intelligence and foresight from vast datasets. The conceptual ideal for a drone-enabled data ecosystem isn’t just to collect data, but to transform it into predictive insights that enable proactive decision-making.
If a drone system collects vast amounts of data but lacks the AI-driven analytics to identify patterns, predict failures, or forecast environmental changes, it is a “lesser” system. A “greater” system, one that offers not just raw information but also intelligent, predictive outputs, is readily conceivable. Therefore, for drone technology to achieve its “greatest conceivable” form in applications demanding foresight, the integration of advanced predictive analytics capabilities becomes an inherent and necessary property. Its absence would imply a conceptual deficiency, hindering the system from reaching its full potential as an indispensable tool for future-oriented decision-making.
The Future of Drone Intelligence: An Ontological Quest
As drone technology continues to evolve, the underlying pursuit remains consistent: the realization of systems that conceptually embody the highest possible levels of autonomy, capability, and utility. From swarm intelligence that enables collective, adaptive behavior beyond the sum of individual units, to self-healing software architectures that maintain operational integrity in the face of errors, developers are perpetually striving to actualize the “greatest conceivable” drone system.
This ongoing quest reflects an implicit ontological framework, where the conceptual perfection of a drone system—defined by its robustness, intelligence, efficiency, and adaptability—serves as the driving force for its development. The argument is not that these technologies must exist because we can conceive of them, but rather that the very concept of an optimal, indispensable, and truly transformative drone system inherently includes these advanced attributes. To conceive of a truly “great” drone without autonomous flight, comprehensive sensing, or predictive intelligence would be a contradiction, just as, for Anselm, conceiving of a greatest being without existence was a logical impossibility. In the rapidly advancing world of Tech & Innovation, the “ontological argument” serves not as a proof of a deity, but as a guiding principle for engineering the future.