
In the rapidly evolving landscape of drone technology and innovation, the seemingly simple concepts of “mean” and “meaning” take on profound significance. Beyond their linguistic interpretations, these terms underpin the very fabric of how advanced drones operate, process data, and generate actionable insights. Within the realm of AI follow modes, autonomous flight, sophisticated mapping, and remote sensing, understanding the role of statistical averages (the “mean”) and the subsequent extraction of actionable intelligence (the “meaning”) is paramount to unlocking the full potential of unmanned aerial systems. This article delves into how these concepts are not just abstract ideas but critical operational components driving the next generation of drone capabilities.
The Foundational Role of Statistical Averages in Drone Intelligence
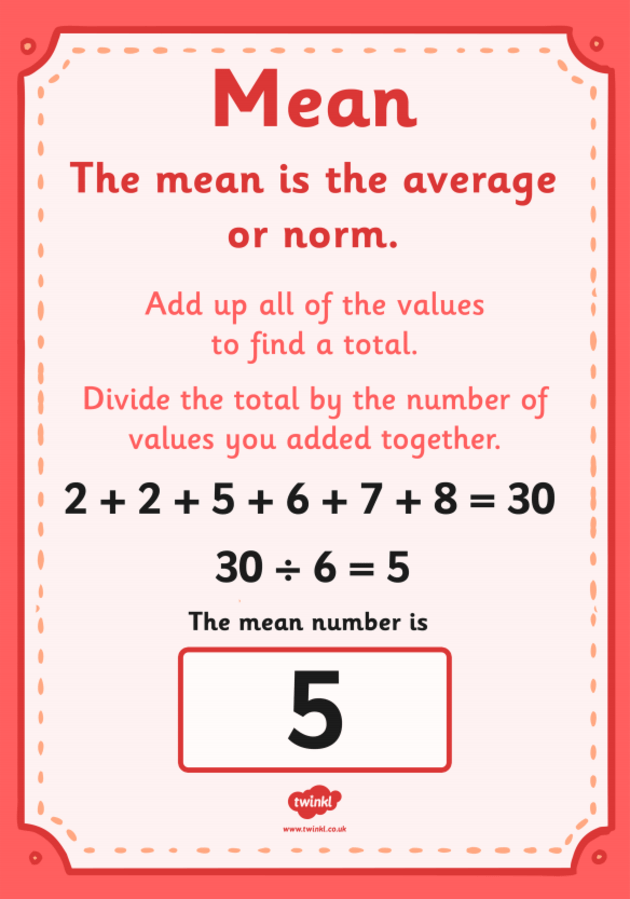
At the heart of any intelligent drone system lies the ability to perceive its environment accurately and consistently. This perception is built upon a deluge of sensor data—from GPS coordinates and IMU readings to visual and thermal imagery. Raw sensor data, however, is inherently noisy and subject to variance. This is where the statistical “mean” becomes an indispensable tool, serving as a cornerstone for data interpretation and system reliability.
Precision in Navigation and Sensor Fusion
Drones rely on a sophisticated array of sensors to maintain stable flight, navigate complex environments, and execute precise movements. Inertial Measurement Units (IMUs) provide data on acceleration and angular velocity, while GPS modules deliver positional information. Altimeters, magnetometers, and vision-based systems contribute further layers of environmental understanding. For any single sensor, a momentary reading can be erroneous or subject to transient noise. By continuously sampling data points and calculating the mean value over a short time window or across multiple redundant sensors, systems can filter out outliers and converge on a more accurate representation of the drone’s true state.
Sensor fusion algorithms, such as Kalman filters or Extended Kalman filters, heavily leverage statistical means to combine data from disparate sources. These algorithms estimate the most probable state of the drone (position, velocity, orientation) by weighing individual sensor inputs based on their estimated accuracy and historical “mean” behavior. The resulting mean state estimate is far more robust and precise than any single sensor reading could provide, directly impacting the drone’s ability to maintain stable flight, hold position, and follow complex trajectories with sub-meter accuracy. Without the reliable averaging inherent in these calculations, autonomous flight would be fraught with instability and inaccuracy, rendering advanced applications impossible.
Data Normalization and Noise Reduction
Beyond navigation, statistical means play a crucial role in preparing data for higher-level processing, particularly in remote sensing and mapping. When a drone collects vast amounts of imagery or spectral data, variations can arise from lighting conditions, atmospheric effects, sensor calibration drifts, or even slight changes in flight altitude. To compare data points across different scans or over time, normalization techniques are often applied, frequently using mean values to adjust data scales.
For example, in multispectral imaging, the mean reflectance value for a known calibration target can be used to normalize subsequent readings, ensuring that variations in light intensity do not skew spectral signatures. Similarly, noise reduction algorithms often involve averaging pixel values within a local neighborhood, effectively smoothing out random fluctuations while preserving essential features. This process directly contributes to creating clearer maps, more accurate 3D models, and more reliable input for machine learning models, ensuring that the “meaning” extracted from the data is based on clean, consistent information.
Extracting Meaning from Raw Data: The Core of Autonomous Systems
While the “mean” provides a foundational level of data consistency, the true power of innovative drone technology lies in extracting “meaning” from this processed information. This refers to transforming raw numbers and images into actionable intelligence, enabling autonomous decision-making, pattern recognition, and comprehensive environmental understanding.
AI and Machine Learning: Interpreting Patterns
Artificial Intelligence and Machine Learning (AI/ML) are transformative forces in drone innovation, and their effectiveness is entirely dependent on their ability to derive meaning from complex datasets. In applications like AI follow mode, object detection, and autonomous navigation, ML models are trained on massive datasets to recognize patterns, objects, and environmental features. The training process itself often involves statistical means—for instance, mean average precision (mAP) is a common metric for evaluating object detection models, reflecting the average precision across multiple object classes.
Once deployed, these models analyze live drone sensor data, processing images or lidar point clouds to identify specific objects (e.g., people, vehicles, power lines), classify terrain types, or detect changes in the environment. The “meaning” here is the system’s interpretation: “This pixel cluster represents a human,” or “This spectral signature indicates plant stress.” This interpretation directly informs the drone’s subsequent actions, whether it’s adjusting its flight path to follow a target, avoiding an obstacle, or highlighting an area of interest for human review. Without sophisticated AI/ML algorithms to make sense of the data, the drone remains a mere data collector; with them, it becomes an intelligent agent.
Environmental Sensing and Anomaly Detection
Remote sensing drones are equipped with specialized sensors (e.g., thermal, LiDAR, multispectral, hyperspectral) to gather detailed information about the environment below. The “meaning” derived from this data is incredibly diverse, ranging from agricultural health assessments to infrastructure inspection and environmental monitoring. For instance, in agriculture, multispectral imagery provides data points that, when processed, can yield a Normalized Difference Vegetation Index (NDVI). The “mean” NDVI value over a specific crop field might indicate its overall health, but the “meaning” truly comes from identifying deviations from this mean—areas of unusually low NDVI suggesting disease or water stress.
Similarly, in infrastructure inspection, thermal cameras might capture temperature distributions across solar panels or building facades. While an average temperature (mean) might be within acceptable limits, the “meaning” is derived from detecting hotspots or cold spots that deviate significantly from the mean, indicating potential failures or inefficiencies. Anomaly detection algorithms often rely on establishing a statistical baseline (e.g., the mean and standard deviation of normal operating conditions) and then flagging any data points that fall outside these expected ranges. This ability to pinpoint deviations from the norm is crucial for proactive maintenance and early problem identification.
Mean as a Metric: Quantifying Performance and Insight
The concept of “mean” extends beyond data processing; it is also a fundamental metric for evaluating the performance of drone systems and quantifying the insights gained from their operations.
Performance Metrics in Autonomous Flight
For autonomous flight systems, performance is often quantified using metrics that incorporate mean values. For instance, “mean absolute error” (MAE) or “root mean square error” (RMSE) are used to evaluate how closely a drone’s actual trajectory adheres to its planned flight path. A low mean error signifies high navigational precision, crucial for applications requiring repeatable, accurate movements such as automated surveying or delivery.
Similarly, in drone racing or high-performance flight, metrics like “mean lap time” or “mean top speed” are used to gauge pilot skill or drone efficiency. For AI follow modes, the “mean tracking error”—the average distance between the drone and its target over time—is a key indicator of the system’s robustness and accuracy. These mean-based metrics provide objective, quantifiable measures of system performance, guiding development and ensuring reliable operation in diverse and challenging conditions.
Geospatial Analysis and Remote Sensing Applications
In mapping and remote sensing, the “mean” is essential for summarizing vast geographical datasets and extracting macro-level insights. For example, when creating elevation models from LiDAR data, the mean elevation of a specific area might be calculated to understand its overall topography. In urban planning, the mean building height or mean green space per capita, derived from drone-collected imagery and point clouds, can inform policy decisions.
For environmental monitoring, the mean concentration of a pollutant across a region, or the mean canopy height in a forest, derived from drone data, provides crucial insights into ecological health and change over time. These aggregated mean values help scientists and planners understand trends, identify critical areas, and assess the impact of environmental factors, translating raw data into meaningful scientific and policy-relevant information.
The Synergy of Mean Calculation and Actionable Meaning
The symbiotic relationship between calculating the “mean” and extracting “meaning” is what truly empowers modern drone technology. It’s a continuous feedback loop where robust data processing leads to accurate interpretation, which in turn enables intelligent action.
Real-time Decision Making
In fully autonomous systems, real-time decision-making is paramount. A drone performing obstacle avoidance must process sensor data, calculate mean distances to objects, and interpret the “meaning” of these distances (e.g., “collision imminent,” “safe to proceed”) within milliseconds. An AI-powered drone navigating a complex indoor environment must continuously fuse data from visual SLAM (Simultaneous Localization and Mapping) and other sensors, relying on statistical averages to maintain a consistent self-position estimate, while interpreting the “meaning” of perceived walls, doors, and open spaces to plot a safe and efficient course. This immediate transition from data averaging to meaningful interpretation and subsequent action is the hallmark of truly intelligent and responsive drone systems.
Predictive Analytics and Future Trends
Beyond real-time operations, the aggregation of drone data over longer periods, often summarized by mean values and other statistical measures, fuels predictive analytics. By analyzing historical “mean” crop yields, mean thermal anomalies, or mean traffic patterns derived from drone observations, systems can predict future trends, identify potential problems before they escalate, and optimize resource allocation. The “meaning” here is forward-looking: “Based on historical mean NDVI values, this field is likely to experience nutrient deficiency next season,” or “The mean deterioration rate of this bridge suggests a maintenance window in two years.” This predictive capability elevates drones from mere data collectors to strategic tools for planning and forecasting, demonstrating the ultimate synergy of “mean” and “meaning” in driving innovation.
In conclusion, “what is mean meaning” within drone technology is far from a trivial question. It encapsulates the journey from noisy, raw sensor data to precise statistical averages, and finally, to the profound insights and autonomous actions that define cutting-edge drone innovation. The meticulous calculation of means ensures data reliability, while the sophisticated extraction of meaning transforms this data into the intelligence required for advanced applications like AI follow modes, autonomous flight, precision mapping, and insightful remote sensing, continually pushing the boundaries of what unmanned aerial systems can achieve.