
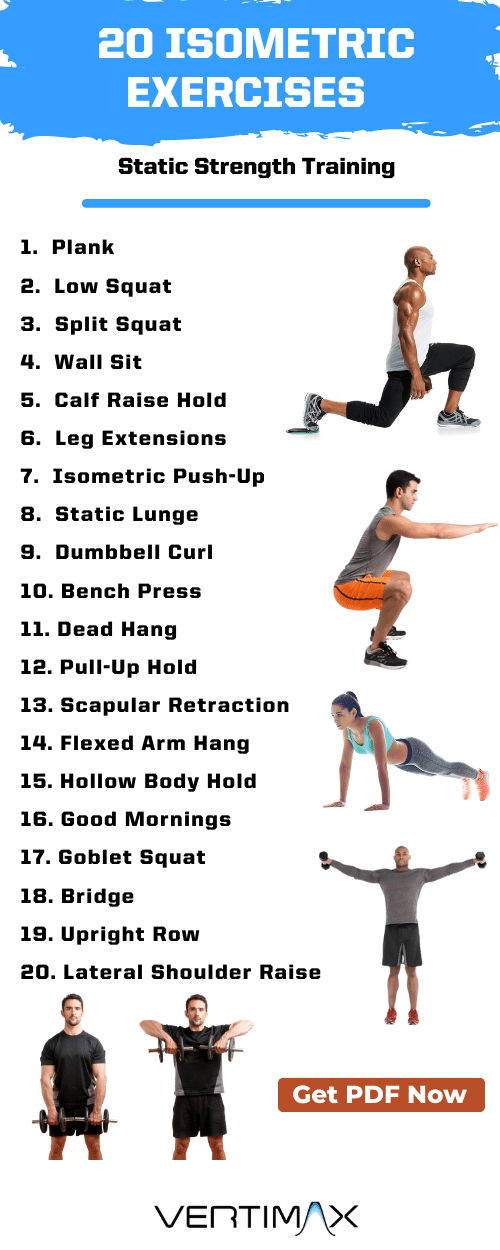
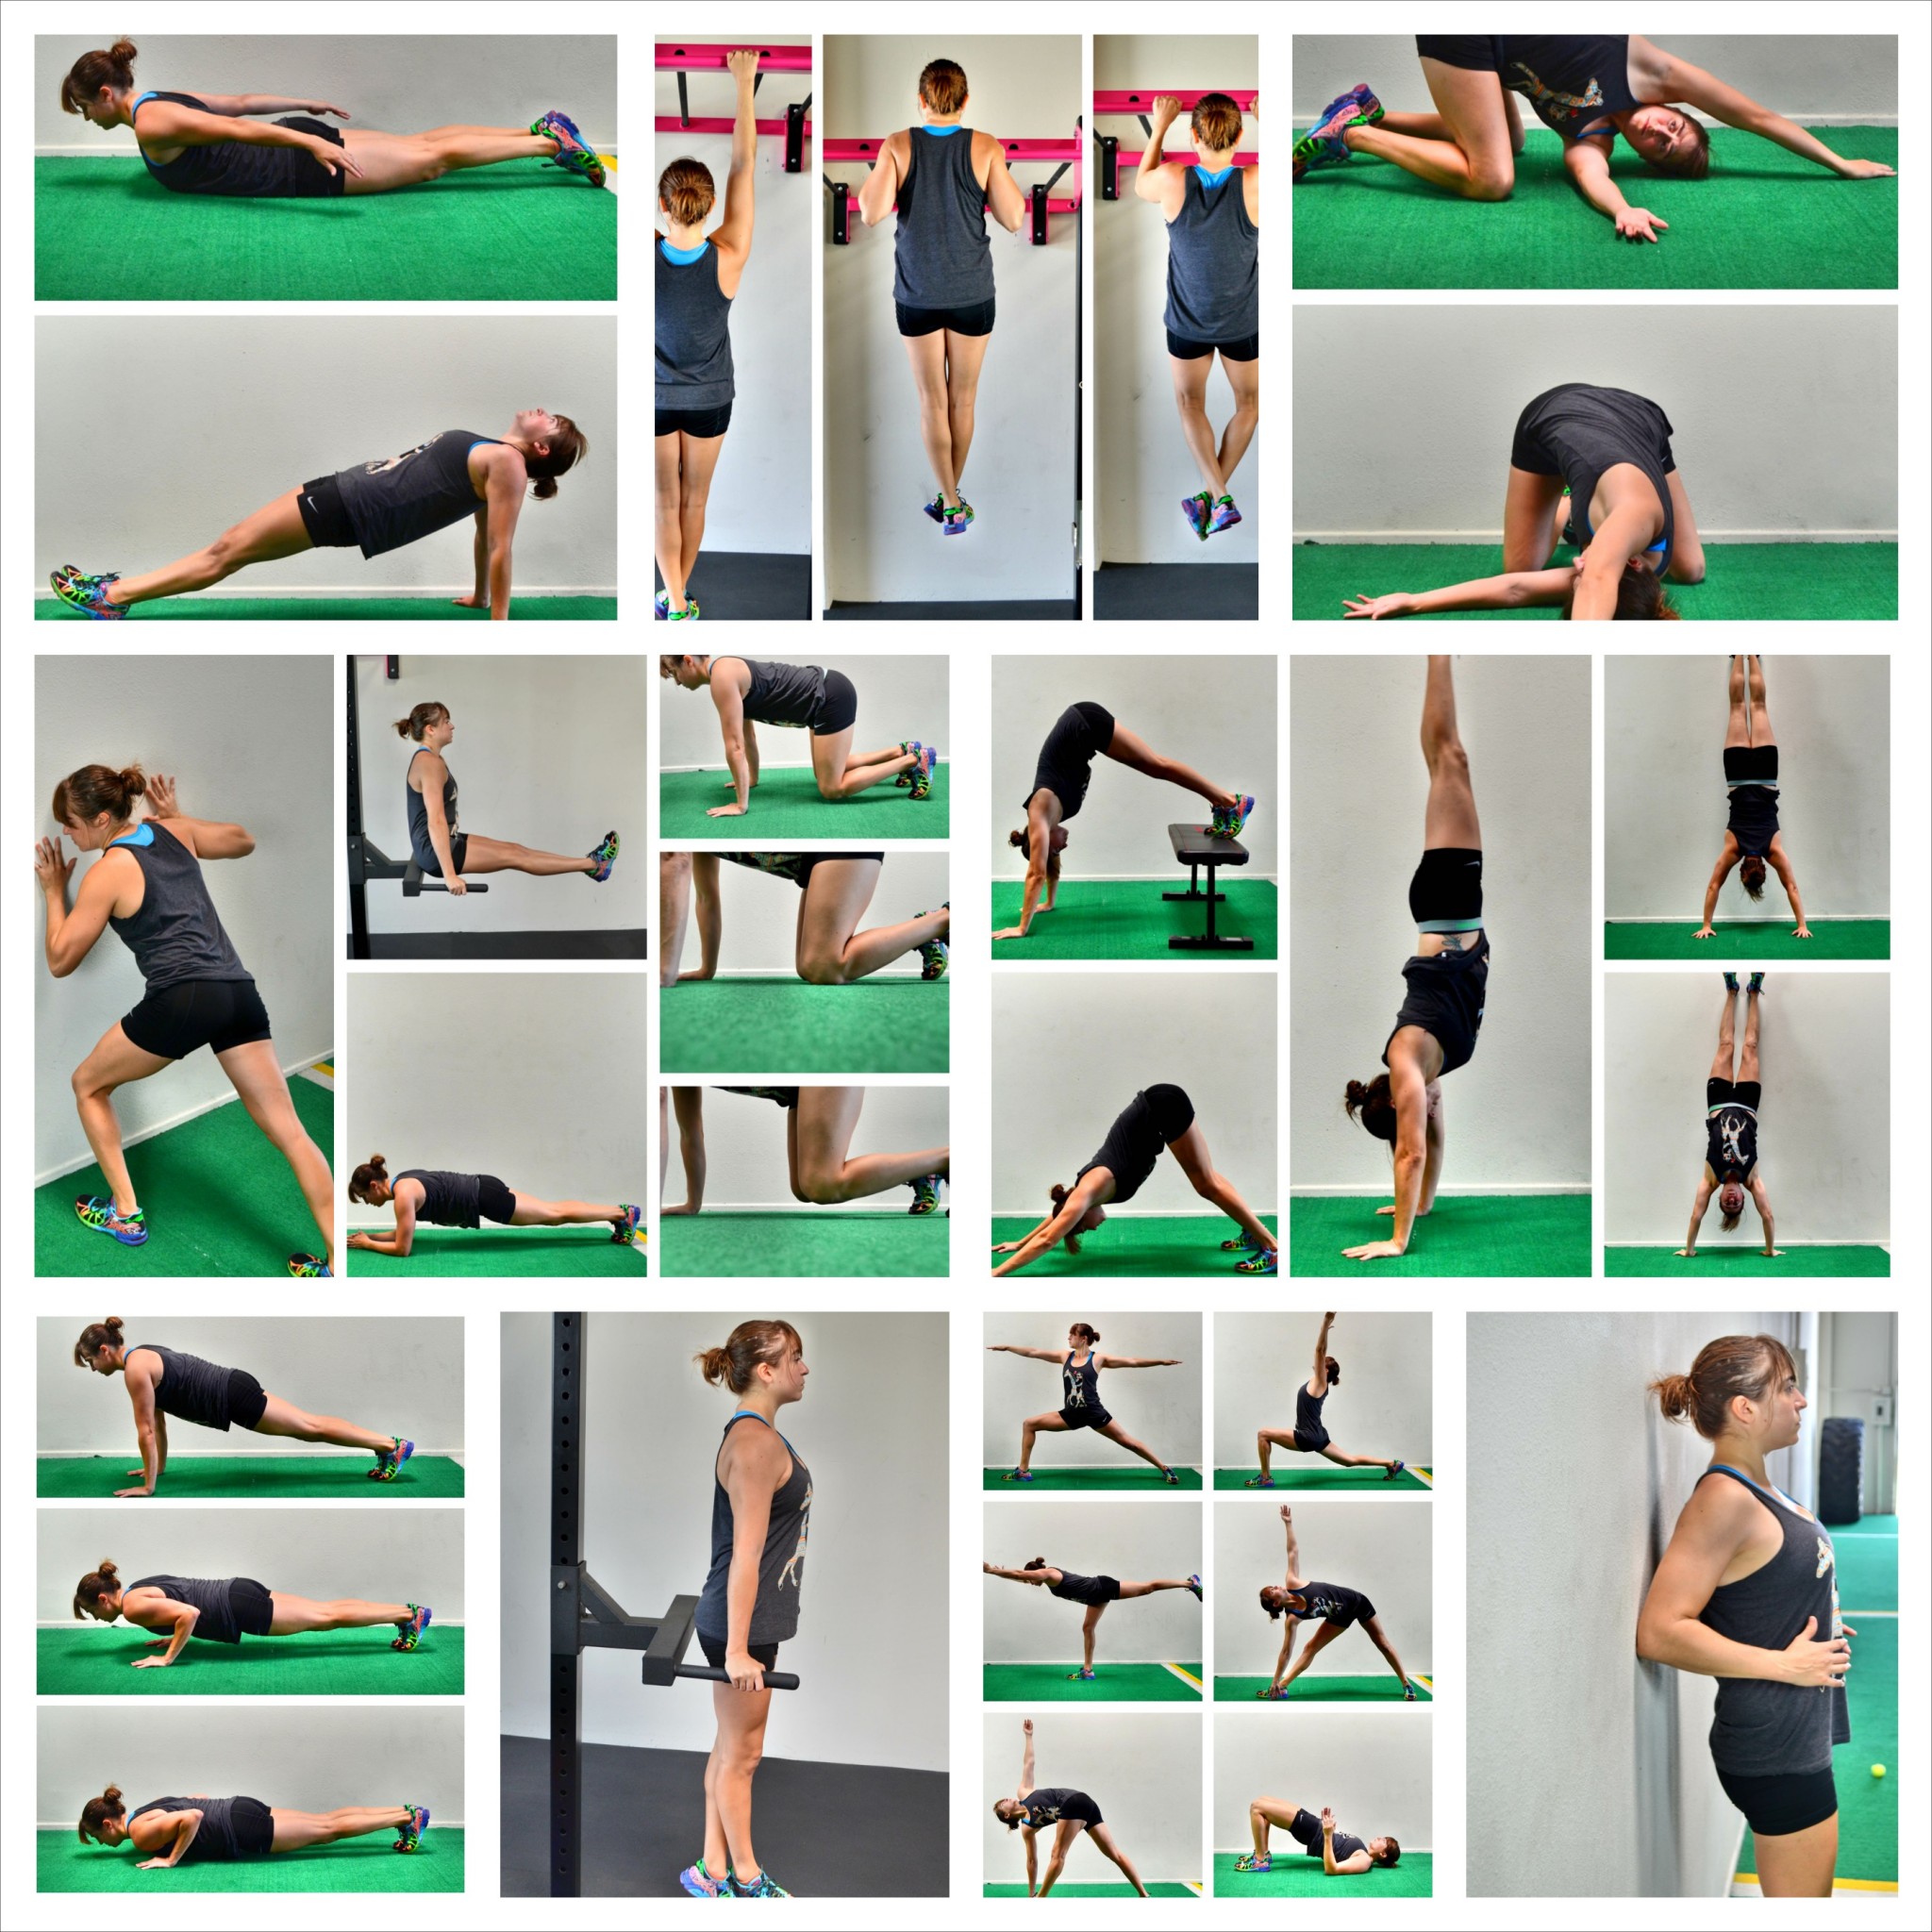
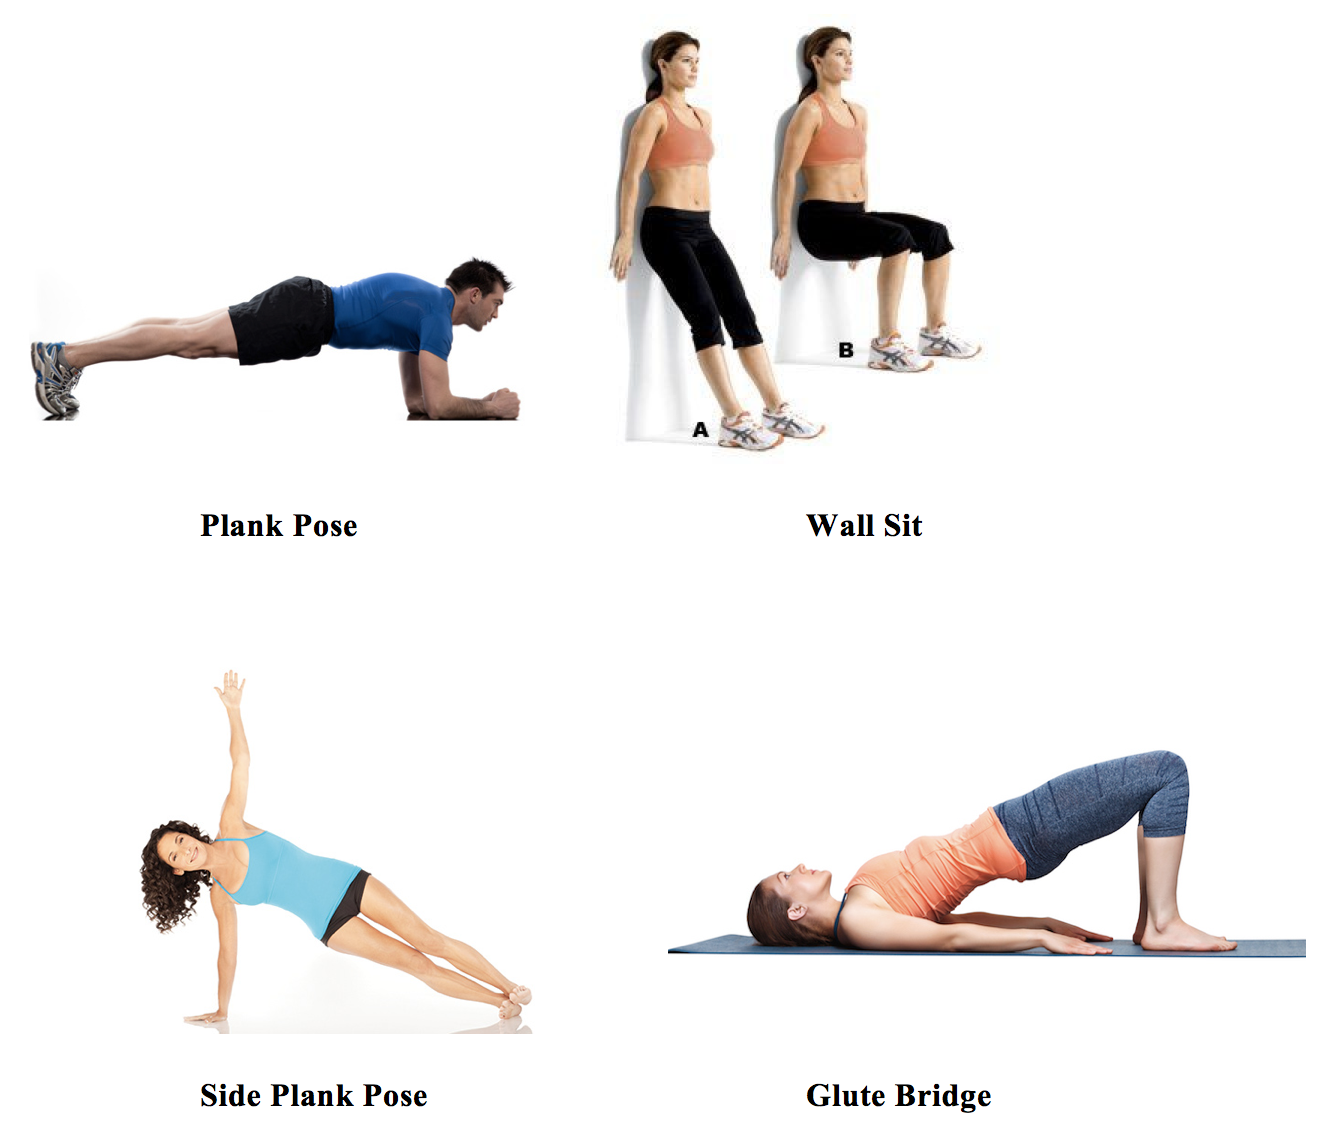
In the realm of advanced flight technology, the concept of “isometrics exercise” translates not into physical exertion for a human, but into the ultimate test of a drone’s stabilization and control systems. When applied to unmanned aerial vehicles (UAVs), “isometrics exercise” refers to the drone’s ability to maintain a perfectly static, unmoving position in three-dimensional space, effortlessly countering external forces and executing micro-adjustments with extreme precision. This static hold, devoid of any discernible drift or unintended movement, is a cornerstone of sophisticated drone operations and a critical indicator of a flight system’s refinement. It’s the equivalent of a human athlete holding a demanding pose without a tremor – a demonstration of immense control and strength within a fixed position.
This capacity for isometric flight is far more than a mere parlor trick; it underpins many of the most demanding and precise applications for drones today. From capturing razor-sharp aerial photography to conducting meticulous industrial inspections, the ability to lock into a precise spatial coordinate and remain absolutely stable is paramount. It separates amateur-grade hovering from professional-grade positional integrity, showcasing the culmination of intricate sensor fusion, sophisticated algorithms, and responsive propulsion systems working in perfect harmony.
The Core Concept: Static Stability in Flight
At its heart, static stability in drone flight is the machine’s inherent tendency to return to or maintain an equilibrium position when disturbed. In the context of an “isometric hold,” this means actively resisting any perturbation that would cause it to deviate from its assigned hover point. Unlike dynamic flight, which involves continuous movement and complex trajectories, isometric flight emphasizes absolute stillness and positional accuracy.
The importance of this capability cannot be overstated across various drone applications. For cinematographers, it means achieving perfectly still wide shots or precise tracking without unwanted jitter. For industrial inspectors, it allows for close-up examination of structures, documenting subtle faults without the risk of collision due to drift. For mapping and surveying, an isometric hold ensures that each collected data point is geo-referenced with maximum precision, leading to highly accurate models and analyses. This fundamental requirement drives continuous innovation in flight control algorithms and sensor hardware, pushing the boundaries of what these autonomous platforms can achieve in terms of positional fidelity.
Key Technologies Enabling Isometric Flight
Achieving an impeccable isometric hold is a testament to the seamless integration of several advanced technologies, each playing a crucial role in sensing, processing, and executing the necessary adjustments.
Advanced Stabilization Systems
The bedrock of a drone’s isometric capability lies within its advanced stabilization systems, primarily centered around its Inertial Measurement Unit (IMU) and flight controller.
- IMUs (Accelerometers, Gyroscopes, Magnetometers): These micro-sensors continuously measure the drone’s orientation (pitch, roll, yaw) and linear acceleration in all three axes. Accelerometers detect linear motion and gravity, gyroscopes measure angular velocity, and magnetometers provide heading information relative to Earth’s magnetic field. Together, they paint a real-time picture of the drone’s state in space.
- PID Controllers: Proportional-Integral-Derivative (PID) controllers are the workhorses of drone flight control. They take the IMU data, compare it to the desired state (e.g., perfect hover), and calculate the precise adjustments needed for the motors. The “P” component addresses the immediate error, the “I” component corrects for accumulated past errors (helping prevent steady-state error or drift), and the “D” component anticipates future errors based on the rate of change, adding damping to prevent overshoot and oscillations. Fine-tuning these gains is critical for achieving a responsive yet stable isometric hold.
- Flight Controller Algorithms: Beyond basic PID, modern flight controllers employ sophisticated algorithms for sensor fusion, filtering noise from IMU readings, and robustly estimating the drone’s position and velocity. Kalman filters and complementary filters are commonly used to combine data from various sensors (IMU, GPS, barometers, vision sensors) into a single, highly accurate state estimate, even when individual sensor data might be noisy or intermittently unavailable.
GPS and Vision Positioning Systems (VPS)
While IMUs provide local orientation and acceleration, global and local positioning systems are essential for maintaining a fixed point in space.
- GPS (Global Positioning System): For outdoor flight, GPS is the primary means of global positioning. Multi-constellation GNSS receivers (supporting GPS, GLONASS, Galileo, BeiDou) enhance accuracy and reliability. While standard GPS offers accuracy within a few meters, advanced techniques like RTK (Real-Time Kinematic) and PPK (Post-Processed Kinematic) can reduce positional error down to centimeter-level, enabling extremely precise isometric holds for professional applications like surveying and high-fidelity mapping.
- Vision Positioning Systems (VPS): In environments where GPS signals are weak, blocked, or unavailable (e.g., indoors, under bridges, dense urban canyons), VPS takes over. These systems typically use downward-facing optical flow cameras and/or ultrasonic sensors. The optical flow camera tracks texture patterns on the ground to detect horizontal movement, while ultrasonic sensors measure altitude by bouncing sound waves off the ground. Together, they provide crucial local positional data, allowing the drone to maintain a stable hover even without satellite navigation.
Propulsion and Motor Control
Even the most accurate sensor data and algorithms are useless without precise execution.
- Precise RPM Adjustments: The drone’s motors and Electronic Speed Controllers (ESCs) must be capable of incredibly fine and rapid adjustments to their rotational speed. Any lag or imprecision in motor response will directly translate into instability.
- ESC Responsiveness: Modern ESCs are designed for high refresh rates and minimal latency, allowing the flight controller’s commands to be executed almost instantaneously. Features like active braking also enable quicker motor speed changes.
- Propeller Design: The efficiency and balance of the propellers are also crucial. Well-designed, balanced propellers reduce vibrations and produce consistent thrust, contributing to overall flight stability and the drone’s ability to hold an isometric position with minimal power fluctuations.
The Challenges of Perfect Isometric Hold
While impressive, achieving a truly perfect isometric hold is an ongoing engineering challenge, fraught with various environmental and systemic complexities.
Environmental Factors
The very medium in which drones operate is inherently dynamic, posing constant threats to stability.
- Wind Gusts and Air Currents: These are arguably the most significant external factors. Even subtle air movements can exert considerable force on a drone’s relatively light airframe, demanding rapid and precise counter-thrust from the propulsion system. In extreme conditions, even the most advanced systems may struggle to maintain absolute stillness.
- Temperature Changes: Variations in ambient temperature can subtly affect sensor calibration, leading to drift. For instance, gyroscopes can experience thermal drift, and atmospheric pressure changes can influence barometer readings, affecting altitude hold.
- GPS Signal Interference: Satellite signals can be attenuated, reflected (multipath), or even intentionally jammed, degrading GPS accuracy or causing complete signal loss. In such scenarios, the drone must seamlessly transition to alternative positioning systems (like VPS) to maintain stability.
- Lighting Conditions: For VPS, extreme lighting conditions—too dark, too bright, highly reflective surfaces, or lack of discernible texture—can impair the optical flow camera’s ability to track ground features, compromising local positional accuracy.
System Limitations
Even with cutting-edge technology, inherent limitations within the drone’s hardware and software can affect isometric performance.
- Sensor Noise and Drift: No sensor is perfect. IMUs inherently have a certain level of noise, and over time, gyroscopes can accumulate small errors (drift), which, if not properly compensated for by filtering and fusion algorithms, can lead to slow positional creep.
- Motor Wear and Balance Issues: Over extended use, motors can wear, and propellers can become slightly unbalanced or damaged. These issues introduce vibrations and inconsistencies in thrust, making precise control more difficult and impacting the drone’s ability to hold a perfect isometric pose.
- Battery Degradation: As batteries age or discharge, their ability to deliver consistent power can diminish. This can affect motor responsiveness and peak thrust, potentially making it harder for the drone to react strongly to disturbances or maintain a very long isometric hold.
- Algorithm Complexity and Processing Power: The algorithms required for robust sensor fusion and precise flight control are computationally intensive. There’s a constant trade-off between the complexity of these algorithms (which enhance performance) and the available processing power on the flight controller, which influences the speed and effectiveness of real-time adjustments.
Applications and Future of Isometric Drone Capabilities
The mastery of isometric flight has opened doors to numerous high-value applications and continues to be a frontier for future technological advancements.
Precision Aerial Photography and Cinematography
For visual artists and content creators, the ability to execute a flawless isometric hold is a game-changer.
- Sharp Images and Smooth Video: By eliminating drift and subtle movements, drones can capture perfectly still photographs, even with longer exposure times, and deliver incredibly smooth, cinematic video footage free from unwanted jitters or wobbles. This precision is vital for professional-grade productions.
- Complex Creative Techniques: Isometric capabilities enable advanced techniques such as hyper-lapses (where the drone remains perfectly still while the world moves around it), precise orbit shots around a static subject, or intricate reveal shots that start from an absolutely fixed point.
Industrial Inspection and Mapping
In industrial and commercial sectors, isometric drone flight offers significant advantages in safety, efficiency, and data quality.
- Close-up Inspection: Drones can perform detailed visual inspections of critical infrastructure—bridges, wind turbines, power lines, cell towers—hovering mere inches from surfaces without the risk of contact. This allows for the identification of minute structural flaws or corrosion that might be missed with less stable platforms.
- High-Accuracy 3D Mapping and Photogrammetry: For creating precise 3D models and maps, each photograph or data point must be geo-referenced with extreme accuracy. A drone capable of excellent isometric hold ensures consistent overlap between images and precise positioning of sensors, leading to highly accurate and detailed models for construction, mining, agriculture, and urban planning.
Emerging Technologies for Enhanced Stability
The pursuit of even more robust isometric capabilities continues to drive innovation in drone technology.
- AI/Machine Learning for Adaptive Flight Control: Future drones will increasingly leverage AI to learn from flight conditions and adapt their control parameters in real-time. This could allow drones to better predict and counter wind gusts or compensate for sensor degradation, achieving unprecedented levels of stability.
- More Robust Sensor Fusion and Redundancy: Advanced sensor fusion algorithms will combine an even wider array of sensor types (e.g., LiDAR, radar, ultra-wideband localization) with greater sophistication, providing more resilient and accurate positioning, especially in challenging GPS-denied or complex environments. Redundant systems will ensure continuous operation even if one sensor fails.
- Swarm Intelligence for Collective Stability: While still nascent, the concept of drone swarms working cooperatively could lead to collective isometric stability. By sharing positional data and coordinating their movements, a swarm could potentially achieve a more stable collective hold than a single drone, or provide hyper-dense sensor coverage for a static point.
In conclusion, what begins as an “isometrics exercise” for a drone transforms into a sophisticated ballet of sensors, algorithms, and propulsion systems. It is a critical benchmark for flight technology, defining the precision and reliability of modern UAVs and unlocking their potential across an ever-expanding array of professional and creative applications. As the technology evolves, the ability of drones to remain perfectly still in a turbulent world will only become more refined, opening new vistas for aerial innovation.