
The Core Concept of Homeostasis: Maintaining Dynamic Equilibrium
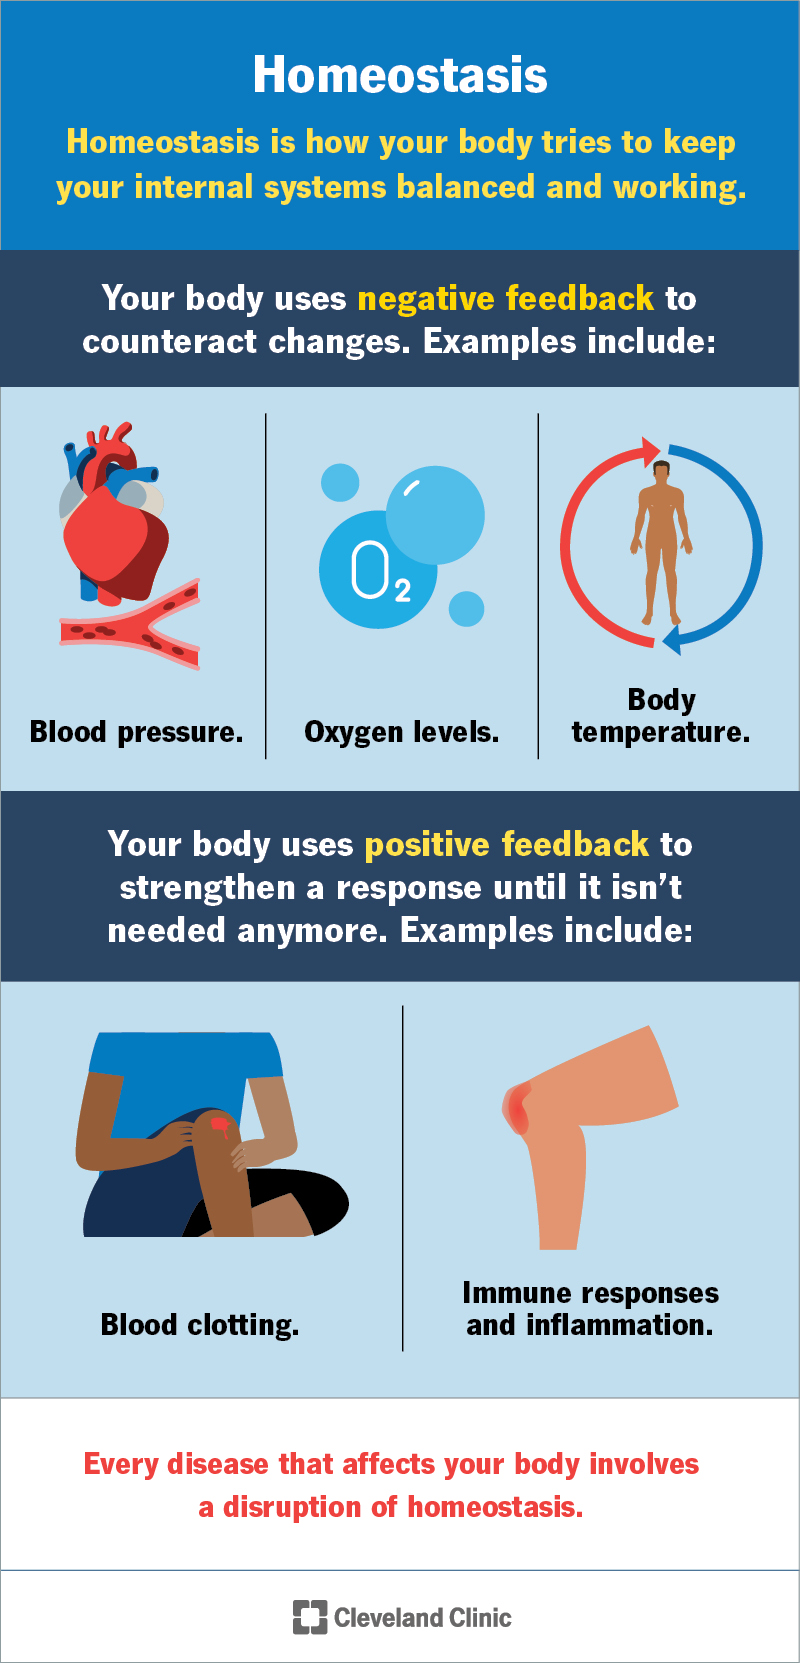
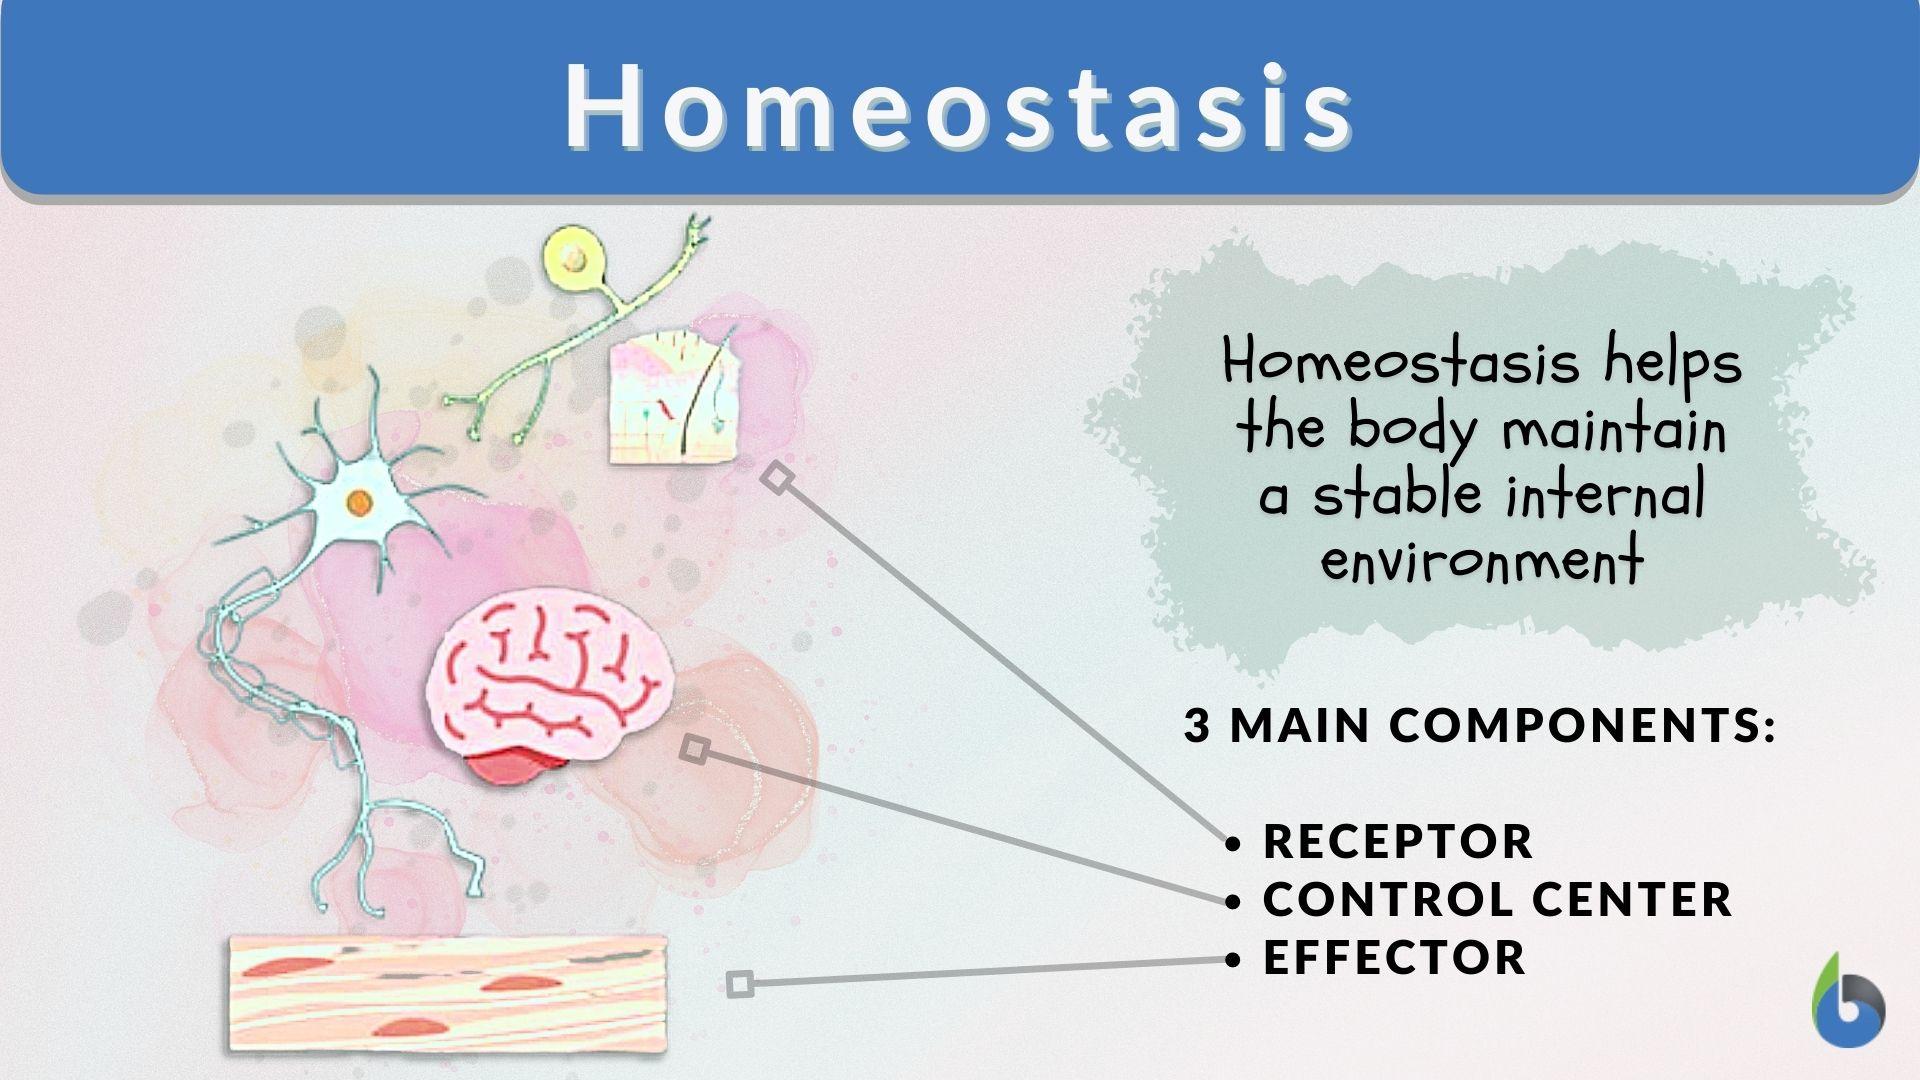
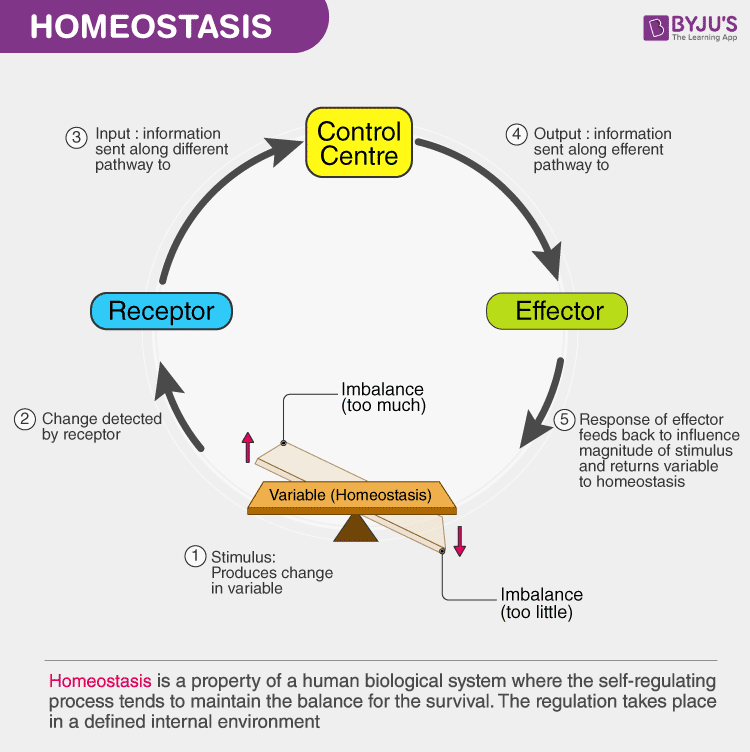
Homeostasis, fundamentally a biological concept, describes the ability of an organism to maintain stable internal conditions necessary for survival, despite external changes. It’s a continuous process of self-regulation, where various feedback mechanisms work to keep critical parameters – such as temperature, pH levels, or blood glucose – within a narrow, optimal range. This isn’t a static state, but a dynamic equilibrium; a constant adjustment to maintain balance.
While originating in biology, the principles of homeostasis are remarkably applicable to complex engineered systems, particularly in the realm of drone flight technology. Drones, much like living organisms, operate in dynamic, often unpredictable environments. To achieve stable flight, execute precise maneuvers, and perform their intended functions reliably, they must continuously monitor their internal state and external surroundings, making rapid adjustments to maintain optimal operational parameters. This pursuit of stability, self-regulation, and adaptive response to disturbances lies at the heart of modern drone design and innovation, mirroring the essence of biological homeostasis. Without sophisticated systems that mimic homeostatic control, drones would be unstable, uncontrollable, and ultimately useless.
Flight Stabilization Systems: The Drone’s Autonomic Nervous System
At the core of a drone’s ability to maintain stable flight is its intricate flight stabilization system. This system acts as the drone’s “autonomic nervous system,” constantly sensing the drone’s orientation and motion, and making imperceptible, real-time corrections to keep it balanced and on course. This is arguably the most direct example of homeostasis in drone technology, as it directly addresses the challenge of maintaining a desired attitude and stability against external forces like wind, turbulence, and shifts in payload.
Inertial Measurement Units (IMUs): Sensing the “Internal State”
The primary sensory input for flight stabilization comes from the Inertial Measurement Unit (IMU). Comprising accelerometers and gyroscopes, the IMU is the drone’s equivalent of proprioceptors, providing crucial data about its orientation and motion in space.
- Accelerometers measure linear acceleration in three axes, detecting changes in velocity and providing data about gravity, which helps determine the drone’s pitch and roll relative to the earth’s surface.
- Gyroscopes measure angular velocity, detecting rotational changes around the pitch, roll, and yaw axes. This is vital for understanding how quickly the drone is tilting, rolling, or rotating.
Together, these sensors provide the flight controller with a continuous stream of information about the drone’s current attitude, velocity, and rotational state. This real-time data is critical for the flight controller to understand the drone’s “internal state” and identify any deviation from the desired stable flight parameters.
Flight Controllers: The Brain Regulating Stability
The flight controller is the central processing unit, the “brain” of the drone’s homeostatic system. It receives data from the IMU and other sensors, processes it through complex algorithms, and sends commands to the electronic speed controllers (ESCs) which, in turn, adjust the speed of each motor and propeller.
The most common control loop used is the PID (Proportional-Integral-Derivative) controller.
- Proportional (P) component: Responds to the current error (deviation from the desired attitude). A larger deviation results in a stronger corrective action.
- Integral (I) component: Addresses persistent, small errors over time. It helps eliminate steady-state errors and ensures the drone eventually reaches its target attitude precisely.
- Derivative (D) component: Predicts future errors based on the rate of change of the current error. This helps to dampen oscillations and improve the system’s responsiveness, preventing overcorrection.
By continuously adjusting the thrust of individual motors based on PID calculations, the flight controller maintains the drone’s desired pitch, roll, and yaw angles, effectively counteracting external disturbances like wind gusts. This constant sensing, processing, and correction loop is a perfect illustration of how drones maintain a homeostatic balance in flight.
Navigation and Position Hold: Maintaining the “Desired Set Point”
Beyond merely staying stable, drones must also maintain specific positions or follow predefined paths, much like an organism needs to maintain a specific body temperature or blood pressure. This involves maintaining a “set point” for location and altitude, utilizing various navigation technologies.
GPS and GNSS Systems: Knowing Where You Are
Global Positioning System (GPS) and other Global Navigation Satellite Systems (GNSS) are fundamental for outdoor position holding and autonomous navigation. These systems allow the drone to pinpoint its geographical coordinates with high accuracy.
- The flight controller uses GPS/GNSS data to compare the drone’s current position with its desired position (e.g., a hover point or a waypoint on a flight path).
- If a deviation is detected, the flight controller initiates corrective actions by adjusting motor thrusts to gently guide the drone back to the target coordinates. This continuous feedback loop ensures the drone maintains its spatial “homeostasis.” Advanced RTK (Real-Time Kinematic) and PPK (Post-Processed Kinematic) GPS systems further enhance this precision, crucial for applications requiring centimeter-level accuracy in mapping and surveying.
Barometers and Vision Positioning Systems (VPS): Vertical and Local Stability
Maintaining stable altitude is another critical aspect of drone homeostasis.
- Barometers (pressure sensors) measure ambient air pressure, which changes predictably with altitude. The flight controller uses this data to maintain a constant height above the ground. If the drone drifts up or down, the barometer detects the pressure change, and the flight controller adjusts motor thrust to bring it back to the set altitude.
- Vision Positioning Systems (VPS), often utilizing optical flow sensors and ultrasonic sensors, are crucial for precise hovering in indoor environments or at low altitudes where GPS signals may be weak or unavailable. Optical flow cameras track patterns on the ground to determine horizontal movement, while ultrasonic sensors measure distance to the ground. This combination allows the drone to maintain a precise hover, effectively holding its ground-relative position and altitude with a high degree of “local homeostasis,” even without satellite navigation.
Obstacle Avoidance and Adaptive Flight: Responding to Environmental Changes
A dynamic environment presents continuous challenges to a drone’s operational homeostasis. Obstacles, changing weather, or other aircraft are “external stressors” that the drone must react to in order to maintain its mission parameters and structural integrity. Obstacle avoidance systems represent a sophisticated layer of adaptive homeostasis.
Sensor Fusion for Environmental Awareness
Modern drones integrate a suite of sensors to build a comprehensive understanding of their surroundings:
- Ultrasonic sensors: Emit sound waves and measure the time it takes for them to return, providing short-range distance measurements, particularly useful for detecting objects directly ahead or below.
- LiDAR (Light Detection and Ranging): Uses pulsed laser light to measure distances to targets, generating precise 3D maps of the environment. This is invaluable for detecting complex obstacles and mapping terrain.
- Stereo cameras/Vision sensors: Mimic human vision to perceive depth and identify objects in the drone’s flight path. Advanced computer vision algorithms can classify obstacles and even predict their movement.
The data from these diverse sensors is combined through sensor fusion algorithms. This process creates a robust and redundant environmental awareness system, allowing the drone to detect potential collisions from multiple angles and under varying conditions. The ability to integrate and interpret these disparate data streams allows the drone to understand its environment and maintain a safe operating envelope – a critical form of homeostatic regulation in a complex world.
Predictive Control and Path Planning
Once an obstacle is detected, the drone’s flight controller, using advanced algorithms, determines the safest and most efficient way to maintain its mission while avoiding a collision. This involves:
- Dynamic path planning: Modifying the flight trajectory in real-time to steer around the detected obstacle.
- Speed and altitude adjustment: Reducing speed or changing altitude to safely clear the obstacle.
- Predictive control: In some advanced systems, the drone can anticipate the movement of dynamic obstacles (e.g., another drone or a bird) and adjust its path proactively to maintain a safe distance, embodying a proactive form of homeostasis.
These adaptive capabilities ensure the drone maintains its mission objectives while preserving its “well-being” (i.e., avoiding damage), much like an organism adjusts its behavior to avoid harm and ensure continued function.
Power Management and Battery Health: Sustaining Operational Life
Just as an organism needs a stable energy supply to maintain its homeostatic functions, a drone relies on efficient and regulated power management. Maintaining the “energy homeostasis” of the drone is crucial for its operational longevity and safety.
Monitoring and Regulation of Power Flow
The drone’s flight controller and dedicated power management systems continuously monitor key electrical parameters:
- Battery voltage: Ensures the battery remains within a safe operating range, preventing over-discharge which can damage the battery and lead to sudden power loss.
- Current draw: Tracks the amount of power being consumed, which varies depending on flight maneuvers, payload, and environmental conditions.
- Battery temperature: Prevents overheating during high-current operations or cold-weather performance degradation.
When critical thresholds are approached (e.g., low battery voltage), the flight controller triggers homeostatic responses such as:
- Return-to-Home (RTH) activation: Automatically initiating a flight back to the launch point before power runs out.
- Performance reduction: Limiting motor power to extend flight time or reduce strain on components.
- Warning alerts: Notifying the operator of impending power issues.
These mechanisms are vital for ensuring the drone’s continued operational viability, preventing a catastrophic “system shutdown” due to energy imbalance.
Thermal Management
Maintaining optimal operating temperatures for motors, ESCs, and the flight controller itself is another critical homeostatic function. Overheating can lead to component failure, reduced performance, and even fire. Drone designs incorporate:
- Passive cooling: Strategic placement of components and airflow channels to dissipate heat.
- Active cooling (in some larger drones): Fans or other mechanisms to regulate temperature.
The flight controller can also implement thermal management through software, for instance, by limiting the maximum thrust or flight duration if component temperatures rise above safe levels, thus preventing thermal runaway and maintaining the internal “thermal homeostasis” of the system.