
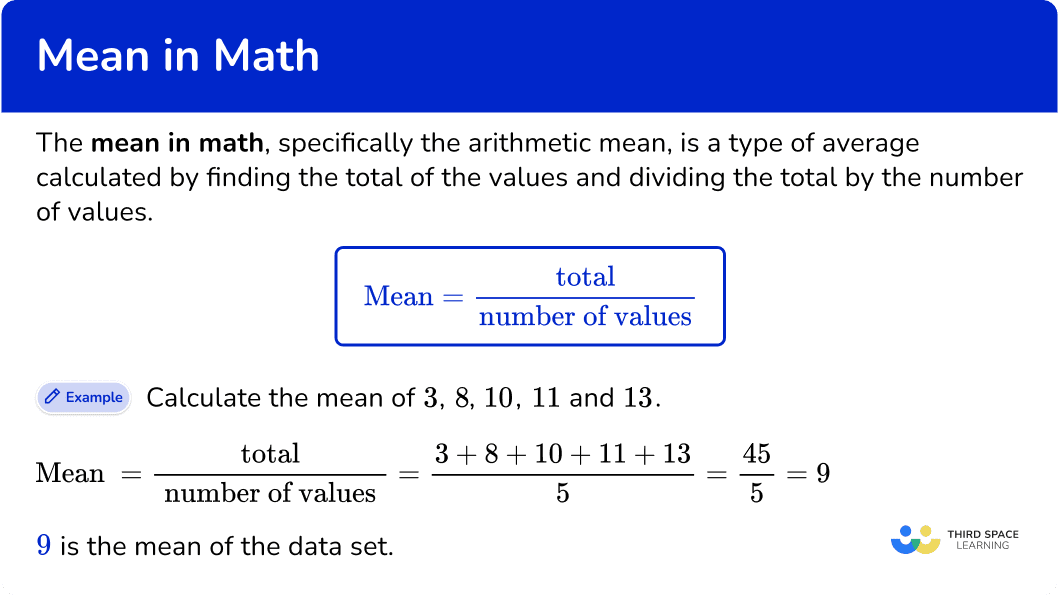
The phrase “what does means in math” within the context of cutting-edge drone technology signifies the fundamental mathematical principles, algorithms, and models that underpin advanced functionalities. Far from being an abstract academic concept, “math” here represents the precise language and set of computational tools that transform conceptual designs into functional, high-performance systems for unmanned aerial vehicles (UAVs). Understanding these mathematical “means” is crucial for appreciating the capabilities and future potential of modern drone Tech & Innovation, including AI-driven navigation, autonomous operations, precise mapping, and insightful remote sensing.
The Mathematical Foundation of AI Follow Mode
AI Follow Mode, a cornerstone of intelligent drone operation, allows a UAV to autonomously track and follow a designated subject. This seemingly intuitive capability is built upon a complex tapestry of mathematical principles, ranging from sophisticated computer vision algorithms to dynamic path planning and control theory. The “means in math” in this application involve accurately defining the target, predicting its movement, and calculating the optimal drone trajectory in real-time.
Predictive Tracking and Object Recognition
At its core, AI Follow Mode relies on robust object recognition. Drones employ deep learning models, often convolutional neural networks (CNNs), which are fundamentally mathematical constructs. These networks consist of layers of interconnected “neurons” that perform matrix multiplications and activation functions to identify intricate patterns within image data. The extensive training process involves vast datasets and sophisticated optimization algorithms, such as stochastic gradient descent, to iteratively adjust the network’s internal parameters (weights and biases). This adjustment aims to minimize a mathematical “loss function” that quantifies the discrepancy between the network’s predictions and the true labels, thereby enhancing its recognition accuracy.
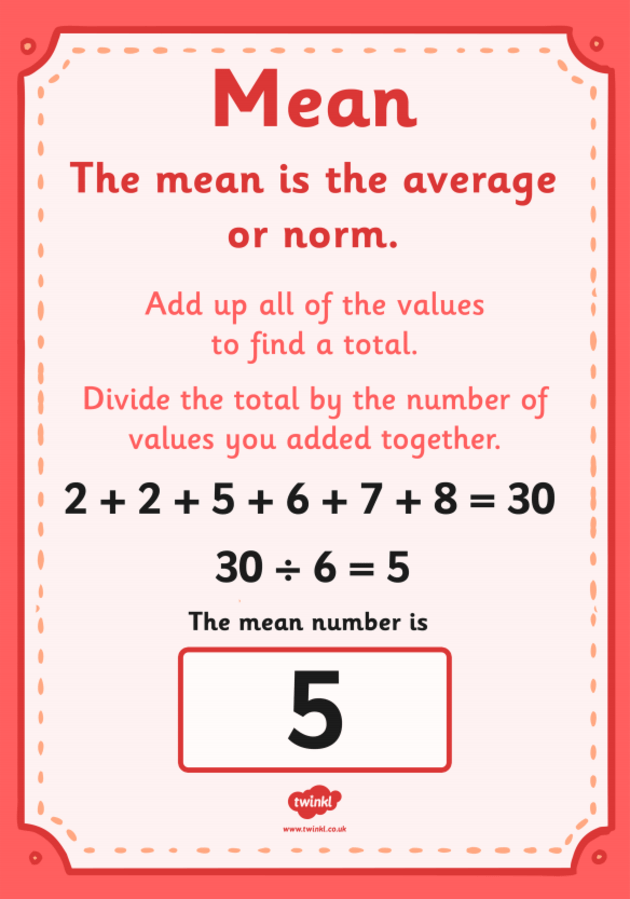
Once a target is identified, the drone must predict its future movement to maintain a smooth, continuous follow. This is where state estimation techniques, particularly Kalman Filters, become indispensable. A Kalman Filter is an elegant recursive algorithm rooted in probability theory and linear algebra. It estimates the current and predicts the future state of a dynamic system (e.g., the position and velocity of the target) from a series of incomplete, noisy measurements. It leverages a mathematical model of the system’s dynamics and statistical properties of noise to produce an optimal estimate. In essence, it calculates the “mean” or most probable state of the target at any given time, constantly updating its prediction based on new sensor data. This blend of mathematical inference allows the drone to anticipate the subject’s path, rather than merely reacting to its current position, enabling fluid and intelligent tracking.
Path Optimization and Control
Following a subject isn’t just about knowing where it is; it’s also about knowing how to get there efficiently and safely. This involves complex path planning and control algorithms, heavily rooted in optimization theory and differential calculus. The drone must calculate a flight path that minimizes a specific cost function—perhaps a combination of energy consumption, distance from obstacles, smoothness of movement, and proximity to the target. This typically involves solving complex optimization problems, often framed as quadratic programs or using gradient-based methods, to determine the optimal thrust and attitude commands that the drone’s motors need to execute.
Furthermore, maintaining stable flight while executing these dynamic maneuvers requires precise control. Proportional-Integral-Derivative (PID) controllers, ubiquitous in drone flight systems, are derived directly from control theory. These mathematical algorithms continually adjust motor speeds based on the “error” between the desired state (e.g., target altitude, heading) and the current measured state. The proportional term reacts to the current error, the integral term accounts for past errors (to eliminate steady-state offset), and the derivative term anticipates future errors based on the rate of change. Each term’s contribution is weighted by a gain, and tuning these gains is a delicate mathematical balance to achieve stable and responsive control. Thus, “means in math” in this context refers to the exact mathematical rules that dictate how the drone corrects its flight to achieve its objective reliably.
Autonomous Flight: Navigating with Algorithms
Autonomous flight represents a pinnacle of drone technology, enabling UAVs to operate without direct human intervention. From automated takeoff to precision landing, and through complex missions, these drones rely on sophisticated mathematical models and algorithms to understand their environment, localize themselves within it, and plan safe, efficient trajectories.
Simultaneous Localization and Mapping (SLAM)
One of the most profound “means in math” enabling autonomous flight is Simultaneous Localization and Mapping (SLAM). For a drone to navigate autonomously in an unknown environment, it must continuously answer two fundamental questions: “Where exactly am I?” and “What does the surrounding world look like?” SLAM algorithms simultaneously build a detailed map of the environment while tracking the drone’s own location within that evolving map. This is an inherently challenging chicken-and-egg problem, successfully tackled through a powerful combination of geometry, linear algebra, and probabilistic inference.
Techniques like Extended Kalman Filters (EKF-SLAM) or Graph-Based SLAM (e.g., factor graphs) process diverse sensor data (from cameras, LiDAR, inertial measurement units – IMUs) to estimate both the drone’s pose (position and orientation) and the precise positions of significant features in the environment. EKF-SLAM uses mathematical models to predict the drone’s movement and sensor observations, then corrects these predictions based on actual measurements, continually updating the “mean” and covariance (uncertainty) of the drone’s state and map features. Graph-Based SLAM, on the other hand, represents the drone’s trajectory and landmark observations as a sophisticated network, and then optimizes the entire graph to find the most globally consistent arrangement. These advanced mathematical frameworks allow autonomous drones to construct dynamic, real-time representations of their surroundings, which are absolutely essential for robust collision avoidance and complex mission execution.
Control Theory and Stability

Beyond knowing its location, an autonomous drone must actively control its flight with extreme precision. Control theory, a field rich in calculus and differential equations, provides the mathematical tools for designing systems that can maintain stability and achieve desired performance objectives despite external disturbances or internal uncertainties. For multi-rotor drones, this involves meticulously managing the forces generated by each propeller to achieve specific attitude (roll, pitch, yaw) and position changes.
Modern flight controllers utilize comprehensive mathematical models of the drone’s dynamics, often expressed as sets of coupled differential equations, to accurately predict its response to various motor inputs. State-space representation, a key concept in modern control theory, employs vectors and matrices to concisely model the system’s behavior, allowing for comprehensive analysis and robust control design. Linear quadratic regulator (LQR) techniques, for example, calculate optimal control inputs by minimizing a quadratic cost function that judiciously balances control effort and deviation from the desired state. Robust control methods further apply sophisticated mathematical principles to guarantee stability and performance even when the drone’s physical parameters or environmental conditions are uncertain. These sophisticated mathematical “means” guarantee that an autonomous drone can consistently and accurately execute its planned trajectory, even in challenging and dynamic operational conditions.
Precision in Drone Mapping and Remote Sensing
Drone technology has profoundly revolutionized mapping and remote sensing, providing unprecedented capabilities for data collection and analysis across a multitude of industries. The accuracy, reliability, and ultimate utility of these applications are profoundly rooted in fundamental mathematical principles, transforming vast amounts of raw sensor data into actionable and invaluable insights.
Photogrammetry: From Pixels to 3D Models
Photogrammetry, the science of making precise measurements from photographs, is a prime example of “means in math” meticulously applied to drone imaging. When a drone captures a series of overlapping images of a terrain or structure, specialized software employs sophisticated mathematical algorithms to accurately reconstruct a detailed 3D model of the surveyed area. This intricate process involves several critical mathematical steps:
- Feature Detection and Matching: Algorithms such as SIFT (Scale-Invariant Feature Transform) or SURF (Speeded Up Robust Features) utilize advanced mathematical descriptors to identify unique, stable points across multiple images, invariant to scale and rotation changes. These algorithms leverage concepts from linear algebra, image processing, and differential geometry.
- Bundle Adjustment: This is a sophisticated and complex optimization problem that simultaneously refines the 3D coordinates of scene points, the camera’s external orientation (its precise position and rotation in space), and its internal parameters (focal length, lens distortion). It minimizes the total re-projection error (the difference between observed image points and the mathematically projected 3D points) using non-linear least squares optimization, a powerful numerical method rooted in multivariable calculus.
- Dense Point Cloud Generation: Once camera positions and the overall scene structure are accurately estimated, dense matching algorithms (often based on stereo vision principles) use trigonometry and projective geometry to calculate the precise 3D coordinates for millions of individual pixels, generating an incredibly detailed point cloud.
- Orthomosaic and Digital Surface Model (DSM) Creation: The generated point cloud is then mathematically processed to create an orthomosaic (a geometrically corrected aerial image with uniform scale) and a DSM (a 3D model representing the elevation of natural and artificial features). These transformations involve projecting 3D points onto a 2D plane and vice versa, requiring a precise understanding of coordinate systems and various geometric transformations (affine and projective geometry).
These mathematical “means” enable everything from precision agriculture and detailed construction site monitoring to comprehensive urban planning and environmental surveying, providing highly accurate, quantifiable, and indispensable data.
Data Interpretation through Statistical Means
Remote sensing with drones goes far beyond just capturing images; it crucially involves interpreting the collected data to derive meaningful and actionable information. This is where statistical “means” become absolutely vital. Multispectral and hyperspectral sensors collect data across various electromagnetic spectrum bands, with each band revealing distinct properties of the observed surface materials.
Analyzing this multi-band data often involves:
- Spectral Indices: Mathematical combinations of reflectances from different bands (e.g., the Normalized Difference Vegetation Index – NDVI) are used to quantitatively assess vegetation health, water content, or soil properties. These indices are direct mathematical formulas applied to pixel values.
- Classification and Clustering: Algorithms like K-means clustering (an unsupervised machine learning technique) or Support Vector Machines (SVMs, a supervised learning method) employ statistical distances and mathematical boundaries to group pixels into distinct land cover classes. These powerful methods are deeply rooted in multivariate statistics and optimization theory.
- Time Series Analysis: When monitoring environmental changes or infrastructure integrity over time, sophisticated statistical techniques are employed to identify trends, anomalies, and rates of change. This involves advanced statistical modeling and hypothesis testing to extract meaningful information from sequences of collected data.
Through these statistical and mathematical “means,” remote sensing data can be transformed from raw numerical values into powerful insights for informed decision-making across diverse fields, demonstrating how quantitative analysis is fundamental to understanding and managing our world through the sophisticated lens of drone technology.
The Interplay of Mathematics and Innovation
The phrase “what does means in math” within the context of drone technology ultimately signifies the indispensable and pervasive role of quantitative reasoning, precise definitions, and algorithmic thinking. Every advanced feature, from seamless autonomous navigation to sophisticated data analytics, is meticulously built upon a foundational bedrock of mathematical principles.
Innovation in drone technology is not merely about developing novel hardware components; it is equally, if not more, about pioneering new mathematical models and algorithms that unlock unprecedented capabilities. Advancements in artificial intelligence, for instance, are intrinsically linked to breakthroughs in linear algebra, calculus, and optimization theory that enable more efficient neural networks and smarter, more adaptive decision-making processes. Similarly, enhancing the accuracy of mapping or the reliability of autonomous flight often involves meticulously refining existing mathematical frameworks or devising entirely new ones to handle greater levels of complexity and uncertainty.
Understanding the “means in math” is therefore absolutely crucial for anyone involved in developing, operating, or even simply appreciating the cutting edge of drone technology. It reveals that the smooth, seemingly effortless operations of modern drones are the direct result of rigorous mathematical engineering, transforming abstract concepts into tangible, powerful tools that are reshaping industries and continually pushing the boundaries of what is possible in the skies. The ongoing evolution of drone capabilities will undoubtedly continue to be driven by an ever-deepening reliance on and innovation within the mathematical sciences.