
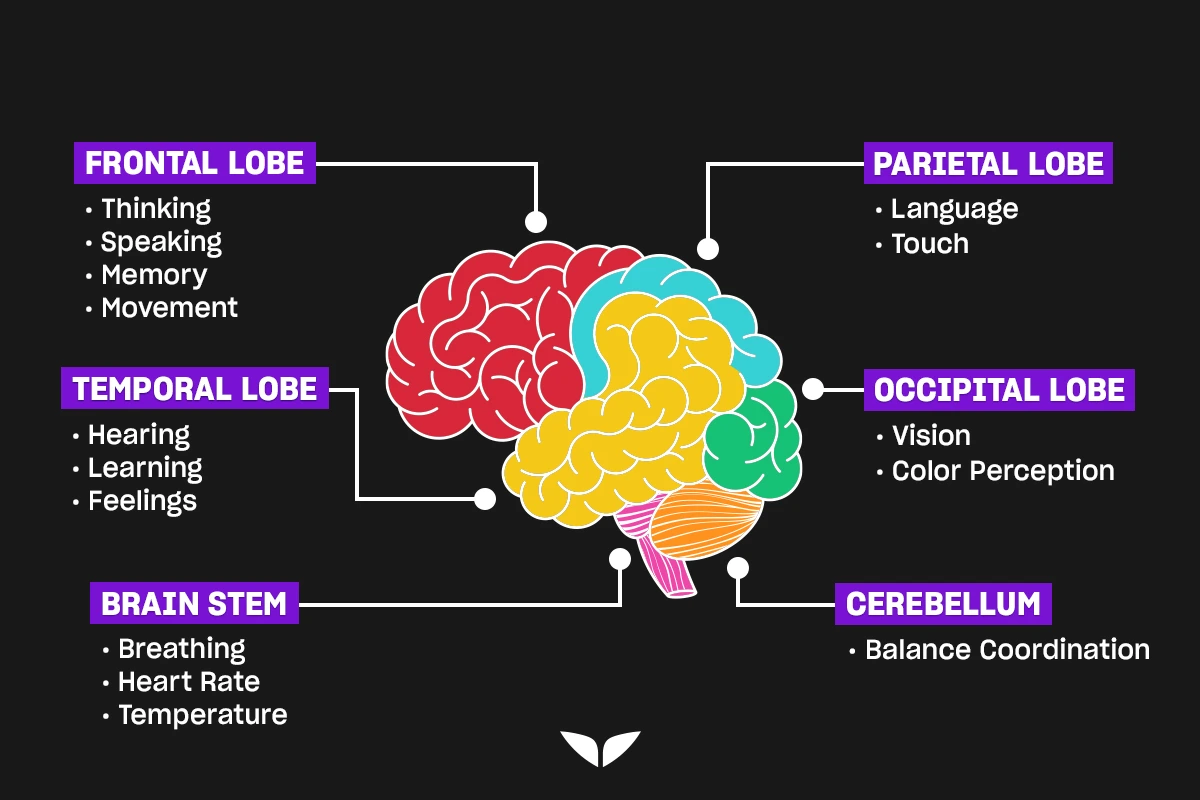
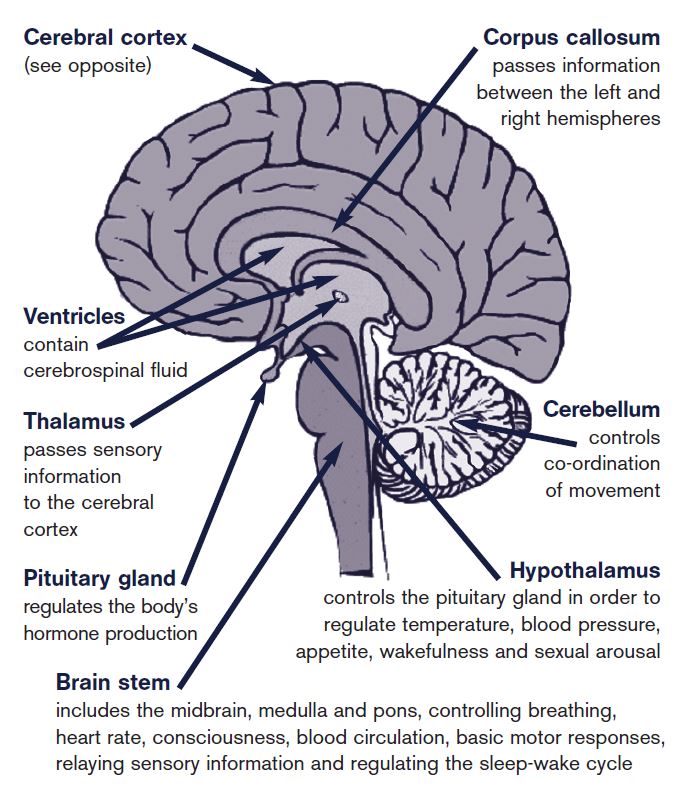
In the sophisticated world of unmanned aerial vehicles (UAVs), a drone’s ability to navigate, stabilize, and perform complex tasks stems from an intricate web of interconnected flight technologies. Much like the specialized regions of a biological brain, each component within a drone’s flight system plays a distinct and crucial role, working in concert to achieve seamless and intelligent operation. Understanding these “parts of the brain” and their functions is key to appreciating the engineering marvel behind modern flight.
The Brain’s Core: Flight Controllers and Embedded Processors
At the very heart of any drone’s flight technology lies the flight controller, an embedded computer system that serves as the central processing unit and decision-maker. Analogous to the cerebrum, this sophisticated board receives, processes, and interprets data from a myriad of onboard sensors, then translates that information into precise commands for the drone’s motors and other actuators.
Flight controllers vary widely in complexity and capability, from basic open-source boards used by hobbyists to highly integrated, proprietary systems found in advanced enterprise and industrial drones. Regardless of their scale, their fundamental task remains the same: to maintain stable flight, execute pilot commands, and enable autonomous functions. They run specialized firmware (such as ArduPilot, PX4, or DJI’s custom operating systems) that contains complex algorithms for attitude control, navigation, and mission planning. These algorithms are continuously calculating factors like pitch, roll, yaw, altitude, and speed, making instantaneous adjustments hundreds of times per second to ensure the drone remains stable and responsive. Without this central processing unit, the drone would be nothing more than a collection of uncoordinated parts.
Sensory Systems: Navigation, Positioning, and Environmental Awareness
For the flight controller to make informed decisions, it relies heavily on an array of sensory inputs that provide comprehensive data about the drone’s position, orientation, and surrounding environment. These sensors are the drone’s eyes, ears, and proprioceptors, constantly feeding vital information to its “brain.”
Global Navigation Satellite Systems (GNSS): The Drone’s GPS Sense
GNSS modules, commonly referred to by their most famous component, GPS (Global Positioning System), are indispensable for outdoor drone operations. These systems enable a drone to determine its precise geographical location on Earth by receiving signals from a constellation of orbiting satellites. Beyond GPS, modern drones often integrate with other GNSS systems like GLONASS (Russia), Galileo (Europe), and BeiDou (China) to enhance accuracy and signal reliability, especially in challenging environments.
The GNSS module allows the flight controller to execute critical functions such as waypoint navigation, enabling the drone to follow pre-programmed flight paths with remarkable precision. It facilitates automated return-to-home features, where the drone can autonomously fly back to its takeoff point if signal is lost or battery levels are low. Furthermore, GNSS data is crucial for geofencing, preventing the drone from entering restricted airspace, and for maintaining position hold, where the drone actively resists wind and stays stationary in the air without manual input.
Inertial Measurement Units (IMUs): Perceiving Motion and Orientation
The Inertial Measurement Unit (IMU) is a critical sensor package that provides the flight controller with essential data about the drone’s movement and orientation in three-dimensional space. An IMU typically comprises three main components:
- Accelerometers: Measure linear acceleration along three axes, detecting changes in velocity and gravity. This data is used to determine the drone’s tilt and overall movement.
- Gyroscopes: Measure angular velocity or rotational changes around three axes (pitch, roll, and yaw). Gyroscope data is vital for stabilizing the drone and correcting any unwanted rotations.
- Magnetometers: Function as an electronic compass, measuring the strength and direction of the Earth’s magnetic field to determine the drone’s heading or yaw orientation.
The flight controller employs sophisticated sensor fusion algorithms to combine the data from these three components. This fusion process filters out noise and compensates for the inherent drift of individual sensors, providing a highly accurate and reliable estimate of the drone’s attitude (orientation) and velocity. The IMU is fundamental for maintaining stable flight, responding accurately to control inputs, and compensating for external disturbances like wind gusts.
Barometers and Altimeters: Understanding Altitude
To accurately determine its vertical position, a drone utilizes barometers and, in some cases, dedicated altimeters. Barometers are pressure sensors that measure atmospheric pressure, which correlates directly with altitude. By detecting changes in air pressure, the flight controller can estimate the drone’s relative altitude above its takeoff point, enabling it to maintain a consistent height or ascend/descend to specific levels.
For more precise altitude measurements, especially close to the ground, some drones incorporate ultrasonic or lidar (Light Detection and Ranging) altimeters. Ultrasonic sensors emit sound waves and measure the time it takes for them to bounce back, providing highly accurate ground clearance data, particularly useful during landing maneuvers or terrain-following operations. Lidar altimeters use laser pulses for similar, often more precise, measurements over a wider range. These systems are crucial for automated landings, precise low-altitude flights, and maintaining safe distances from obstacles below.
Vision Systems and Obstacle Avoidance: Seeing the World
As drones become more autonomous and operate in increasingly complex environments, vision systems and obstacle avoidance technologies have become paramount. These systems equip the drone with a form of “sight,” allowing it to detect and react to its surroundings.

Various sensors are employed for this purpose, including stereo cameras (providing depth perception), monocular cameras (often used with machine learning for object recognition), Time-of-Flight (ToF) sensors, lidar, and ultrasonic sensors. These systems work by mapping the environment in real-time, identifying potential collision threats, and relaying this information to the flight controller.
Upon detecting an obstacle, the flight controller can initiate automatic braking, rerouting, or hovering maneuvers to prevent a collision. Vision systems also play a crucial role in precise landing, terrain following, and indoor navigation where GNSS signals are unavailable. Optical flow sensors, which analyze visual patterns on the ground, enable highly stable hovering in GNSS-denied environments by tracking movement relative to the surface below. Advanced systems often integrate AI and machine learning algorithms to distinguish between different types of objects, enabling more intelligent and context-aware avoidance strategies.
The Motor Cortex: Actuation and Stabilizing Mechanisms
Once the flight controller has processed all sensory data and made its decisions, it must then translate those decisions into physical actions. This is where the actuation systems come into play, serving as the drone’s “motor cortex” – the part of the brain responsible for executing movement.
Electronic Speed Controllers (ESCs) and Motors: Powering Movement
The primary actuators responsible for drone movement are the brushless motors, each connected to a propeller. However, these motors don’t operate directly from the flight controller’s commands. Instead, they are managed by Electronic Speed Controllers (ESCs). Each ESC is an individual microcontroller that receives signals from the flight controller and precisely regulates the power delivered to its corresponding motor.
By adjusting the speed and direction of rotation for each motor, the flight controller can precisely control the drone’s lift, pitch (forward/backward tilt), roll (side-to-side tilt), and yaw (rotation around its vertical axis). For instance, to move forward, the flight controller instructs the front motors to spin slower and the rear motors faster, tilting the drone forward. To ascend, all motors spin faster in unison. This dynamic and coordinated control of multiple motors is fundamental to multirotor flight and enables the drone to perform complex aerial maneuvers.
Gimbal Stabilization: Isolating Payloads
While not directly controlling the drone’s flight path, gimbal stabilization systems are a vital part of a drone’s overall stabilization technology, particularly for professional applications involving cameras or other sensors. A gimbal is a motorized mount that holds a payload (e.g., a camera) and uses a set of gyroscopes and brushless motors to counteract the drone’s movements and vibrations.
The gimbal’s independent gyroscopes detect any changes in the drone’s pitch, roll, and yaw, and its motors then rapidly adjust the camera’s orientation in the opposite direction. This constant, real-time stabilization ensures that the camera remains perfectly level and steady, even as the drone pitches, rolls, or vibrates during flight. This is crucial for capturing smooth, professional-grade aerial footage, collecting undistorted photogrammetry data, or maintaining a stable line of sight for inspection sensors.
The Communication Network: Data Links and Telemetry
Just as the brain communicates with the rest of the body, a drone’s flight technology includes robust communication pathways that enable interaction with its human operator and other systems. These data links are essential for command, control, and real-time monitoring.
Command and Control Link: Pilot to Drone
The command and control link is the communication channel through which the pilot’s inputs from the remote controller are transmitted to the drone’s flight controller. This typically operates over radio frequencies (commonly 2.4 GHz or 5.8 GHz, sometimes 900 MHz for longer range). These links are often encrypted to prevent unauthorized access and interference, ensuring that only the authorized pilot can control the drone. The remote controller translates the physical movements of its joysticks and switches into digital commands that the drone’s flight controller understands and executes. This direct link is fundamental for manual flight operations and overrides of autonomous modes.
Telemetry and Video Downlink: Drone to Pilot
Equally important is the telemetry and video downlink, which transmits critical information from the drone back to the pilot or ground station. Telemetry data includes real-time flight parameters such as altitude, speed, GPS coordinates, battery voltage, motor RPMs, and sensor status. This information is typically displayed on the pilot’s remote controller screen or a connected mobile device, providing crucial situational awareness and allowing the pilot to monitor the drone’s health and performance.
The video downlink transmits a live feed from the drone’s camera (often called First-Person View or FPV) back to the pilot. This allows the pilot to “see” from the drone’s perspective, which is vital for precise maneuvers, aerial photography framing, and navigating beyond visual line of sight (though strict regulations apply to BVLOS flights). The quality and latency of the video downlink are critical for immersive control and safe operation.
Advanced Data Transmission: Beyond Line of Sight
For more advanced applications, traditional radio links are augmented or replaced by cellular technologies like LTE and 5G. These advanced data transmission methods enable drones to operate over much greater distances, often beyond the pilot’s visual line of sight (BVLOS), by connecting to the internet and cloud-based systems. This opens up possibilities for widespread drone delivery networks, large-scale infrastructure inspection, remote sensing over vast areas, and coordinated swarm operations where multiple drones communicate with each other and a central command center via cloud infrastructure. These systems integrate the drone into a broader digital ecosystem, pushing the boundaries of what autonomous flight can achieve.