
In the vast and ever-evolving landscape of technology and innovation, understanding fundamental networking concepts is paramount, even for cutting-edge fields like drone technology. One such foundational concept is “localhost” and its associated IP address. While seemingly simple, “localhost” plays an indispensable role in the development, testing, and deployment cycles of advanced drone systems, AI follow modes, autonomous flight algorithms, mapping solutions, and remote sensing applications. At its core, localhost refers to the current computer used to access it, and its standard Internet Protocol (IP) address is 127.0.0.1 for IPv4, and ::1 for IPv6. This seemingly abstract concept is a critical cornerstone for local development, simulation, and robust system integrity within the demanding world of drone innovation.

Unpacking the Concept of Localhost
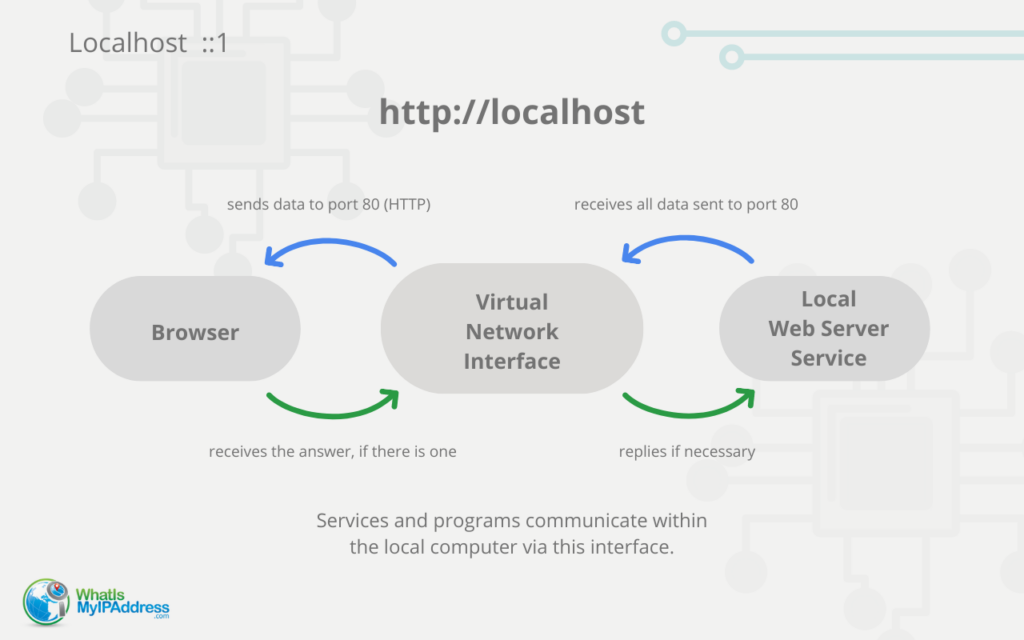
Localhost is a universally recognized hostname that refers to the “local computer” or “this computer.” It is a loopback address, meaning that any data sent to localhost is immediately “looped back” to the sending device itself. Instead of traversing a network interface card (NIC) and potentially reaching an external network, the data is routed internally within the operating system’s network stack. This internal loopback mechanism is incredibly efficient and serves several crucial purposes in software development and system administration.
The primary IPv4 address associated with localhost is 127.0.0.1. This address is reserved for the loopback interface, meaning it will never be assigned to a device on a public network. No matter where you are or what device you are using, 127.0.0.1 always refers to the machine you are currently operating. This consistency makes it an invaluable tool for developers. The IPv6 equivalent, ::1, serves the exact same purpose within IPv6 networks, providing a dedicated loopback address for the newer protocol. The loopback interface itself doesn’t require a physical network adapter to function; it’s a software-defined interface managed by the operating system. This intrinsic characteristic makes it ideal for developing and testing applications that require network communication without needing an active external network connection or risking interference with live network traffic.
The Indispensable Role of Localhost in Drone Tech Development
For innovators pushing the boundaries of drone technology, localhost is far more than just a technical curiosity; it’s a daily workhorse. Developing sophisticated features like AI-powered obstacle avoidance, dynamic path planning for autonomous flight, or advanced data fusion for remote sensing often begins in a local, controlled environment. Localhost provides precisely this. Developers can run their server-side applications, data processing pipelines, or even simulated drone components directly on their development machines. This allows for rapid iteration, debugging, and performance tuning without the complexities of deploying to a remote server or a physical drone. For instance, an AI engineer building an object recognition module for a drone’s vision system might serve simulated camera feeds to their local AI model via a web server running on localhost. This setup enables swift testing of new algorithms and model weights, ensuring functionality before integrating with actual drone hardware.
Localhost in Simulation and Testing Environments
The domain of drones, especially autonomous systems, heavily relies on robust simulation for safe and efficient development. Software-in-the-Loop (SITL) and Hardware-in-the-Loop (HITL) simulations are critical for validating flight controllers, navigation algorithms, and sensor integration before actual flight. Localhost is the backbone of many SITL setups. A virtual drone, its sensors, and its environment can be simulated as separate software components running on the same machine. These components communicate with each other using TCP/IP or UDP protocols, with localhost (127.0.0.1) acting as the network address for all internal communication.
Consider a developer refining an autonomous landing algorithm. They can run a flight controller simulator on their machine, which communicates with a physics engine simulator, a GPS simulator, and an AI decision-making module – all via localhost. The AI module might receive simulated sensor data from the physics engine through 127.0.0.1, process it, and then send control commands back to the flight controller simulator on the same loopback address. This creates a closed-loop testing environment that accurately mimics real-world interactions without the risks, costs, or logistical challenges of physical testing. This capability accelerates the development cycle, allowing for continuous integration and testing of complex drone behaviors and safety protocols.
Securing Localhost in Networked Drone Systems
While localhost primarily refers to internal communication, its implications for security are not to be overlooked, especially as drone systems become increasingly networked and sophisticated. Development environments often host proprietary code, sensitive algorithms, and critical configuration files. Even if services are configured to listen only on localhost, misconfigurations or vulnerabilities in the underlying operating system could potentially expose these services. For example, if a developer runs a local web server on 127.0.0.1 to test a drone’s ground control interface, and that server has a security flaw, it could be exploited if an attacker gains local access to the machine.
Therefore, best security practices extend even to local development. This includes regular patching of operating systems and development tools, using strong authentication for any local services that require logins, and understanding network configurations to ensure that services intended for localhost do not inadvertently bind to external network interfaces. As drone innovation moves towards more interconnected ecosystems, with data being processed locally before transmission to cloud platforms or other ground stations, maintaining the integrity and security of localhost-based services is crucial for protecting intellectual property and preventing potential compromises of drone operations.
Beyond 127.0.0.1: IPv6 and Loopback Evolution
The evolution of network technology brings us to IPv6, the successor to IPv4, designed to address the exhaustion of IPv4 addresses and offer enhanced features. Just as 127.0.0.1 is the reserved loopback address for IPv4, ::1 serves the same function for IPv6. The transition to IPv6 is slowly but surely impacting all aspects of networking, including specialized applications in drone technology and remote sensing.
IPv6 offers a vastly larger address space, which is increasingly relevant as drone fleets grow, sensor networks expand, and the Internet of Things (IoT) integrates more deeply into drone operations. More sophisticated local network setups for complex simulations or multi-component drone systems might leverage IPv6 for clearer addressing and potentially more efficient routing within a machine. For instance, a drone ground control station might run several microservices locally, each communicating via IPv6 localhost, offering a robust and scalable internal communication architecture. Understanding both 127.0.0.1 and ::1 ensures that developers can build applications compatible with current and future networking paradigms, future-proofing their drone innovations.
Practical Applications in Drone Innovation
The abstract concept of localhost truly comes to life when we consider its concrete applications within the “Tech & Innovation” category of drone technology:
AI Follow Mode Development
Developing advanced AI follow modes requires extensive testing of computer vision algorithms, object tracking, and predictive movement. A common setup involves serving simulated video streams or image sequences to an AI model running on the development machine. The AI model itself might be hosted on a local server, accessible via 127.0.0.1. This allows developers to rapidly fine-tune the AI’s parameters, test different tracking strategies, and debug complex algorithms without needing a physical drone or an active network connection, accelerating the path to robust AI-driven autonomous features.
Autonomous Flight System Prototyping
Autonomous flight is the pinnacle of drone innovation, demanding rigorous testing of flight controllers, navigation systems, and decision-making logic. As discussed, Software-in-the-Loop (SITL) simulation is indispensable here. The various components of an autonomous flight stack—such as the flight controller software, sensor models (GPS, IMU, LiDAR), environmental simulators, and path planning algorithms—can all run as separate processes on a single computer. Their inter-process communication, often using standard network protocols, is facilitated by localhost. This enables engineers to validate the entire autonomous flight pipeline in a controlled, repeatable environment, identifying and resolving issues long before expensive hardware testing.
Mapping and Geospatial Data Processing
Drones are revolutionizing mapping and surveying by capturing high-resolution imagery and LiDAR data. The subsequent processing of this data, which often involves photogrammetry, 3D model generation, and geospatial analysis, typically occurs on powerful local workstations. Mapping software might run local servers to manage large datasets, serve processed maps, or provide web-based interfaces for visualization, all accessible via localhost. Developers can quickly test new algorithms for stitching images, correcting distortions, or classifying terrain types against local datasets, ensuring efficiency and accuracy before scaling to larger projects or cloud-based solutions.
Remote Sensing Data Analysis
Remote sensing involves collecting data from a distance, often using specialized sensors on drones (e.g., multispectral, thermal, hyperspectral). The development of tools and algorithms to analyze this unique data often begins locally. Researchers might build custom data processing pipelines that ingest simulated or previously collected remote sensing data from a local file system, serving it to an analysis application running on localhost. This allows for the rapid development of algorithms for crop health monitoring, environmental assessment, or infrastructure inspection, providing immediate feedback on processing results and algorithm efficacy.
Edge Computing for Onboard Intelligence
As drones become more intelligent, there’s a growing trend towards edge computing – processing data directly on the drone itself using companion computers. When developing and testing edge-computing modules, engineers often replicate the drone’s onboard environment on a development machine. The edge computing application might simulate interaction with the drone’s flight controller or sensors using localhost communication, allowing for the refinement of algorithms for real-time decision-making, object detection, or data compression before deployment to the drone’s limited onboard resources.
In essence, whether it’s developing groundbreaking AI, perfecting autonomous navigation, refining mapping precision, or enhancing remote sensing capabilities, the humble IP address of localhost—127.0.0.1 (or ::1)—is an unsung hero. It underpins the local development, rigorous testing, and secure prototyping environments that are absolutely essential for pushing the frontiers of drone innovation.