
In the dynamic realm of autonomous systems, particularly within drone technology and innovation, the concept of “implied volatility” extends far beyond its traditional financial market definition. Here, it refers to the sophisticated algorithmic frameworks and predictive models that drones utilize to infer and quantify the degree of unpredictability, dynamism, and uncertainty within their operational environment or the behavior of their targets. It’s not a single, static equation, but a complex, adaptive “formula” that enables drones to anticipate, rather than merely react, to the ever-changing world around them, making autonomous flight safer, more efficient, and incredibly versatile.
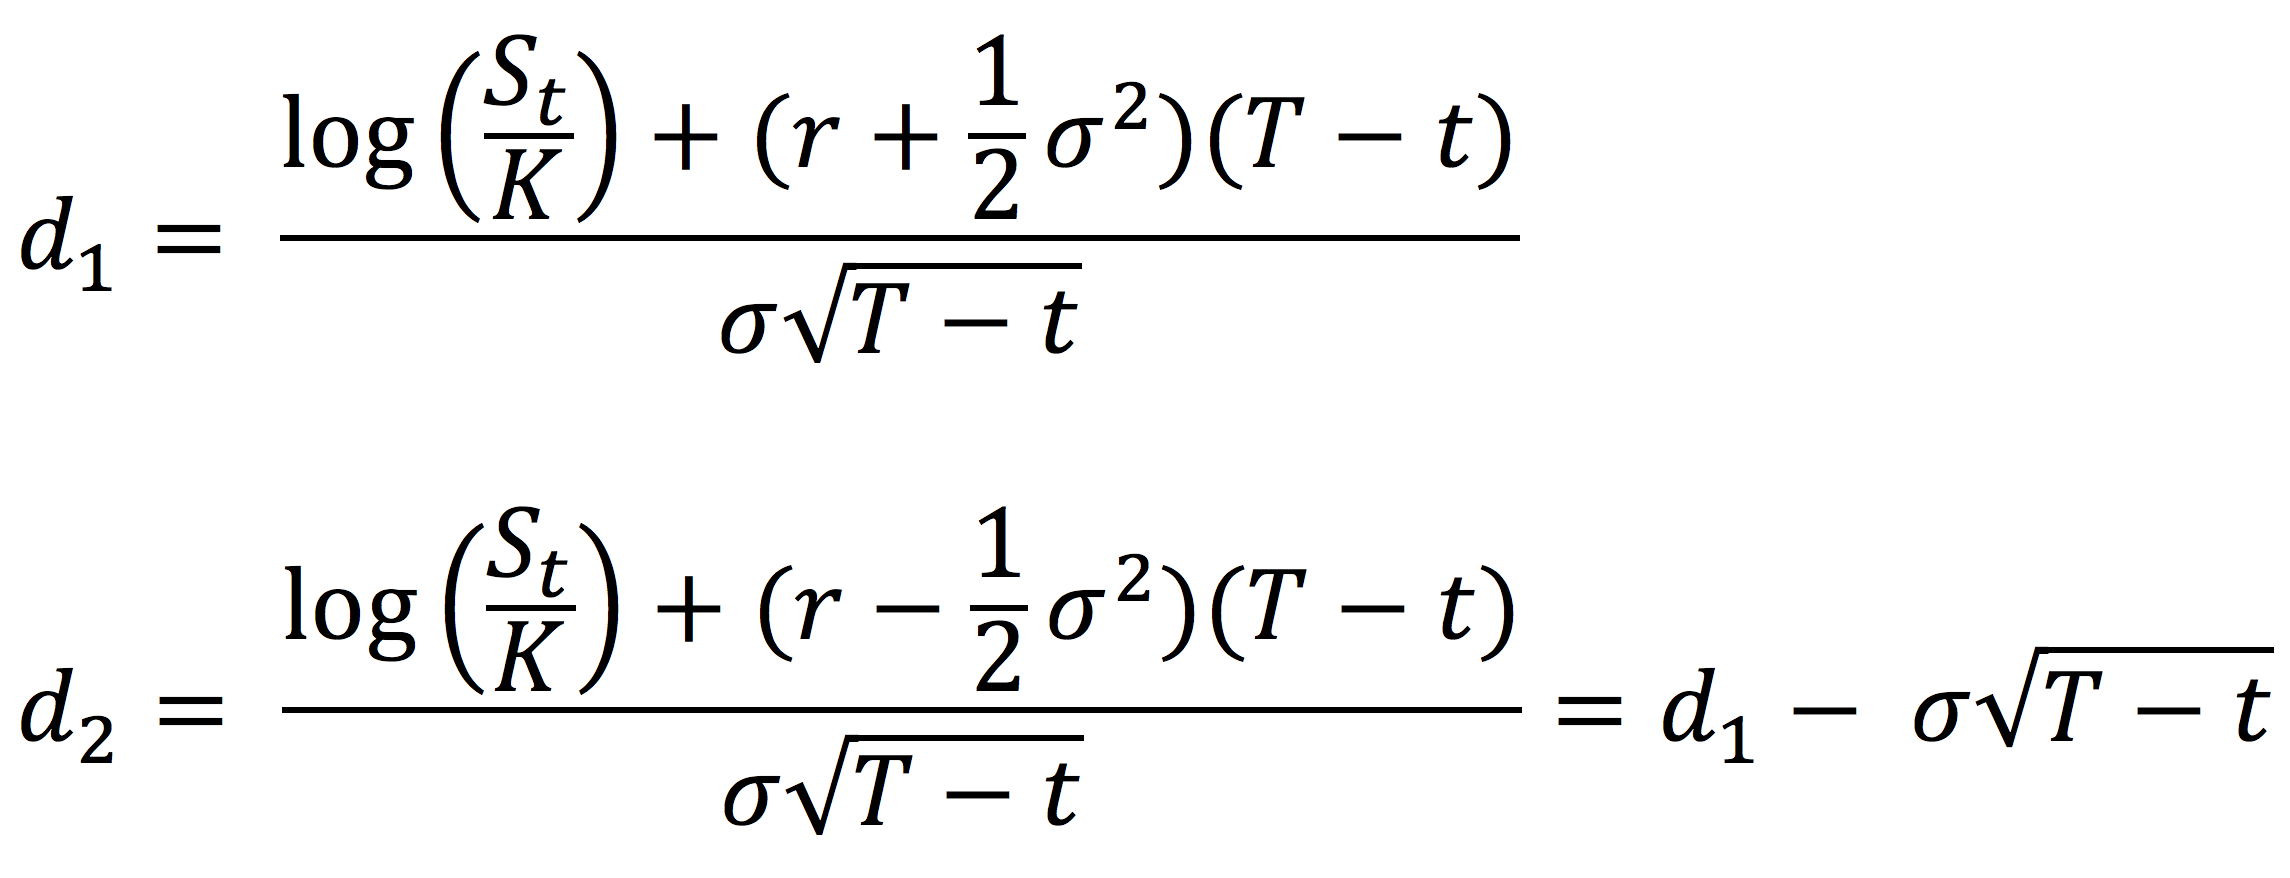
Defining Volatility in Autonomous Drone Operations
For an autonomous drone, “volatility” isn’t about stock price fluctuations; it’s about the inherent unpredictability of the physical world. This encompasses a broad spectrum of dynamic elements that can impact mission success and safety.
Beyond Financial Markets: A Drone Perspective
From a drone’s standpoint, volatility manifests in several critical areas:
- Environmental Dynamics: Rapid shifts in wind speed or direction, sudden changes in light conditions affecting visual sensors, unexpected precipitation, or the sudden appearance of fog.
- Obstacle and Terrain Volatility: Unforeseen objects appearing in the flight path, dynamic changes in terrain (e.g., shifting sand, melting snow), or the unpredictable movement of non-cooperative obstacles like birds or other unpiloted aircraft.
- Target Behavior: When a drone is in AI follow mode, tracking a person, vehicle, or animal, the subject’s movement patterns can be highly volatile—sudden stops, accelerations, changes in direction, or occlusions.
- Sensor Noise and System Uncertainty: Even with advanced sensors, inherent noise and measurement errors introduce a degree of uncertainty. Internal system health, battery degradation, or minor mechanical shifts can also add to operational volatility.
The need for drones to not just react but to proactively infer and quantify these forms of volatility is paramount. Reactive systems, by their nature, will always lag behind events, increasing the risk of collisions or mission failure. Proactive inference, guided by an “implied volatility formula,” allows a drone to make informed, forward-looking decisions.
The Need for Inference
The human brain excels at inferring future states based on current observations and past experiences—we anticipate a ball’s trajectory or a car’s next turn. Autonomous systems require a similar capability, formalized through algorithms. This inference is crucial for:
- Safety: Anticipating a sudden gust of wind or an unexpected obstacle allows for evasive maneuvers well in advance.
- Efficiency: Optimizing flight paths and energy consumption by predicting environmental resistance or target movements.
- Precision: Maintaining stable tracking or precise navigation despite unpredictable external factors.
- Robustness: Ensuring reliable operation in a wide range of challenging and dynamic environments.
Algorithmic Foundations of Volatility Inference
The “implied volatility formula” in drone tech is not a singular mathematical expression but a sophisticated blend of probabilistic models, statistical methods, and advanced machine learning algorithms. These frameworks process raw sensor data to construct a probabilistic understanding of the present state and, crucially, predict the likelihood and nature of future states.
Probabilistic Models as the “Formula”
At the core of quantifying uncertainty are algorithms that manage and propagate probabilities:
- Kalman Filters and Extended Kalman Filters (EKF): These are foundational for state estimation. They work by iteratively predicting a drone’s state (position, velocity, orientation) and then updating that prediction with noisy sensor measurements. The filter’s internal covariance matrix is a direct representation of the “implied volatility” – the uncertainty in its state estimate. A larger covariance indicates higher uncertainty or volatility in the environment or system. EKFs extend this to non-linear systems, making them more suitable for complex drone dynamics.
- Particle Filters: For highly non-linear or non-Gaussian systems where EKFs struggle, particle filters offer a more robust solution. They represent the probability distribution of a drone’s state (and thus its implied volatility) using a set of weighted “particles” or hypotheses. This allows them to capture complex, multi-modal uncertainties, like predicting which of several paths a target might take.
- Machine Learning and Deep Learning: Modern “implied volatility formulas” heavily leverage AI.
- Recurrent Neural Networks (RNNs) and Long Short-Term Memory (LSTM) networks: Excel at processing time-series data. They learn patterns in historical sensor data (e.g., wind patterns, target movement history) to predict future trends, effectively inferring and quantifying environmental or behavioral volatility.
- Convolutional Neural Networks (CNNs): Used for processing visual data (images, video streams) to identify and classify dynamic obstacles, helping to predict their future positions or behaviors.
- Reinforcement Learning (RL): Drones can learn optimal policies for navigating volatile environments through trial and error in simulated or real-world scenarios. The reward functions in RL often implicitly penalize high volatility or reward successful navigation through it, thus refining the drone’s internal “volatility formula.”
Quantifying Uncertainty
Within these algorithmic frameworks, “implied volatility” is quantified using various metrics:
- Standard Deviation: In Kalman filters, the standard deviation of state estimates within the covariance matrix indicates the dispersion of possible future states.
- Entropy: In probabilistic distributions, higher entropy signifies greater uncertainty or unpredictability—a direct measure of implied volatility.
- Prediction Error Rates: Algorithms continuously track their prediction accuracy. Higher historical or real-time prediction errors can indicate higher underlying volatility that the model needs to account for.
Practical Applications in Advanced Drone Systems
The insights generated by the “implied volatility formula” are critical for enhancing virtually every aspect of autonomous drone operation.
Adaptive Path Planning and Collision Avoidance
When an autonomous drone navigates through complex or dynamic environments (e.g., dense forests, urban canyons, or areas with unpredictable air traffic), its “implied volatility formula” constantly assesses the likelihood of encountering obstacles or sudden environmental changes.
- If the formula indicates high implied volatility (e.g., a path with many occluded areas, strong fluctuating winds), the drone might proactively adjust its flight plan. This could involve reducing speed, increasing altitude, choosing a wider, more conservative trajectory, or allocating more processing power to real-time sensor analysis.
- In collision avoidance, predicting the “volatility” of an object’s trajectory (e.g., another drone, a bird) allows the system to initiate evasive maneuvers much earlier and with greater confidence, ensuring safer separation distances.
Enhanced AI Follow Mode
For drones tasked with following a moving subject, the “implied volatility formula” is indispensable. It predicts the subject’s probable future movements based on current velocity, acceleration, and historical patterns.
- If the formula detects high implied volatility (e.g., the subject is moving erratically, frequently changing direction, or visibility is low), the drone can adapt its tracking strategy. This might mean maintaining a larger safe distance, adjusting camera gimbal speeds to pre-compensate for anticipated subject movement, or predicting potential occlusions to prepare for reacquisition.
- Conversely, if volatility is low, the drone can maintain closer proximity and smoother camera work, optimizing for cinematic quality or precise data capture.
Dynamic Resource Allocation

Autonomous drones have finite computational, energy, and sensor resources. The “implied volatility formula” can help optimize their use.
- In environments with high implied volatility, the drone’s AI might dynamically allocate more processing power to its perception and planning modules, run state estimation algorithms more frequently, or activate redundant sensor systems for cross-verification.
- In low-volatility scenarios, resources can be conserved, allowing for longer flight times or prioritizing other tasks like data transmission or advanced analytics.
Gimbal Stabilization and Camera Control
Even on stable platforms, precise camera control is vital for high-quality imaging. The “implied volatility formula” contributes to smoother footage by predicting platform movements or target movements.
- By inferring the “volatility” of anticipated drone vibrations or external perturbations, gimbals can pre-compensate with micro-adjustments, ensuring the camera remains perfectly stable, even in turbulent conditions or during aggressive maneuvers. This translates directly to professional-grade aerial photography and videography.
Data Inputs, Learning, and Continuous Refinement
The accuracy and efficacy of an “implied volatility formula” are directly dependent on the quality and richness of its data inputs, and its ability to continuously learn and adapt.
Sensor Fusion as Input
The “formula” operates on a rich tapestry of data derived from multiple onboard sensors, a process known as sensor fusion:
- Lidar and Radar: Provide precise distance and velocity measurements, crucial for detecting obstacles and mapping terrain, enabling the prediction of spatial volatility.
- Visual Cameras: Offer contextual information, object recognition, and tracking capabilities, allowing for the inference of behavioral volatility from moving subjects.
- Inertial Measurement Units (IMUs) and GPS: Provide fundamental data on the drone’s own state (position, orientation, velocity), which is critical for understanding self-induced volatility and contextualizing external volatility.
- Environmental Sensors: Barometers, thermometers, and anemometers provide real-time weather data, directly feeding into predictions of atmospheric volatility.
The “formula” integrates these noisy, often conflicting inputs into a single, coherent, and probabilistically weighted understanding of the environment and the drone’s state.
Learning from Experience
Modern “implied volatility formulas” are not hard-coded; they evolve:
- Supervised Learning: Training data sets—comprising sensor inputs paired with optimal drone responses in various dynamic scenarios—allow algorithms to learn the correlations between environmental cues and effective actions.
- Reinforcement Learning (RL): Drones learn by interacting with their environment, both in simulation and real-world scenarios. Through a system of rewards and penalties, an RL agent can refine its “volatility formula,” discovering the most effective strategies to navigate or interact with unpredictable elements. This trial-and-error approach is particularly powerful for adapting to novel forms of volatility.
- Unsupervised Learning: Algorithms can identify hidden patterns and anomalies in large datasets of flight telemetry and environmental data, helping to discover previously unknown forms of volatility or refine existing models without explicit labels.
Real-time Adaptation
Crucially, the “implied volatility formula” is a living system. It continuously updates its assessment of volatility based on new sensor data streaming in milliseconds. This real-time adaptation ensures that the drone’s decision-making always reflects the most current and probable understanding of its environment, allowing for immediate adjustments to changing conditions.
Challenges and the Future of Predictive Autonomy
Despite significant advancements, perfecting the “implied volatility formula” for drones presents ongoing challenges and exciting avenues for future development.
Computational Demands and Real-time Processing
Complex probabilistic models and deep learning algorithms require substantial computational power. Executing these “formulas” in real-time on power-constrained drone hardware while maintaining low latency for critical decision-making remains a significant engineering hurdle. Future advancements in edge AI processors and optimized algorithms will be key.
Handling Edge Cases and Black Swans
While “implied volatility formulas” excel at recognizing known patterns of unpredictability, they can struggle with truly novel, never-before-seen events—so-called “black swans.” Predicting completely unprecedented scenarios, especially those with severe consequences, remains a frontier for AI research. Robustness in the face of such extreme volatility is paramount.
Explainable AI and Trust
As these “volatility formulas” become more complex, particularly with deep learning, their internal workings can become opaque. Understanding why a drone inferred a certain level of volatility or chose a particular action based on that inference is critical for debugging, regulatory compliance, and building public trust in autonomous systems. Research into Explainable AI (XAI) is vital here.

Towards Hyper-Contextual Awareness
The future of the “implied volatility formula” involves integrating even richer, more diverse contextual data. This includes:
- Predictive Weather Models: Integrating real-time and forecast weather data for more accurate environmental volatility predictions.
- Crowd Behavior Analytics: For urban operations, understanding and predicting human movement patterns.
- Multi-Drone Communication and Swarm Intelligence: Sharing “implied volatility” assessments among multiple drones to create a collective, more robust understanding of a large, dynamic environment.
- Quantum Computing: While futuristic, quantum computing could potentially process vastly more complex probabilistic models, allowing for near-perfect “implied volatility” calculations in highly intricate, multi-variable scenarios.
The “implied volatility formula” is at the heart of making drones truly autonomous, intelligent, and capable of operating safely and effectively in the unpredictable world. Its continuous evolution is driving the next generation of aerial robotics and innovation.