
The pursuit of innovation in technology, particularly in dynamic fields like drone development and operation, is often a winding path marked by both breakthroughs and unforeseen challenges. To navigate these complexities, engineers, developers, and operators require robust tools for problem-solving, quality control, and continuous improvement. Among these, the Fishbone Diagram, also known as an Ishikawa Diagram or Cause-and-Effect Diagram, stands out as a powerful visual aid for systematically identifying the potential root causes of a problem. It moves beyond superficial symptoms, encouraging a deeper, more structured investigation into why things go wrong, or why desired outcomes are not achieved within sophisticated tech ecosystems.
Understanding the Fishbone Diagram: A Foundation for Root Cause Analysis
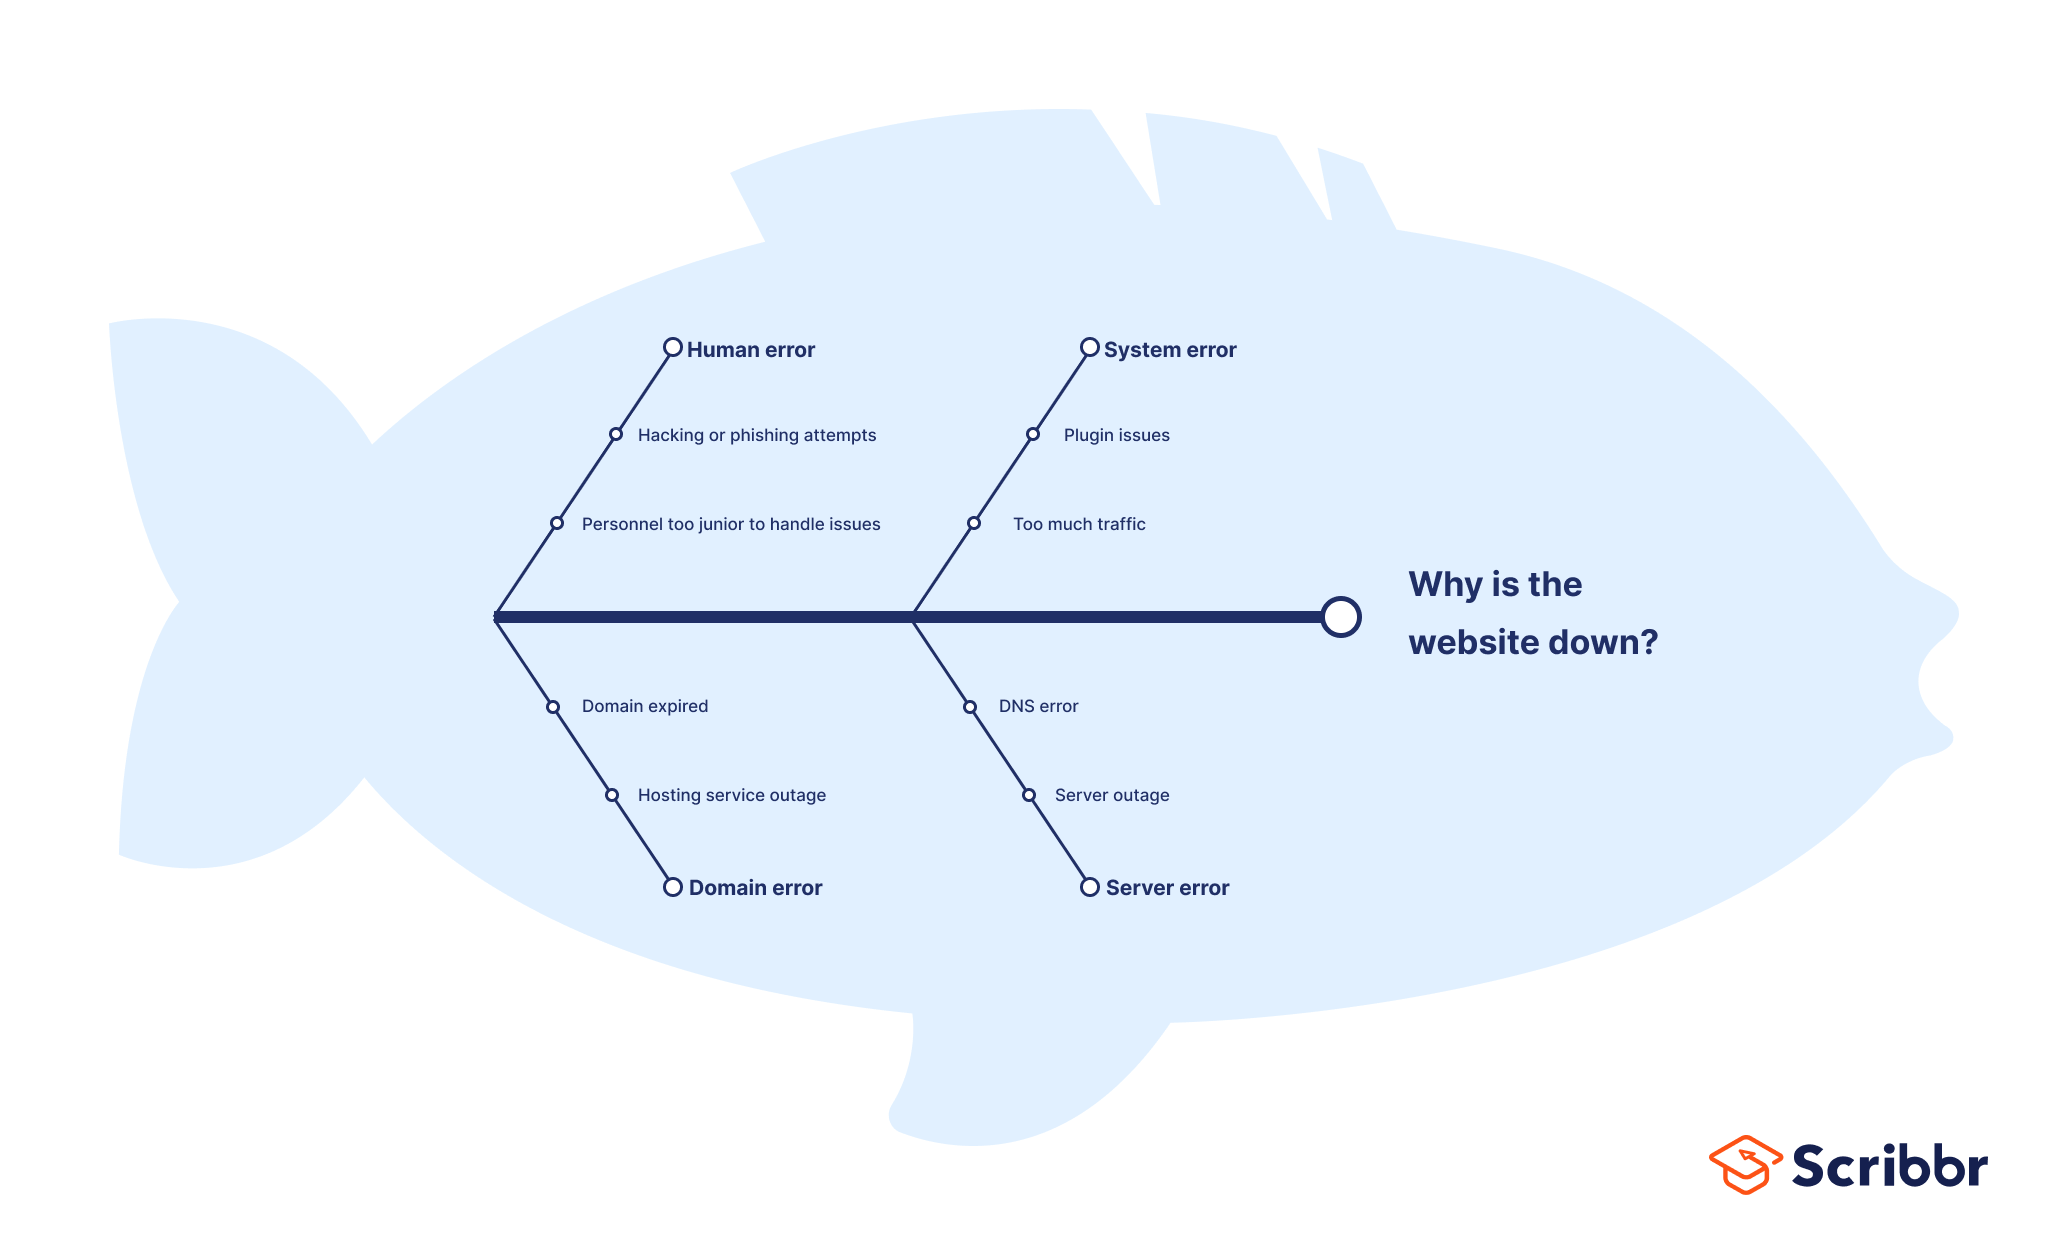
At its core, the Fishbone Diagram is a structured brainstorming tool that visually categorizes potential causes of a problem to identify its root causes. Invented by Kaoru Ishikawa, a Japanese quality control statistician, the diagram resembles the skeleton of a fish, hence its common name. The “head” of the fish points to the problem statement or effect, while the “bones” branch out to represent various categories of potential causes. This visual organization helps teams think comprehensively about all possible factors contributing to a specific issue, preventing tunnel vision and fostering a holistic approach to troubleshooting.
The Six Ms (or Four Ps/Es)
Traditionally, in manufacturing and quality control, the primary categories for causes often revolve around the “6 Ms”: Manpower (or People), Methods, Machines, Materials, Measurement, and Mother Nature (Environment). These categories provide a universal framework for initial brainstorming. However, depending on the specific context, especially in tech and innovation, these categories can be adapted. For instance, in software development or systems engineering relevant to drones, one might use “4 Ps” (People, Process, Policies, Plant/Technology) or “4 Es” (Environment, Equipment, Education, Procedures/Methods). The key is to select categories that are most relevant to the problem at hand and encourage a thorough examination of all contributing elements. Each major bone in the fishbone represents one of these categories, and smaller bones branching off represent specific causes within that category. This hierarchical structure allows for progressively more detailed analysis, drilling down from broad causal areas to specific actionable items.
Constructing a Fishbone Diagram
The process of constructing a fishbone diagram typically begins with a clear, concise problem statement placed at the “head” of the fish. This statement should define the undesirable effect or challenge being investigated. Next, the major categories of causes are drawn as diagonal lines leading to the central horizontal “spine.” These categories serve as starting points for brainstorming. Within each category, team members then identify specific potential causes, drawing them as smaller horizontal lines branching off the main category lines. As more detailed causes are identified, they can be added as sub-branches. The process encourages iterative exploration: for each potential cause, the question “Why does this happen?” is asked repeatedly until the root cause, which is often an actionable item, is identified. This systematic breakdown ensures that no stone is left unturned, leading to a comprehensive understanding of the problem’s origins.
Applying Fishbone Diagrams in Drone Technology & Innovation
The intricate nature of drone systems, encompassing hardware, software, connectivity, and environmental interactions, makes them fertile ground for the application of fishbone diagrams. From addressing flight instability to optimizing data processing, this tool provides a structured approach to problem identification and resolution, driving innovation and reliability.
Diagnosing Flight Performance Issues
Consider a scenario where a newly developed drone consistently exhibits unexpected drift during autonomous flight missions, failing to maintain its prescribed trajectory. This “unexpected drift” becomes the head of the fishbone diagram. The major categories could include:
- Hardware: Are there issues with the propellers (unbalanced, damaged)? Motors (underpowered, inconsistent RPM)? GPS module (faulty antenna, poor signal reception)? IMU (gyroscope drift, accelerometer calibration errors)? Flight controller (firmware bugs, hardware defects)?
- Software/Firmware: Is the PID controller gain incorrectly tuned? Are there bugs in the navigation algorithms? Is the sensor fusion algorithm introducing errors? Are there latency issues in control loops?
- Environment: Is the drone operating in strong winds or electromagnetic interference? Are there GPS signal blockages (urban canyons, dense foliage)? Is there temperature fluctuation affecting sensor performance?
- Calibration/Setup: Was the compass properly calibrated before flight? Were IMU offsets correctly applied? Is the weight distribution of the payload balanced?
- Power System: Is there insufficient power delivery to motors under load? Are battery cells degrading unevenly? Voltage drops affecting sensitive electronics?
By systematically exploring each of these branches, the team can pinpoint whether the drift is due to, for example, an outdated GPS module driver, a specific batch of imbalanced propellers, or environmental magnetic interference in a particular test area. This precise identification allows for targeted solutions, saving significant time and resources compared to trial-and-error troubleshooting.
Enhancing Autonomous Systems Reliability

Autonomous flight, AI follow modes, and object avoidance are pillars of advanced drone technology. Failures or inconsistencies in these systems can have significant implications. A fishbone diagram can be instrumental in identifying the root causes of, say, an autonomous drone failing to follow a designated flight path or exhibiting erratic object avoidance behavior. The problem could be traced back to:
- Sensor Input: Faulty lidar/radar data, poor camera resolution, incorrect sensor fusion, or inadequate environmental perception algorithms.
- Algorithms/Logic: Bugs in path planning algorithms, flaws in decision-making logic, insufficient machine learning model training data, or incorrect parameter tuning for AI follow mode.
- Processing Power: Insufficient onboard computing resources leading to latency or dropped frames, causing delayed reactions in obstacle avoidance.
- Communication: Intermittent loss of telemetry, slow data links between drone and ground control, or interference affecting control signals crucial for maintaining autonomous operations.
By methodically breaking down potential causes, development teams can isolate whether the issue lies with a specific sensor’s calibration, a bug in the AI model’s inference logic, or a fundamental architectural limitation, thereby guiding iterative improvements and enhancing the overall reliability of complex autonomous features.
Optimizing Data Capture and Remote Sensing
Drones are invaluable tools for remote sensing, mapping, and data capture across various industries. When data quality is suboptimal (e.g., blurry images, inaccurate mapping overlays, inconsistent multispectral readings), a fishbone diagram can help diagnose the underlying issues. Categories for investigation might include:
- Camera/Sensor Hardware: Lens focus issues, sensor noise, gimbal instability, incorrect filter usage, or malfunctioning thermal/multispectral units.
- Flight Parameters: Incorrect altitude for desired resolution, too fast flight speed causing motion blur, improper overlap settings for mapping, or insufficient light conditions.
- Software/Processing: Bugs in image stitching software, incorrect georeferencing algorithms, issues with post-processing workflows, or erroneous sensor calibration profiles applied during data acquisition.
- Environmental Factors: Atmospheric haze, strong vibrations affecting image sharpness, glare from sun, or variations in surface reflectivity impacting sensor readings.
- Operator Error/Methodology: Incorrect camera settings, improper flight planning for specific data requirements, or inconsistent data capture procedures.
Pinpointing whether poor image quality stems from an oscillating gimbal (hardware), an incorrectly configured flight path (methodology), or a post-processing software bug allows for precise adjustments, leading to higher quality data and more effective remote sensing applications.
Proactive Problem-Solving and Continuous Improvement
While fishbone diagrams are excellent for reactive problem-solving, their true power extends to fostering a culture of continuous improvement and proactive risk mitigation within tech and innovation cycles. By systematically analyzing past failures, teams can derive lessons that inform future designs and operational protocols.
From Reactive Fixes to Preventative Measures
Once a root cause is identified using a fishbone diagram, the goal shifts from merely fixing the current problem to implementing preventative measures that preclude its recurrence. For instance, if a common cause for drone crashes is identified as battery degradation due to improper charging protocols (Manpower/Methods), the solution isn’t just to replace the battery, but to revise charging guidelines, train operators, and potentially integrate smart charging systems. In the context of drone innovation, this translates to feeding insights from problem analyses back into the design and development phases. A recurring software bug linked to a specific sensor integration might lead to redesigning the sensor interface or developing more robust error-handling routines in future firmware updates. This proactive approach elevates the quality and reliability of drone systems over time, fostering innovation through learning.
Facilitating Cross-Disciplinary Collaboration
Modern drone systems are a nexus of mechanical engineering, electrical engineering, software development, aerodynamics, and data science. Problems often cross these disciplinary boundaries. The visual and structured nature of a fishbone diagram makes it an ideal tool for facilitating cross-disciplinary discussions. Engineers from different specialties can simultaneously contribute their perspectives to the same diagram, ensuring that all relevant angles are considered. For example, a flight anomaly might involve input from a propulsion engineer (motors, propellers), a software engineer (flight control algorithms), and a systems integration specialist (sensor calibration). The diagram provides a common language and framework for these diverse teams to collaborate effectively, understand interconnected causes, and collectively arrive at comprehensive solutions that might not be apparent from a single disciplinary viewpoint. This collaborative problem-solving is crucial for the rapid and complex development cycles characteristic of tech innovation.

Best Practices for Effective Implementation
To maximize the utility of fishbone diagrams in the drone tech and innovation landscape, several best practices should be observed. Firstly, defining the problem statement clearly and concisely is paramount; a vague problem leads to a convoluted diagram. Secondly, engaging a diverse team with varied expertise is critical for comprehensive brainstorming, ensuring all angles are covered. Thirdly, resisting the urge to jump to solutions prematurely is vital; the focus must remain on identifying causes. Asking “Why?” multiple times for each potential cause helps peel back layers to reveal the true root. Finally, once root causes are identified, the diagram should lead to actionable steps and responsible parties, transforming insights into tangible improvements. Regular reviews of completed diagrams and their associated solutions contribute to a knowledge base, fostering organizational learning and accelerating future innovation cycles in drone technology.