
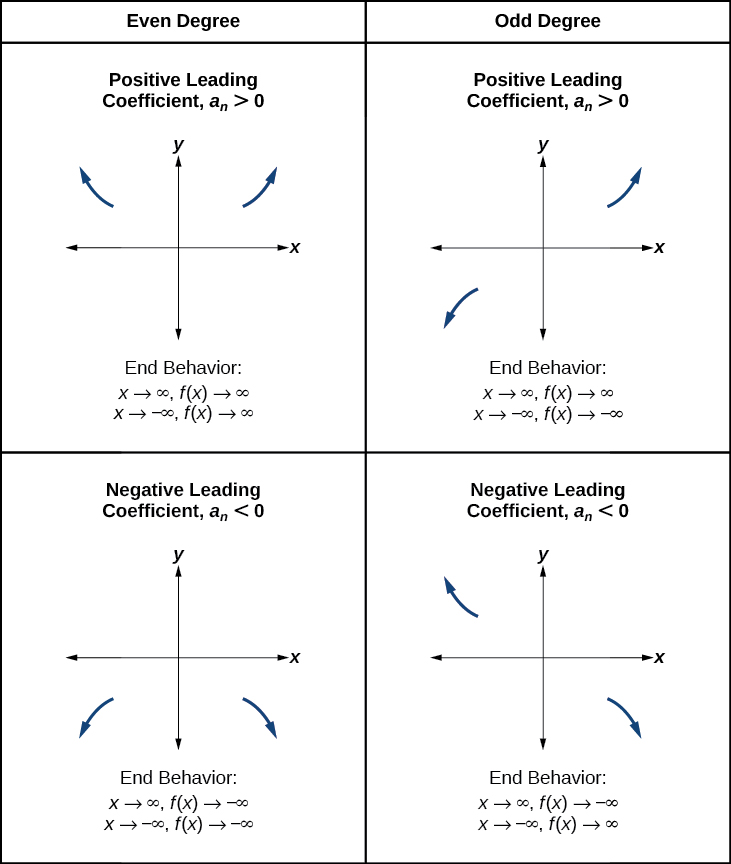
In the realm of advanced drone technology and innovation, the concept of “end behavior of a function” extends far beyond its pure mathematical definition. Here, it refers to the critical analysis of how complex autonomous systems, intelligent algorithms, and data models perform, trend, or stabilize when pushed to their operational limits, subjected to extreme conditions, or observed over extended periods. Understanding this end behavior is paramount for developing robust, reliable, and truly autonomous drones capable of sophisticated tasks like AI follow mode, remote sensing, comprehensive mapping, and proactive obstacle avoidance. It’s about predicting performance at the asymptotic edge, ensuring safety, and maximizing efficiency when systems operate at the boundaries of their design parameters or over the long haul.

Defining System Limits in Autonomous Platforms
The efficacy of AI-driven drone capabilities is often determined by how well their underlying “functions”—the algorithms and control laws—behave under stress or over vast operational envelopes. This is where analyzing end behavior becomes crucial, revealing the ultimate boundaries and stability characteristics of these intelligent systems.
Autonomous Flight Path Planning and Edge Cases
For autonomous flight, a function might represent the algorithm dictating flight path planning. Its end behavior would describe how the drone’s navigation system performs when faced with increasingly complex environments, extreme distances, or prolonged missions that test its computational resources and sensor integrity. As a drone attempts to map an enormous land area or navigate through an intricate urban canyon for hours, its path planning algorithm’s end behavior reveals its capacity for long-term optimization, error accumulation, and resilience to unforeseen variables. Does its trajectory planning remain efficient and collision-free as the data set of obstacles grows exponentially? Does it maintain a stable and optimal flight path even as battery life dwindles, affecting thrust output and control responsiveness? Understanding these asymptotic performance characteristics helps developers design systems that don’t just work, but work reliably under the most demanding circumstances.
AI-Driven Object Recognition at Scale
Consider the function of an AI-driven object recognition system, vital for tasks like security monitoring, wildlife tracking, or infrastructure inspection. Its end behavior relates to its accuracy, latency, and resource consumption when processing an overwhelming volume of visual data over extended durations or across vast, diverse landscapes. As a drone autonomously patrols a massive industrial site, continuously identifying anomalies or intruders, how does the recognition algorithm’s accuracy hold up after hours of operation, through varying light conditions, and across thousands of unique observations? Does its computational load become prohibitive, leading to reduced frame rates or delayed reactions? The end behavior here isn’t just about a single prediction but the sustained, reliable performance of a complex neural network under continuous, high-throughput demands. This analysis guides the optimization of hardware-software co-design, ensuring that real-time processing remains feasible and effective without significant degradation over time or scale.
Predictive Analytics and Long-Term Trends in Mapping and Remote Sensing
Mapping and remote sensing operations inherently involve collecting vast amounts of data, often over large geographical areas or extended timeframes. The “end behavior” of the functions governing these processes dictates the long-term integrity, utility, and consistency of the data products.
Data Integrity and Asymptotic Accuracy
In drone-based mapping, a key function is the photogrammetry or LiDAR processing pipeline that transforms raw sensor data into actionable 3D models or precise topographical maps. Its end behavior pertains to how the accuracy and integrity of these maps hold up as the surveyed area expands significantly or as the data collection period lengthens. Does the geometric accuracy degrade proportionally with the scale of the project, or does it reach a stable, albeit imperfect, asymptote? Are there subtle cumulative errors that only become apparent when mapping thousands of square kilometers? Remote sensing for agricultural health, for instance, might involve collecting multispectral data weekly for an entire growing season. The end behavior of the data processing function would describe how consistent and reliable the derived health metrics are across hundreds of datasets, accounting for sensor drift, atmospheric variations, and algorithmic biases that might manifest over many months. Ensuring data consistency at scale and over time is critical for drawing meaningful conclusions and making informed decisions.
Environmental Monitoring Over Extended Periods
For environmental monitoring, drones deploy sensors to track phenomena like pollution dispersion, forest health, or ice melt. The “function” in this context could be the algorithm that interprets sensor readings to provide actionable insights. The end behavior would describe how the long-term trends identified by these algorithms remain stable, reliable, and free from accumulating errors as data is collected over years. For instance, monitoring changes in glacier volume requires precise measurements over decades. The end behavior analysis helps understand if the chosen sensing and processing methodologies maintain their fidelity across different seasons, hardware upgrades, and evolving environmental conditions, preventing the misinterpretation of crucial ecological shifts due to systematic drift or algorithmic fatigue. This foresight allows scientists and policymakers to trust the long-term data for critical environmental policy and research.
Adaptive Algorithms and Robustness in Dynamic Environments
Modern drone systems rely heavily on adaptive algorithms that can adjust to changing conditions. The “end behavior” of these adaptive functions reveals their ultimate resilience and capacity for sustained, intelligent operation in unpredictable, dynamic environments.
The Stability of AI Follow Mode
AI follow mode, a popular feature in many consumer and professional drones, relies on complex computer vision and control algorithms. The “function” here dictates how the drone maintains a lock on a moving subject while simultaneously avoiding obstacles. Its end behavior describes the system’s stability and reliability when the subject moves erratically, changes speed drastically, or moves through increasingly dense or visually ambiguous environments. Does the system maintain its lock without erratic movements? Does it handle sudden obstructions by gracefully re-routing and re-acquiring the target, or does it become confused and abandon the track? The end behavior analysis helps determine the maximum sustained performance of the follow mode—its “infinity”—before performance inevitably degrades or fails, which is crucial for applications ranging from extreme sports videography to covert surveillance.
Resilience of Obstacle Avoidance Systems
Obstacle avoidance functions are paramount for safe autonomous flight. Their end behavior involves assessing how the system performs as environmental complexity increases to its theoretical maximum. What happens when the drone encounters a highly cluttered environment with hundreds of small, fast-moving objects, or when sensor visibility is compromised by fog or dust? Does the system maintain its ability to detect, classify, and react to threats, or does its processing latency or false positive/negative rate spike? Analyzing the end behavior provides insights into the true limits of current sensor fusion techniques and real-time path replanning algorithms, guiding the development of more robust systems capable of navigating even the most challenging three-dimensional spaces without human intervention. This also includes understanding how the system performs under conditions where processing power might be throttled or communication bandwidth limited.
The Evolving Landscape of Drone Intelligence
As drone technology progresses towards higher levels of autonomy, understanding the end behavior of self-learning and self-correcting functions becomes pivotal. This guides the development of true machine intelligence in aerial platforms.
Self-Correction and Learning Algorithms
The most advanced drones are now incorporating machine learning algorithms that allow them to learn from experience and self-correct. The “function” here is the learning algorithm itself, and its end behavior describes its capacity for continuous improvement and adaptation over an infinite number of operational cycles. Does the drone continue to refine its flight parameters and decision-making processes indefinitely, reaching an asymptotic level of mastery, or does it plateau after a certain amount of training data or experience? What are the limits of its ability to generalize learned behaviors to entirely new, unforeseen scenarios? Understanding this “learning curve’s” end behavior helps assess the potential for truly sentient and adaptable drone systems that can operate with minimal human oversight for prolonged periods, learning and evolving in the field.
Future Implications for Fully Autonomous Operations
Ultimately, the goal for many in drone tech and innovation is fully autonomous operations, where drones can execute complex missions without any direct human input. The “end behavior of a function” in this ultimate context refers to the collective, long-term stability, reliability, and decision-making capability of an entire integrated system operating at the absolute limits of its designed parameters and beyond. Can a swarm of drones, each executing its own function, maintain coherent, collaborative behavior indefinitely in an unpredictable, contested airspace? Can a single drone perform complex inspection tasks for months on end, adapting to equipment wear, environmental changes, and unforeseen anomalies while maintaining optimal performance and safety? Analyzing the end behavior of these complex, interconnected “functions” is not merely an academic exercise; it is fundamental to unlocking the next generation of truly intelligent, resilient, and indispensable aerial robotics. It is about foreseeing the ultimate capabilities and limitations of tomorrow’s autonomous ecosystems.