
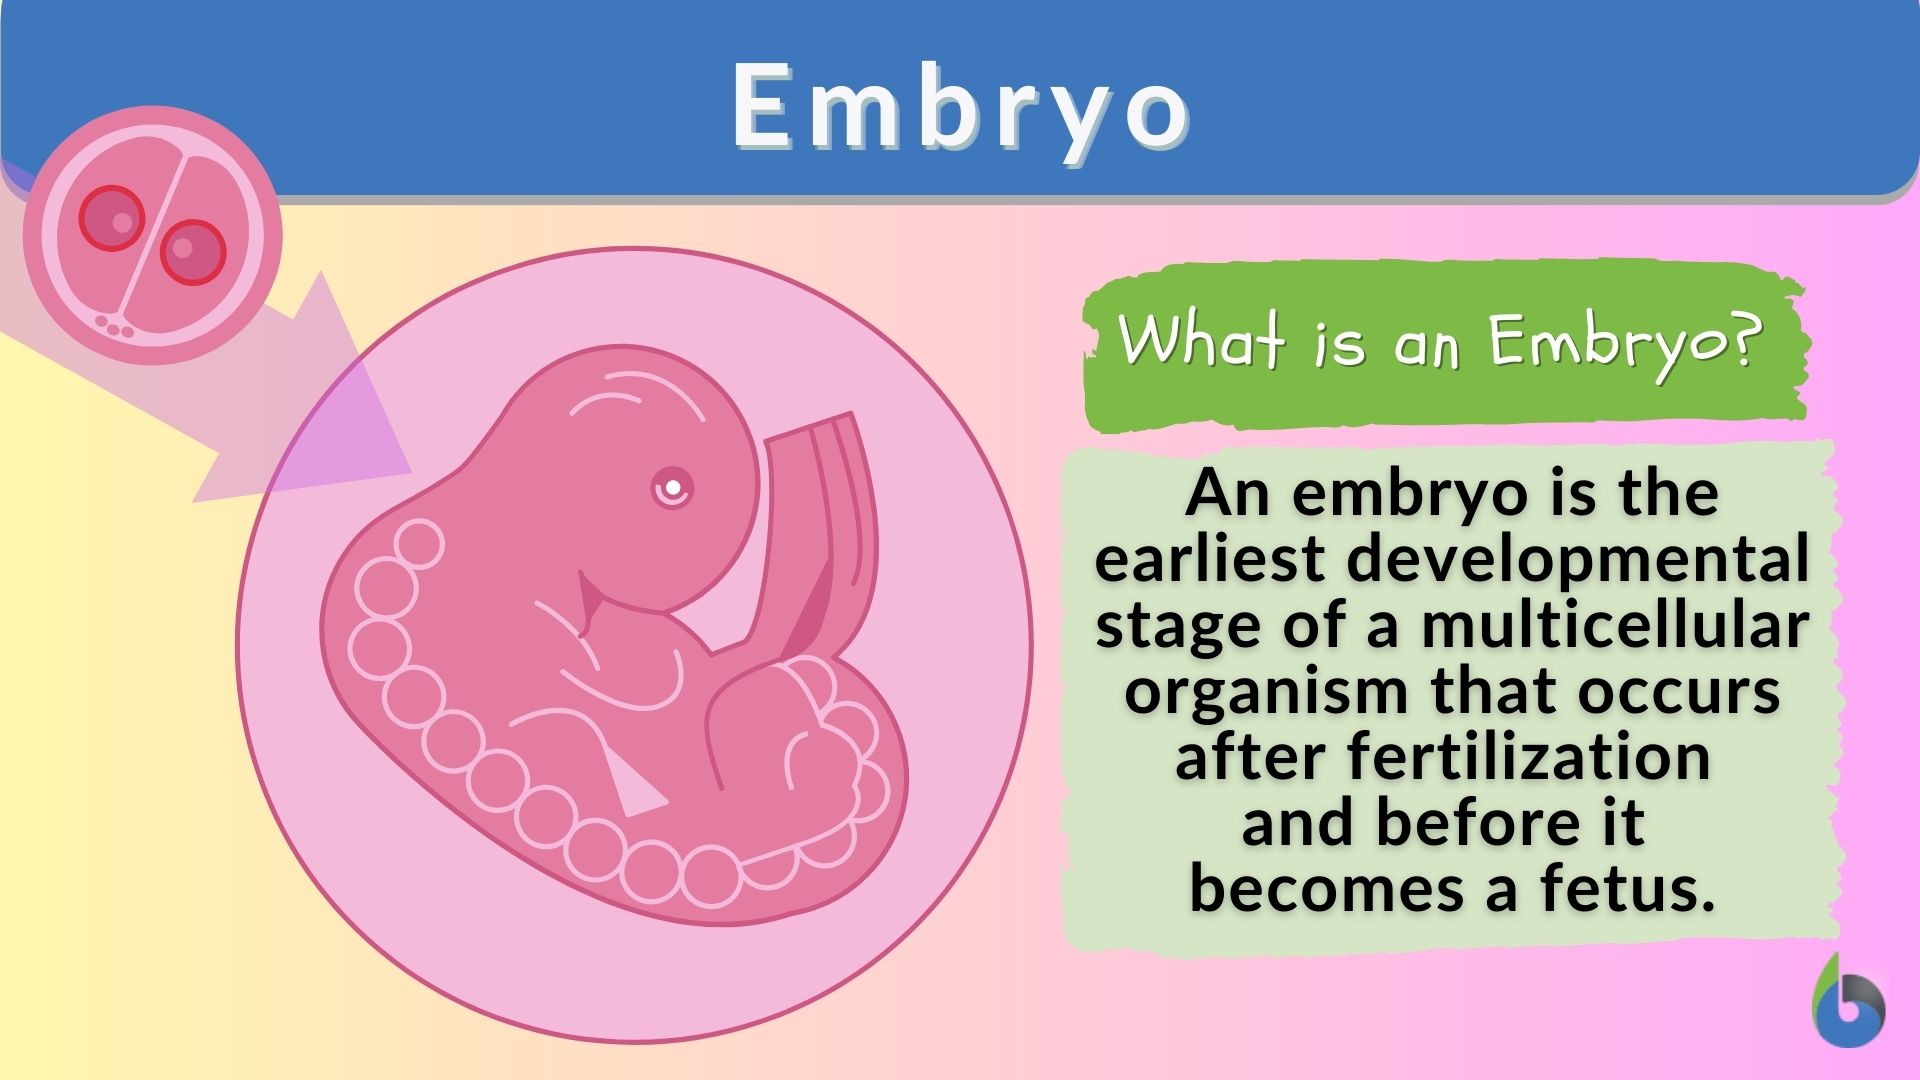
In the rapidly evolving landscape of technology and innovation, the concept of an “embryo” transcends its biological origins to represent the nascent, foundational, and often fragile stages of groundbreaking ideas, systems, and solutions. Within the domains of drones, AI, autonomous flight, mapping, and remote sensing, understanding what constitutes the “embryonic” phase is crucial for identifying potential breakthroughs, nurturing their growth, and ultimately shaping the future. It refers to the initial spark, the core algorithm, the rudimentary prototype, or the fundamental principle from which complex technologies emerge and mature. This formative period is characterized by intense research, iterative development, and the establishment of the core viability that will define the technology’s eventual impact.
The Nascent Spark of Innovation in Tech
Every revolutionary technology begins as an embryo—a preliminary concept, a proof-of-principle experiment, or a theoretical framework that holds the promise of significant disruption. In the realm of tech, this embryonic stage is where creativity meets engineering, where abstract ideas are first translated into tangible, albeit primitive, forms. It’s a period marked by high uncertainty but also immense potential, laying the groundwork for what will eventually become a robust and integrated system.
From Concept to Core Algorithm
The journey often starts with a fundamental problem that demands an innovative solution. For instance, the embryo of autonomous flight wasn’t a fully functional drone but perhaps a novel algorithm designed for basic position holding or obstacle detection. Researchers might spend years developing mathematical models and simulated environments to prove a concept’s viability before any physical hardware is involved. This core algorithm or theoretical model acts as the genetic code of the future technology, dictating its fundamental capabilities and limitations. It’s a delicate phase where the precision of logic and the elegance of design determine the potential for future scalability and performance. Identifying these core algorithms early allows for focused development and resource allocation, preventing wasted effort on dead-end paths.
Prototyping and First Principles
Once a core concept or algorithm shows promise, the next step in its embryonic development is often the creation of a rudimentary prototype. This isn’t a polished product but a barebones manifestation designed solely to validate the foundational principles. For a drone’s AI follow mode, the embryo might be a simple camera tracking a colored ball on a fixed platform, demonstrating the basic visual recognition and positional adjustment loop. These prototypes are critical for moving beyond theoretical models, exposing unforeseen challenges, and providing concrete data for refinement. They are often clumsy, inefficient, and far from market-ready, but they represent the first physical embodiment of the innovation, proving that the theoretical “DNA” can indeed manifest in the physical world. This iterative process of building, testing, learning, and refining is central to nurturing the technological embryo.
Embryonic AI: Shaping Autonomous Flight
Artificial Intelligence (AI) is perhaps one of the most fertile grounds for embryonic technologies, particularly in how it underpins autonomous flight and advanced drone operations. The “embryo” of AI in this context refers to the initial learning models, decision-making frameworks, and perception systems that allow drones to interpret their environment and act without direct human intervention.
Learning Algorithms and Predictive Models
The earliest forms of AI in flight involved simple rule-based systems or basic PID controllers for stabilization. However, the true embryo of modern autonomous flight AI lies in the development of machine learning algorithms capable of processing sensor data (from GPS, IMUs, cameras, lidar) and making predictive judgments. For instance, the embryo of an AI follow mode wasn’t about complex object recognition across varied environments, but rather basic visual tracking algorithms that could identify and maintain a relative position to a designated target. These initial learning models, often trained on limited datasets, established the blueprint for how drones could learn from experience and adapt to dynamic situations, moving beyond pre-programmed commands. The accuracy and robustness of these foundational learning architectures are paramount, as errors at this stage can propagate into complex failures in more advanced systems.
Edge Computing and Onboard Intelligence
Another crucial embryonic development for AI in drones is the advent of edge computing. The capability for drones to process data onboard, rather than relying solely on ground stations or cloud computing, marked a significant leap towards true autonomy. The embryo here was the initial concept of embedding microprocessors and specialized AI chips directly onto the drone, allowing for real-time decision-making, such as immediate obstacle avoidance or dynamic path planning, without latency. This shift from centralized processing to distributed, onboard intelligence transformed drones from mere remote-controlled platforms into intelligent, self-aware entities. The development of efficient algorithms tailored for limited computational resources at the edge was a critical embryonic step, enabling the miniaturization and power efficiency necessary for practical drone applications.
The Germination of Remote Sensing and Mapping Capabilities
The ability of drones to gather vast amounts of geospatial data and create detailed maps is another area where “embryonic” developments have paved the way for profound innovation. The early stages involved overcoming fundamental challenges in sensor integration, data acquisition, and processing, which have now matured into sophisticated applications.
Sensor Fusion and Data Interpretation
The embryo of advanced remote sensing lay in the basic ability to integrate multiple sensor types onto a single drone platform. Initially, this might have involved simply mounting a standard camera and a GPS module. However, the true innovation began with the development of algorithms for sensor fusion, where data from disparate sources (e.g., optical cameras, thermal cameras, lidar, multispectral sensors, IMUs, GPS) could be combined and correlated to create a more comprehensive understanding of the environment. The embryonic algorithms for photogrammetry, which stitch together overlapping images to create 3D models and orthomosaics, were revolutionary. These initial methods, though computationally intensive and less precise than today’s solutions, provided the core methodology for transforming raw sensor data into actionable geographic information. The interpretation of this fused data, leading to insights about crop health, structural integrity, or environmental changes, also began with rudimentary analytical tools that formed the embryo of today’s advanced geospatial analytics platforms.
Evolving Precision Agriculture and Environmental Monitoring
In areas like precision agriculture, the embryonic stage involved demonstrating that drones equipped with basic multispectral cameras could differentiate between healthy and stressed crops. This initial capability, though coarse, sparked the realization of drones’ potential to provide granular, field-level data that traditional satellite imagery could not. Similarly, in environmental monitoring, the embryo was the proof-of-concept for using drones to detect hot spots in wildfires or monitor wildlife populations over limited areas. These early demonstrations, often using modified consumer drones and off-the-shelf sensors, provided the compelling evidence needed to invest in more specialized drone platforms and sophisticated sensor payloads. The development of initial data pipelines for processing and visualizing this information formed the backbone of current advanced agricultural and ecological remote sensing solutions.
Autonomous Systems: The Fledgling Stages of Self-Reliance
The ultimate goal for many drone technologies is full autonomy. The “embryo” of autonomous systems encompasses the foundational principles and initial successes that allow drones to operate independently, making complex decisions and navigating intricate environments without constant human input.
Overcoming Obstacle Avoidance Challenges
One of the most critical embryonic challenges for autonomous flight was obstacle avoidance. Early attempts often relied on simple ultrasonic sensors, providing very limited range and resolution. The true embryo of robust obstacle avoidance emerged with the development of more sophisticated perception systems, combining stereo vision, lidar, and eventually radar. The initial algorithms for processing this sensor data to create a real-time 3D map of the environment and identify collision threats were foundational. These early systems, capable of detecting and circumnavigating simple, static obstacles, formed the blueprint for today’s advanced collision avoidance technologies, which can handle dynamic environments and predict trajectories. The development of reactive and proactive avoidance strategies, even in their rudimentary forms, was a significant embryonic breakthrough.
Regulatory Frameworks and Ethical Considerations
Beyond the technical, the “embryo” of autonomous systems also includes the very first discussions and attempts at establishing regulatory frameworks. As drones moved from experimental prototypes to commercial possibilities, the need for rules governing their autonomous operation became apparent. The initial policy papers, safety guidelines, and ethical debates surrounding AI decision-making in autonomous flight represented an essential, non-technical embryo. These early discussions, though often speculative and unrefined, began to outline the societal and legal parameters within which future autonomous systems would have to operate. Establishing trust and addressing concerns about privacy, safety, and accountability in the earliest stages of autonomous development is crucial for widespread adoption.
Nurturing the Future: Scaling from Embryo to Ecosystem
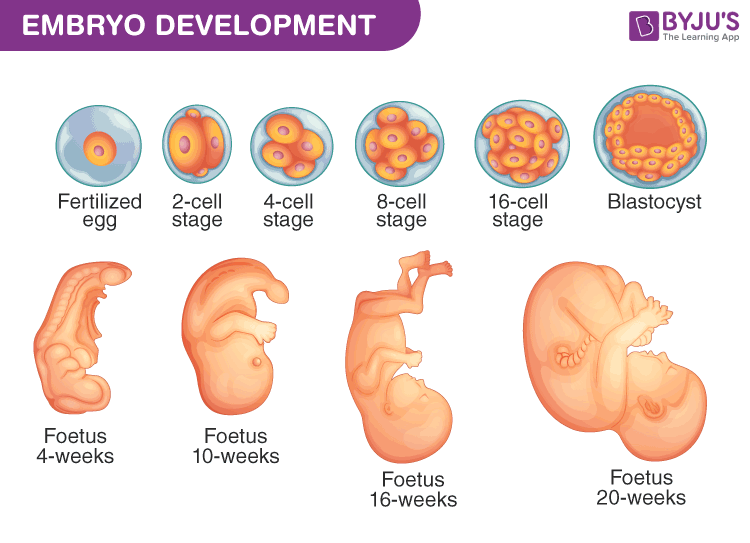
Identifying and nurturing these technological embryos is paramount. Just as a biological embryo requires a specific environment to develop, technological embryos demand sustained investment, collaborative research, and an ecosystem that encourages innovation. From the initial lines of code for an AI algorithm to the first crude prototype demonstrating autonomous navigation, each embryonic stage builds upon the last, progressively adding complexity and capability. The transition from an isolated concept to a fully integrated solution involves countless iterations, overcoming unforeseen technical hurdles, and adapting to user feedback and market demands. Recognizing the potential in these early, often imperfect, stages is the hallmark of forward-thinking innovation, ultimately scaling these foundational concepts into the sophisticated, interconnected technologies that define our modern world.