
In the rapidly evolving landscape of unmanned aerial vehicles (UAVs), colloquially known as drones, the concept of an operating system (OS) transcends the traditional desktop computer paradigm. For a drone, the “OS on computer” refers to the sophisticated software architecture that orchestrates its myriad components, transforming a collection of hardware into an intelligent, autonomous flying machine. This embedded operating system, often a specialized firmware or a real-time operating system (RTOS), is the invisible conductor behind every controlled flight, every intelligent maneuver, and every piece of data collected. It is the core technological innovation that enables the advanced features pushing the boundaries of aerial robotics, from AI-powered follow modes to intricate mapping and remote sensing missions.
The Brain of the Machine: Demystifying the Drone’s Operating System
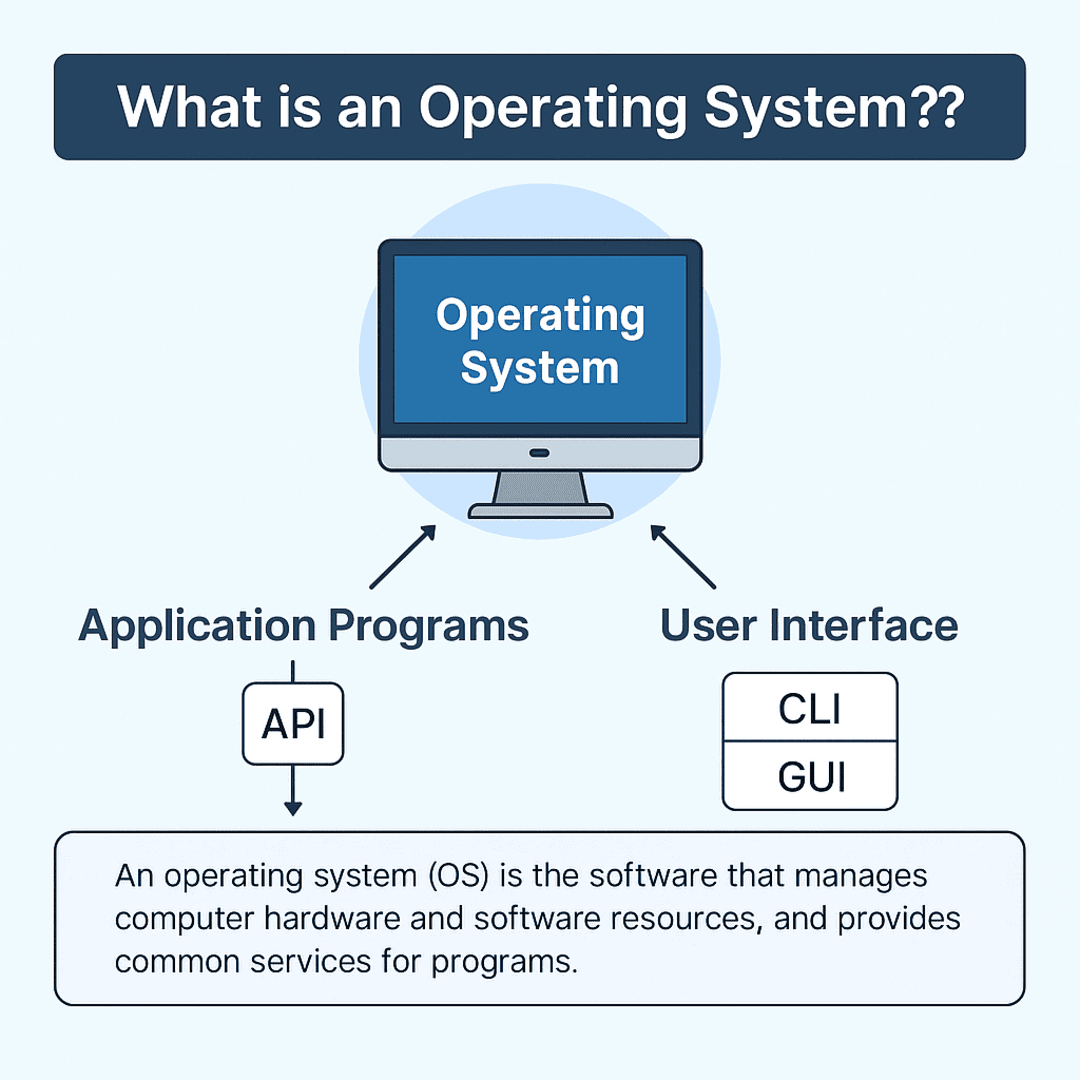
At its heart, a drone is a complex computer system. Unlike a personal computer with a general-purpose OS like Windows or macOS, a drone’s “computer” is typically an embedded system, highly optimized for specific tasks: flight control, sensor management, and communication. The operating system here isn’t a user-friendly interface but a low-level, high-performance software layer. It manages the fundamental processes that allow the drone to operate, making real-time decisions essential for stable and safe flight.
Firmware as a Specialized OS
For many drones, particularly consumer and prosumer models, the core software is often referred to as firmware. This firmware is, in essence, a specialized operating system. It’s a permanent software program etched into a hardware device’s non-volatile memory, providing the necessary instructions for the hardware to function. In a drone, the flight controller board houses this crucial firmware. It handles critical real-time operations, processing data from gyroscopes, accelerometers, magnetometers, and GPS modules. This continuous data stream allows the firmware to calculate the drone’s attitude, position, and velocity, then issue precise commands to the electronic speed controllers (ESCs) that govern motor speeds, ensuring stability and responsiveness.
The firmware also manages communication protocols, allowing the drone to interface with remote controllers, ground control stations, and other onboard modules like camera gimbals or payload systems. Without this foundational layer, the drone would be nothing more than inert components. The efficiency and reliability of this specialized OS are paramount, as even minor delays or errors can have catastrophic consequences in an aerial environment.
From Bare Metal to Advanced Control
Early drones operated with relatively simple control loops, where the firmware directly interacted with hardware (“bare metal”). As drone technology advanced, the complexity of tasks increased, necessitating more robust software architectures. Modern drone operating systems often employ real-time operating systems (RTOS), which guarantee that critical operations are performed within specific time constraints. This determinism is vital for flight control, where milliseconds can mean the difference between a smooth maneuver and a crash.
The RTOS provides a framework for multiple tasks (e.g., sensor reading, motor control, navigation, communication) to run concurrently and prioritize them based on their importance. This multi-tasking capability is what allows drones to perform sophisticated functions simultaneously—maintaining stable flight while executing a complex waypoint mission, avoiding obstacles, and streaming live video. The transition from simple firmware to more sophisticated RTOS-based systems has been a key innovation enabling the advanced capabilities we see in today’s drones, paving the way for true autonomy and intelligent behavior.
Powering Autonomy: OS and AI Follow Mode
One of the most compelling innovations in drone technology is the implementation of artificial intelligence (AI) for autonomous features like “follow mode.” This seemingly simple function is, in fact, a testament to the sophisticated interplay between the drone’s operating system, its sensor suite, and advanced AI algorithms. The OS acts as the central hub, managing the resources and data flow necessary for these intelligent operations.
Real-time Data Processing and Decision Making
For AI follow mode to work, the drone’s OS must orchestrate the real-time acquisition and processing of vast amounts of data. This includes visual information from onboard cameras, distance data from ultrasonic or LiDAR sensors, and positional data from GPS and IMUs (Inertial Measurement Units). The OS allocates computational resources to run complex computer vision algorithms that identify and track a designated subject. It processes video frames, detects objects, estimates their movement vectors, and then feeds this information to the navigation module.
Crucially, the OS doesn’t just pass data; it facilitates immediate decision-making. Based on the subject’s movement and pre-programmed parameters (e.g., maintaining a certain distance or angle), the OS calculates the necessary adjustments to the drone’s flight path, speed, and altitude. This feedback loop operates continuously, making adjustments many times per second to ensure the drone smoothly follows its target. The responsiveness and low latency inherent in the drone’s OS are what make such dynamic autonomous functions possible and reliable.
Integrating Vision Systems for Intelligent Navigation
Intelligent navigation, a core component of AI follow mode and other autonomous functions like obstacle avoidance, relies heavily on the seamless integration of vision systems with the drone’s core OS. The OS is responsible for managing the camera hardware, acquiring raw image data, and then passing it to dedicated image processing units (GPUs or specialized AI chips if present) or the main flight controller for analysis.

It also handles the integration of advanced algorithms such as Simultaneous Localization and Mapping (SLAM) or Visual Odometry. These algorithms, facilitated by the OS, allow the drone to understand its environment, build a map of its surroundings, and localize itself within that map, even in GPS-denied environments. In follow mode, this means the drone can not only track a subject but also intelligently navigate around trees, buildings, or other obstacles that might impede its path, ensuring safe and uninterrupted following. The OS acts as the bridge between the high-level AI directives and the low-level flight control mechanisms, translating abstract goals into precise motor commands.
Enabling Advanced Missions: Mapping, Sensing, and the OS Interface
Beyond autonomous flight, the drone’s operating system is fundamental to its utility in advanced applications like precision mapping and remote sensing. These missions demand not only stable flight but also meticulous data acquisition, precise geo-referencing, and robust data management – all orchestrated by the underlying software infrastructure.
Orchestrating Sensor Data for Precision Mapping
Precision mapping with drones requires the capture of high-resolution imagery or LiDAR data, meticulously tagged with accurate geospatial information. The drone’s OS plays a critical role in synchronizing the operation of various sensors. It ensures that images are captured at precise intervals or locations, triggering the camera at the exact moment the drone reaches a specific waypoint or attitude. Simultaneously, it logs data from the GPS module, IMU, and potentially other sensors like barometers or magnetometers, attaching this metadata to each image or data point.
This synchronization is crucial for generating accurate orthomosaic maps, 3D models, or point clouds. The OS manages the data storage onboard, ensuring efficient writing to memory cards and preparing the data for subsequent post-processing. Without a well-designed OS that can handle these complex timing and data management tasks, the quality and accuracy of the mapping output would be severely compromised, hindering applications in agriculture, construction, surveying, and environmental monitoring.
Remote Sensing Applications and OS Management
Remote sensing, which involves collecting information about an object or area without coming into physical contact with it, leverages drones equipped with specialized sensors like multispectral, hyperspectral, or thermal cameras. The drone’s operating system is the backbone for integrating and managing these diverse payloads. It provides the interface for controlling the specific parameters of each sensor, such as exposure settings for multispectral cameras or temperature ranges for thermal imagers.
Furthermore, the OS often facilitates the real-time processing or transmission of this specialized sensor data. For instance, in agricultural remote sensing, the OS might process multispectral data to calculate vegetation indices (like NDVI) onboard, providing immediate insights to farmers. It also manages the communication links, securely transmitting large volumes of data back to a ground station or directly to cloud platforms for further analysis. The ability of the OS to robustly handle the demands of specialized sensor integration, data processing, and secure communication is what unlocks the full potential of drones for scientific research, infrastructure inspection, wildlife monitoring, and numerous other remote sensing applications.
The Evolution of Drone OS: Towards True Autonomous Intelligence
The trajectory of drone technology points towards increasingly autonomous and intelligent systems. The operating system at the core of these machines is undergoing continuous evolution, moving beyond simple control loops to incorporate sophisticated AI frameworks, machine learning capabilities, and more adaptive architectures. The future of drone OS aims to create platforms that can not only execute pre-programmed tasks but also learn, adapt, and make complex decisions in dynamic, unpredictable environments.
Machine Learning Integration and Adaptive Flight
The next generation of drone operating systems will deeply embed machine learning (ML) capabilities, moving beyond reactive control to proactive and adaptive flight. This involves the OS managing ML models that can analyze flight data, sensor inputs, and environmental conditions to refine flight parameters in real-time. For example, a drone’s OS could use ML to predict wind gusts and automatically adjust its flight profile for smoother operation, or to learn optimal power consumption patterns for extended flight times.
Adaptive flight also extends to mission planning. An ML-enhanced OS could dynamically alter a mapping path based on observed terrain features or modify an inspection route if an anomaly is detected. This represents a significant leap from current systems, where most decision-making logic is explicitly programmed. With ML integration, the OS becomes a learning entity, continuously improving its performance and capabilities based on experience, leading to more robust, efficient, and intelligent drone operations.
Edge Computing and Distributed OS Architectures
As drones become more sophisticated and operate in increasingly complex scenarios (e.g., urban environments, autonomous swarms), the demand for onboard processing power and low-latency decision-making grows. This drives the shift towards edge computing, where much of the data processing and AI inference occurs directly on the drone itself, rather than relying solely on cloud processing. The drone’s OS will evolve to manage these powerful edge computing resources, efficiently allocating tasks to dedicated processing units (e.g., GPUs, NPUs) and ensuring optimal performance.
Furthermore, for applications like drone swarms, the concept of a single “OS on computer” expands to a distributed operating system. Here, multiple drones collaborate, and their individual operating systems communicate and coordinate seamlessly to achieve a collective goal. This involves advanced networking protocols, robust synchronization mechanisms, and algorithms for decentralized decision-making. The future drone OS will therefore not only manage individual drone intelligence but also facilitate complex inter-drone communication and collective intelligence, opening up possibilities for large-scale environmental monitoring, search and rescue operations, and logistical applications that are currently beyond reach. The OS is truly the foundational enabler for the next era of drone innovation.