
The Earth, a beautiful, complex three-dimensional spheroid, presents a unique challenge for those who seek to represent its features on a two-dimensional surface. This fundamental cartographic dilemma gives rise to the concept of map projection – a systematic transformation of the Earth’s curved surface onto a flat plane. In the age of advanced drone technology, remote sensing, and sophisticated mapping, understanding map projections is more critical than ever, as it underpins the accuracy, interpretability, and utility of all spatial data we collect and analyze. Without a proper understanding of map projection, the high-resolution imagery and precise GPS coordinates captured by drones would be difficult to integrate, analyze, or even correctly display.

The Fundamental Challenge: Representing a Sphere on a Plane
Imagine peeling an orange and trying to flatten its skin without tearing or stretching it. It’s impossible to do without some form of distortion. The same principle applies to mapping the Earth. Our planet is an oblate spheroid – slightly flattened at the poles and bulging at the equator – and representing this inherently curved surface on a flat map invariably introduces inaccuracies.
The Earth’s Irregular Shape and Geographic Coordinates
The Earth’s true shape is often described by a geoid, an equipotential surface of the Earth’s gravity field approximating mean sea level. However, for most mapping purposes, a simpler mathematical model called an ellipsoid (or spheroid) is used to approximate the Earth’s shape. Geographic coordinates – latitude and longitude – are angular measurements relative to this ellipsoid. Latitude measures the angle north or south from the equator, while longitude measures the angle east or west from the prime meridian. These coordinates define a precise location on the Earth’s curved surface.
The challenge arises when these 3D coordinates need to be translated into X,Y coordinates on a 2D map. This transformation process is what a map projection accomplishes. It’s a mathematical function that takes geographic coordinates (latitude, longitude) and converts them into planar coordinates (easting, northing or x,y) on a map.
The Inevitable Distortions of Projection
Because it’s impossible to flatten a curved surface without some form of distortion, every map projection will inevitably distort at least one, and usually several, of the Earth’s four fundamental properties:
- Shape (Angular relationships): The shapes of features, like continents or countries.
- Area (Size): The relative sizes of landmasses.
- Distance: The accuracy of distances between points.
- Direction (Azimuth): The accuracy of compass bearings from one point to another.
The choice of map projection depends entirely on the purpose of the map and which properties are most important to preserve for a specific application. A drone mapping project focused on calculating precise land areas will require a different projection than one designed for navigation, where true direction might be paramount.
Types of Map Projections and Their Applications
Map projections are typically classified based on the developable surface used during the conceptual transformation. These developable surfaces are geometric shapes that can be flattened into a plane without stretching or tearing. The most common types are cylindrical, conic, and azimuthal (or planar).
Cylindrical Projections (e.g., Mercator)
Cylindrical projections conceptually wrap a cylinder around the globe. The Earth’s surface is then projected onto the cylinder, which is subsequently unrolled into a flat map.
- Properties: Often preserve shape (conformal) and direction along specific lines (rhumb lines).
- Distortions: Area distortion increases significantly towards the poles. Greenland appears much larger than South America, though it is considerably smaller.
- Applications: Historically popular for navigation (Mercator allows a constant bearing to be drawn as a straight line), and still widely used in web mapping services like Google Maps due to its conformal properties making local shapes look correct. For drone mapping, local conformal projections can be useful for maintaining the shapes of features within a relatively small project area.
Conic Projections (e.g., Lambert Conformal Conic, Albers Equal-Area Conic)
Conic projections place a cone over the globe, projecting the Earth’s surface onto it. The cone is then unrolled.
- Properties: Often used for mid-latitude regions. They can be designed to preserve either shape (conformal) or area (equal-area). Distortion increases further from the standard parallels (where the cone touches or intersects the globe).
- Applications: Common for national and regional mapping, especially in countries with an east-west extent (e.g., the United States). Lambert Conformal Conic is excellent for maintaining shapes over large regions, while Albers Equal-Area Conic is preferred for thematic maps where accurate area comparisons are crucial. Drone mapping projects covering larger areas at mid-latitudes might utilize conic projections for their balanced distortion characteristics.
Azimuthal/Planar Projections (e.g., Orthographic, Stereographic)
Azimuthal projections project the Earth’s surface onto a flat plane tangent to the globe at a single point (the center of the projection).
- Properties: Preserve direction and distance accurately from the central point. Distortion increases away from the center.
- Applications: Ideal for mapping polar regions (e.g., Polar Stereographic) or for showing hemispheres. Used in navigation charts centered on a specific point, or for displaying satellite imagery where the perspective from space is mimicked (e.g., Orthographic). For drone-based urban planning or site-specific analysis, where a single central point is the focus, azimuthal projections can be highly effective.
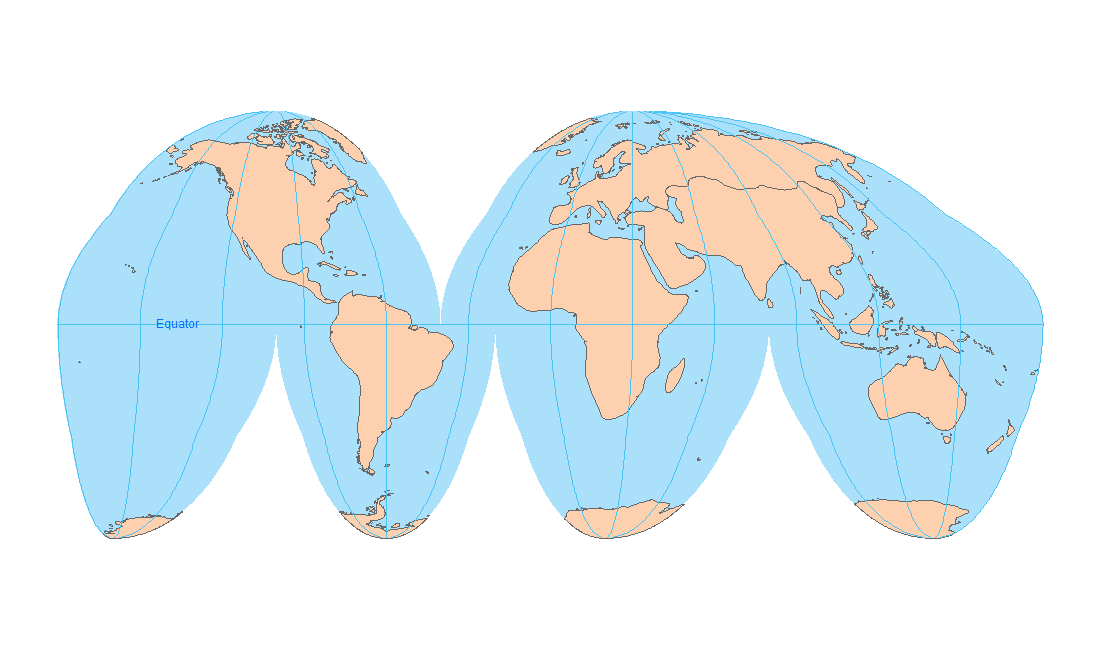
Compromise Projections (e.g., Robinson, Winkel Tripel)
Many projections are “compromise” projections, which do not strictly preserve any single property but instead attempt to minimize overall distortion of all four properties.
- Properties: Aims for a balance, making them visually appealing for general-purpose world maps.
- Applications: Popular for atlases, educational maps, and general geographic displays where an overall pleasing aesthetic and reasonable representation of all properties are desired, rather than extreme accuracy for any one property. These are less common for precise drone mapping analysis, but might be used for broad overviews or public-facing visualisations.
Key Properties Preserved and Distorted by Projections
When selecting a map projection for drone data or any spatial analysis, understanding which properties are preserved and which are distorted is paramount.
Conformal (Shape)
A conformal projection preserves local angles and shapes. This means that at any point, the scale is the same in all directions. Lines of latitude and longitude intersect at right angles, just as they do on the globe. While local shapes are true, areas can be severely distorted, especially at higher latitudes (as seen in Mercator). Conformal projections are critical for navigation, engineering, and any application where the accurate representation of local shapes is essential, such as detailed building footprints from drone photogrammetry.
Equal-Area (Area)
An equal-area (or equivalent) projection preserves the relative sizes of geographic features. If a country is twice the size of another on the Earth, it will be twice the size on an equal-area map. However, achieving this typically comes at the cost of shape distortion, especially in areas away from the standard parallels or central meridian. Equal-area projections are vital for thematic mapping, population density analysis, resource management, and any drone application where accurate quantification of area (e.g., agricultural field size, deforestation rates) is a primary objective.
Equidistant (Distance)
An equidistant projection preserves true distances, usually from one or two specific points or along certain lines. Distances measured from other points or along other lines will not necessarily be accurate. For example, an Azimuthal Equidistant projection centered on a city will accurately show the distance from that city to any other point, but not necessarily the distance between two other points on the map. These are useful for calculating travel distances from a central hub, or for drone flight planning where accurate distances from a base station are required.
True-Direction (Direction/Azimuth)
A true-direction (or azimuthal) projection preserves true bearings (directions) from a central point to all other points on the map. Like equidistant projections, this accuracy is typically from the center only. Azimuthal projections are valuable for understanding navigational bearings from a specific origin, such as flight paths from an airport.
Map Projection in Modern Mapping and Remote Sensing
The advent of precise GPS, high-resolution drone cameras, and powerful computing has revolutionized mapping and remote sensing. However, these advancements only amplify the need for a solid grasp of map projection.
Geographic Information Systems (GIS) and Data Integration
Geographic Information Systems (GIS) are the backbone of modern spatial analysis. They allow for the capture, storage, manipulation, analysis, and presentation of spatial or geographic data. A critical aspect of GIS is integrating data from various sources – satellite imagery, drone surveys, historical maps, GPS tracks – each potentially collected or presented using different coordinate systems and projections. For data layers to align correctly and for accurate spatial analysis to occur, all data must be transformed into a common projection system. Misaligned projections are a common source of errors in GIS projects, leading to inaccurate measurements and flawed interpretations.
Drone Mapping and Photogrammetry Workflows
Drones equipped with RTK/PPK GPS systems can capture imagery with incredible locational accuracy. Photogrammetry software then processes these images to create orthomosaics, 3D models, and point clouds. During this process, the software takes the georeferenced images and projects them onto a chosen 2D plane.
- Ground Control Points (GCPs): Even with RTK/PPK, GCPs are often used to refine the absolute accuracy of drone maps. The coordinates of these GCPs must be in a specific projected coordinate system that aligns with the desired output.
- Coordinate Reference Systems (CRS): A CRS combines a datum (a model of the Earth’s shape) with a projection. Drone mapping output must be assigned a CRS. Common CRSs for local drone projects include Universal Transverse Mercator (UTM) or State Plane Coordinate Systems, which are specifically designed to minimize distortion within smaller operational areas.
Choosing the Right Projection for Drone Data
The selection of a map projection for drone mapping data is not arbitrary; it’s a critical decision based on the project’s objectives and geographic extent:
- Local Accuracy: For detailed site surveys, construction monitoring, or precision agriculture, a projection that minimizes local distortion, such as UTM or a State Plane projection, is usually preferred. These systems divide the Earth into zones, each with its own projection, to ensure high accuracy within that zone.
- Area Measurement: If the primary goal is accurate area calculation for properties, fields, or environmental assessments, an equal-area projection or a local projection with minimal area distortion is essential.
- Visualization: For public-facing maps or general overviews, a projection that offers a balanced aesthetic and minimizes overall distortion might be chosen, though specific drone analysis almost always prioritizes accuracy over generalized aesthetics.
- Integration with Existing Data: Often, drone data needs to integrate seamlessly with existing GIS datasets from clients or government agencies. In such cases, adopting the projection of the existing data is crucial to ensure compatibility and avoid misalignment issues.

The Importance of Understanding Projection Parameters
Beyond simply choosing a projection type, understanding its parameters is also vital. These parameters include:
- Datum: The reference system for geographic coordinates (e.g., WGS84 for GPS, NAD83 for North America).
- Central Meridian: The longitude that defines the center of the projection, often the line of true scale or minimal distortion.
- Standard Parallels: For conic projections, these are the lines of latitude where the cone touches or intersects the globe, and where there is no distortion.
- False Easting/Northing: Offset values applied to the X and Y coordinates to ensure all values are positive and manageable.
Misinterpreting or incorrectly applying these parameters can lead to significant errors in drone-derived maps, rendering them useless for precise applications. As drone technology continues to evolve and become an indispensable tool for mapping and remote sensing, a solid understanding of map projection remains a foundational skill for anyone working with spatial data.