
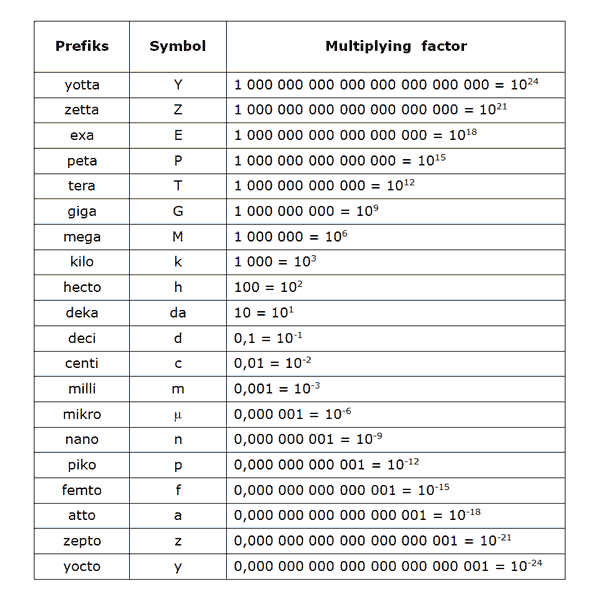
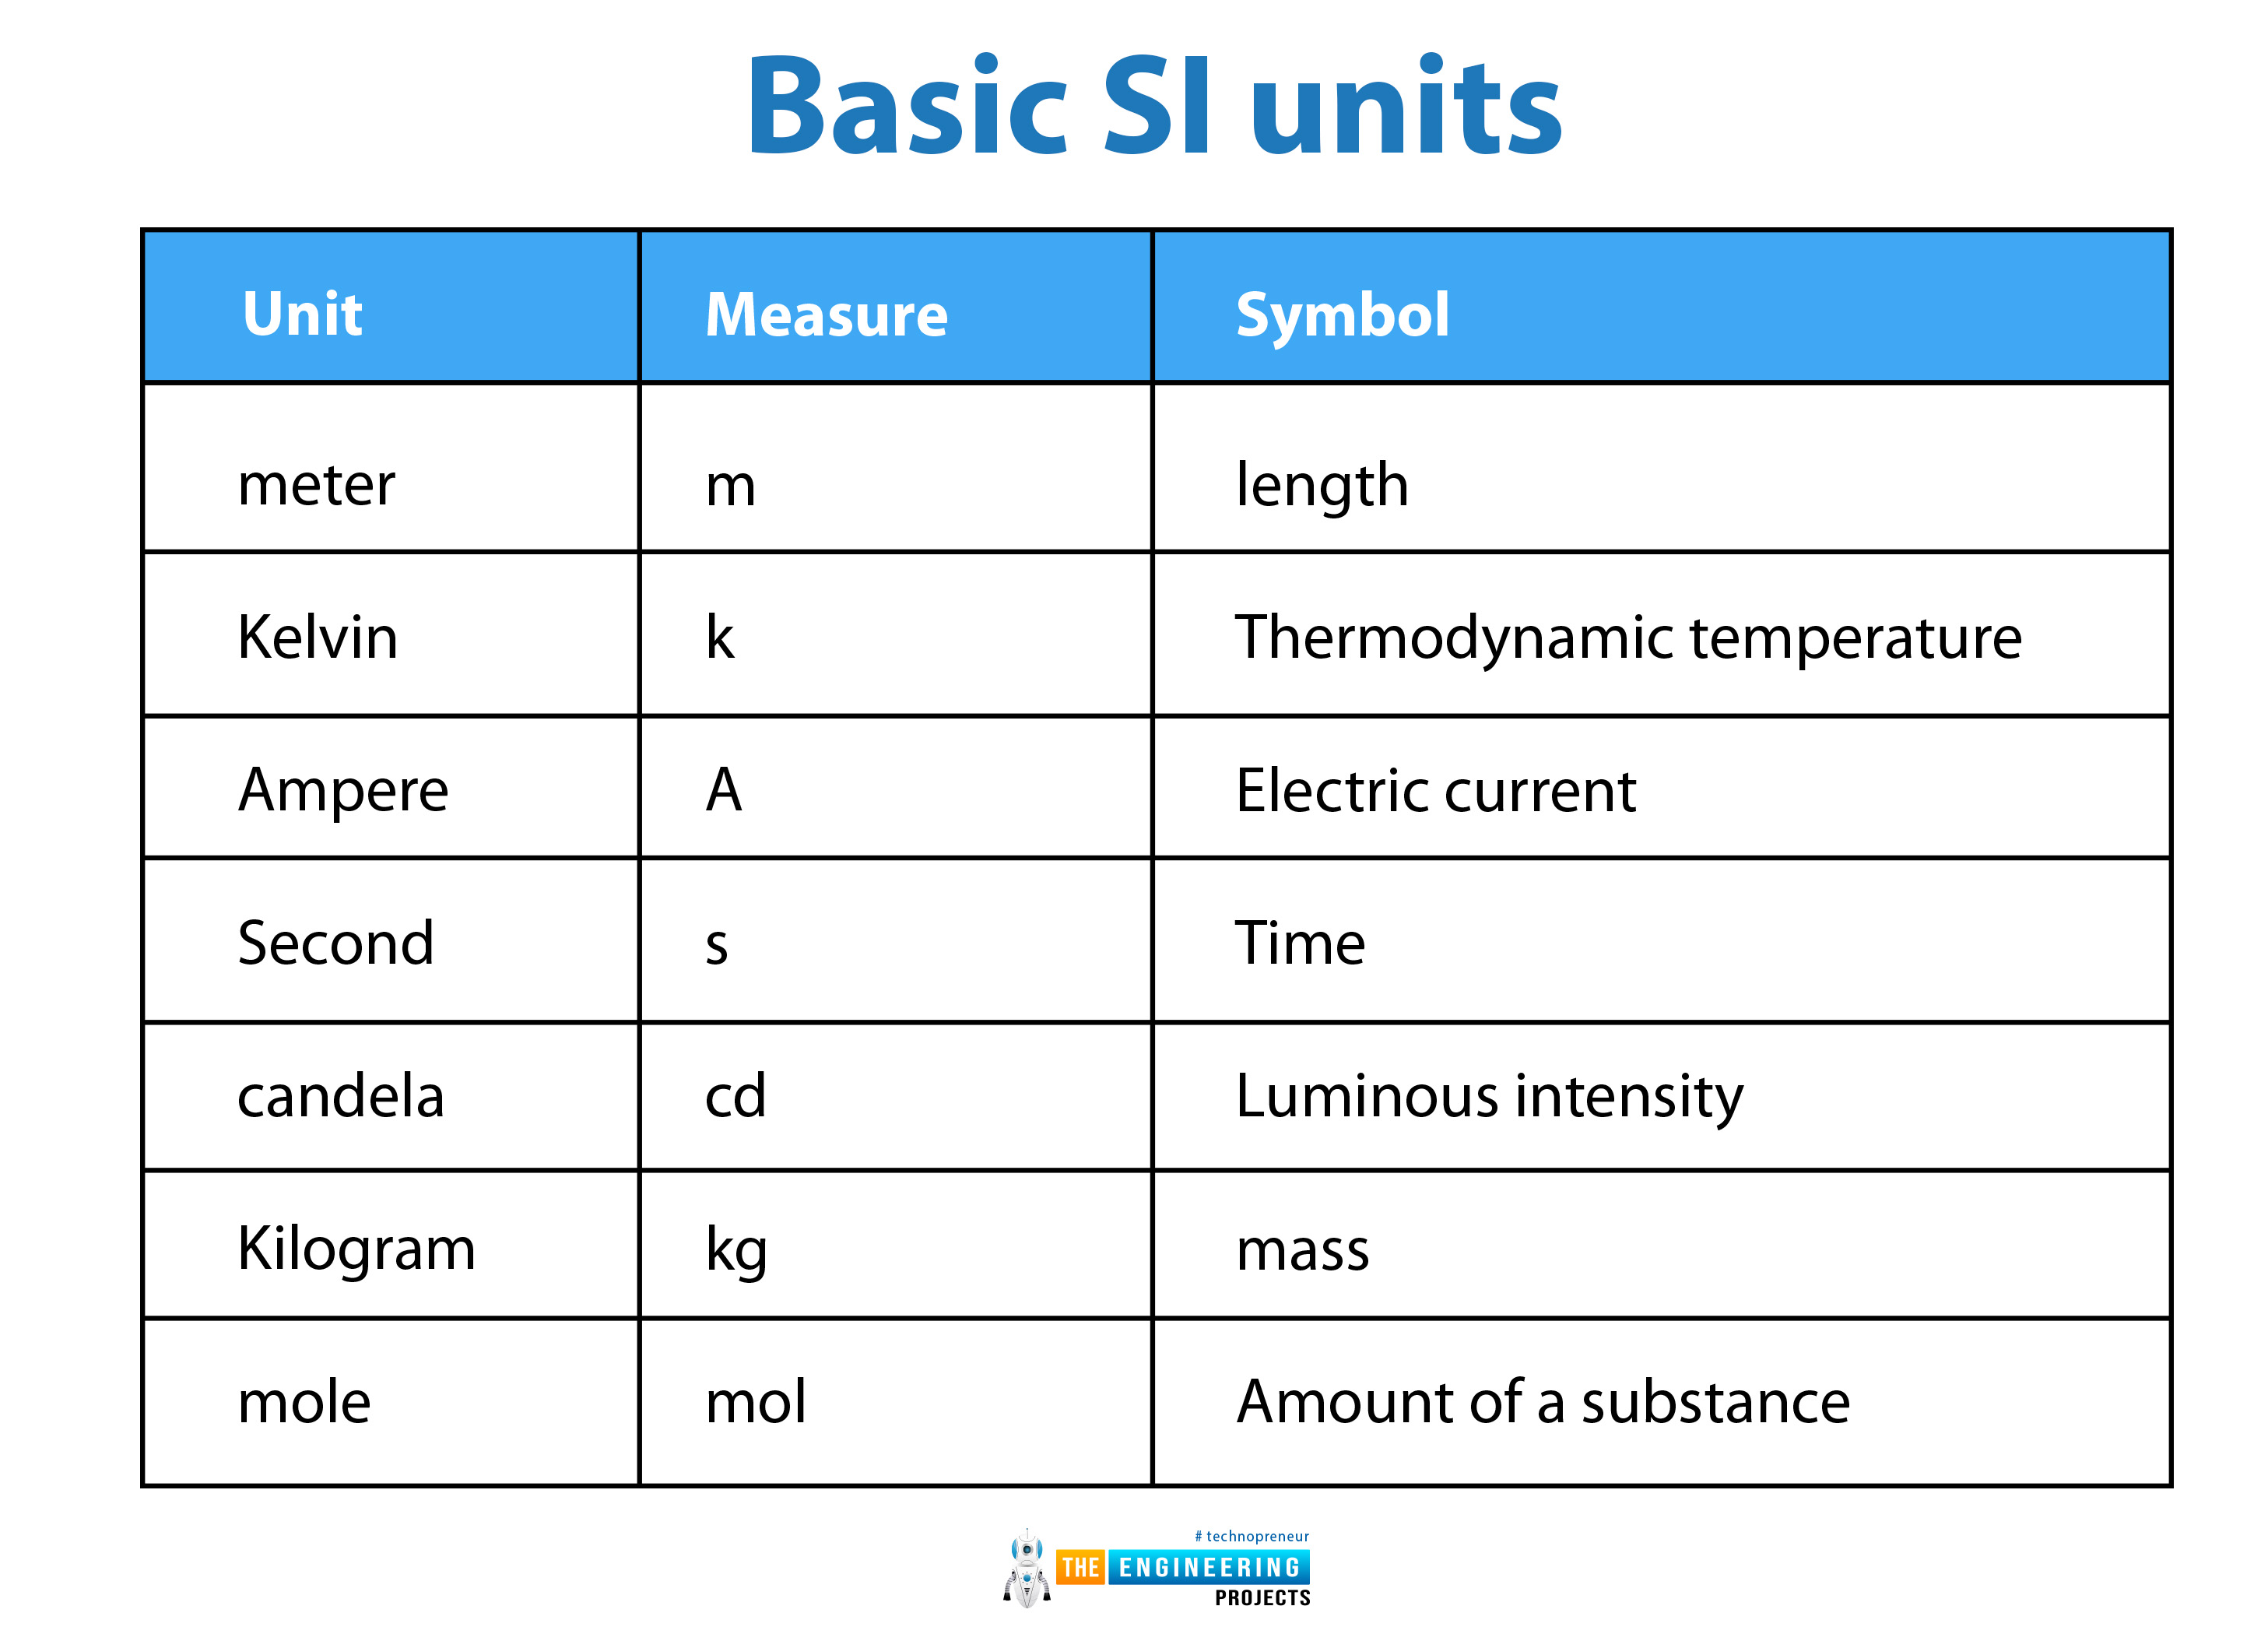
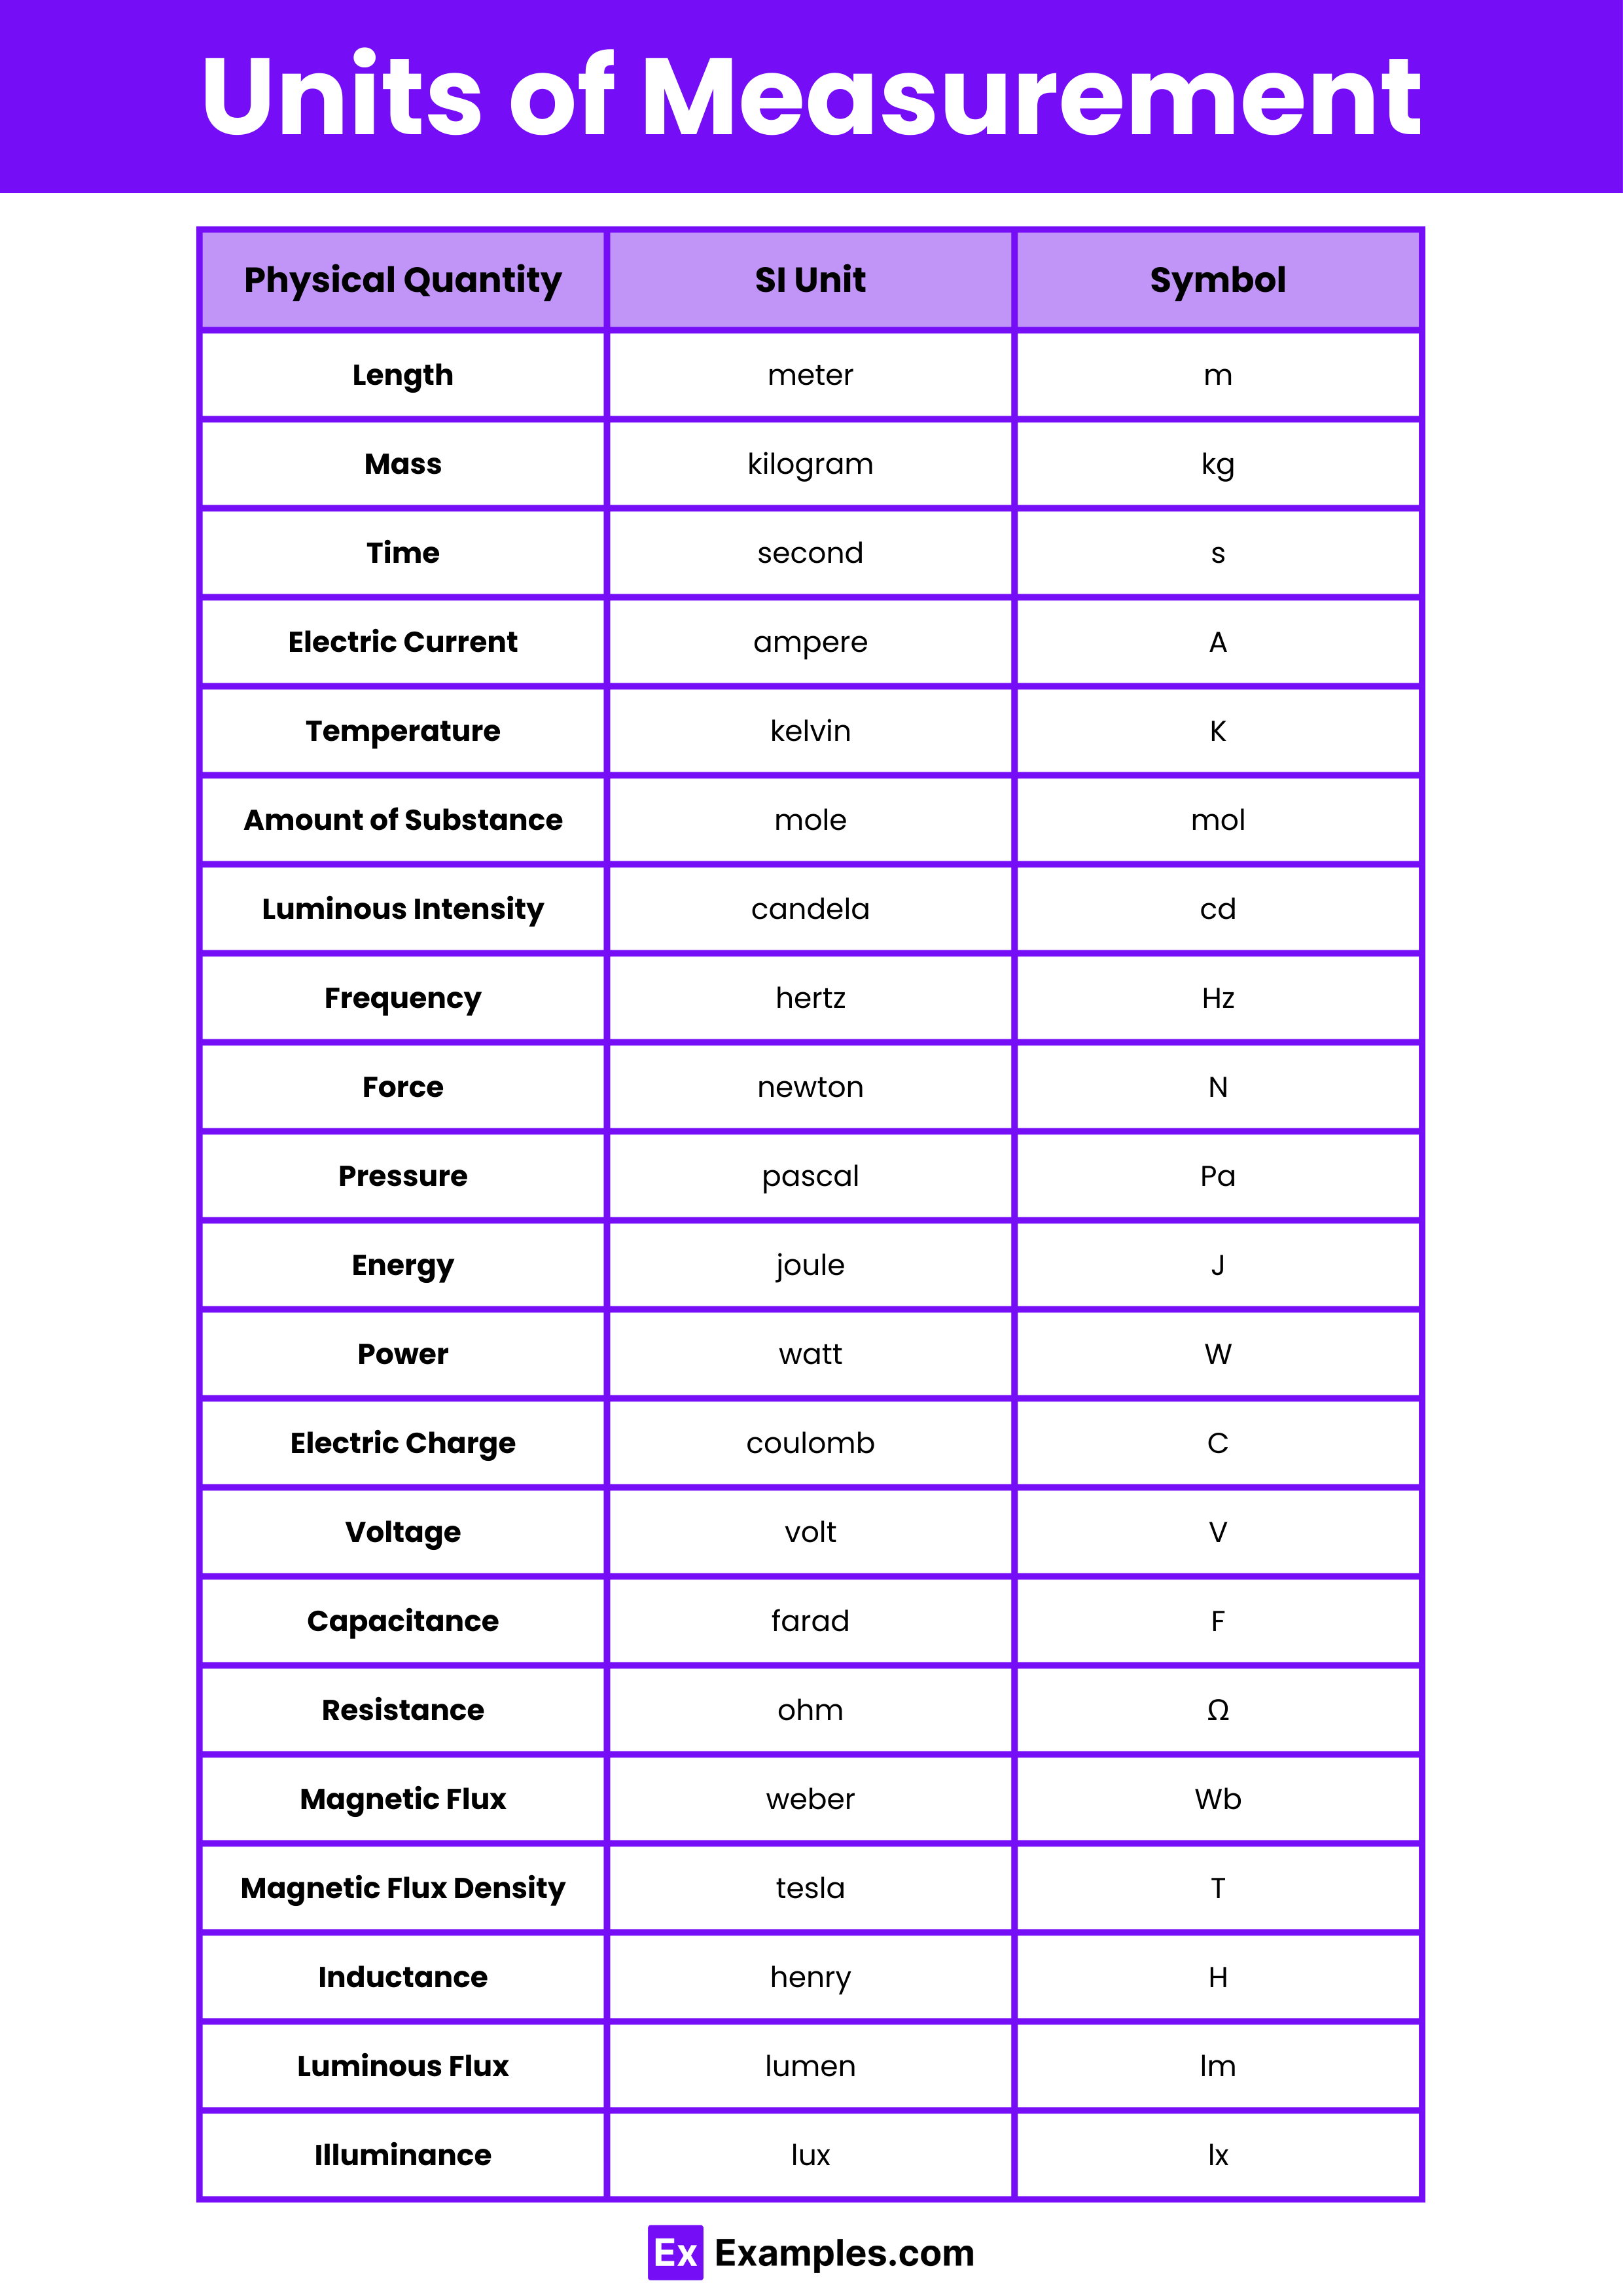
The International System of Units (SI), derived from the French “Système international d’unités,” represents the globally recognized standard for measurement. It is the modern metric system, meticulously designed to provide a coherent, unambiguous, and universally applicable framework for quantifying physical phenomena across science, technology, industry, and commerce. At its foundation are seven base units: the meter (m) for length, kilogram (kg) for mass, second (s) for time, ampere (A) for electric current, kelvin (K) for thermodynamic temperature, mole (mol) for amount of substance, and candela (cd) for luminous intensity. All other SI units, known as derived units (e.g., newton for force, pascal for pressure, joule for energy), are mathematically expressed in terms of these base units. The very existence and reliability of modern flight technology, from intricate drone navigation systems to sophisticated stabilization algorithms, are inextricably linked to the rigorous adoption and precise interpretation of these standardized SI units. Without this consistent framework, the complex interplay of sensors, processors, and actuators that define contemporary aerial vehicles would be prone to chaos, rendering precise control and predictable operation impossible.
The Imperative of Standardization in Flight Technology
In the demanding realm of flight technology, precision, consistency, and interoperability are not merely desirable attributes but absolute necessities. An unmanned aerial vehicle (UAV) or drone is a marvel of engineering that synthesizes data from an array of disparate sensors, each measuring different physical quantities. For these diverse data streams to be fused, interpreted, and acted upon effectively by the flight controller, they must first speak the same language—the language of SI units.
Bridging Diverse Sensor Data
A typical drone’s flight stack incorporates an Inertial Measurement Unit (IMU), comprising accelerometers and gyroscopes; a Global Positioning System (GPS) receiver; a magnetometer; and often a barometric altimeter. Each of these components outputs data in a specific format, representing acceleration, angular velocity, position, magnetic field strength, and atmospheric pressure, respectively. If an accelerometer reports acceleration in ‘g-forces’ and a gyroscope reports angular velocity in ‘degrees per second,’ while a navigation algorithm expects inputs in ‘meters per second squared’ and ‘radians per second,’ a direct conversion or misinterpretation could lead to significant errors.
The SI system resolves this challenge by providing a universal standard. Accelerometers are calibrated to output in meters per second squared (m/s²), gyroscopes in radians per second (rad/s), GPS receivers in meters (m) for position, and barometers in pascals (Pa) for pressure. This standardization ensures that when a flight control algorithm combines data from these sensors—for instance, to estimate the drone’s attitude or velocity through a Kalman filter or complementary filter—all inputs are coherently expressed within the same system. This coherence is paramount for accurate sensor fusion, which is the process of combining data from multiple sensors to achieve a more robust and accurate estimate of the drone’s state than would be possible with individual sensors alone. Without SI unit consistency, sensor fusion algorithms would fail to produce reliable results, leading to unstable flight, inaccurate navigation, or even catastrophic failure.
Global Compatibility and Reliability
Beyond internal system coherence, SI units facilitate global compatibility in drone development, manufacturing, and operation. Manufacturers worldwide can design components, write software, and publish specifications using the same measurement standards. This universality simplifies development cycles, reduces the potential for costly errors stemming from unit conversions, and allows for seamless integration of components from various suppliers. Moreover, it enables international collaboration in research and development, fostering innovation and accelerating advancements in flight technology. For operators, especially those engaged in commercial applications like mapping, surveying, or delivery, adhering to SI units ensures that their collected data is universally understood and can be easily integrated into other systems, irrespective of geographical location or originating equipment. The reliability derived from this standardization extends to safety protocols, air traffic management systems for UAVs, and regulatory compliance, all of which depend on unambiguous quantitative data.
Core SI Units Driving Drone Navigation and Control
The precise control and autonomous capabilities of modern drones are fundamentally underpinned by the accurate measurement and processing of data in specific SI units. These units form the bedrock upon which sophisticated flight control systems are built.
Length and Position: The Meter (m)
The meter is arguably the most critical SI base unit for drone navigation. Global Positioning System (GPS) receivers, fundamental to outdoor drone operation, communicate position coordinates (latitude, longitude, altitude) and velocity in meters and meters per second, respectively. Real-Time Kinematic (RTK) and Post-Processed Kinematic (PPK) GPS systems, designed for centimeter-level accuracy, directly output positions with reference to a known baseline in meters.
Beyond navigation, meters define the operational space of a drone. Obstacle avoidance systems use rangefinders (ultrasonic, lidar, stereo vision) to measure distances to objects in meters, feeding this data into algorithms that guide the drone away from collisions. Mapping and surveying applications rely on the meter to define the scale and precision of generated maps, orthomosaics, and 3D models. Every dimension, every distance, and every positional fix that dictates a drone’s presence in space is quantifiable through the meter, ensuring that a drone knows precisely where it is and where it is going relative to its environment.
Motion and Orientation: Accelerometers and Gyroscopes (m/s², rad/s)
The Inertial Measurement Unit (IMU) is the heart of a drone’s stabilization system, providing crucial data on its linear acceleration and angular velocity.
- Accelerometers measure the drone’s proper acceleration, typically along three orthogonal axes. When calibrated correctly, these sensors provide output in meters per second squared (m/s²). This data is vital for estimating linear velocity and position, especially in short-term maneuvers or in environments where GPS signals are weak or unavailable. It also contributes to determining the drone’s attitude by detecting the direction of gravity.
- Gyroscopes measure the drone’s angular velocity—the rate of change of its orientation—around three axes. Their output is standardized in radians per second (rad/s). This information is critical for maintaining stability. The flight controller uses gyroscope data to detect any unintended rotations (pitch, roll, yaw) and apply corrective forces to the motors, ensuring a level and controlled flight. The conversion from degrees per second (a common uncalibrated output) to radians per second is a standard practice in sensor data processing for SI adherence.
The fusion of accelerometer and gyroscope data allows the flight controller to accurately estimate the drone’s attitude and short-term motion, forming the backbone of stabilization algorithms and allowing for precise execution of flight commands.
Atmospheric Pressure and Altitude: The Pascal (Pa)
Barometric altimeters, commonly found in drones, measure atmospheric pressure, which inversely correlates with altitude. The SI unit for pressure is the pascal (Pa). By measuring the change in atmospheric pressure relative to a calibrated sea-level pressure or a known ground-level pressure, the drone’s flight controller can accurately determine its altitude above ground level (AGL) or mean sea level (MSL). This vertical positioning is critical for maintaining a desired altitude during flight, executing precise ascents and descents, and complying with airspace regulations. While altitude is often expressed in meters, the raw measurement from the barometer is in pascals, which is then converted using atmospheric models.
Time: The Second (s)
The second is the SI base unit for time, and its unwavering precision is fundamental to virtually every aspect of flight technology. From the high-frequency sampling rates of IMU sensors (often hundreds or thousands of times per second) to the millisecond-level timing of motor commands and the synchronized data packets from GPS satellites, time is the invisible orchestrator. Accurate timing ensures that sensor data is correctly timestamped for fusion algorithms, that control loops execute with deterministic regularity, and that navigation systems can calculate velocity and predict future positions reliably. Without a precise and consistent definition of the second, the dynamic, real-time computations essential for stable and autonomous flight would be impossible.
Precision, Calibration, and the SI System
The theoretical elegance of SI units is only as good as their practical implementation. For flight technology, maintaining the integrity of these units through precision and rigorous calibration is paramount.
The Impact of Measurement Error
Even small deviations from accurate SI measurement can have significant consequences in dynamic systems like drones. An accelerometer that consistently overestimates acceleration by a small percentage, or a gyroscope whose zero-rate output drifts, can lead to accumulating errors in the estimated position (dead reckoning) or attitude. Over time, these errors can cause the drone to drift, fail to hold position, or even become unstable. The “fly-away” phenomenon, while often multi-faceted, can sometimes be traced back to subtle measurement errors or incorrect unit interpretation leading to cascading failures in the navigation system.
Calibration’s Role in Accuracy
Calibration is the process of adjusting a sensor’s output to match a known standard, ensuring that its readings accurately reflect the true physical quantity in SI units. For instance, accelerometers are calibrated by exposing them to known gravitational forces at different orientations to map raw sensor outputs to m/s². Gyroscopes are calibrated to remove bias (zero-rate offset) and scale errors, ensuring that zero angular velocity corresponds to 0 rad/s and that a given physical rotation rate precisely translates to the correct rad/s value. Magnetometers are calibrated to compensate for hard-iron and soft-iron distortions, ensuring accurate heading measurements in relation to the Earth’s magnetic field (expressed in tesla, another SI derived unit). Consistent and frequent calibration, often performed automatically by the drone’s firmware or through user-initiated routines, is critical for maintaining the high degree of accuracy required for reliable flight.
Advanced Sensor Fusion and SI Coherence
Modern drone flight controllers employ advanced sensor fusion algorithms to combine data from multiple sensors, compensating for the limitations of individual sensors and providing a more robust estimate of the drone’s state. These algorithms, such as Extended Kalman Filters (EKF) or Unscented Kalman Filters (UKF), critically depend on the coherence of all input measurements in SI units. For example, fusing GPS velocity data (m/s) with IMU acceleration data (m/s²) to estimate the drone’s true velocity requires that both inputs are perfectly aligned within the SI framework. Any inconsistency in units or scale factors would introduce systematic errors, severely degrading the filter’s performance and potentially leading to erratic behavior or loss of control. The meticulous adherence to SI units across all sensor inputs is a non-negotiable prerequisite for the success of these sophisticated control methodologies.
Beyond Basic Flight: Advanced Applications and SI Units
The foundational reliance on SI units extends far beyond simple stabilization and navigation, enabling complex and specialized drone applications that drive technological innovation.
Mapping and Geolocation
Drones equipped with high-resolution cameras and advanced navigation systems are indispensable tools for aerial mapping and surveying. The accuracy of the resulting maps, digital elevation models (DEMs), and 3D point clouds is directly tied to the precision of the underlying SI unit measurements. Georeferencing, the process of aligning a map or image with a geographic coordinate system, relies heavily on GPS data in meters. Ground Control Points (GCPs) measured with survey-grade GPS units provide precise meter-level references that anchor the drone’s imagery to the real world. The scale of features within a map, the volumetric calculations for stockpiles, or the precise dimensions of infrastructure are all fundamentally expressed and verified using meters. Without this SI-based precision, mapping data would be inconsistent, inaccurate, and ultimately unusable for critical applications in construction, agriculture, urban planning, and environmental monitoring.
Obstacle Avoidance and Proximity Sensing
Advanced obstacle avoidance systems, which allow drones to navigate complex environments autonomously, are built upon real-time distance measurements. Lidar sensors, ultrasonic rangefinders, and stereo vision cameras all provide proximity data in meters. These systems use this SI-unit distance information to build a dynamic 3D map of the drone’s immediate surroundings. Algorithms then process this data to identify potential collision threats and calculate safe flight paths, often defining exclusion zones in meters around identified obstacles. For instance, a drone might be programmed to maintain a minimum clearance of 2 meters from any detected object. The reliability and safety of such autonomous operations hinge entirely on the accuracy and consistency of these meter-based measurements, demonstrating how SI units enable sophisticated functionalities that push the boundaries of drone capabilities.