
Understanding the GitHub Repository in Drone Tech Development
In the rapidly evolving landscape of drone technology, where innovations in artificial intelligence (AI) follow mode, autonomous flight, sophisticated mapping, and remote sensing are constantly pushing boundaries, the underlying software infrastructure is paramount. A GitHub repository, often simply called a “repo,” serves as the fundamental digital workspace for these advancements. At its core, a repository is a project folder that resides on GitHub’s cloud-based platform, designed to store all the files and historical revisions of a software project. For drone developers, this means housing everything from the complex algorithms powering AI object recognition and navigation systems to the firmware code dictating a drone’s autonomous flight path.
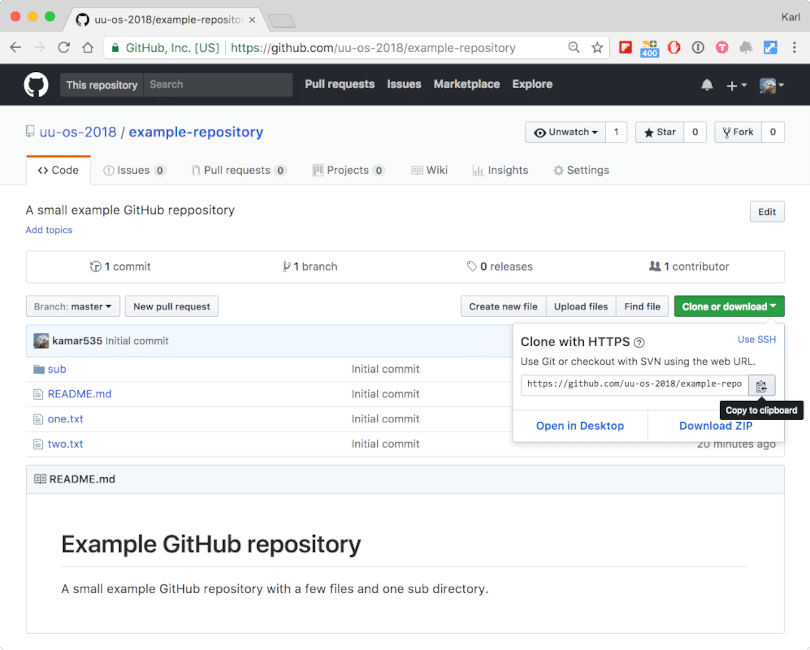
Think of a repository as the central archive and collaborative hub for a specific drone tech initiative. Whether it’s a team of engineers developing next-generation obstacle avoidance software, researchers refining photogrammetry algorithms for 3D mapping, or enthusiasts contributing to an open-source flight controller firmware, the repository provides a structured environment. It’s not just a storage locker; it’s a dynamic record of every change, every contribution, and every decision made throughout the project’s lifecycle, critical for maintaining integrity and enabling rapid iteration in cutting-edge tech.
The Digital Workspace for Autonomous Systems
For developers immersed in creating autonomous flight systems, a GitHub repository is the beating heart of their operation. This digital workspace is where source code for flight control units (FCUs), mission planning software, and sophisticated sensor fusion algorithms are stored and managed. Imagine a project dedicated to an AI-driven system that allows a drone to intelligently inspect power lines. The repository would contain all Python scripts for image processing, machine learning models trained for fault detection, C++ code for embedded system communication, configuration files, and even documentation detailing the system architecture.
This centralized approach ensures that all team members are working from the most current version of the project files. Without a repository, coordinating updates to the highly interconnected components of an autonomous system—like changes to GPS navigation logic needing to integrate with a new stabilization algorithm—would be chaotic and error-prone. GitHub repositories streamline this, providing a clear, chronological history of modifications, making it easier to track progress, debug issues, and ensure the reliability essential for safe and effective autonomous drone operations.
Bridging Concepts to Code for AI and Mapping
The journey from a theoretical concept—such as a novel AI algorithm for environmental monitoring or a more efficient technique for generating high-resolution topographic maps—to deployable code invariably passes through a GitHub repository. These repositories act as the crucible where abstract ideas are transformed into functional software. For AI-powered drone applications, this means storing datasets used for training models, the neural network architectures themselves, inference scripts, and the integration code that allows the AI to interface with drone hardware.
In the realm of mapping and remote sensing, repositories host scripts for stitching together aerial imagery, algorithms for point cloud processing, tools for generating digital elevation models (DEMs), and user interfaces for visualizing geospatial data. The collaborative nature of GitHub means that researchers from different institutions or developers working on disparate parts of a mapping pipeline can contribute their specialized code modules directly into a single, unified project. This fosters a more rapid development cycle, allowing for quicker implementation and testing of new ideas in areas like precision agriculture mapping or infrastructure inspection.
Version Control: The Backbone of Evolving Drone Innovations
At the core of every GitHub repository lies Git, a powerful distributed version control system. Version control is indispensable in tech and innovation, especially for drone systems where precision, safety, and continuous improvement are paramount. Git allows developers to track every single change made to the project files, creating a comprehensive history of modifications. This history is not merely a record; it’s a safeguard, enabling teams to revert to previous stable versions if a new feature introduces bugs, compare different iterations of code, and understand the evolution of an algorithm or system over time.
For advanced drone technologies, where software directly impacts flight performance and safety, robust version control is critical. Consider the development of firmware for autonomous emergency landing procedures. Each line of code, each conditional statement, must be meticulously reviewed and tracked. Git ensures that developers can incrementally build complex functionalities, knowing they can always trace back the lineage of their code, pinpointing exactly when and where a change occurred. This level of traceability is vital for regulatory compliance and ensures the integrity of mission-critical software.
Safeguarding Algorithmic Advances
The development of sophisticated algorithms for AI follow mode, intelligent obstacle avoidance, or advanced data analysis in remote sensing is an iterative process. Researchers and engineers constantly tweak parameters, refactor code, and experiment with new approaches. Git, managed within a GitHub repository, is instrumental in safeguarding these algorithmic advances. Each successful iteration, each optimized function, can be committed to the repository, creating a snapshot in time.
If a new experimental algorithm for object detection, for instance, proves less effective than a previous version, developers can easily revert to the known stable state. This encourages experimentation without the fear of irrevocably corrupting the working codebase. Furthermore, Git allows for detailed commit messages, explaining why a particular change was made, which is invaluable for understanding the rationale behind complex algorithmic decisions weeks or months later, especially when new team members join a project focused on fine-tuning an AI model for environmental monitoring.
Collaborative Development for Complex Flight Logic
Modern drone flight logic involves intricate interactions between various subsystems: navigation (GPS, IMU), propulsion, power management, payload control, and increasingly, AI-driven decision-making. Developing such complex systems often requires multiple experts working concurrently. GitHub repositories facilitate this collaborative development seamlessly.
Each developer can work on their specific component—one might be refining the proportional-integral-derivative (PID) controllers for enhanced stability, another integrating new sensor data for improved GPS-denied navigation, and yet another implementing a new communication protocol for drone-to-drone swarm behavior. Git manages these parallel efforts by allowing each developer to work on their local copy of the repository. When their work is ready, they can “push” their changes to the central GitHub repository, which then becomes available for integration with other team members’ contributions. This distributed model of version control means that even if a team member is working offline, they have the complete project history, ensuring continuity and consistency across a globally distributed development team tackling challenges like precise autonomous landing.
Branching, Merging, and Pull Requests: Accelerating Feature Integration
Beyond basic version control, GitHub repositories leverage powerful workflows centered around branching, merging, and pull requests. These features are indispensable for accelerating the integration of new capabilities and bug fixes into drone technology projects, maintaining stability while fostering rapid innovation. A “branch” is essentially a divergent line of development that stems from the main project codebase, allowing developers to work on new features or fixes without affecting the “main” or “master” branch, which typically represents the stable, deployable version of the software.
Once work on a branch is complete and thoroughly tested, it can be “merged” back into the main branch, integrating the new functionality into the stable codebase. Before merging, a “pull request” (PR) is typically created. A PR is a request to merge changes from one branch into another, serving as a formal mechanism for code review. Team members can discuss proposed changes, suggest improvements, and ensure the code meets quality and performance standards before it becomes part of the core project. This structured approach is crucial for drone software, where even minor code errors can have significant implications for safety and performance.
Parallel Progress on AI Follow Modes and Sensor Integration
Consider a drone development team simultaneously working on enhancing an AI follow mode and integrating a new type of LiDAR sensor for improved obstacle avoidance. With GitHub’s branching model, two separate teams or individual developers can work in parallel. One team develops their AI algorithms for object tracking and prediction on an ai-follow-mode branch. Concurrently, another team writes drivers and sensor fusion algorithms for the new LiDAR on a lidar-integration branch.
Neither team’s work interferes with the other, nor do they risk destabilizing the main branch, which might be running the current stable autonomous flight software. This parallel development significantly reduces the overall time required to bring complex features to market. Once each feature branch is stable and fully tested, the changes can be merged into the main branch, allowing the drone to benefit from both advanced AI tracking and superior environmental perception. This agility is key in the competitive drone tech space.
Ensuring Stability in Autonomous Flight Systems
The stability and reliability of autonomous flight systems are paramount. Any new feature, whether it’s an update to navigation algorithms or a new telemetry reporting module, must be rigorously tested before deployment. Pull requests are a critical part of this quality assurance process within GitHub repositories. When a developer proposes changes through a pull request, automated tests (known as Continuous Integration/Continuous Deployment, or CI/CD pipelines, often integrated with GitHub) can be triggered automatically. These tests verify that the new code doesn’t introduce regressions or break existing functionality.
Furthermore, pull requests enable peer code review, where other experienced engineers scrutinize the proposed changes. For critical drone systems, this review process is invaluable for catching potential bugs, identifying security vulnerabilities, and ensuring adherence to coding standards, ultimately contributing to the robustness and safety of the drone’s autonomous capabilities. Only after thorough review and passing all automated tests is a pull request approved and merged, guaranteeing that the main branch always contains reliable, deployable code ready for integration into drone firmware or ground control stations.
Beyond Code: Repositories for Data, Documentation, and Community
While primarily known for source code management, GitHub repositories extend their utility far beyond just lines of code, serving as comprehensive hubs for all aspects of tech and innovation in the drone industry. They can store documentation, datasets, configuration files, design specifications, and even project management assets. This holistic approach means that a repository can encapsulate the entire scope of a drone tech project, from initial concept to deployment and ongoing maintenance.
For instance, a project focused on developing advanced remote sensing capabilities might use a repository not only for its image processing algorithms but also for sample datasets of aerial imagery, markdown files outlining research methodologies, and licensing information for derived products. This makes the repository a single source of truth for all project-related assets, facilitating transparency and ensuring that all stakeholders, from developers to technical writers and project managers, have access to the most current and relevant information.
Managing Remote Sensing Data and Mapping Outputs
In the domain of remote sensing and mapping with drones, data is as critical as code. GitHub repositories, while not designed for extremely large binary files (which are often managed via external storage linked from the repo), are excellent for managing metadata, smaller processed data samples, scripts for data ingestion and transformation, and the code that generates mapping outputs. For example, a repository for a precision agriculture drone system might contain:
- Python scripts for analyzing multispectral imagery.
- Jupyter notebooks demonstrating how to derive vegetation indices (NDVI).
- Configuration files for photogrammetry software.
- Sample GeoTIFFs or shapefiles as output examples.
- Documentation explaining data formats and processing pipelines.
This structured storage ensures that the entire workflow, from raw sensor data processing to generating actionable intelligence for farmers or land managers, is well-documented and reproducible. Furthermore, tools like Git LFS (Large File Storage) can extend GitHub’s capabilities to manage larger files more efficiently within the repository context by storing pointers to the actual files, which reside on separate servers.
Fostering Open-Source Drone Innovation
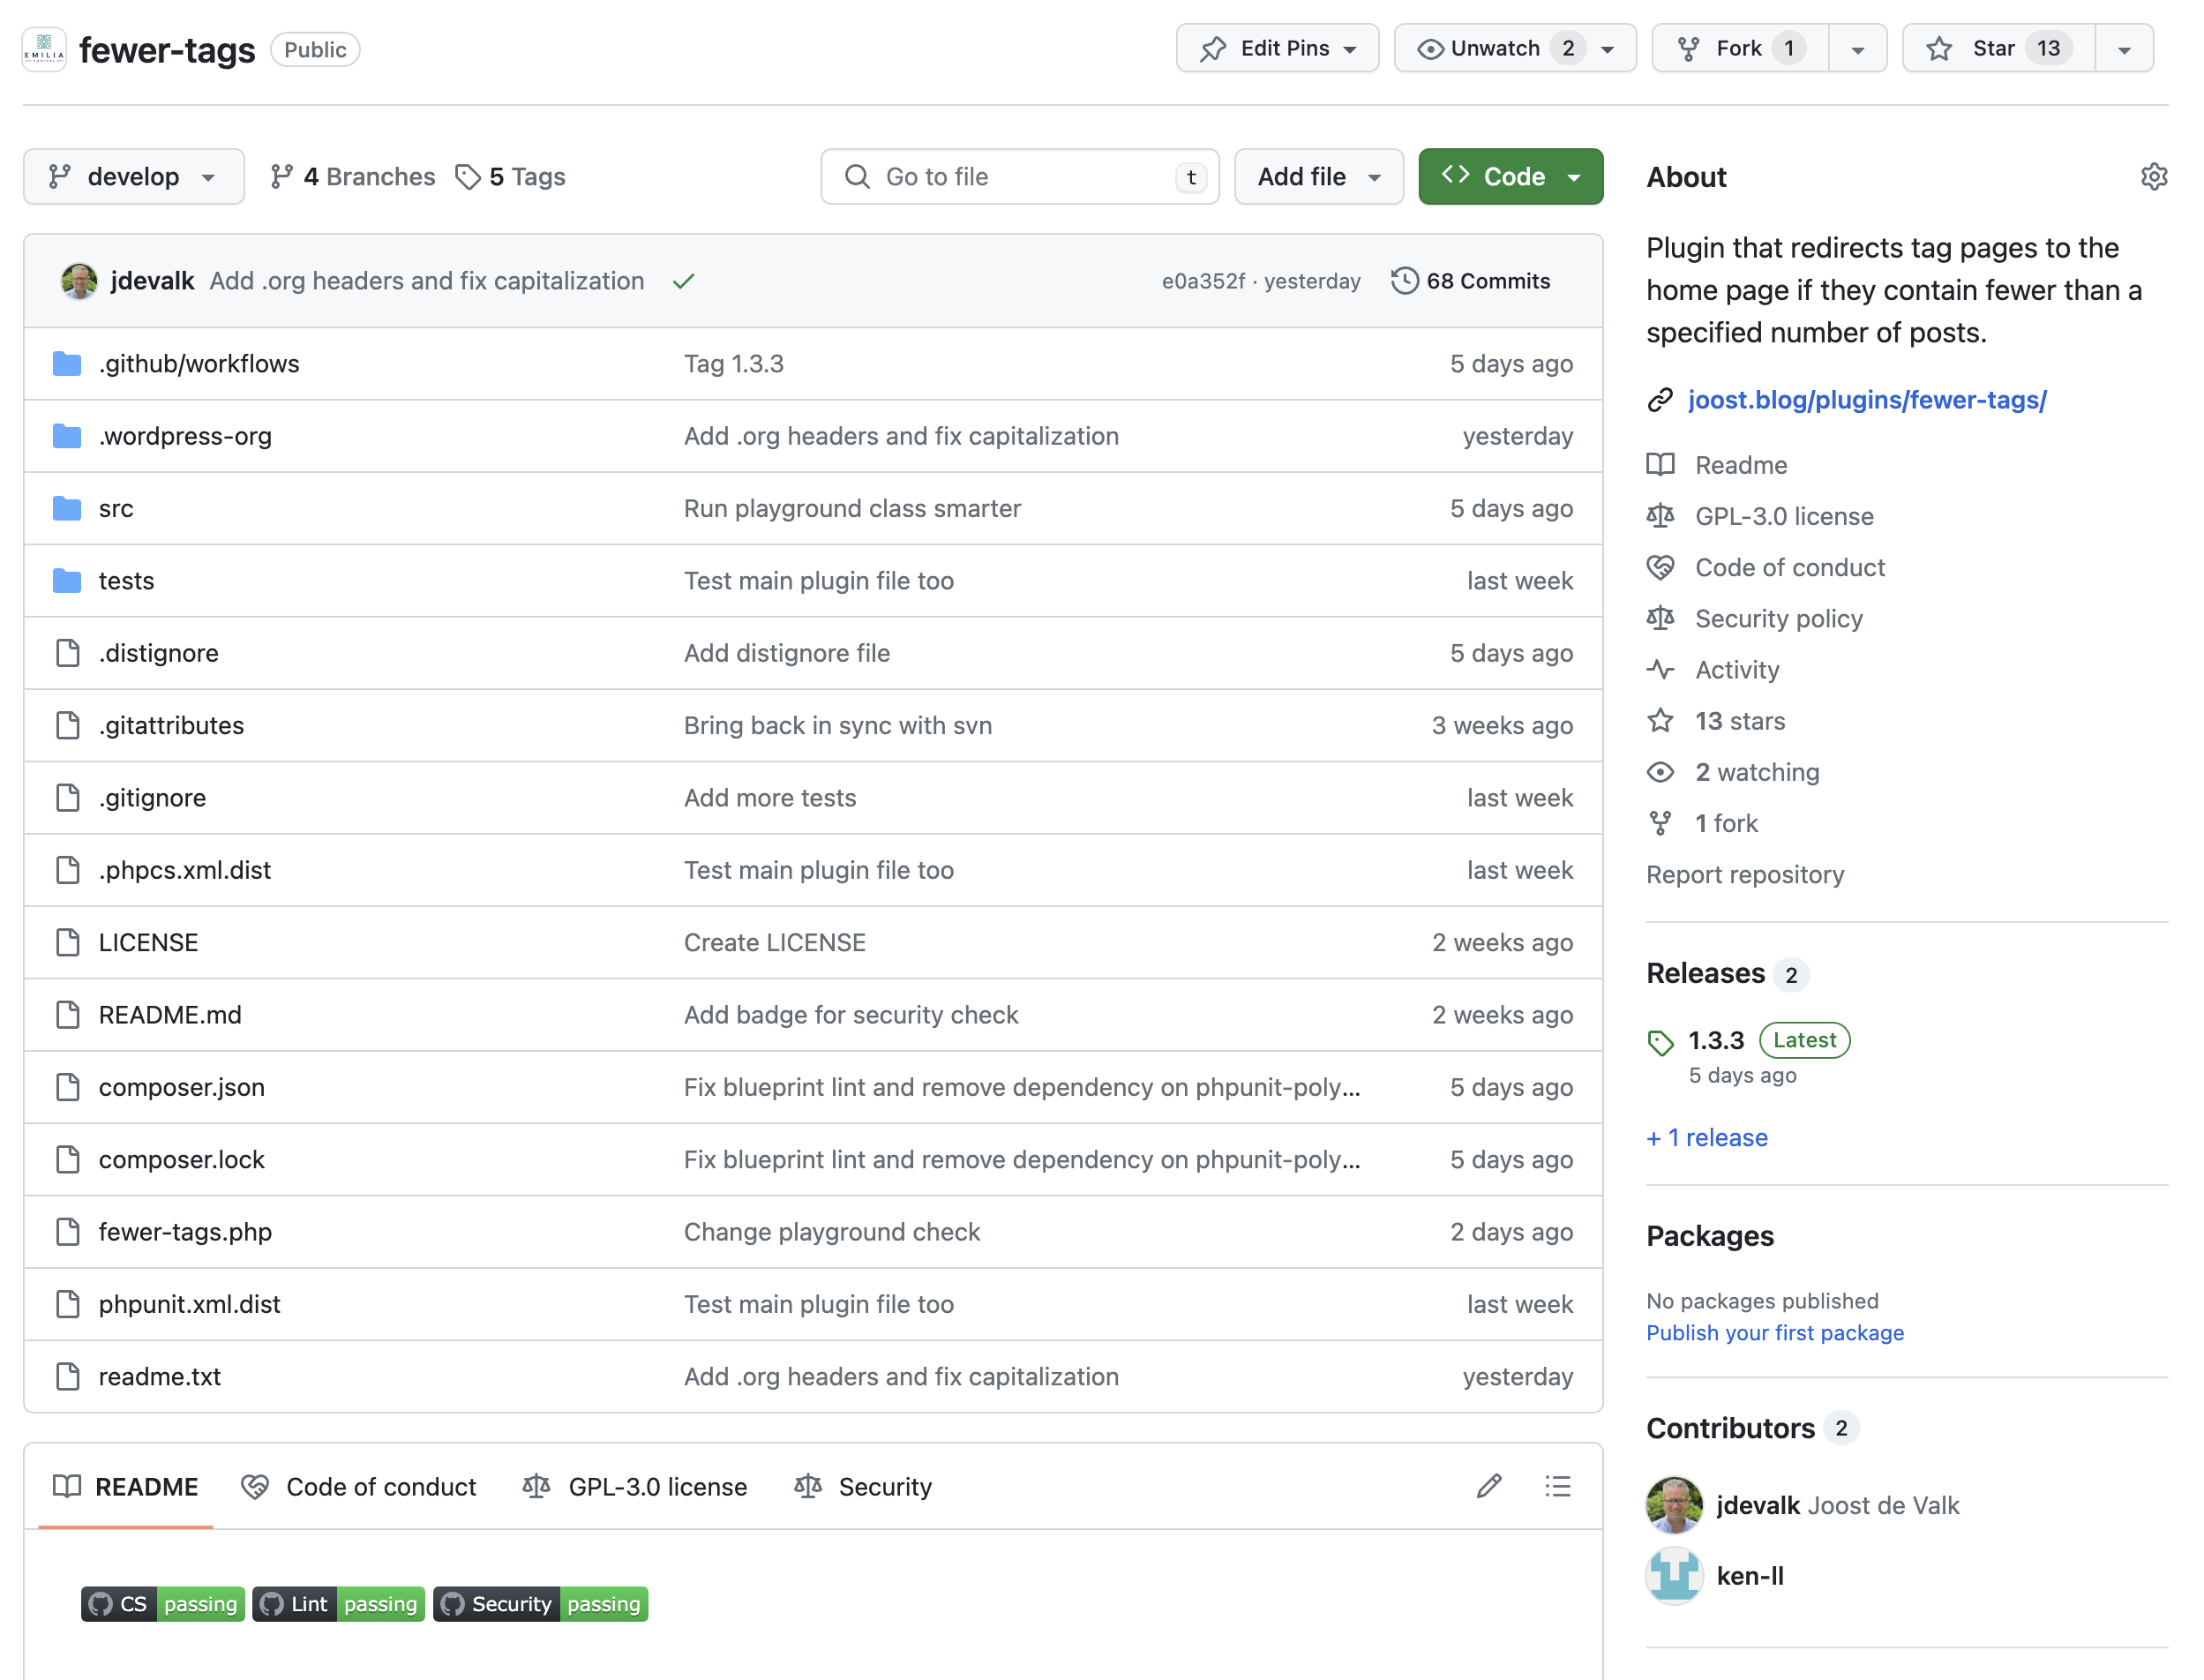
GitHub is synonymous with open-source development, and the drone industry has greatly benefited from this model. Many foundational drone technologies, such as flight controller firmware (e.g., ArduPilot, PX4), ground control station software (e.g., QGroundControl), and simulation platforms, originated and thrive as open-source projects hosted on GitHub. These repositories allow a global community of developers, researchers, and hobbyists to collaborate on complex projects.
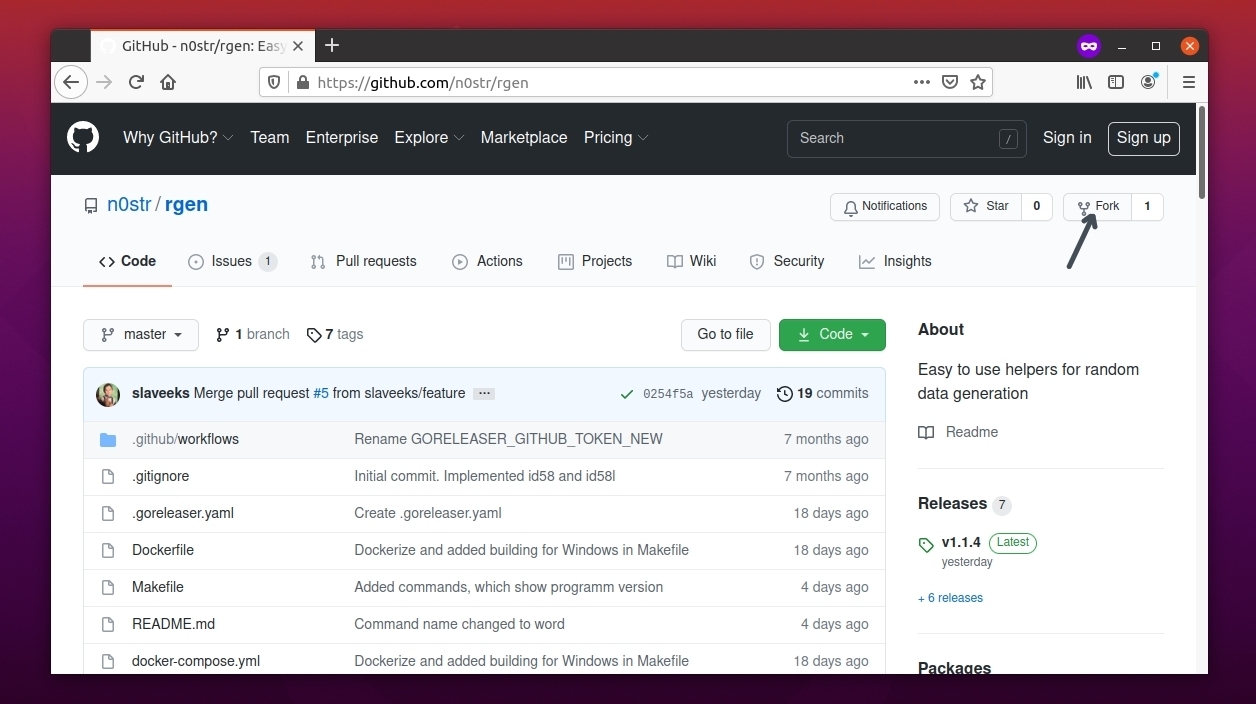
Anyone can “fork” an open-source drone project’s repository, creating their copy to experiment, add features, or fix bugs. If their contributions are valuable, they can submit a pull request back to the original project, potentially having their work integrated into the main codebase. This decentralized, community-driven approach accelerates innovation, democratizes access to advanced drone technology, and leads to more robust, secure, and feature-rich systems than proprietary solutions alone could often achieve. From enhancing autonomous flight capabilities to developing novel remote sensing applications, GitHub repositories are the collaborative engines driving the future of drone tech.