
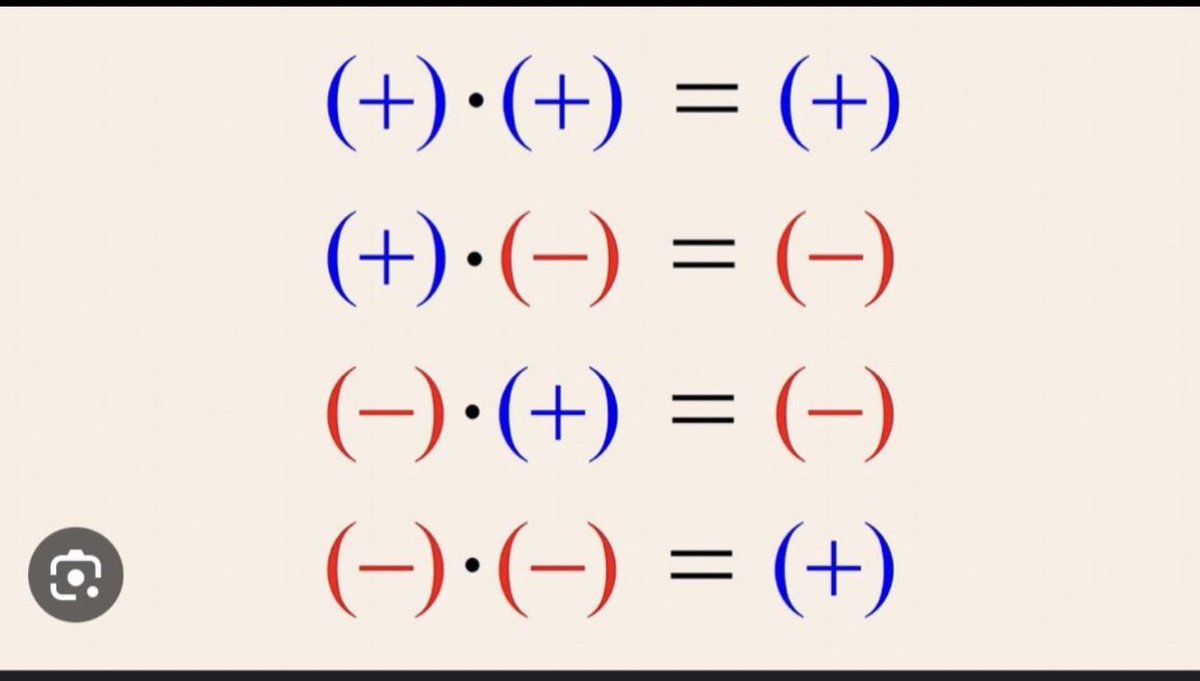
At first glance, “what is -7 minus -10” appears to be a rudimentary mathematical query, a simple exercise in integer subtraction. Yet, in the complex world of flight technology, such seemingly straightforward arithmetic operations represent the bedrock upon which sophisticated autonomous flight, precision navigation, and unwavering stability are built. This seemingly basic equation, which yields the value ‘3’, encapsulates a fundamental principle: the continuous calculation of deltas, deviations, and adjustments that empower unmanned aerial vehicles (UAVs) to operate with unparalleled accuracy and reliability. Far from a trivial sum, this ‘3’ symbolizes a critical output from the myriad algorithms that govern a drone’s every movement, illustrating the constant computational effort required to maintain its desired state in a dynamic environment.
The Foundational Calculus of Drone Control Systems
The inner workings of a drone are a symphony of sensors, microprocessors, and actuators, all orchestrated by sophisticated flight control software. At the heart of this orchestration lies the relentless processing of numerical data, often involving calculations that, in their essence, resemble the simple problem of “-7 minus -10”. This particular operation, resulting in ‘3’, represents a crucial differential value – a quantifiable difference between two states or parameters. This ‘3’ is not an arbitrary number but a vital piece of information that the flight controller constantly computes and acts upon, determining everything from a subtle change in motor thrust to a significant alteration in flight path.
Interpreting Deviations and Offsets in Real-time
Consider the ‘ -7 ‘ and ‘ -10 ‘ as representations of measured deviations or desired offsets within a drone’s operational parameters. For instance, ‘ -7 ‘ might signify an instantaneous measurement from a gyroscope indicating a negative pitch angle of 7 degrees from the horizontal, or a lateral displacement of 7 centimeters to the left of a target path. ‘ -10 ‘, in this context, could represent a reference value: a pre-programmed bias that needs to be compensated for, a desired offset for a specific maneuver, or even a previously observed deviation that serves as a comparative baseline.
The operation ‘(-7) minus (-10)’ then calculates the relative change or the net adjustment needed. If ‘ -7 ‘ is the current observed error and ‘ -10 ‘ is a known, consistent system bias that the flight controller must factor in, then the result of ‘3’ represents the true, uncompensated error. This ‘3’ is the anomaly that remains after accounting for the expected bias, indicating precisely what needs to be actively corrected by the drone’s systems. For example, if a drone’s camera gimbal consistently reports a -10 degree pitch due to its mounting angle, but a sensor reports a -7 degree pitch for the entire drone, the flight controller knows the drone itself is only 3 degrees off the target, not -7, relative to the gimbal’s perspective. This sophisticated differential analysis allows the system to distinguish between inherent system characteristics and actual flight deviations, leading to far more precise control.
The Role of Differential Values in PID Control Loops
The concept of differential values is absolutely critical to the Proportional-Integral-Derivative (PID) controller, the cornerstone of almost all modern flight control systems. A PID controller continuously calculates an “error value” as the difference between a desired setpoint and a measured process variable. The output from the PID controller then drives the actuators (e.g., motor speeds) to reduce this error.
The ‘3’ derived from “-7 minus -10” can directly inform one or more components of the PID loop:
- Proportional (P) Term: While the P-term typically responds directly to the current error (e.g., -7), the ‘3’ could represent a refined error value after subtracting a known offset (-10). This ensures the proportional response is based on the true deviation, not one influenced by a constant bias.
- Derivative (D) Term: The D-term responds to the rate of change of the error. If ‘ -10 ‘ was the error at time t1 and ‘ -7 ‘ is the error at time t2, then the change in error is (-7) – (-10) = 3. This ‘3’ now represents the rate at which the error is increasing or decreasing over a specific time interval. A positive ‘3’ indicates the error is decreasing, providing valuable predictive information for dampening oscillations and ensuring smooth, stable flight by anticipating future errors.
This continuous feedback and adjustment, driven by such precise differential calculations, is what allows drones to hover motionless in gusty winds, execute intricate maneuvers, and maintain stability despite external disturbances.
Advanced Navigation: From Raw Data to Precise Trajectories

Navigational accuracy is paramount for drones, especially in autonomous missions, mapping, and package delivery. Here, the mathematical principle of “-7 minus -10” takes on new dimensions, enabling the fusion of diverse sensor data to overcome inherent limitations and achieve centimeter-level precision.
Fusing Multi-Sensor Inputs for Enhanced Positional Awareness
Modern drones integrate a multitude of navigation sensors: GPS (Global Positioning System), IMUs (Inertial Measurement Units comprising accelerometers and gyroscopes), magnetometers, barometers, vision-based sensors (visual odometry), and even LiDAR. Each of these sensors provides data with its own set of accuracies, biases, and vulnerabilities. The challenge lies in fusing this disparate information into a single, coherent, and highly accurate estimate of the drone’s position and orientation.
Imagine ‘ -7 ‘ as a positional error reported by a standard GPS receiver, indicating a deviation of 7 meters from the true position. Now, consider ‘ -10 ‘ as a correction value provided by a Real-Time Kinematic (RTK) or Post-Processed Kinematic (PPK) system from a ground base station, which might indicate a systematic offset or a more accurate estimate of a particular error component. The calculation ‘ -7 minus -10 ‘ yields ‘3’, which represents the residual error after applying the RTK/PPK correction. This ‘3’ signifies the remaining positional uncertainty that still needs to be accounted for, perhaps by integrating data from visual odometry or an IMU. By performing these differential calculations across multiple sensor streams, the drone’s navigation filter (e.g., an Extended Kalman Filter) can continuously refine its positional estimate, moving from meter-level accuracy to centimeter or even millimeter precision.
Predictive Guidance for Autonomous Operations
Autonomous flight mandates not just current positional awareness but also the ability to predict future states and proactively adjust trajectories. The calculation of “-7 minus -10” can be conceptualized in this predictive realm as well. If a drone is following a pre-planned route, and at a certain waypoint, its predictive model forecasts a deviation of ‘ -7 ‘ units along a specific axis due to anticipated wind conditions. Simultaneously, real-time feedback from the environment or an updated obstacle map indicates that a slightly different adjustment is actually required, perhaps equivalent to ‘ -10 ‘ units for optimal path clearance or energy efficiency. The differential ‘3’ then becomes the dynamic adjustment factor, informing the flight path planning algorithm how much additional correction is needed beyond the initial prediction. This iterative refinement, based on real-time differential calculations, ensures that the drone always adheres to the safest and most efficient flight path, adapting seamlessly to changing conditions.
Enhancing Stability and Responsiveness in Dynamic Environments
The ability of drones to operate reliably in dynamic environments – battling strong winds, compensating for payload shifts, or navigating complex airspaces – is a testament to the sophistication of their flight technology. The constant calculation of small, critical differences, exemplified by “-7 minus -10”, is fundamental to this adaptability.
Adaptive Flight Algorithms and Environmental Compensation
Flight algorithms are not static; they are designed to adapt. If a drone encounters a persistent crosswind causing a roll angle deviation of ‘ -7 ‘ degrees, its adaptive algorithms will monitor this. If, through internal models or previous flight experience, the system understands that to truly counteract such a force effectively, a baseline corrective input equivalent to ‘ -10 ‘ (e.g., specific motor thrust differentials) is usually required, then the calculation of ‘ -7 minus -10 ‘ resulting in ‘3’ becomes crucial. This ‘3’ represents the additional, dynamic adjustment needed beyond the expected baseline compensation. It tells the flight controller that the current conditions require an extra 3 units of counter-force or attitude adjustment to maintain the desired orientation, illustrating the system’s ability to fine-tune its response to specific environmental challenges. This continuous process of measuring, comparing, and differentially adjusting is what enables drones to fly smoothly even in turbulent conditions.
Real-time Diagnostics and Anomaly Detection
Beyond active control, these differential calculations also play a vital role in real-time diagnostics and anomaly detection. If a drone’s expected motor RPM deviation under a specific load is ‘ -10 ‘, but sensor telemetry consistently reports ‘ -7 ‘, the difference of ‘3’ can be a critical flag. While ‘3’ might seem small, a consistent deviation could indicate an emerging issue such as bearing wear, propeller damage, or a motor imbalance. The flight controller, by continuously calculating these differentials, can detect subtle shifts in performance, trigger alerts for maintenance, or even initiate autonomous safety protocols before a minor issue escalates into a critical failure. Thus, the seemingly simple arithmetic of “what is -7 minus -10” underpins the robust health monitoring and predictive maintenance capabilities that are increasingly integrated into advanced drone platforms.
In conclusion, the seemingly abstract mathematical problem of “what is -7 minus -10” transcends its basic arithmetic solution in the context of flight technology. It serves as a powerful metaphor for the intricate, continuous differential calculations that are indispensable for achieving stability, precision navigation, and adaptive performance in modern drones. Every ‘3’ derived from countless such operations represents a critical adjustment, a refined data point, or a vital diagnostic insight, collectively empowering UAVs to push the boundaries of autonomous flight.