
The intricate dance of autonomous flight, the precision of a drone’s stabilization, and the rapid response of its control systems are all underpinned by sophisticated engineering, much of which operates at the lowest levels of software. While high-level languages like C++ or Python dominate many aspects of modern software development, the foundational core of flight technology – particularly within embedded systems – often touches upon assembly language. Here, every byte, every clock cycle, and every memory address matters. Within this crucial realm, the dollar sign ($) is not a symbol of currency but a powerful reference point, signifying the current program counter (PC) or the address of the instruction being assembled. Understanding its role is key to comprehending how ultra-efficient, real-time code drives the cutting edge of flight technology.
The Imperative of Precision: Assembly Language in Flight Technology
The world of drones and advanced flight systems demands uncompromising precision, speed, and resource efficiency. Every millisecond counts for maintaining stable flight, executing complex maneuvers, and responding to dynamic environmental conditions. This stringent requirement pushes developers towards optimization techniques that sometimes necessitate a dive into assembly language, the most fundamental programming language directly intelligible by a computer’s processor.
Microcontrollers and Real-time Operations
At the heart of every drone lies a flight controller, typically powered by a high-performance microcontroller. These tiny computers are responsible for a myriad of real-time tasks: reading sensor data (gyroscopes, accelerometers, magnetometers, barometers, GPS), executing PID (Proportional-Integral-Derivative) control algorithms to stabilize the aircraft, controlling electronic speed controllers (ESCs) to regulate motor speeds, and processing commands from the remote pilot or autonomous navigation systems. Each of these operations must occur within strict timing constraints to ensure stable and predictable flight. Any significant delay or inefficiency can lead to instability, reduced performance, or even catastrophic failure.
The Need for Speed and Efficiency
While modern compilers for C/C++ are highly optimized, there are specific scenarios where direct assembly language manipulation offers advantages. These often involve:
- Critical Timing: Operations that require exact cycle counts or extremely low latency, such as precise pulse-width modulation (PWM) generation for motors or bit-banging communication protocols.
- Hardware Interfacing: Directly manipulating hardware registers without the overhead introduced by higher-level language abstractions.
- Resource Constraints: On microcontrollers with very limited RAM or Flash memory, assembly can produce significantly smaller code footprints.
- Bootloaders: The initial code that runs when a microcontroller powers on, often written in assembly to ensure minimal dependencies and direct hardware setup.
- Interrupt Service Routines (ISRs): Time-critical routines that respond to hardware events (like a sensor data ready interrupt) are sometimes optimized at the assembly level for minimal context switching overhead.
In these contexts, understanding assembly language and its intrinsic symbols becomes invaluable for engineers pushing the boundaries of flight performance and reliability.
Unpacking the Dollar Sign: The Program Counter’s Alias
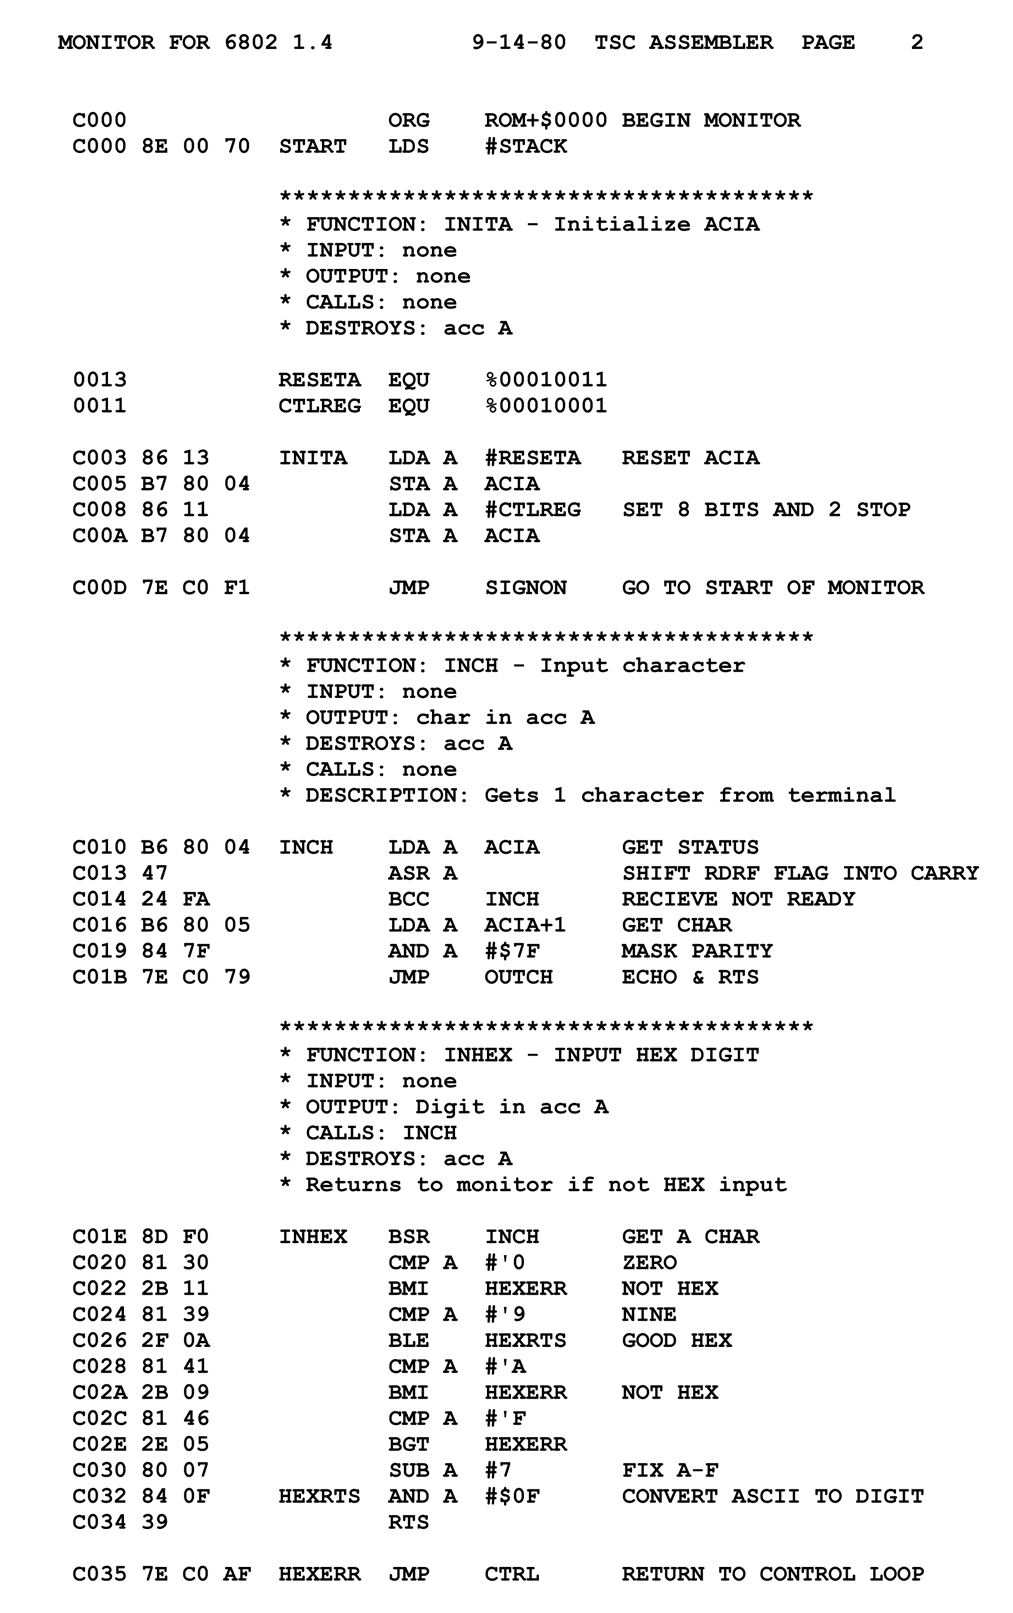
In assembly language programming, the dollar sign ($) is a special symbol used to represent the current address during the assembly process. Specifically, it refers to the address of the instruction currently being assembled. This might seem abstract, but its utility is profound, particularly when dealing with program flow and memory management in embedded systems.
Relative Addressing and Program Flow
The primary application of $ is in relative addressing. Instead of specifying an absolute memory address for a jump or a data reference, one can specify an offset relative to the current instruction. For example, an instruction like JMP $+10 would tell the processor to jump to an address 10 bytes (or words, depending on the architecture) forward from the current instruction. Similarly, JMP $-6 would jump 6 bytes backward.
This relative addressing is critical for several reasons in flight technology:
- Compact Code: Relative jumps often require fewer bits to encode than absolute jumps, saving precious memory space.
- Branch Prediction: On some architectures, processors can predict relative branches more effectively, leading to faster execution.
- Position-Independent Code: This is perhaps the most significant benefit for embedded systems. If the code is designed using relative addressing, it can be loaded and executed from any memory location without needing to be recompiled or relocated. This capability is vital for flexible firmware updates, modular code, and bootloaders.
Consider a flight controller’s firmware that needs to dynamically load a specific control module. If that module is position-independent, it can be placed anywhere in memory, and its internal jumps and data accesses will still function correctly relative to its loaded base address. The $ symbol facilitates the creation of such flexible and robust code.
Position-Independent Code (PIC) for Flexible Firmware
Position-Independent Code (PIC) is a cornerstone of robust embedded systems, especially those in flight technology that might require over-the-air updates or modular firmware components. When an assembly routine uses $ for jumps or data references, the resulting machine code does not hardcode absolute memory addresses. Instead, it encodes offsets from the current instruction.

This means that a block of code built with PIC principles can be loaded into different memory segments without modification. For example, a bootloader might load the main flight control firmware into RAM. If this firmware is PIC-compliant, it doesn’t matter where in RAM it’s loaded; all its internal jumps and memory accesses, using $, will correctly resolve relative to its current execution point. This flexibility is paramount for sophisticated drone platforms that feature complex operating systems or dynamically loaded modules for advanced features like AI-powered navigation or specialized sensor processing.
Strategic Implementations: Where “$” Powers Drone Systems
The practical application of the $ symbol, and assembly language in general, is most evident in the foundational layers of drone flight technology where direct hardware interaction and absolute performance are non-negotiable.
Bootloaders and Firmware Initialization
The bootloader is the very first piece of code that executes when a flight controller powers on. Its job is to initialize essential hardware components, set up the memory map, and then load and execute the main flight firmware. Bootloaders are almost universally written with significant portions in assembly language for maximum control, minimal footprint, and direct hardware access.
Within a bootloader, $ is frequently used for:
- Self-modifying code: Though less common now, historically used for specific optimizations.
- Jump tables: Efficiently dispatching to different routines based on initial conditions, often using relative jumps.
- Relocating code: The bootloader might relocate a section of itself or the main firmware from Flash to RAM for faster execution, and
$helps ensure that the relocated code still functions correctly relative to its new base.
Critical Control Loops and Interrupt Service Routines
While the bulk of PID control loops in modern flight controllers are written in C/C++, certain extremely time-critical sections or highly optimized inner loops might benefit from assembly. Similarly, Interrupt Service Routines (ISRs) – small, fast pieces of code that respond to hardware events (like a timer expiring or a new sensor reading being available) – are prime candidates for assembly optimization.
In an ISR, $ might be used to:
- Fast context saving/restoring: Minimizing the overhead of saving and restoring processor registers.
- Atomic operations: Ensuring that a sequence of operations completes without interruption, crucial for data integrity in multi-tasking environments.
- Jumping to specific handlers: Efficiently dispatching to the correct event handler, potentially using relative jumps.
The efficiency gained here directly translates to improved flight stability and faster response times for the drone. A more responsive control loop means the drone can correct for disturbances more quickly, leading to smoother, more precise maneuvers.
Sensor Interfacing and Data Acquisition
Interacting with complex sensors (IMUs, GPS modules, LiDAR, etc.) often involves precise timing and direct manipulation of communication buses (SPI, I2C, UART). While C libraries exist, performance-critical drivers or very specific bit-banging implementations might leverage assembly. $ can be used here to:
- Create tightly timed delays: Ensuring correct protocol timing for sensor communication.
- Access memory-mapped registers: Directly reading or writing to sensor control registers, with references relative to the current code block.
By optimizing these low-level interactions, the flight controller can acquire sensor data more rapidly and reliably, providing the most up-to-date information for its stabilization and navigation algorithms.
Beyond Optimization: Understanding the Core of Autonomous Flight
While the direct writing of extensive assembly code has diminished with powerful compilers, understanding assembly language – and symbols like $ – remains a powerful tool for engineers operating in the flight technology domain. It offers insights that go beyond mere optimization.
Debugging and Deep System Insights
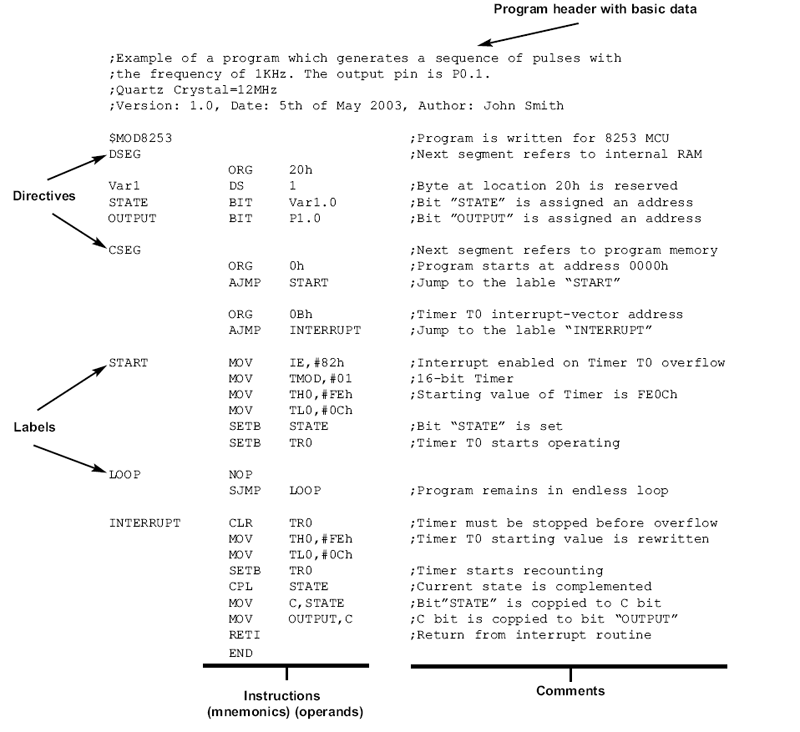
When a complex drone system exhibits unexpected behavior, especially at the hardware-software interface, the ability to inspect the disassembled machine code can be invaluable. Engineers who understand assembly can interpret processor instruction streams, pinpoint exact execution paths, analyze memory access patterns, and identify subtle bugs that higher-level debuggers might obscure. Understanding how $ dictates relative addresses helps in tracing program flow through firmware, offering a deeper understanding of the system’s runtime behavior. This is crucial for diagnosing critical issues that could affect drone reliability and safety.
Future-Proofing and Hardware Interoperability
As new microcontrollers and specialized processing units emerge for flight control (e.g., dedicated AI accelerators for on-board vision processing), familiarity with their assembly instruction sets and architectural nuances becomes beneficial. Concepts like $ for relative addressing are fundamental and apply across different processor architectures. Engineers with this low-level knowledge are better equipped to integrate new hardware, write efficient drivers, and adapt existing firmware to evolving technological landscapes. This foundational understanding ensures that flight technology can continue to innovate, leveraging the full potential of new hardware while maintaining the robust, real-time performance that is non-negotiable for safe and effective autonomous flight. The dollar sign, therefore, is not just a quirky relic but a symbol representing a deep, foundational understanding critical for pushing the boundaries of what drones can achieve.