
In the rapidly evolving landscape of drone technology, where innovation drives capabilities from autonomous navigation to advanced remote sensing, understanding fundamental technical metrics is paramount. Among these, Round-Trip Time, universally abbreviated as RTT, stands as a critical indicator of communication efficiency and responsiveness. Far from being a mere network diagnostic, RTT profoundly influences the performance, reliability, and ultimately, the operational success of cutting-edge drone applications that push the boundaries of aerial technology. It dictates the speed at which a drone can receive commands, transmit vital sensor data, and react to its dynamic environment, shaping everything from the fluidity of AI-driven cinematic movements to the precision of complex industrial inspections.

Decoding Round-Trip Time (RTT) in Drone Technology
At its core, RTT measures the total time it takes for a signal or a data packet to travel from a sender to a receiver and then for an acknowledgment of that packet to return to the original sender. In the context of drone operations, this journey typically spans from the ground control station (GCS) or remote controller to the drone itself, and back again. This seemingly simple metric encapsulates a complex interplay of factors including signal propagation delay, processing time at both ends, and network congestion. While often discussed in general computing or networking contexts, its implications for drone technology are uniquely profound, especially as drones transition from basic human-piloted tools to sophisticated, intelligent, and autonomous systems.
For advanced drone operations that fall under the umbrella of Tech & Innovation, such as AI follow modes, fully autonomous missions, intricate mapping projects, and precise remote sensing, low RTT is not merely desirable; it is absolutely essential. High RTT translates directly into latency, a delay that can cascade through the entire operational chain, degrading real-time responsiveness, undermining precision, and potentially compromising safety. Imagine an autonomous drone needing to instantaneously detect and avoid an unexpected obstacle; a high RTT would mean the command to swerve arrives too late. Similarly, for sophisticated AI algorithms governing flight or data capture, timely data exchange is the lifeblood of their effectiveness. The pursuit of lower RTT is thus a constant endeavor, foundational to unlocking the full potential of future drone capabilities and ensuring their seamless integration into various industrial and technological ecosystems.
RTT’s Crucial Role in Autonomous Flight and AI Integration
The ability of a drone to operate autonomously or to leverage sophisticated artificial intelligence (AI) features is directly proportional to its capacity for rapid, reliable communication. RTT serves as the invisible tether that connects onboard intelligence with ground-based computation and human oversight, dictating the agility and accuracy of these advanced functions.
Autonomous Navigation and Control
For drones engaged in autonomous flight, RTT is a non-negotiable factor. Autonomous systems rely heavily on a continuous feedback loop: sensors on the drone gather data about its environment (position, velocity, obstacles, atmospheric conditions), this data is processed (either onboard or at a ground station), and then control commands are generated and transmitted back to the drone. A high RTT introduces a critical lag in this cycle. If the RTT is too long, the drone’s understanding of its environment becomes outdated by the time it receives instructions, leading to delayed reactions, less precise path adjustments, and increased risk of collision or deviation from the intended trajectory.
Consider an autonomous drone executing a complex inspection pattern around an intricate structure. If the RTT is high, the drone’s internal navigation system might perceive its position as slightly different from its actual, current location dueating to the delay in receiving updated GPS corrections or visual odometry cues. This discrepancy can result in inaccuracies in data acquisition points, or worse, cause the drone to graze obstacles it should have easily avoided. For truly robust and reliable autonomous operations, especially in dynamic or complex environments, the RTT must be minimized to ensure the drone’s decision-making process is based on the most current and accurate information available.
AI Follow Mode and Object Tracking
AI-powered features like “follow mode,” active object tracking, and gesture control are hallmarks of modern consumer and professional drones, offering intuitive and hands-free operation. These functionalities are profoundly susceptible to the adverse effects of high RTT. An AI follow mode, for instance, requires the drone’s onboard vision system to continuously identify and track a subject, predict its movement, and then adjust the drone’s flight path in real-time to maintain optimal positioning. The entire sequence—image capture, AI processing to identify the subject and compute its relative position, generation of flight commands, and transmission of those commands to the drone’s flight controller—must occur with minimal delay.
If the RTT is significant, the drone’s response to the subject’s movement will be noticeably lagged. The drone might follow behind the subject rather than keeping pace, or struggle to maintain a smooth, cinematic tracking shot. For fast-moving subjects, a high RTT can lead to the drone losing track entirely or making jerky, unnatural adjustments. Similarly, gesture control, which relies on the drone recognizing and responding to specific human hand movements, demands ultra-low RTT for a seamless and intuitive user experience. Any noticeable delay between a gesture and the drone’s action diminishes the effectiveness and appeal of the feature, highlighting RTT as a critical performance bottleneck for responsive, AI-driven drone capabilities.
RTT and the Efficacy of Remote Sensing and Mapping Operations
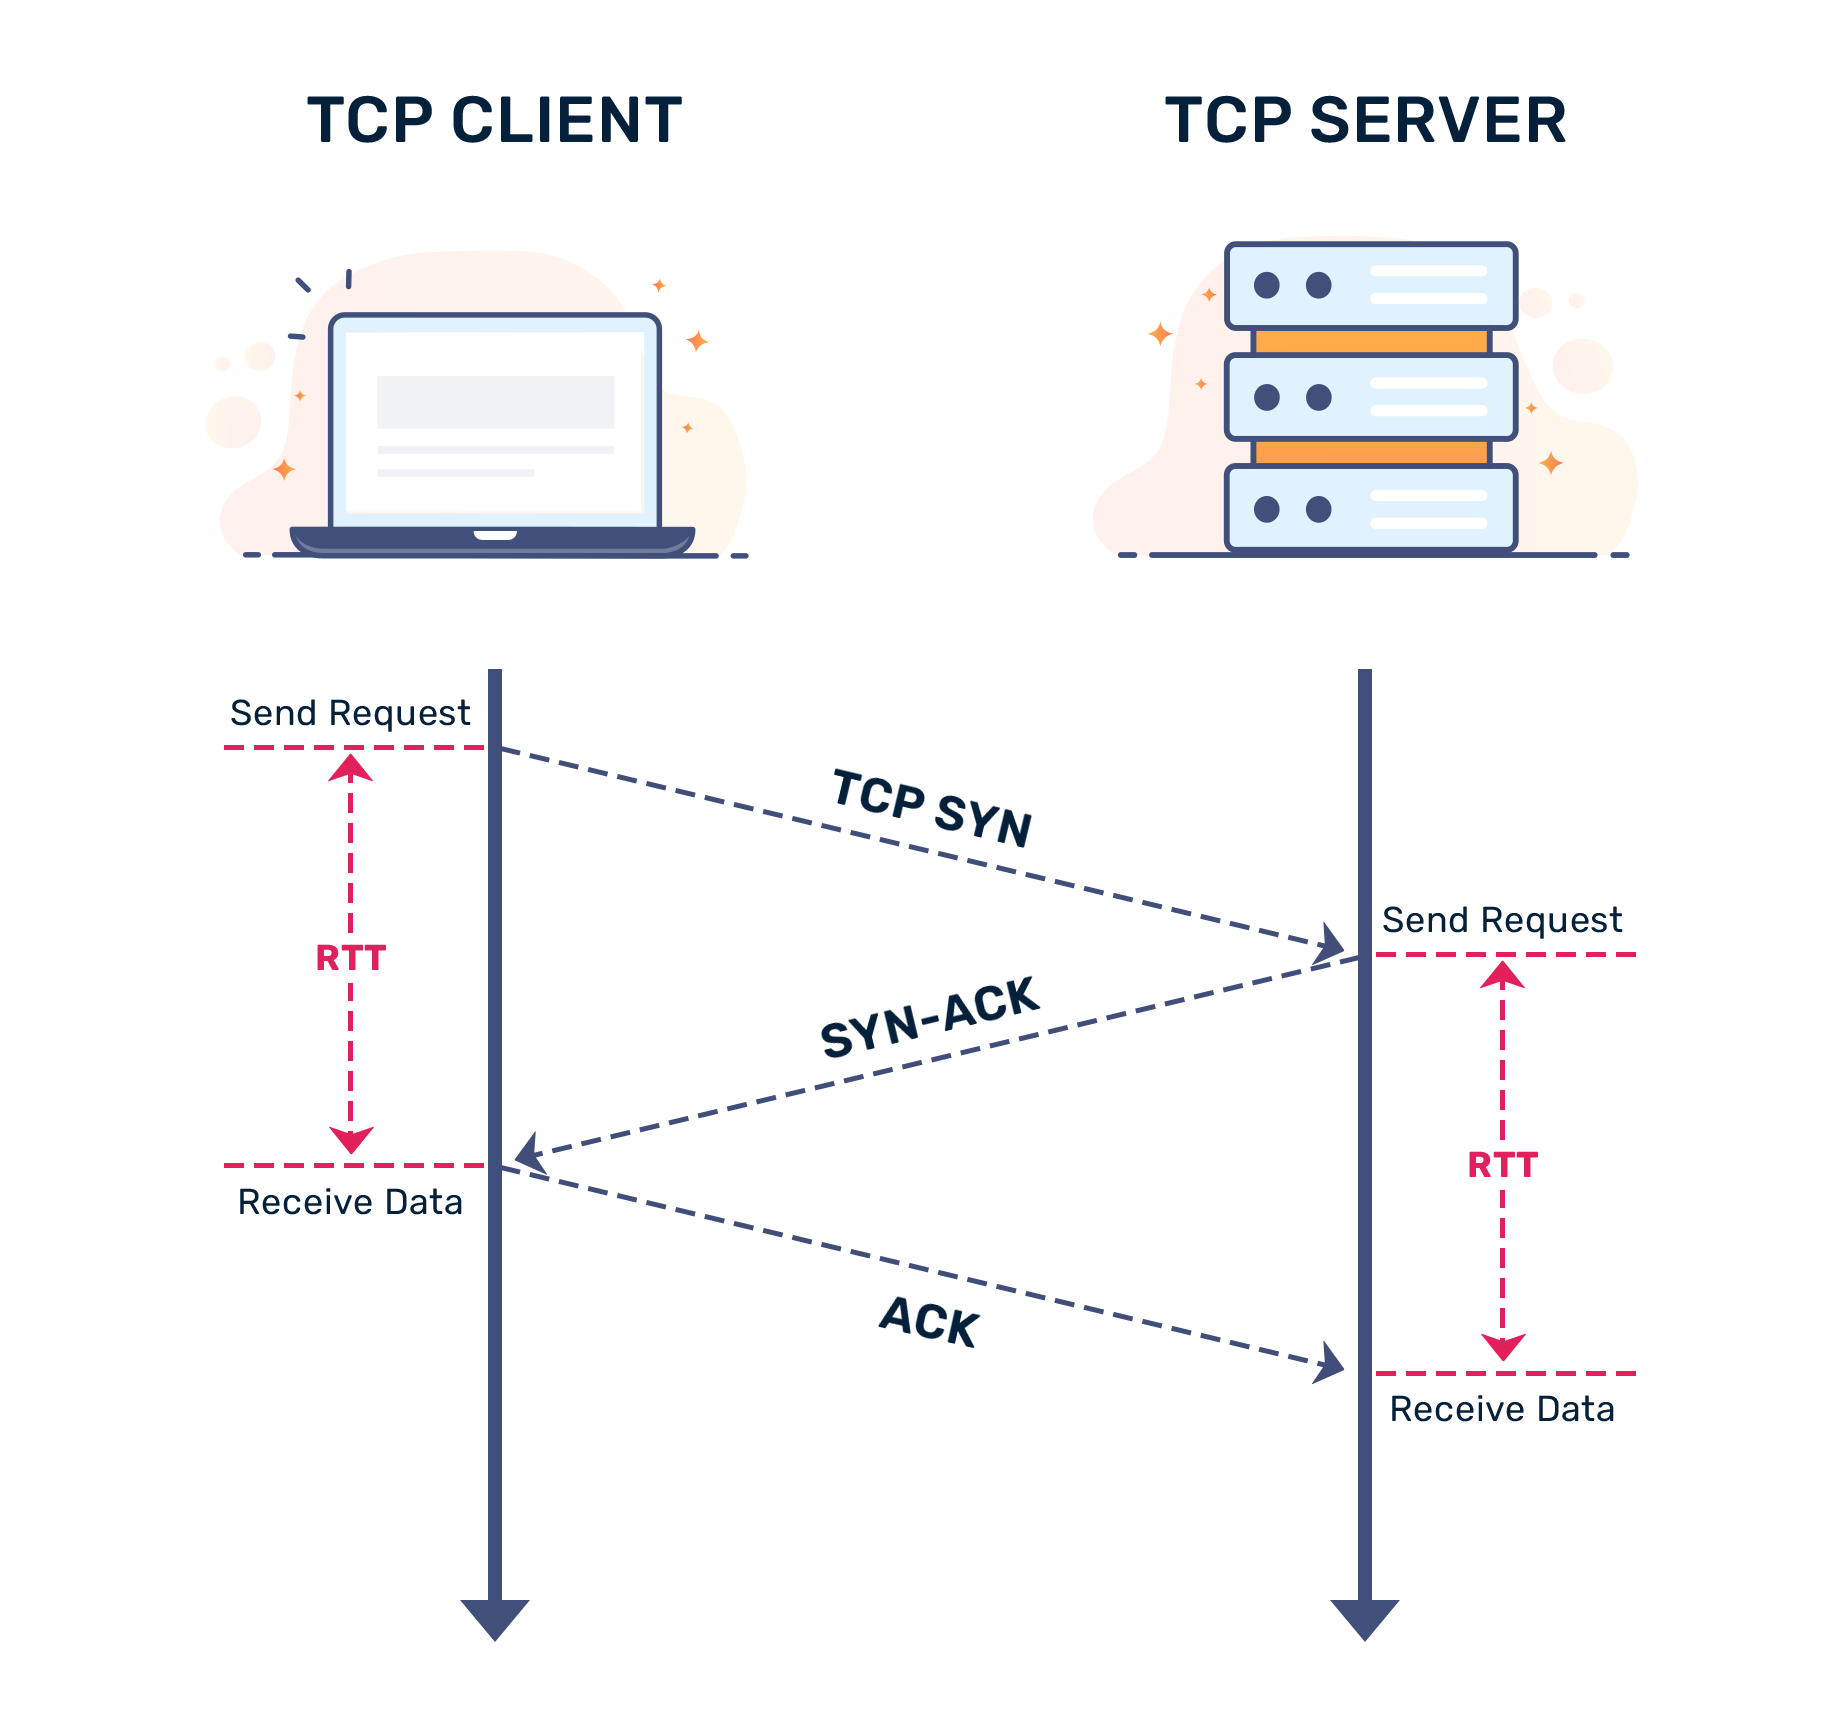
Remote sensing and mapping with drones have revolutionized industries from agriculture and construction to environmental monitoring and emergency response. The value of the data collected—whether for precision agriculture, volumetric measurements, or immediate disaster assessment—is often intrinsically linked to its timeliness. Here, RTT plays a pivotal role, influencing not just the speed of data acquisition but also the integrity and immediate utility of the insights derived.
Data Acquisition and Telemetry
Modern drones are equipped with an array of sophisticated sensors, including LiDAR scanners, multispectral cameras, thermal imagers, and high-resolution RGB cameras. For many remote sensing applications, the data gathered by these sensors needs to be transmitted back to a ground station for real-time analysis, quality control, or immediate decision-making. High RTT directly impacts the efficiency and reliability of this data telemetry. A prolonged RTT can mean delays in receiving critical sensor readings, which can be problematic in time-sensitive scenarios. For instance, in an emergency response situation where a drone is mapping a hazardous spill using thermal imaging, real-time data flow with minimal latency is crucial for rapidly assessing the situation and deploying ground teams safely.
Furthermore, RTT can affect the integrity of streamed data. While modern communication protocols incorporate error correction, high latency can exacerbate issues with packet loss, requiring retransmissions that further increase effective delay. This is particularly relevant for large datasets or continuous streams where data coherence is important for subsequent processing steps, such as stitching together panoramic images or creating seamless 3D models. Ensuring low RTT for data acquisition and telemetry is therefore fundamental to maximizing the practical utility and responsiveness of drone-based remote sensing missions.
Real-Time Mapping and 3D Modeling
The demand for real-time mapping and instantaneous 3D model generation from drone data is growing across various sectors. Applications like construction progress monitoring, live volumetric calculations for aggregate piles, or rapid damage assessment post-disaster all benefit immensely from the ability to process and visualize aerial data as it is being collected. For these tasks, low RTT is absolutely paramount.
When a drone is performing a mapping flight, it continuously captures imagery and geospatial data. For real-time mapping, this data needs to be quickly transmitted to a ground-based processing unit that can stitch images, generate orthomosaics, or build preliminary 3D point clouds on the fly. If the RTT is high, there will be a significant lag between the drone capturing an image and that image appearing on the ground station’s real-time map. This delay can hinder operators from identifying coverage gaps, adjusting flight paths dynamically to capture missed areas, or quickly verifying the quality of the incoming data. In scenarios like search and rescue, where minutes can save lives, the ability to generate a live, evolving map of a disaster zone with minimal RTT can be a game-changer, providing responders with an immediate and accurate overview of the operational environment.
Mitigating RTT: Strategies for Enhanced Drone Performance
The imperative to reduce RTT in drone operations is a driving force behind significant technological advancements. Achieving minimal latency requires a multi-faceted approach, encompassing improvements in communication protocols, strategic processing capabilities, and careful management of the drone’s operational environment.
Optimizing Communication Protocols
A primary strategy for lowering RTT involves the use of advanced and optimized communication protocols. Traditional Wi-Fi, while ubiquitous, often struggles with latency and range limitations when applied to drones. Specialized transmission technologies like DJI’s OcuSync and Lightbridge, or increasingly, cellular 5G for drones, are engineered to drastically reduce latency and increase bandwidth. These systems employ sophisticated modulation techniques, error correction codes, and dynamic frequency hopping to maintain a robust, low-latency link even in challenging environments. Efficient data compression algorithms are also critical, minimizing the size of data packets and thus the time required for their transmission. By reducing the amount of data that needs to traverse the air interface, and ensuring that what is transmitted is done so with minimal overhead, these protocols directly contribute to a lower RTT and a more responsive drone system.
Edge Computing and Onboard Processing
Processing data closer to its source, commonly known as edge computing, is a powerful technique for mitigating the impact of RTT, particularly for time-critical decision-making. Instead of transmitting all raw sensor data back to a ground station for processing and then sending commands back to the drone, certain computational tasks can be offloaded to powerful onboard processors. For instance, obstacle detection and avoidance algorithms can run entirely on the drone, allowing it to react instantaneously to immediate threats without waiting for round-trip communication with the GCS. Similarly, initial image analysis for object tracking or target identification can be performed onboard, sending only summarized or action-oriented data packets down to the ground. This reduces the dependency on a constant, low-latency link for every decision, effectively shrinking the “control loop” and making the drone more autonomous and responsive to its immediate surroundings, even if the communication RTT remains moderate for other, less critical data streams.
Network Infrastructure and Range Management
Beyond the drone itself, the quality of the overall network infrastructure and careful management of operational parameters significantly influence RTT. This includes selecting robust ground control station (GCS) equipment with high-gain, directional antennas that maintain a strong and stable link with the drone. The physical environment plays a critical role; factors like electromagnetic interference, line-of-sight obstructions, and atmospheric conditions can all degrade signal quality and increase RTT. Operators must plan flight paths to minimize these interferences, ensuring a clear communication channel. Furthermore, managing the drone’s operational range is crucial; pushing a drone to the very limits of its communication range inevitably leads to increased latency and signal degradation. Adhering to manufacturer recommendations for maximum effective range, or even operating well within these limits, helps maintain a consistently low RTT, ensuring reliable control and data transfer for even the most demanding technological applications.