
The modern era of drone technology, particularly in areas like autonomous flight, AI follow modes, mapping, and remote sensing, is defined by an intricate web of interacting systems and algorithms. Predicting the precise behavior and outcome of a drone operation, especially in dynamic environments, is paramount for safety, efficiency, and reliability. In this complex landscape, the metaphorical application of a “Punnett square” offers a compelling conceptual framework for understanding how various inputs combine to yield a spectrum of potential outcomes, allowing engineers and operators to systematically analyze, predict, and optimize performance. Far from its biological origins, this conceptual model helps to map the probabilistic results of system interactions, sensor data fusion, and algorithmic decision-making in advanced unmanned aerial vehicles (UAVs).
Unpacking Predictive Frameworks in Autonomous Systems
Autonomous drone operations are the culmination of numerous interdependent variables: sensor readings, environmental conditions, navigational algorithms, and control system parameters. Each of these elements contributes to the drone’s overall behavior, and their interplay can produce a wide range of outcomes, from flawless mission execution to unexpected deviations. The core challenge in developing robust autonomous systems lies in predicting these outcomes accurately and mitigating risks.
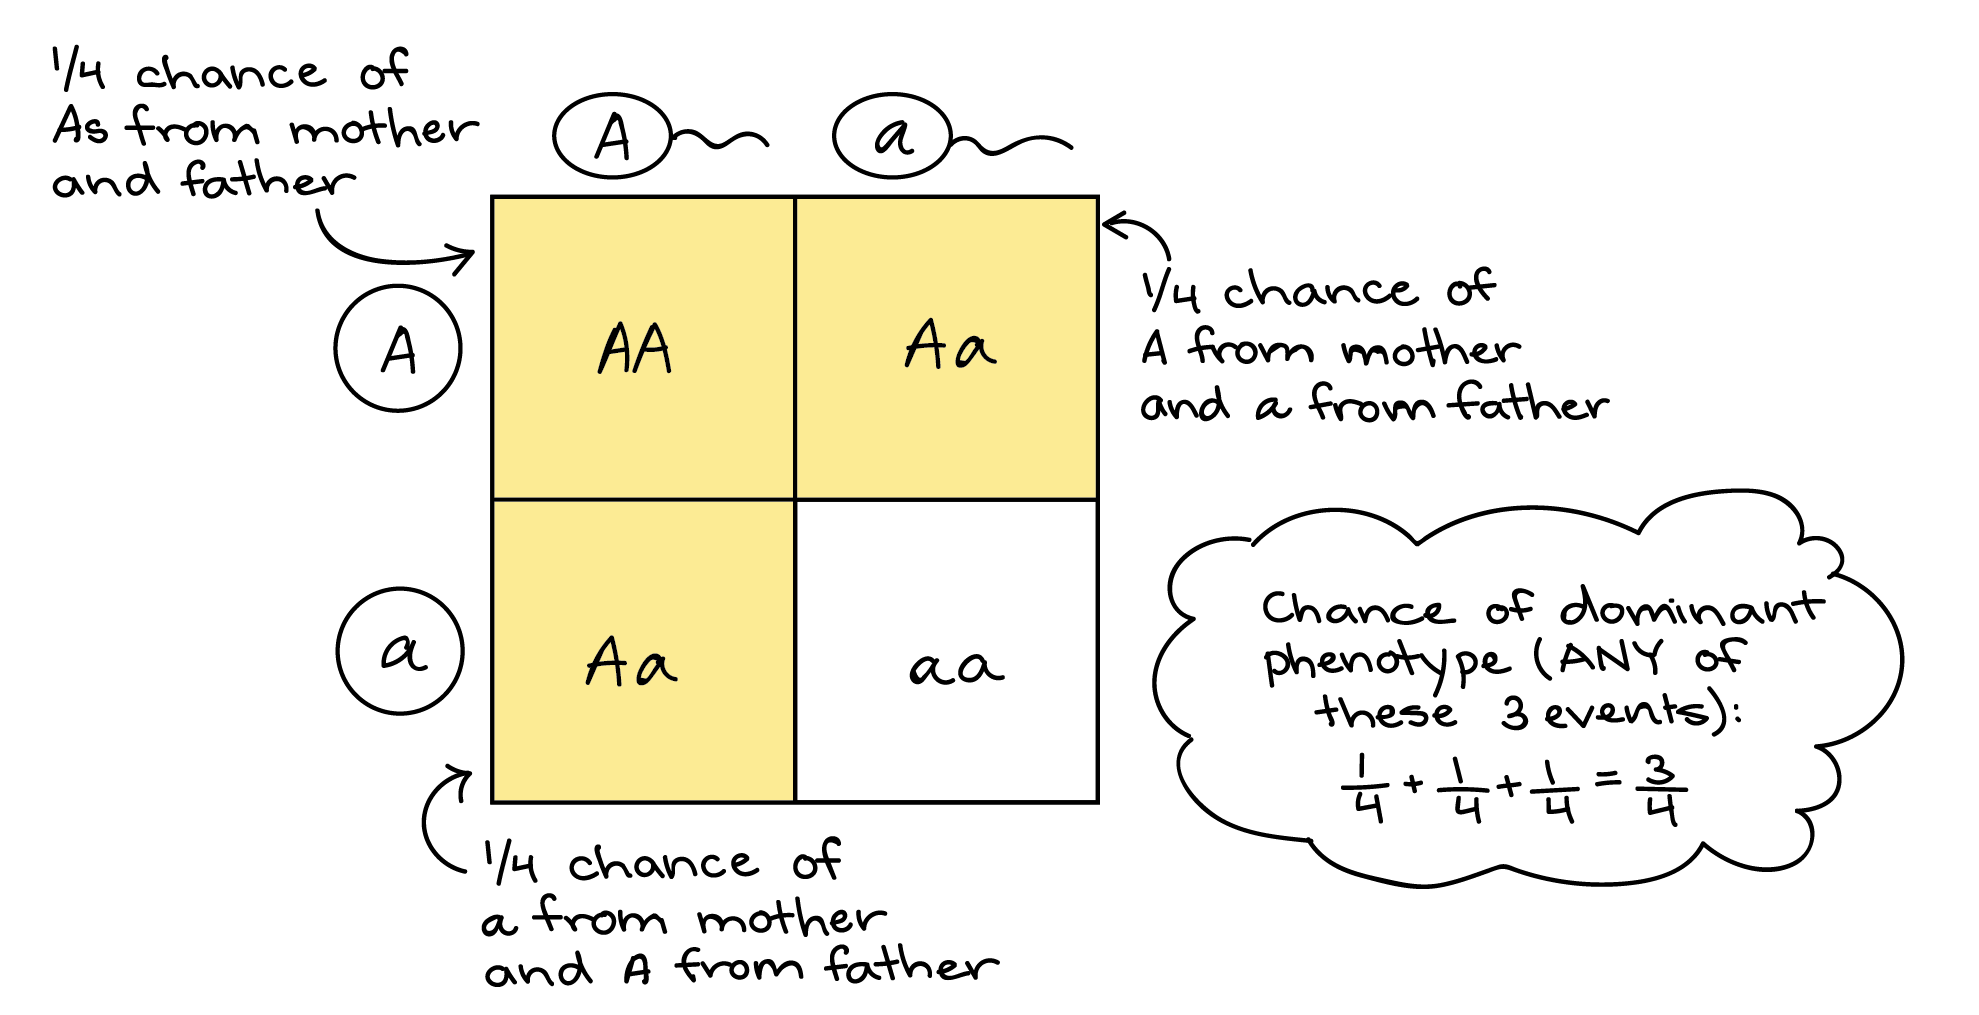
Conceptually, a “Punnett square” provides a grid-like structure for visualizing the combinations of discrete variables and their resultant probabilities. In drone tech, imagine the axes of this conceptual square representing different sets of input variables. For instance, one axis might represent variations in sensor data quality (e.g., high GPS accuracy vs. moderate GPS accuracy in a signal-denied environment), while the other axis could represent different algorithmic responses (e.g., aggressive path correction vs. conservative path correction). Each cell within this “Punnett square” then illustrates a specific combination of these inputs and the predicted outcome or probability of a particular system state.
This structured approach moves beyond simple cause-and-effect analysis, allowing for a more nuanced understanding of complex emergent behaviors. It highlights that a system’s resilience is not just about the quality of individual components but about how those components interact under various operational contexts. By systematically mapping these interactions, developers can identify critical failure points, optimize parameter settings, and design systems that are more adaptable and predictable. The ultimate goal is to move from reactive problem-solving to proactive, predictive engineering, building a deep understanding of how specific combinations of factors influence a drone’s performance in real-world scenarios.
Mapping System Interactions for Reliable Autonomy
The reliability of autonomous flight is heavily dependent on the harmonious interaction of various technological layers. From the low-level processing of raw sensor data to high-level mission planning, every decision point involves a confluence of inputs. Applying the Punnett square concept here helps to visualize how these combinations influence the probability of achieving mission objectives.
Sensor Fusion and Environmental Variables
Consider a drone operating in a challenging environment. Its ability to navigate autonomously relies on sensor fusion—integrating data from GPS, IMUs (Inertial Measurement Units), lidar, radar, and vision cameras. Each sensor has its own accuracy, latency, and susceptibility to environmental factors (e.g., GPS signal degradation in urban canyons, lidar interference from rain, visual obstructions from fog).
A conceptual Punnett square for sensor fusion might have one axis representing varying environmental conditions (e.g., clear sky, light fog, heavy rain) and the other axis representing different sensor health statuses (e.g., optimal GPS lock, partial GPS, no GPS but good visual odometry). Each cell would then predict the probability of a successful navigation fix or an accurate positional estimate. This exercise reveals that while a single sensor might fail, the system’s ability to fuse data from multiple, diverse sources increases the overall robustness. However, it also highlights scenarios where specific combinations of environmental challenges and sensor limitations could lead to critical failures, guiding the development of more resilient sensor redundancy and error compensation algorithms.
Algorithmic Combinations for AI Follow Mode
AI follow mode is a popular feature that allows drones to autonomously track a moving subject. Its success hinges on the robust interaction between computer vision algorithms, predictive motion models, and flight control systems. Here, a Punnett square could illustrate the combinations of subject behavior and environmental clutter.
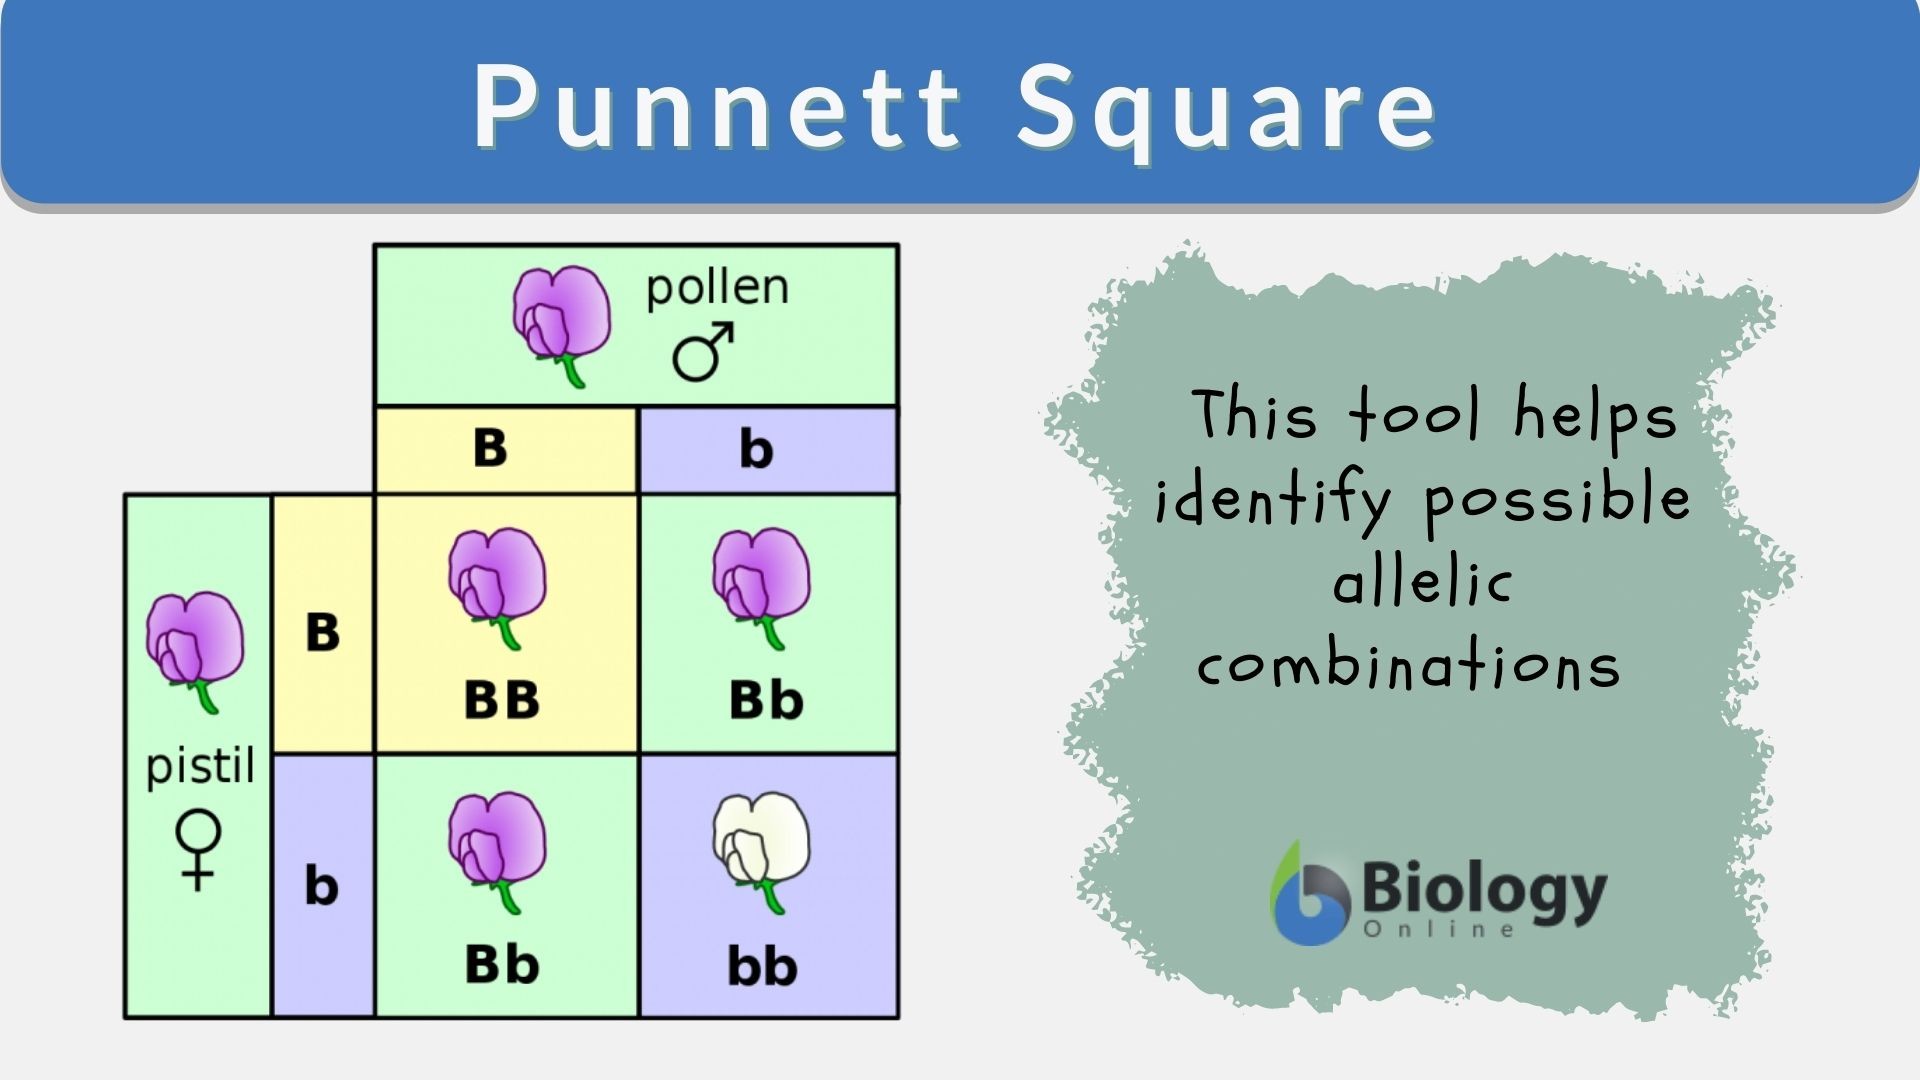
One axis might represent different subject movement patterns (e.g., slow walk, sudden sprint, erratic motion), and the other axis could represent environmental complexity (e.g., open field, sparse trees, dense urban area with occlusions). The resulting cells would depict the probability of maintaining a lock on the target, predicting its trajectory accurately, and executing smooth, stable flight while maintaining safety distances. This analytical framework helps engineers refine the AI’s learning models, optimize prediction algorithms, and adapt control strategies to ensure seamless tracking even under challenging, unpredictable conditions. Understanding these combinatorial probabilities is crucial for developing AI follow modes that are not only impressive but also consistently reliable across diverse operational contexts.
Assessing Outcomes in Remote Sensing and Data Acquisition
Remote sensing and aerial mapping leverage drones to collect critical data for a multitude of applications, from agricultural monitoring to infrastructure inspection and environmental analysis. The quality and utility of the acquired data are direct functions of multiple interdependent factors, including flight path planning, sensor selection, and environmental conditions during data capture. The Punnett square concept serves as a powerful tool for predicting the actionable insights derivable from various configurations.
Optimizing Data Capture Probabilities
For a remote sensing mission, the “Punnett square” can help project the probable quality of the final data product based on chosen inputs. One axis might represent variations in flight parameters (e.g., altitude, overlap percentage, flight speed), while the other axis could represent different sensor types (e.g., high-resolution RGB camera, multispectral sensor, thermal imager) deployed under varying atmospheric conditions (e.g., clear, hazy, cloudy).
Each cell in this matrix would then provide a probabilistic assessment of the data outcome: for example, the likelihood of achieving a desired Ground Sample Distance (GSD), the accuracy of plant health indices, or the clarity of thermal anomalies. This predictive model allows operators to make informed decisions before deployment, optimizing the mission plan to maximize data utility while minimizing costs and flight time. It helps to avoid costly re-flights by identifying sub-optimal combinations of parameters that are unlikely to yield the required data quality.
From Data Inputs to Actionable Intelligence Outcomes
The ultimate value of remote sensing lies not just in collecting data, but in transforming it into actionable intelligence. Here, the Punnett square can extend its utility to predict the likelihood of generating specific analytical outcomes based on the raw data inputs and subsequent processing techniques.
Imagine an analysis focused on identifying disease outbreaks in crops. One axis of our conceptual Punnett square might detail different levels of input data quality (e.g., precise multispectral imagery, moderate-resolution RGB data), while the other axis could represent various data processing algorithms (e.g., advanced machine learning models, traditional vegetation index calculations). The cells would then represent the probability of accurately detecting disease outbreaks, quantifying stress levels, or predicting yield reductions. This framework allows for a systematic evaluation of different data acquisition and processing strategies, guiding the selection of optimal workflows to derive the most accurate and impactful insights for stakeholders, whether in agriculture, forestry, or urban planning.

The Future of Deterministic and Probabilistic Drone Behavior
The conceptual framework of a Punnett square, when applied to drone technology, underpins a fundamental shift from purely deterministic system design to one that embraces and quantifies probabilistic outcomes. As drones become more autonomous and capable of operating in increasingly complex and unpredictable environments, understanding these combinatorial effects is no longer a luxury but a necessity.
This predictive approach is driving advancements in simulation and digital twin technologies. By creating high-fidelity virtual replicas of drones and their operating environments, engineers can explore millions of “Punnett square” combinations without ever lifting off. These simulations allow for the rapid iteration and testing of new algorithms, sensor configurations, and control strategies, predicting their performance before real-world deployment. The insights gained from these simulated “squares” inform the development of more robust AI, enabling drones to learn from a vast array of potential scenarios and adapt their behavior dynamically.
The long-term vision involves self-optimizing drone systems that can, in real-time, assess their own internal “Punnett squares.” Leveraging onboard AI and machine learning, these advanced drones will be able to evaluate the probabilities of various outcomes given their current state, sensor inputs, and environmental context. This enables them to make intelligent decisions that maximize mission success and minimize risk, even in unforeseen circumstances. By internalizing this conceptual framework, future drones will not merely react to their environment but will proactively choose actions based on a sophisticated understanding of potential futures, making true autonomous and intelligent flight a ubiquitous reality.