
The world of drones, particularly within the realm of Tech & Innovation, is fundamentally underpinned by a fascinating array of mathematical and scientific principles. While often unseen, these foundational concepts enable everything from precise mapping to autonomous flight. Among these, the geometric principle of similar triangles stands out as a deceptively simple yet profoundly powerful tool. Far from being a mere academic curiosity, understanding similar triangles is crucial for grasping how drones measure distances, interpret spatial data, and perform sophisticated tasks in autonomous navigation, mapping, and remote sensing.
At its heart, similar triangles refer to two or more triangles that have the same shape but not necessarily the same size. Imagine zooming in or out on a photograph of a triangle—the resulting image is still a triangle of the same shape, just scaled differently. This scaling relationship, governed by proportional sides and identical angles, is what makes similar triangles such an indispensable concept in drone technology.
The Core Principles of Similar Triangles
To fully appreciate their utility, it’s essential to first establish a clear understanding of what similar triangles are and their defining characteristics. This mathematical groundwork forms the basis for their application in advanced drone systems.
Defining Similarity
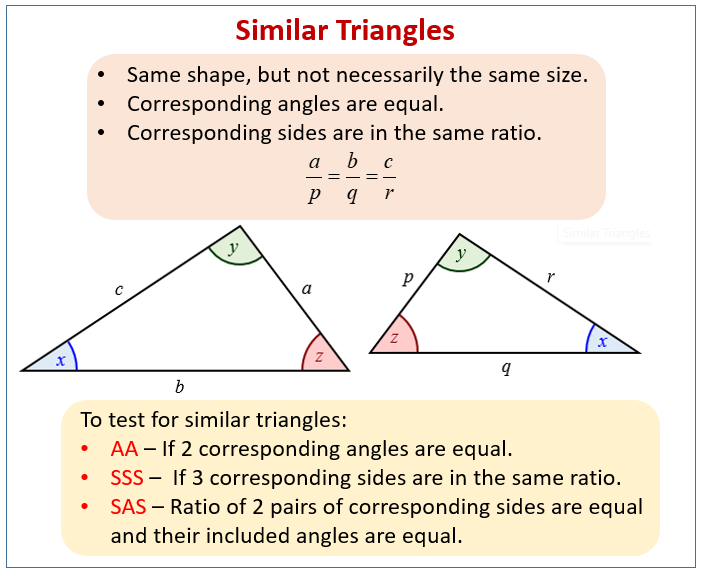
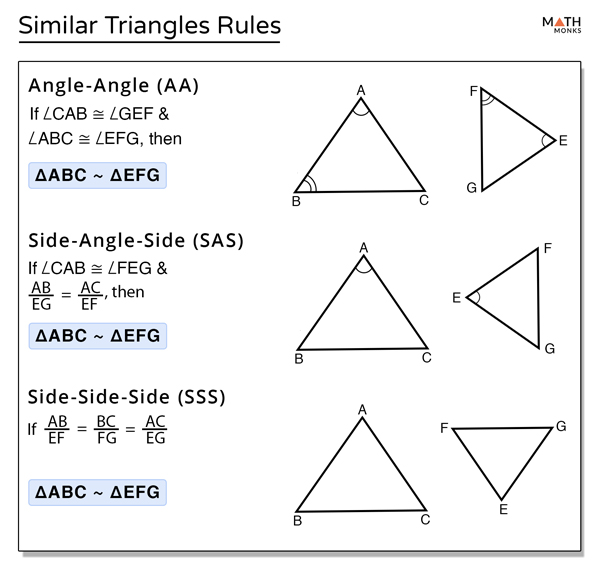
Two triangles are considered similar if all of their corresponding angles are equal, and their corresponding sides are in proportion. This means that if you have triangle ABC and triangle XYZ, they are similar if:
- Angle A = Angle X
- Angle B = Angle Y
- Angle C = Angle Z
And consequently:
- AB/XY = BC/YZ = CA/ZX = k (where k is a constant scale factor)
The order of vertices matters when stating similarity, indicating which angles correspond and which sides are proportional. The symbol for similarity is ‘~’. So, if triangle ABC is similar to triangle XYZ, we write ΔABC ~ ΔXYZ. There are several criteria to prove triangle similarity without knowing all angles and sides, such as Angle-Angle (AA), Side-Angle-Side (SAS), and Side-Side-Side (SSS) similarity theorems. For drone applications, the implications of these proportional relationships are what truly matter.
Properties and Proportions
The defining property of similar triangles—that corresponding sides are proportional—is the workhorse in drone technology. This proportionality allows engineers and autonomous systems to calculate unknown distances, heights, or sizes based on known values and observed angles or ratios. If a drone’s camera captures an image, and the geometry involved creates similar triangles between the camera, an object, and the ground, then by knowing certain camera parameters (like focal length) and the object’s pixel size, the drone can infer the object’s real-world distance or size. This principle extends to various scenarios:
- Scaling: If one triangle is twice the size of another similar triangle, then all its sides are twice as long. This scale factor (k) is critical for converting pixel measurements to real-world dimensions.
- Perspective: When objects at different distances are viewed through a lens, their apparent size changes. Similar triangles help quantify this change, allowing for depth estimation from 2D images.
- Triangulation: A fundamental technique in surveying and navigation, triangulation often relies on constructing a network of triangles. If the angles and one side of a triangle are known, other sides (distances) can be calculated using trigonometry, which itself is built upon similar right-angled triangles.
The consistency of these proportional relationships across different scales is precisely what makes similar triangles an invaluable tool for drones operating in complex 3D environments.
Similar Triangles in Drone Mapping and Photogrammetry
One of the most impactful applications of similar triangles in drone technology is found in the fields of mapping and photogrammetry. Drones equipped with high-resolution cameras can capture vast amounts of imagery, which is then processed to create highly accurate 2D maps and 3D models of landscapes, structures, and objects. The underlying geometry for these transformations heavily relies on the principles of similar triangles.
Ground Sample Distance (GSD) Calculation
Ground Sample Distance (GSD) is a critical metric in drone mapping, representing the real-world distance between the centers of two adjacent pixels in an aerial image. A smaller GSD means higher resolution and greater detail. Calculating GSD precisely is essential for accurate measurements from drone-derived maps. This calculation directly employs the concept of similar triangles.
Imagine a triangle formed by the camera’s lens, the image sensor plane, and the ground. As the drone flies higher, the area covered by a single pixel on the ground increases, meaning the GSD increases. The relationship between the camera’s focal length (f), the sensor pixel size (p), and the drone’s altitude (H) to the GSD is described by a similar triangle relationship:
GSD / p = H / f
From this, we can derive: GSD = (H * p) / f.
Here, the triangle formed by the lens, a pixel, and the point it represents on the sensor is similar to the triangle formed by the lens, the GSD, and the corresponding area on the ground. This formula allows mapping professionals to plan flight paths and altitudes to achieve a desired resolution for their projects, ensuring the derived maps meet specific accuracy requirements for various applications, from construction progress monitoring to environmental impact assessments.

3D Reconstruction and Digital Models
Photogrammetry involves taking multiple overlapping 2D photographs from different angles and using specialized software to stitch them together and reconstruct a 3D model of the photographed scene. This process fundamentally relies on the projective geometry of cameras, where similar triangles play a crucial role in determining depth and relative positions.
When a drone captures images from slightly different viewpoints, points in the real world appear in different pixel locations in each image – this phenomenon is known as parallax. By identifying corresponding points across multiple images, similar triangles are used to triangulate the 3D position of each point.
Consider two camera positions capturing the same point in space. The baseline between the two camera positions, combined with the viewing angles to the common point, forms a series of similar triangles. By knowing the camera’s internal parameters (calibration) and its relative position and orientation (external parameters), software can use these similar triangle relationships to calculate the 3D coordinates of every pixel, effectively building a dense point cloud. This point cloud can then be converted into a mesh, textured, and used to create Digital Surface Models (DSMs) and Digital Terrain Models (DTMs), which are invaluable for land surveying, urban planning, and infrastructure inspection.
Enhancing Autonomous Flight and Navigation
Beyond mapping, the principles of similar triangles are integral to the advanced algorithms that enable autonomous flight, intelligent navigation, and sophisticated interaction with the environment. Drones leverage these geometric relationships to understand their surroundings, track objects, and navigate safely without constant human intervention.
Visual Odometry and SLAM
Visual Odometry (VO) and Simultaneous Localization and Mapping (SLAM) are cornerstone technologies for autonomous drones. These systems allow a drone to estimate its own position and build a map of its environment solely using camera input. Similar triangles are at the core of how depth and motion are inferred from sequential 2D images.
- Visual Odometry: As a drone moves, objects in its field of view shift across the image sensor. By tracking these pixel movements (optical flow) between consecutive frames, and knowing the camera’s intrinsic parameters (like focal length), algorithms can construct a series of similar triangles. The change in the apparent size or position of an object in the image directly relates, via similar triangles, to the drone’s movement and the object’s distance. This allows the drone to estimate how far it has moved and in what direction.
- SLAM: SLAM extends VO by building and maintaining a consistent map of the environment while simultaneously tracking the drone’s position within that map. When the drone re-observes a previously mapped feature, the geometric constraints provided by similar triangles (e.g., relating the feature’s 3D position to its 2D projection in multiple camera views) are used to refine both the drone’s estimated pose and the map’s accuracy. This continuous loop of observation and refinement is heavily reliant on robust geometric calculations, often simplified and generalized through principles derived from similar triangles.
Object Sizing and Distance Estimation
For tasks like AI follow mode, obstacle avoidance, or inspecting specific assets, drones need to accurately estimate the size and distance of objects in their environment. Monocular (single camera) and stereo vision systems frequently employ similar triangles for these estimations.
- Monocular Vision: With a single camera, if the real-world size of an object (or a known reference within the scene) is known, or can be assumed, then similar triangles can be used to calculate its distance from the camera. The triangle formed by the camera’s focal point and the top and bottom of the object on the sensor is similar to the triangle formed by the focal point and the real-world top and bottom of the object.
Object Height (pixels) / Focal Length (pixels) = Real Object Height (meters) / Distance to Object (meters)
This relationship allows a drone to estimate distance if it knows an object’s real size, or to estimate an object’s size if its distance is known (e.g., from a rangefinder).
- Stereo Vision: Drones with two cameras (stereo vision) mimic human binocular vision. By comparing the disparity (difference in pixel location) of a specific point in the left and right images, similar triangles are formed. The baseline distance between the two cameras, combined with their focal lengths and the observed disparity, creates a geometric setup where the distance to the object can be precisely calculated. This is a highly robust method for real-time depth perception, crucial for advanced obstacle avoidance and target tracking.
Remote Sensing and Environmental Analysis
The capabilities of drones in remote sensing for environmental analysis are significantly enhanced by the precision afforded by similar triangles. From monitoring agricultural health to assessing natural disasters, accurate measurement and spatial understanding are paramount.
Scale and Measurement Accuracy
In remote sensing, drones collect data that helps scientists and practitioners understand large-scale environmental phenomena. The scale of an image or a derived map is a fundamental concept, indicating the ratio between a distance on the map and the corresponding distance on the ground. Similar triangles are intrinsically linked to understanding and maintaining this scale.
When creating orthomosaics—georeferenced, distortion-free images—from aerial photographs, the geometric transformations involve correcting for perspective distortions. Each pixel’s position relative to the camera and the ground forms a series of similar triangles, allowing algorithms to project ground features accurately onto a flat, scaled map. This ensures that measurements taken directly from the digital map (e.g., area of a forest, length of a river segment) are true-to-life. The ability to guarantee consistent scale across vast areas enables accurate quantification and comparative analysis over time.
Change Detection and Monitoring
Drones are invaluable tools for long-term environmental monitoring, from tracking glacier retreat to monitoring vegetation health in agricultural fields. Change detection relies on comparing data collected at different times. For this comparison to be meaningful, the spatial data from each epoch must be accurately registered and scaled.
Similar triangles contribute to this accuracy by ensuring that ground measurements and object sizes are consistently calculated across different flights, even if flying conditions (like altitude) vary slightly. When analyzing shifts in coastlines, changes in urban sprawl, or the progression of deforestation, the ability to convert pixel data into consistent, real-world measurements via similar triangle principles guarantees that observed changes are actual environmental transformations, not artifacts of inconsistent data collection or processing. This precision allows for robust scientific analysis and informed decision-making in environmental management and conservation efforts.
In summary, similar triangles, a concept seemingly simple, are a cornerstone of advanced drone technology. They empower drones to perceive, navigate, map, and interact with the world with an ever-increasing level of autonomy and precision, continually pushing the boundaries of what is possible in tech and innovation.