
Uniform distribution stands as a foundational concept in probability theory and statistics, describing a scenario where all outcomes within a defined range or set are equally likely. Unlike distributions that feature peaks or clusters of common outcomes, a uniform distribution presents a flat, constant probability across its entire domain. For the burgeoning field of drone technology and innovation, understanding and leveraging uniform distribution is crucial for everything from optimizing data collection strategies to enhancing the reliability of autonomous systems and simulations.
The Fundamentals of Uniform Distribution
At its core, uniform distribution posits that every possible value within a given interval has the same probability of occurring. This simplicity makes it a powerful tool for modeling situations where there is no inherent bias towards one outcome over another.

Defining the Concept
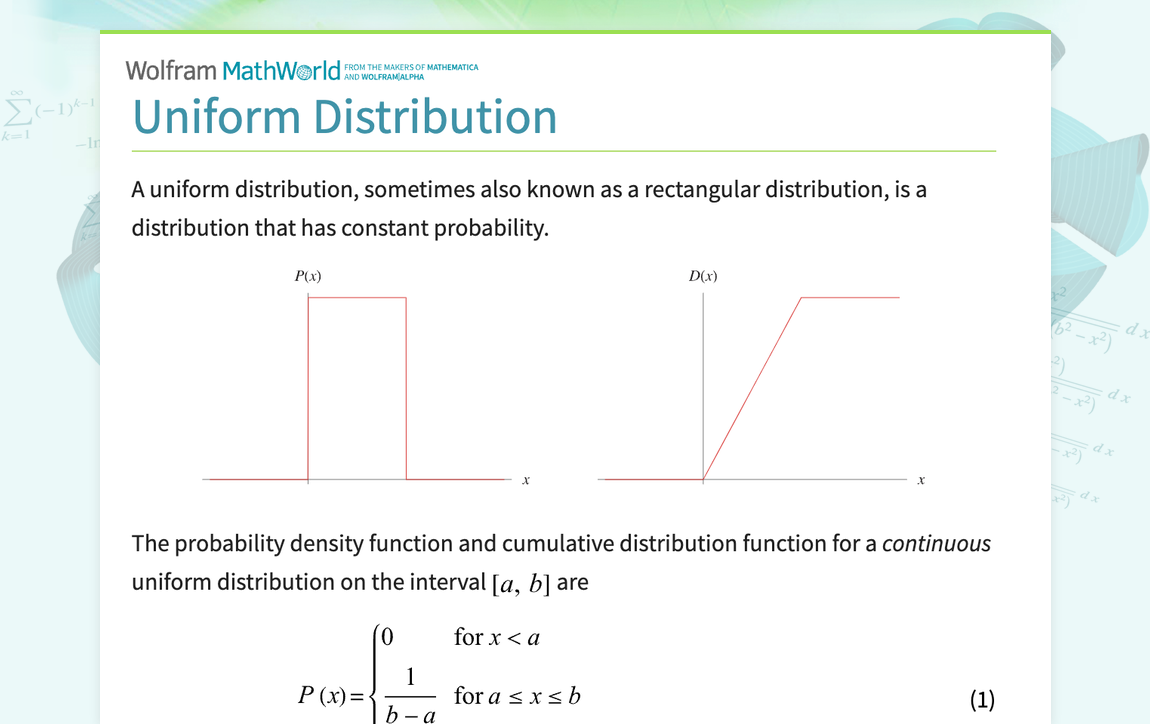
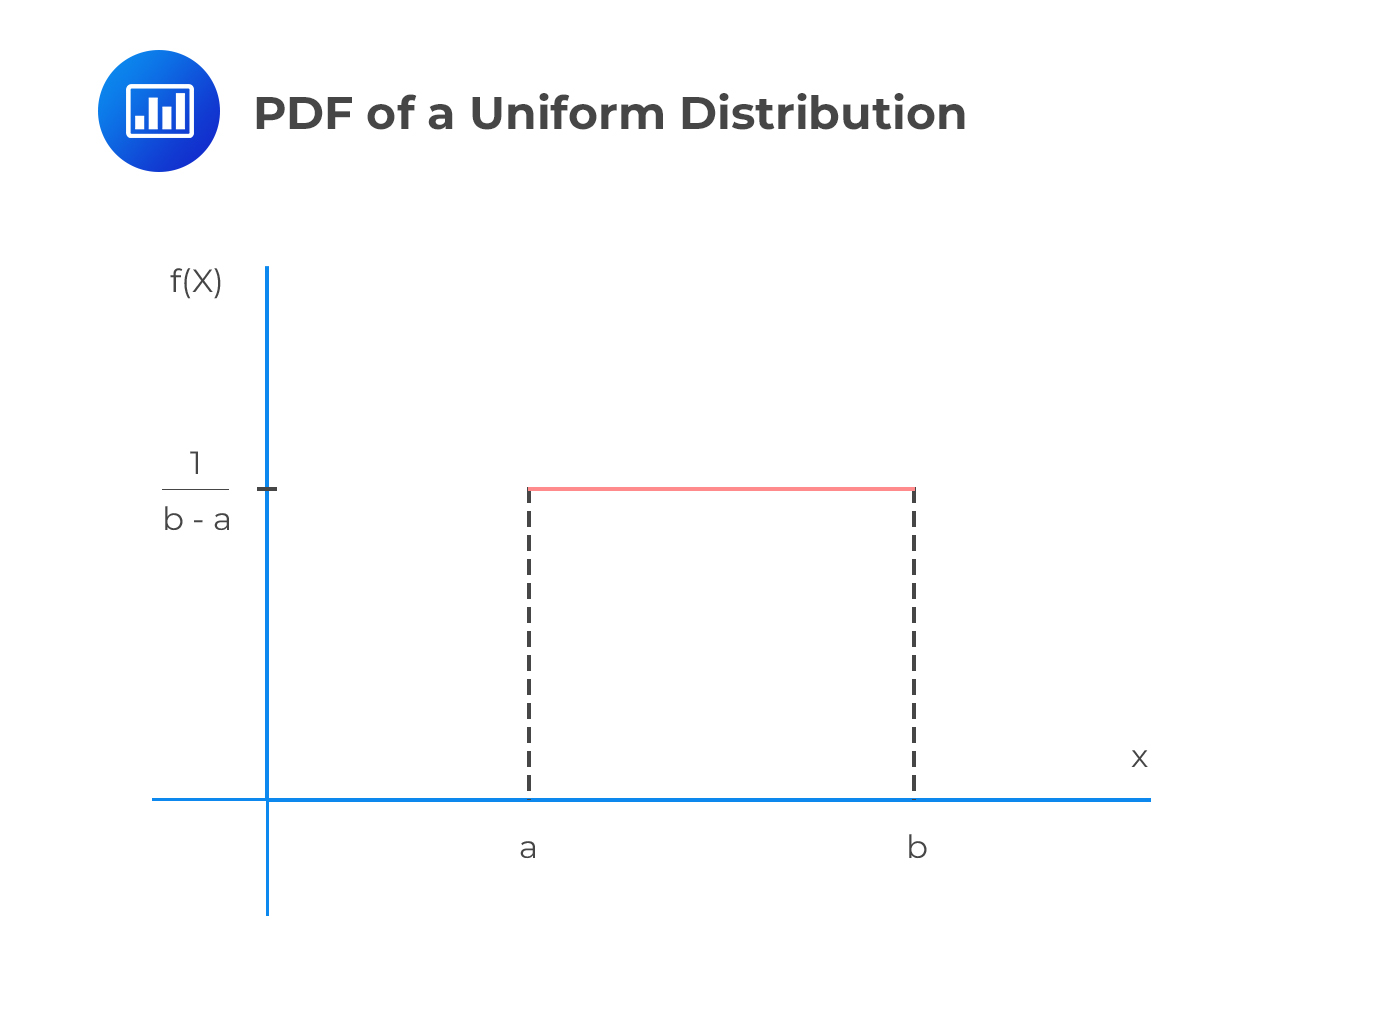
Imagine a scenario where a drone is programmed to randomly drop a payload within a square target area. If the drone’s drop mechanism is truly random and lacks any preference for specific coordinates within that square, then the probability of the payload landing in any one small sub-area of equal size within the target would be identical. This exemplifies a continuous uniform distribution, where the probability density function (PDF) is constant across the entire range of possible outcomes and zero elsewhere. Similarly, a discrete uniform distribution applies when a finite number of distinct outcomes are all equally probable—for instance, if a drone is selecting a task from a list of five equally important tasks, and each task has a 20% chance of being chosen.
Types of Uniform Distributions
The distinction between continuous and discrete uniform distributions is significant in drone technology applications:
- Continuous Uniform Distribution: This applies to variables that can take any value within a specified interval. Examples include GPS measurement errors within a certain bounded range, or the coordinates chosen for a random search pattern. The probability density function is constant over the interval [a, b] and zero outside it. The total area under this function must integrate to 1.
- Discrete Uniform Distribution: This applies to variables that can only take on a finite number of distinct values, each with an equal probability. For example, selecting a specific channel for communication from a set of available channels, or choosing one of several predetermined flight altitudes. If there are ‘n’ possible outcomes, each has a probability of 1/n.
Key Characteristics
Several key characteristics define uniform distribution:
- Constant Probability/Density: The defining feature is the unchanging probability for each outcome within the specified range.
- Defined Range: Uniform distributions always operate within a clear, finite lower (a) and upper (b) bound for continuous variables, or a finite set of outcomes for discrete variables.
- Mean and Variance: For a continuous uniform distribution on [a, b], the mean (expected value) is (a+b)/2, representing the midpoint of the range. The variance, which measures the spread of the distribution, is (b-a)^2 / 12. These statistical measures provide critical insights for analysis and system design.
Uniform Distribution in Drone Data Collection and Mapping
The accurate and comprehensive collection of data is paramount for many drone-based applications, including mapping, surveying, and photogrammetry. Uniform distribution principles play a critical role in designing effective data acquisition strategies.
Ensuring Comprehensive Coverage
When a drone is tasked with creating an orthomosaic or a 3D model of a large area, it’s essential to ensure that every part of the target region is adequately photographed or scanned. A uniform distribution approach to flight path planning ensures that the drone systematically covers the entire area without significant gaps or excessive overlaps in certain zones. This might involve generating a grid pattern where waypoints are uniformly spaced, or employing algorithms that distribute camera trigger points uniformly across the desired ground area. The goal is to achieve an even density of data points, leading to a more consistent and reliable final product.
Optimizing Sensor Placement and Sampling
In remote sensing, drones often carry a suite of sensors—optical, multispectral, thermal, LiDAR. The effectiveness of the data relies heavily on how these sensors sample the environment. Uniform sampling involves taking measurements at regularly spaced intervals, ensuring that the sensor’s readings represent the entire target area without bias. For instance, in agricultural monitoring, a uniform sampling strategy ensures that soil moisture or crop health data is collected evenly across fields, preventing misleading conclusions due to localized readings. This approach is vital for calibrating sensors and validating models across diverse environmental conditions encountered during flight.
Building Accurate Orthomosaics and 3D Models
The creation of high-quality orthomosaics and 3D models from drone imagery requires a robust dataset. Photogrammetry software relies on feature matching across multiple overlapping images to reconstruct the scene. If the camera positions and image capture points are uniformly distributed, it provides a consistent baseline for geometric reconstruction. Non-uniform distribution of images can lead to areas with insufficient overlap, causing distortion or holes in the final model, or areas with excessive overlap, which unnecessarily increases processing time without adding significant value. A uniform distribution of image acquisition points helps maintain consistent ground sample distance (GSD) and geometric accuracy throughout the mapped area.
Autonomous Flight and Path Planning
Autonomous drones operate with increasing sophistication, making complex decisions regarding navigation, exploration, and interaction with their environment. Uniform distribution is an underlying concept in many of the algorithms that drive these autonomous capabilities.
Efficient Area Coverage Strategies
For autonomous drones performing tasks like search and rescue, surveillance, or infrastructure inspection, efficient area coverage is non-negotiable. Algorithms for path planning often incorporate uniform distribution principles to guarantee that the drone systematically covers every segment of a predefined area. Spiral patterns, lawnmower patterns, or more complex Boustrophedon paths are designed to distribute the drone’s presence (and therefore its sensor coverage) uniformly over the operational domain. This ensures thoroughness and minimizes the time and energy expended to achieve full coverage.
Randomness in Exploration and Obstacle Avoidance
While autonomous flight often aims for deterministic outcomes, controlled randomness, often generated from a uniform distribution, is crucial for specific applications. In unknown or dynamic environments, a drone might employ randomized search strategies to explore new areas or discover obstacles. By drawing random numbers from a uniform distribution to dictate small perturbations in its path, or to select alternative routes when blocked, the drone can avoid getting stuck in local optima or repetitive patterns. This stochastic approach, grounded in uniform probability, helps ensure thorough exploration and robust obstacle avoidance behavior in complex scenarios.
Simulating Environmental Variables
Developing and testing autonomous drone systems demands rigorous simulation. Uniform distribution is indispensable for generating realistic and varied environmental parameters for these simulations. For instance, when testing an autonomous drone’s ability to operate in varying wind conditions, simulator engineers might sample wind speeds and directions from a uniform distribution within a plausible range. This ensures that the drone’s algorithms are tested against a wide spectrum of potential conditions, rather than just a few fixed scenarios, thereby increasing the robustness and reliability of the autonomous flight system before real-world deployment.
Remote Sensing and Environmental Monitoring
Drones equipped with specialized sensors are transforming environmental monitoring and remote sensing by providing high-resolution data over vast and often inaccessible areas. Uniform distribution principles aid in standardizing data acquisition and ensuring the integrity of the collected information.
Standardizing Data Acquisition
In environmental monitoring, collecting data consistently across time and space is crucial for detecting trends and changes. Whether it’s tracking deforestation, monitoring water quality, or assessing crop health, uniform distribution guides the systematic acquisition of data. Drones flying pre-programmed missions with uniformly spaced waypoints and consistent sensor settings ensure that data collected from different areas or at different times can be directly compared. This standardization, rooted in uniform sampling, reduces variability attributed to the data collection process itself, allowing scientists to focus on true environmental variations.
Calibrating Sensors and Reducing Bias
The accuracy of remote sensing data depends heavily on well-calibrated sensors. Uniform distribution can be applied during the calibration process by exposing sensors to a uniform range of known stimuli (e.g., light intensities, temperatures). This ensures that the sensor’s response across its entire operational range is characterized accurately. Furthermore, when combining data from multiple sensors or different drone platforms, understanding the potential for uniformly distributed errors or biases allows for more precise data fusion and correction algorithms, leading to more reliable environmental insights.
Identifying Anomalies and Trends
When analyzing large datasets collected by drones, uniform distribution often serves as a baseline or null hypothesis. If environmental data (e.g., pollutant concentrations, temperature readings) shows significant deviation from a uniform distribution across an area where it is expected to be uniform, it can signal an anomaly or an emerging trend. For example, if vegetation index values are expected to be uniformly distributed across a healthy, homogenous field but show significant variation, it could indicate disease, water stress, or nutrient deficiencies in specific areas. This application helps target interventions and further investigations efficiently.
Beyond the Basics: Advanced Applications and Considerations
The concept of uniform distribution, while simple, extends into more complex computational and statistical models within drone technology and innovation.
Challenges and Limitations
Despite its utility, applying uniform distribution faces challenges. Achieving truly uniform coverage in dynamic environments is difficult due to wind, battery life, varying terrain, and no-fly zones. Sensors might also have non-uniform sensitivities across their field of view. Moreover, not all real-world phenomena exhibit uniform distribution; many follow normal, exponential, or other complex distributions. Therefore, understanding when uniform distribution is an appropriate model versus when it is a simplification is critical for accurate analysis.
Integration with Other Distributions
In advanced drone systems, uniform distributions are often integrated with other statistical models. For instance, random numbers drawn from a uniform distribution can be transformed to generate samples from a normal distribution (e.g., for modeling GPS errors) or other specialized distributions, which better represent particular physical phenomena. This allows algorithms to leverage the ease of generating uniform random numbers while still modeling complex real-world variability.
Future Implications for Drone AI and Robotics
As drone AI advances, the understanding of uniform distribution will become even more integral. From training machine learning models with uniformly sampled datasets to ensure robustness and prevent bias, to designing sophisticated exploration algorithms for truly autonomous robotic swarms, the concept remains fundamental. For instance, in multi-drone collaborative missions, a uniform distribution of tasks among drones can optimize efficiency and resource allocation. As drones become more integrated into smart cities and complex ecosystems, the ability to model and manage their interactions and data collection strategies based on sound statistical principles, including uniform distribution, will be paramount for safety, efficiency, and innovation.