
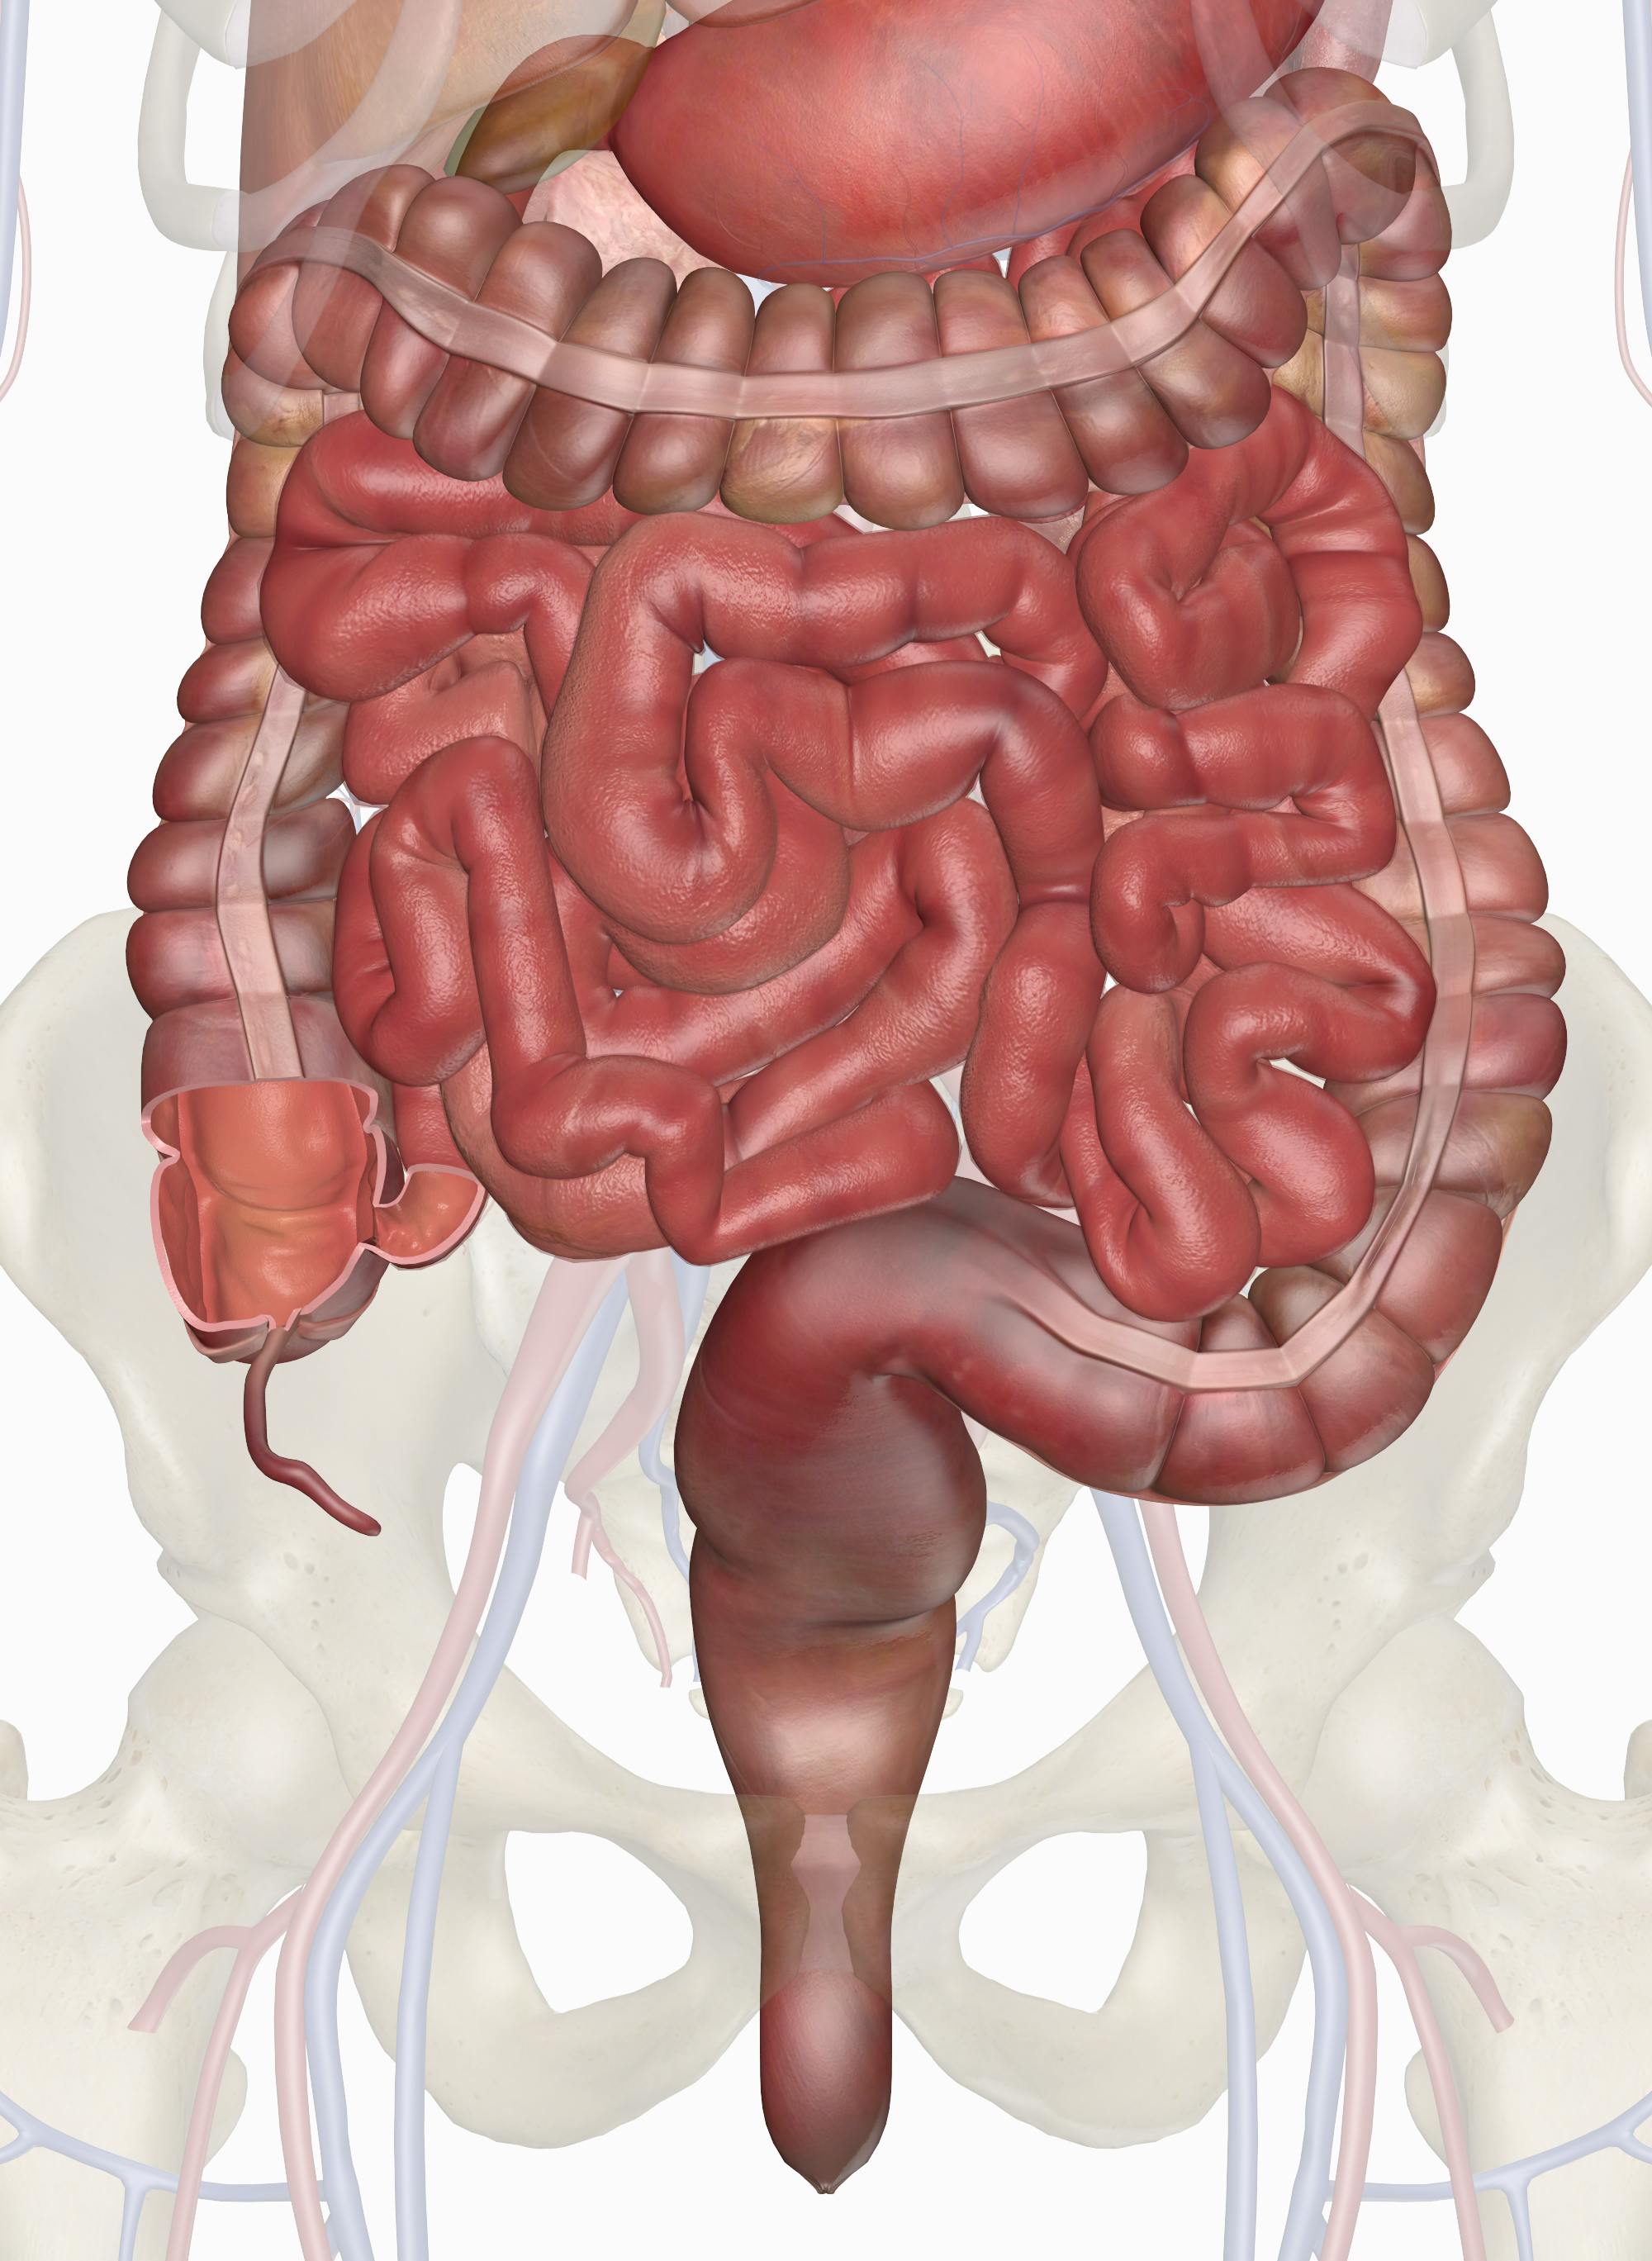
The term “intestinal” typically evokes biological imagery – a complex, convoluted system vital for life. In the realm of advanced technology and innovation, however, “intestinal” can be a powerful metaphor to describe the intricate, confined, and often hazardous internal environments that challenge autonomous systems and remote sensing capabilities. These are the hidden labyrinthine spaces within infrastructure, machinery, natural formations, and disaster sites that are inaccessible or too dangerous for human exploration. Understanding “what is intestinal” in this technological context means defining these challenging environments and exploring how cutting-edge innovations, particularly in drone technology, artificial intelligence, and specialized sensing, are enabling unprecedented access and insight.
The Labyrinthine Challenge: Defining “Intestinal” Environments for Autonomous Systems
The “intestinal” environments that push the boundaries of tech and innovation share several defining characteristics that make them particularly difficult to navigate and analyze. These are not merely tight spaces; they represent a confluence of physical, sensory, and operational hurdles that demand sophisticated solutions.
Complexity and Confinement
At the core of an “intestinal” environment is its inherent complexity and confinement. This can range from the intricate pipe networks of an industrial plant, the narrow ventilation shafts of a building, the internal structures of large vessels, or the collapsed rubble of a disaster zone. Such spaces are often characterized by:
- Irregular Geometries: Unlike open-air flight, internal spaces feature unpredictable walls, obstacles, and sudden changes in dimension, making pre-programmed flight paths largely ineffective.
- Limited Access Points: Entry and exit may be severely restricted, often requiring small, agile platforms.
- Variable Topography: Floors, ceilings, and walls can be uneven, slippery, or covered in debris, impacting ground-based robots and requiring advanced aerial agility.
- Dynamic Environments: In industrial settings, these spaces might contain moving parts, varying temperatures, or fluctuating air currents. In disaster scenarios, the environment itself can shift.
These factors necessitate autonomous systems capable of real-time perception, decision-making, and execution within highly constrained volumes, far beyond what simple remote control can offer.
Sensor Limitations and Data Acquisition
Another significant challenge in “intestinal” environments is the limitation on conventional sensor operation and effective data acquisition. Standard GPS signals are often unavailable or severely degraded indoors and underground, rendering traditional navigation systems useless. Furthermore:
- Lack of Illumination: Many internal spaces are dark or dimly lit, requiring specialized cameras with low-light capabilities, thermal imaging, or active illumination.
- Obstruction of Line-of-Sight: Walls, machinery, and debris frequently block radio signals, affecting communication with the autonomous platform and hindering data transmission.
- Reflective Surfaces and Dust: Metallic surfaces can create confusing sensor returns, while dust or moisture can obscure optical sensors, leading to inaccurate readings.
- Sensor Saturation and Sparsity: In very confined spaces, sensors can become overwhelmed with proximate object data, or conversely, in larger but still internal voids, data can be sparse.
Overcoming these limitations requires a multi-modal sensing approach, often fusing data from various sources like lidar, sonar, inertial measurement units (IMUs), and visual cameras, processed by intelligent algorithms.
Autonomous Navigation and Mapping in Constrained Spaces
Addressing the “intestinal” challenge fundamentally relies on breakthroughs in autonomous navigation and sophisticated mapping techniques that can operate without external reference points. This area is where significant innovation in AI and robotics truly shines.
Simultaneous Localization and Mapping (SLAM)
SLAM algorithms are foundational to autonomous operation in GPS-denied environments. They enable a robot or drone to build a map of its surroundings while simultaneously tracking its own position within that map. For “intestinal” environments, visual-inertial SLAM (V-SLAM) and lidar-based SLAM are particularly critical:
- Visual SLAM: Utilizes cameras to identify features in the environment (visual landmarks) and estimates the platform’s movement by tracking these features across consecutive frames. When combined with IMU data, V-SLAM provides robust localization even in feature-poor or textureless areas often found internally.
- Lidar SLAM: Employs laser scanners to measure distances to surrounding surfaces, generating a 3D point cloud of the environment. By matching successive point clouds, the system can determine its movement and refine the map. Lidar excels in challenging lighting conditions and provides highly accurate spatial data crucial for dense mapping of complex internal structures.
The fusion of these techniques, often through advanced Kalman filters or graph-based optimization methods, allows for the creation of precise, real-time 3D maps essential for inspection, measurement, and future intervention within these intricate spaces.
AI-Powered Obstacle Avoidance and Path Planning
Beyond merely knowing where it is, an autonomous system in an “intestinal” environment must intelligently navigate it. This is where advanced AI and machine learning algorithms are indispensable:
- Dynamic Obstacle Avoidance: Unlike static maps, some “intestinal” environments feature moving parts or changing conditions. AI-driven perception systems can identify and track dynamic obstacles, adjusting flight or movement paths in real-time to prevent collisions. This includes predictive algorithms that anticipate the movement of objects or potential environmental changes.
- Constrained Path Planning: Traditional path planning often assumes open spaces. For confined environments, algorithms must factor in the drone’s physical dimensions, maneuvering capabilities, and the narrowness of the pathways. Reinforcement learning, for instance, can train autonomous agents to discover optimal, collision-free paths through highly complex, previously unknown 3D structures, optimizing for factors like mission duration, energy consumption, and data coverage.
- Exploration Strategies: When the environment is completely unknown (e.g., a collapsed building), AI-driven exploration strategies guide the drone to systematically cover the area, prioritizing unknown regions while minimizing redundant travel, ensuring comprehensive mapping and inspection.
These capabilities transform a drone from a remote-controlled tool into an intelligent explorer, capable of making autonomous decisions crucial for safe and effective internal missions.
Specialized Sensing and Data Interpretation
The mission within “intestinal” environments is not just to navigate but to gather meaningful data. This necessitates highly specialized sensors and intelligent methods for interpreting the vast amounts of information collected.
Miniaturized and Multi-spectral Sensors
To fit within tight spaces and collect diverse data, sensors for “intestinal” exploration must be compact, robust, and often capable of perceiving beyond the visible spectrum:
- High-Resolution Miniaturized Cameras: Often equipped with global shutters to prevent motion blur in fast movements and advanced image processing for low-light conditions, these cameras capture detailed visual information for inspection.
- Thermal and Hyperspectral Imaging: Thermal cameras reveal heat signatures, vital for detecting anomalies like hot spots in machinery, water leaks, or potential survivors in a disaster zone. Hyperspectral sensors can analyze material composition, identifying corrosion, gas leaks, or even biological traces.
- Gas and Radiation Detectors: For hazardous industrial settings or post-disaster scenarios, integrated gas sensors can detect combustible or toxic gases, while radiation detectors can identify radioactive materials, providing crucial safety intelligence without human exposure.
- Ultrasonic and Millimeter-Wave Radar: These sensors can penetrate smoke, dust, or steam more effectively than optical sensors, providing proximity data for navigation and detecting hidden structures or objects.
The integration of multiple sensor types into a single, compact payload, coupled with onboard processing, allows for a comprehensive understanding of the internal environment’s state.
Remote Inspection and Predictive Maintenance
The primary application of “intestinal” exploration technology is often critical inspection and, increasingly, predictive maintenance. Drones equipped with these advanced sensors can perform tasks that were previously impossible, dangerous, or extremely costly:
- Structural Integrity Assessment: High-resolution cameras and lidar can detect cracks, deformation, and corrosion in internal structures, piping, and welds, providing early warning signs of potential failures.
- Leak Detection: Thermal cameras can identify temperature differentials indicative of fluid or gas leaks, while specialized gas sensors pinpoint the exact location and type of leak.
- Inventory and Asset Tracking: In large internal facilities, drones can conduct automated scans for inventory management or to locate specific assets.
- Predictive Maintenance: By regularly monitoring critical internal components for subtle changes over time (e.g., increased vibration, minor thermal variations, or early signs of material degradation), autonomous systems can contribute data to predictive maintenance programs, optimizing equipment lifespan and preventing costly downtime. This proactive approach significantly enhances operational efficiency and safety in industries like energy, manufacturing, and infrastructure.
The Future of Internal Exploration: Innovation and Impact
The trajectory of “intestinal” exploration technology points towards even greater autonomy, collaboration, and integration, promising transformative impacts across numerous sectors.
Swarm Robotics and Collaborative Mapping
Future advancements will see individual autonomous drones evolve into intelligent swarms capable of collaborative mapping and inspection. A swarm of small, agile drones could:
- Rapidly Map Vast Areas: By distributing the mapping task, a swarm can cover extensive internal networks or large collapsed structures far more quickly than a single drone.
- Enhanced Redundancy and Robustness: If one drone fails or becomes stuck, others in the swarm can continue the mission, ensuring mission success.
- Multi-Perspective Data Collection: Each drone in a swarm can collect data from a slightly different perspective, which when fused, can create a more comprehensive and robust 3D model of the environment.
- Coordinated Search and Rescue: In disaster scenarios, swarms could fan out to locate survivors or points of interest more efficiently, communicating findings and coordinating movements in real-time.
This requires sophisticated inter-robot communication, decentralized decision-making algorithms, and advanced swarm intelligence to maintain cohesion and achieve collective goals.
Ethical Considerations and Safety Protocols
As autonomous systems delve deeper into these challenging “intestinal” environments, ethical considerations and robust safety protocols become paramount.
- Data Privacy and Security: The collection of detailed internal visual and sensory data raises concerns about privacy, especially in private infrastructure. Secure data handling, encryption, and strict access controls are essential.
- System Reliability and Redundancy: Given the critical nature of many inspection tasks, autonomous systems must be exceptionally reliable, with fail-safe mechanisms, redundant systems, and robust error handling to prevent catastrophic failures or data loss.
- Human Oversight and Intervention: While autonomy is increasing, human operators will continue to play a vital role in supervising missions, interpreting complex data, and intervening when unexpected situations arise. Designing intuitive human-machine interfaces is key.
- Regulatory Frameworks: As these technologies become more widespread, clear regulatory frameworks are needed to govern their deployment, particularly in sensitive or hazardous environments, ensuring public safety and accountability.
By meticulously addressing “what is intestinal” as a complex technological challenge, focusing on innovative solutions in autonomous navigation, specialized sensing, and AI-driven data interpretation, the tech industry is not only unlocking unprecedented access to hidden worlds but also redefining the boundaries of what is possible in remote exploration and intelligent systems. This ongoing innovation promises safer, more efficient, and more insightful interaction with the intricate internal landscapes that comprise much of our built and natural world.