
In the complex and rapidly evolving landscape of drone technology and innovation, the robust design of software systems is paramount. From autonomous flight algorithms to sophisticated AI follow modes and high-fidelity mapping, every advanced feature relies on meticulously crafted code. Within the Java programming language, a concept known as an “interface” serves as a critical architectural pillar, defining contracts and establishing a framework for modularity, flexibility, and scalability—all indispensable qualities for cutting-edge drone applications.
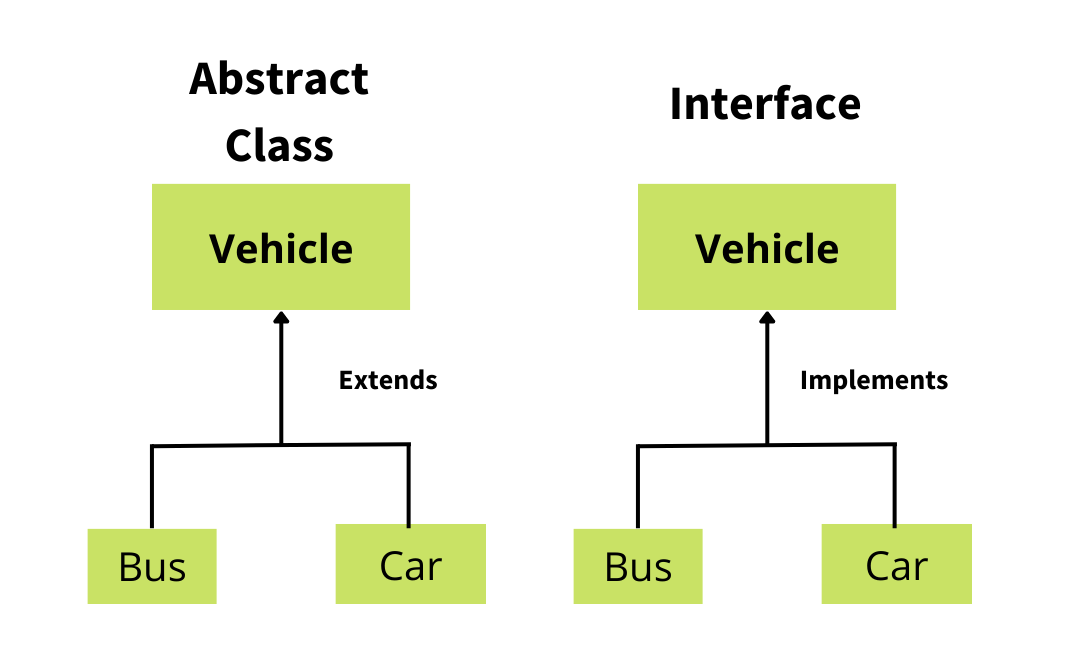
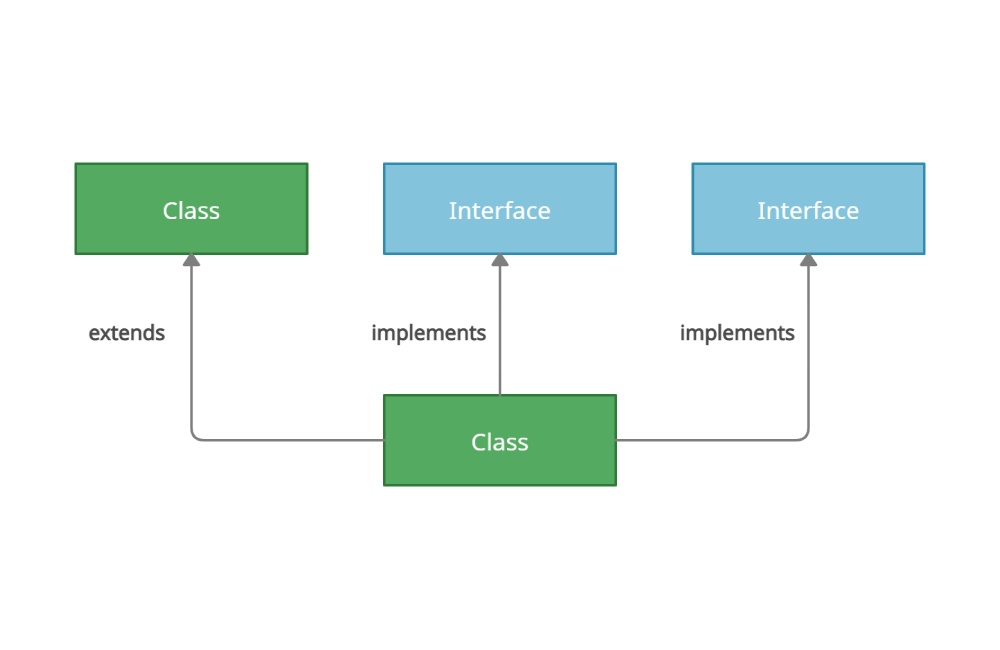
An interface in Java is a blueprint of a class. It can contain method signatures (abstract methods) and default methods, static methods, and constants. Crucially, it cannot contain instance variables and all methods are implicitly public and abstract (unless they are default or static). Unlike classes, interfaces cannot be instantiated directly. Instead, classes implement interfaces, thereby agreeing to provide concrete implementations for all the abstract methods declared within that interface. This mechanism enforces a contract: any class implementing a specific interface promises to deliver a defined set of behaviors. For drone software, this means that components can be designed to interact based on agreed-upon capabilities rather than specific implementations, fostering loose coupling and promoting a highly adaptable system.
Interfaces as Foundational Contracts for Autonomous Flight Systems
The core of any advanced drone system lies in its ability to execute complex maneuvers autonomously and react intelligently to its environment. This demands a highly organized and predictable software architecture, where different subsystems can communicate and cooperate seamlessly. Java interfaces play a pivotal role in establishing these foundational contracts.
Enforcing Standard Behaviors for Drone Subsystems
Consider a drone’s flight controller, which manages propulsion, stabilization, and navigation. Within such a system, various modules are responsible for distinct tasks: reading sensor data, calculating flight adjustments, and actuating motors. An interface can define a standard set of operations that any flight control module must provide. For instance, an IFlightController interface might declare methods like stabilize(), takeOff(), land(), or adjustAltitude(float targetAltitude). Any class designed to control flight, whether it’s a basic manual control system or an advanced AI-driven autopilot, must implement this IFlightController interface and provide concrete logic for each method. This ensures that regardless of the underlying complexity, any part of the drone’s software stack can interact with “a flight controller” through a consistent, predictable API. This standardization is vital for ensuring system integrity and preventing unexpected behaviors during critical flight operations, enhancing both safety and reliability.
Achieving Modularity and Interchangeability in Core Flight Logic
The ability to swap out or upgrade components without re-architecting the entire system is a hallmark of robust drone innovation. Interfaces facilitate this modularity by decoupling the “what” from the “how.” For example, a drone might employ different navigation strategies depending on the mission profile—GPS-based for outdoor long-range flight, or vision-based for indoor precision maneuvers. Instead of hardcoding a specific navigation module, the system can rely on an INavigationSystem interface. This interface would define methods such as getCurrentPosition(), calculateRoute(Waypoint[] path), or detectObstacles().
Now, developers can create multiple concrete implementations: GPSNavigationSystem, VisionNavigationSystem, or even HybridNavigationSystem. At runtime, the drone’s mission planning software can dynamically select and load the appropriate implementation, as long as it adheres to the INavigationSystem contract. This level of interchangeability is crucial for rapid prototyping of new algorithms, seamless hardware integration, and extending drone capabilities without disrupting core flight logic. It means that an innovative new navigation technique can be integrated by simply implementing the existing INavigationSystem interface, drastically reducing development cycles and increasing the pace of technological advancement.
Powering Innovation in AI Follow Mode and Obstacle Avoidance
Artificial intelligence and advanced perception systems are at the forefront of drone innovation, enabling features like autonomous object tracking, intelligent path planning, and sophisticated obstacle avoidance. Java interfaces are instrumental in structuring the software that underpins these complex behaviors, allowing for adaptable and evolving AI.
Polymorphic Design for Adaptive AI Algorithms
AI follow mode, where a drone autonomously tracks a moving subject, requires dynamic adaptation to varying conditions, subject movements, and environmental factors. Different AI algorithms might be employed for tracking, perhaps one optimized for human subjects in open fields and another for vehicles in urban environments. An IFollowBehavior interface could define the core methods required for any follow algorithm, such as trackTarget(TargetInfo info), predictNextPosition(), or adjustDronePosition().
By utilizing polymorphism—the ability of an object to take on many forms—the drone’s control system can interact with any IFollowBehavior implementation without needing to know its specific internal workings. If a new, more advanced neural network-based tracking algorithm is developed, it simply needs to implement IFollowBehavior. The drone’s AI coordinator can then seamlessly swap out the old algorithm for the new one, enhancing its tracking capabilities. This architectural flexibility is key to enabling continuous innovation in AI-driven drone features, allowing researchers and developers to experiment with and deploy new algorithms with minimal system disruption.
Abstracting Sensor Data for Advanced Perception
Obstacle avoidance systems rely on processing vast amounts of data from diverse sensors: ultrasonic, LiDAR, stereo cameras, and thermal imagers. Each sensor type provides data in a unique format, yet the ultimate goal is to generate a coherent understanding of the drone’s surroundings to prevent collisions. An ISensorDataProcessor interface can abstract away the specific details of individual sensors. It might define methods like processRawData(byte[] rawData), getObstacleMap(), or identifyThreats().
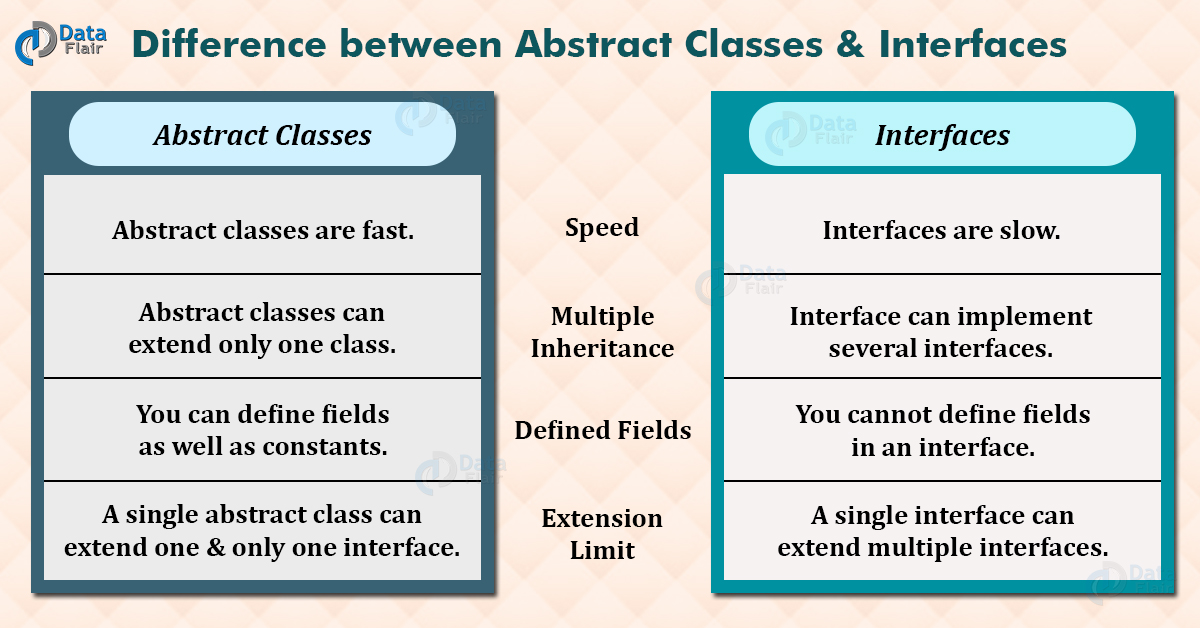
Specific implementations, such as LidarProcessor or StereoVisionProcessor, would then handle the nuances of their respective sensor data. The drone’s perception module can then receive processed data in a standardized format, regardless of its origin. This abstraction is vital for integrating new sensor technologies as they emerge, ensuring that the drone’s software remains adaptable to advancements in hardware. It allows innovators to focus on developing advanced perception algorithms that consume normalized data, rather than getting bogged down in sensor-specific integration details, accelerating the development of more robust and intelligent obstacle avoidance capabilities.
Elevating Drone Mapping and Remote Sensing Capabilities
Drone-based mapping and remote sensing applications, used in everything from agriculture and construction to environmental monitoring, demand precise data acquisition, efficient processing, and scalable data management. Interfaces streamline these processes, ensuring consistency and allowing for the integration of diverse methodologies.
Standardizing Data Processing Pipelines
High-resolution mapping often involves stitching together thousands of individual images, processing LiDAR point clouds, or analyzing multispectral data. The pipeline for handling this data can be complex, involving steps like geo-referencing, image correction, feature extraction, and 3D model generation. An IDataProcessingTask interface could define a standard unit of work within this pipeline, with methods such as execute(DataSet input), getResult(), or isCompleted().
This approach enables a highly modular processing framework. Different tasks (e.g., ImageStitchingTask, LidarPointCleanupTask, VegetationIndexCalculationTask) can all implement this interface. A drone’s ground control software or an onboard processing unit can then dynamically assemble and execute a sequence of these tasks, forming a complete mapping workflow. If a new, more efficient algorithm for geo-referencing is developed, it can be seamlessly integrated as a new GeoReferencingTask implementation without altering the overall pipeline structure. This standardization is crucial for maintaining data integrity across various mapping projects and for facilitating the adoption of new, more sophisticated processing techniques as they become available.
Ensuring Scalability for Complex Geospatial Applications
The sheer volume of data generated by drones in remote sensing missions can be immense. Processing this data efficiently and scalably, often in parallel, is a significant challenge. Interfaces can define contracts for data storage and retrieval, allowing the system to scale effectively. For instance, an IGeospatialDataSource interface might offer methods like retrieveTile(int x, int y, int zoom), storePoint(Point3D point, byte[] attributes), or queryFeatures(BoundingBox area).
Different implementations could then connect to various backends: LocalFileDataSource for onboard processing, CloudStorageDataSource for large-scale cloud-based analysis, or DatabaseDataSource for structured geospatial data. The mapping application itself interacts only with the IGeospatialDataSource interface, oblivious to the underlying storage mechanism. This architectural abstraction ensures that the drone’s mapping software can effortlessly scale from processing small datasets locally to managing petabytes of data across distributed cloud infrastructure. This scalability is fundamental for evolving drone applications towards real-time, large-area monitoring and sophisticated environmental analysis, driving innovation in how we collect and interpret spatial information.
Bolstering Reliability and Testability in Drone Software Development
The stakes are incredibly high in drone operations; a software bug can lead to property damage, injury, or mission failure. Therefore, robust testing and high software reliability are non-negotiable. Java interfaces contribute significantly to achieving these goals by promoting decoupling and facilitating systematic testing.
Decoupling Components for Rigorous Unit Testing
One of the greatest challenges in testing complex, integrated systems like drones is isolating individual components for focused examination. Interfaces address this by defining clear boundaries between parts of the software. When a class implements an interface, its functionality can be tested in isolation by creating “mock” or “stub” implementations of the interfaces it depends on.
For example, to test a new AutonomousLandingLogic class, a developer doesn’t need a physical drone or even a full flight simulator. Instead, they can create a MockAltimeter that implements an IAltimeter interface, providing controlled, simulated altitude readings. Similarly, a MockMotorController (implementing IMotorController) can simulate motor responses. This decoupling allows developers to thoroughly test complex algorithms and critical flight logic in a controlled, repeatable environment without dependencies on external hardware or other complex software modules. Such rigorous unit testing dramatically increases the confidence in individual components, reducing the likelihood of critical bugs emerging in real-world flight.
Facilitating Collaborative Development of Advanced Features
Developing advanced drone features, such as sophisticated AI models or new navigation algorithms, often involves large teams of engineers and researchers. Interfaces act as a common language and contract that multiple teams can adhere to. One team can define an interface for a new feature (e.g., IIntruderDetectionSystem), specifying its public methods and expected behaviors. Another team can then immediately begin developing a module that uses this interface, even before the first team has fully completed its implementation.
This parallel development is possible because both teams agree on the interface’s contract. The using team can work with a mock implementation of the interface initially, while the implementing team focuses on the actual logic. This concurrent development model significantly accelerates the overall development timeline for innovative drone features, fostering a more efficient and collaborative engineering environment. Interfaces, therefore, are not just a programming construct; they are a critical tool for project management and team coordination in the fast-paced world of drone technology.