
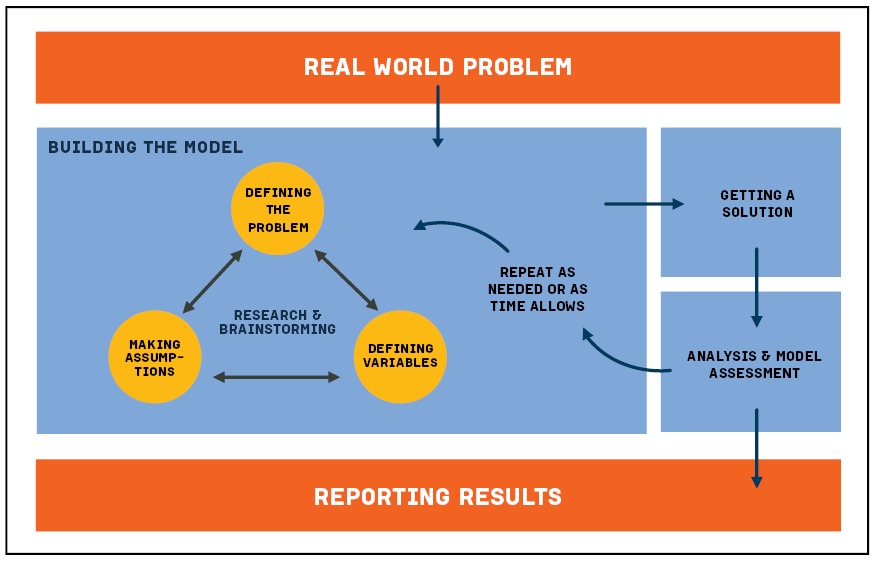
In the realm of modern “Tech & Innovation,” particularly concerning autonomous systems like drones, the concept of a “mathematical model” stands as an indispensable cornerstone. Far from being an abstract academic exercise, mathematical models are the fundamental blueprints that allow engineers and computer scientists to understand, predict, and control complex systems, driving advancements from precise navigation to intelligent autonomous decision-making. Essentially, a mathematical model is a description of a system using mathematical concepts and language. It translates real-world phenomena into equations, algorithms, and data structures, enabling us to simulate behavior, analyze performance, and design intelligent solutions before physical implementation.
The Foundation of Understanding and Prediction
At its core, a mathematical model simplifies reality, capturing its most essential features to make it amenable to quantitative analysis. This simplification isn’t about ignoring complexity; it’s about identifying the critical variables, parameters, and relationships that dictate a system’s behavior. For instance, modeling the flight of a drone involves considering forces like lift, drag, thrust, and gravity, alongside its mass, inertia, and the atmospheric conditions. These elements are expressed through differential equations, algebraic equations, or statistical relationships, forming a coherent framework.
The utility of these models is multifaceted. They provide a deeper understanding of underlying mechanisms, allowing researchers to explore “what-if” scenarios without incurring the cost or risk of physical experimentation. More importantly for tech and innovation, they are crucial for prediction. A well-constructed model can forecast how a drone will respond to a given control input, how its battery life will diminish under certain conditions, or how accurately a sensor will measure a specific parameter. This predictive power is vital for developing robust autonomous systems, where anticipating behavior is key to safety, efficiency, and performance. Without mathematical models, the intricate control laws, navigation algorithms, and AI capabilities we now associate with cutting-edge drone technology would simply not exist. They are the unseen logic that governs every intelligent action a drone performs.
Mathematical Models in Autonomous Flight Systems
Autonomous flight, a pinnacle of drone technology and innovation, is entirely reliant on sophisticated mathematical models. These models dictate everything from how a drone stabilizes itself in turbulent air to how it plans its optimal path through a complex environment.
Kinematic and Dynamic Models
For a drone to fly autonomously, it first needs to “understand” its own motion and how external forces affect it. Kinematic models describe the drone’s position, velocity, and acceleration without considering the forces causing them. Dynamic models, on the other hand, incorporate Newton’s laws of motion, linking forces (like thrust from propellers, aerodynamic drag, gravity) to the resulting motion. These models are typically represented by sets of differential equations that capture the drone’s six degrees of freedom (three translational and three rotational). High-fidelity dynamic models are crucial for designing precise flight controllers that can maintain stability, execute complex maneuvers, and compensate for external disturbances such as wind gusts.
Control System Models
Once the drone’s dynamics are understood, mathematical models are used to design its control systems. Proportional-Integral-Derivative (PID) controllers, for example, are ubiquitous in drone stabilization. These controllers use mathematical models to calculate the necessary motor adjustments based on the difference between the drone’s desired state (e.g., target altitude, heading) and its current measured state. More advanced control strategies, such as Model Predictive Control (MPC), rely on predictive mathematical models of the drone’s future behavior to optimize control inputs over a time horizon, anticipating and reacting to upcoming conditions or path requirements. This allows for smoother, more efficient, and more precise autonomous flight trajectories.
State Estimation Models
A drone’s onboard sensors (GPS, accelerometers, gyroscopes, magnetometers) provide noisy and imperfect data about its state (position, velocity, orientation). Mathematical models, particularly those based on probabilistic frameworks like Kalman filters or Extended Kalman Filters (EKF), are used to fuse these diverse sensor inputs. These models statistically combine sensor measurements with the drone’s dynamic model predictions to estimate the true state more accurately than any single sensor could provide alone. This robust state estimation is absolutely critical for stable autonomous flight, accurate navigation, and reliable obstacle avoidance, forming the backbone of a drone’s situational awareness.
Shaping Reality: Models for Mapping and Remote Sensing
Drones equipped for mapping and remote sensing exemplify another domain where mathematical models are not just useful, but fundamental to extracting actionable insights from raw data. The transformation of aerial imagery into precise 2D maps, 3D models, or environmental data relies heavily on complex mathematical frameworks.
Photogrammetry and 3D Reconstruction Models
Photogrammetry, the science of making measurements from photographs, is a key application. Mathematical models of camera geometry (focal length, sensor size, lens distortions) and drone trajectory are used to accurately reconstruct the 3D structure of terrain and objects from overlapping 2D images. Structure-from-Motion (SfM) algorithms, for instance, employ intricate mathematical optimizations to simultaneously determine camera positions and orientations for thousands of images, alongside the 3D coordinates of millions of points in the environment. These models correct for perspective distortions, lens aberrations, and variations in drone altitude and attitude to produce highly accurate and dense point clouds, which are then converted into digital elevation models (DEMs), orthomosaics, and textured 3D meshes.
Remote Sensing Data Interpretation Models
Beyond geometry, drones with specialized sensors (e.g., thermal, multispectral, hyperspectral) capture data that requires mathematical models for interpretation. These models are used to convert raw sensor readings into meaningful physical quantities. For instance, in agriculture, mathematical models relate spectral reflectance values (captured by multispectral cameras) to crop health indicators like Normalized Difference Vegetation Index (NDVI), biomass, or water stress. Atmospheric correction models are essential to remove the effects of haze and aerosols, ensuring that the measured reflectance truly represents the ground target. For thermal imaging, mathematical models convert raw pixel values into accurate temperature readings, accounting for emissivity and atmospheric transmission. These interpretative models are crucial for applications ranging from precision agriculture and environmental monitoring to infrastructure inspection.
The Intelligence Behind AI and Decision Making
The “AI Follow Mode” and broader autonomous decision-making capabilities of modern drones are direct manifestations of mathematical models integrated within artificial intelligence frameworks. AI algorithms themselves are, at their heart, sophisticated mathematical models.
Machine Learning Models for Object Recognition and Tracking
AI Follow Mode relies on computer vision algorithms, which are built upon complex mathematical models. Convolutional Neural Networks (CNNs), a type of deep learning model, use mathematical operations (convolutions, activations, pooling) to learn hierarchical features from image data. These models are trained on vast datasets to recognize and track specific objects (e.g., a person, a vehicle) in real-time from the drone’s camera feed. The output of these models provides the necessary information—the target’s position, velocity, and identity—to the drone’s control system, allowing it to autonomously follow the designated subject.
Predictive Models for Trajectory and Path Planning
Beyond simple following, advanced autonomous flight often involves predicting the future behavior of dynamic objects or planning optimal paths in changing environments. Mathematical models within AI systems are used for this predictive analytics. For instance, a drone might use a Kalman filter to predict the future position of a moving target based on its current and past trajectory. For obstacle avoidance or dynamic path planning, mathematical optimization models are employed to find the safest and most efficient path through a complex, potentially changing, 3D space, balancing objectives like speed, energy consumption, and collision risk. These models dynamically recalculate paths based on real-time sensor data and environmental predictions, enabling truly intelligent autonomous operation.
The Continuous Evolution of Mathematical Modeling
As drone technology continues to push the boundaries of “Tech & Innovation,” the role of mathematical models will only grow in importance. Future advancements in autonomous flight, hyper-accurate mapping, and sophisticated AI will be inextricably linked to the development of more complex, robust, and computationally efficient mathematical models. From quantum-inspired optimization for route planning to novel statistical models for sensor fusion in GPS-denied environments, and even advanced topological data analysis for understanding complex spatial relationships, mathematical modeling remains the essential language for innovation. It empowers engineers to abstract the physical world into solvable problems, paving the way for the next generation of intelligent, autonomous, and impactful drone applications that reshape how we perceive and interact with our world.