
Sir Isaac Newton’s three laws of motion form the bedrock of classical mechanics, providing the fundamental principles that govern the movement of every object in the universe, from planets orbiting stars to the intricate dance of a modern drone in the sky. For the realm of flight technology, these laws are not mere academic concepts; they are the engineering commandments that dictate design, performance, stability, and control across all aerial platforms, from sophisticated autonomous systems to high-performance racing drones. Understanding these laws is essential for comprehending how flight systems navigate, stabilize, and execute complex maneuvers, making them indispensable to anyone involved in the design or operation of advanced aerial vehicles.

The Foundation of Flight: Newton’s First Law (Inertia) in Aviation
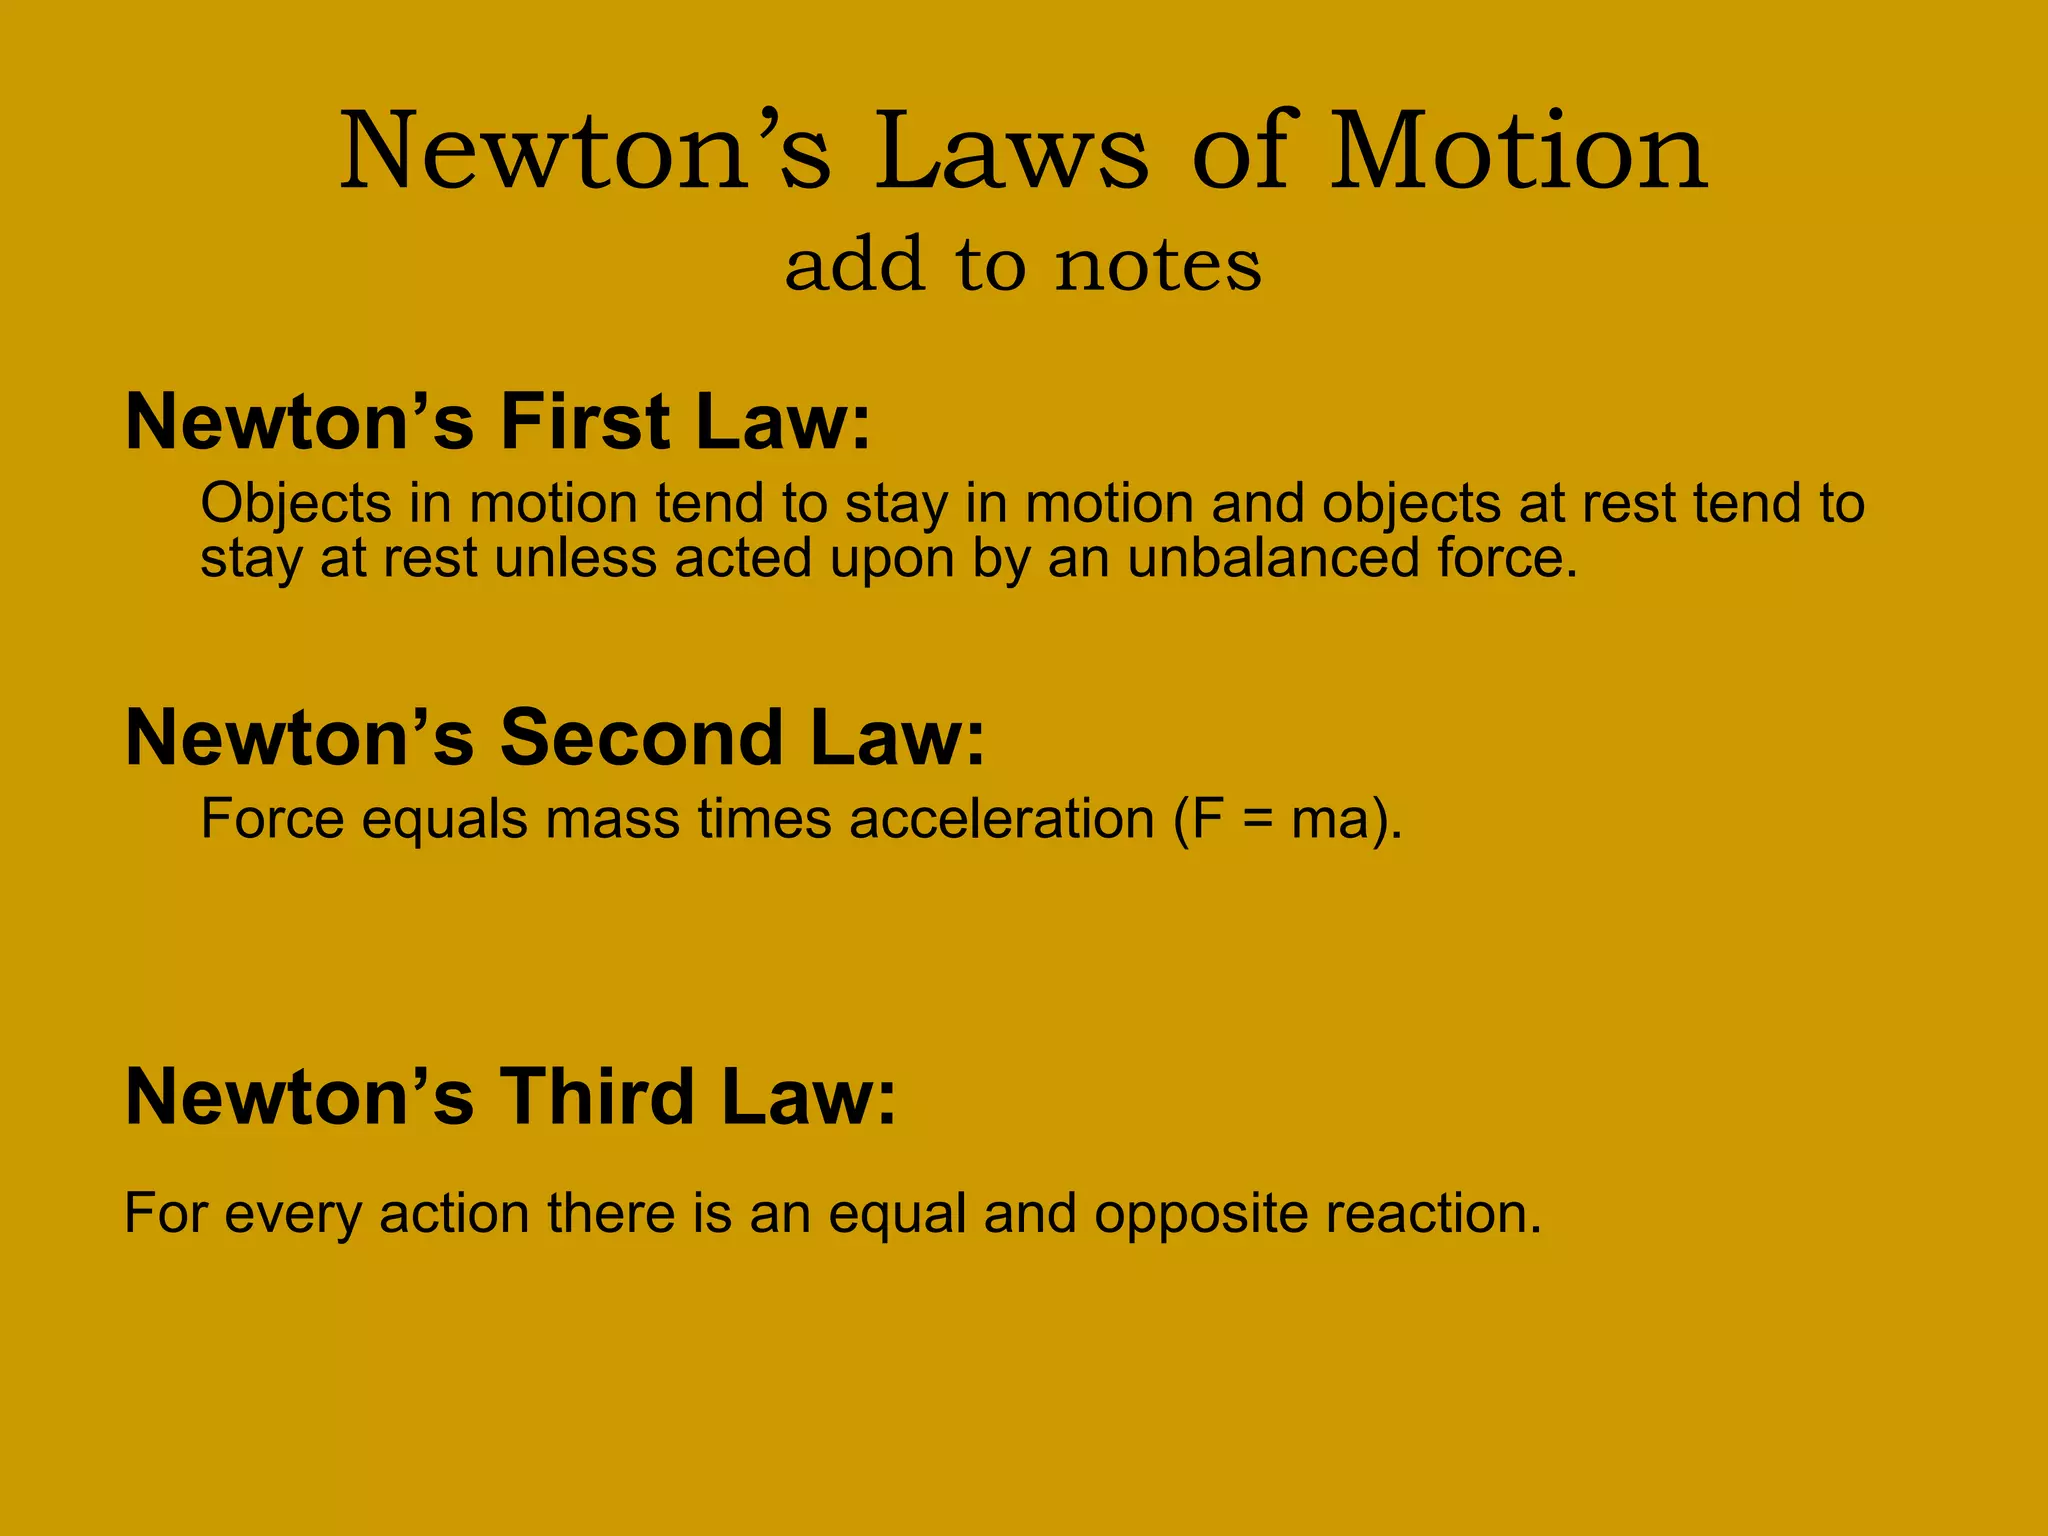
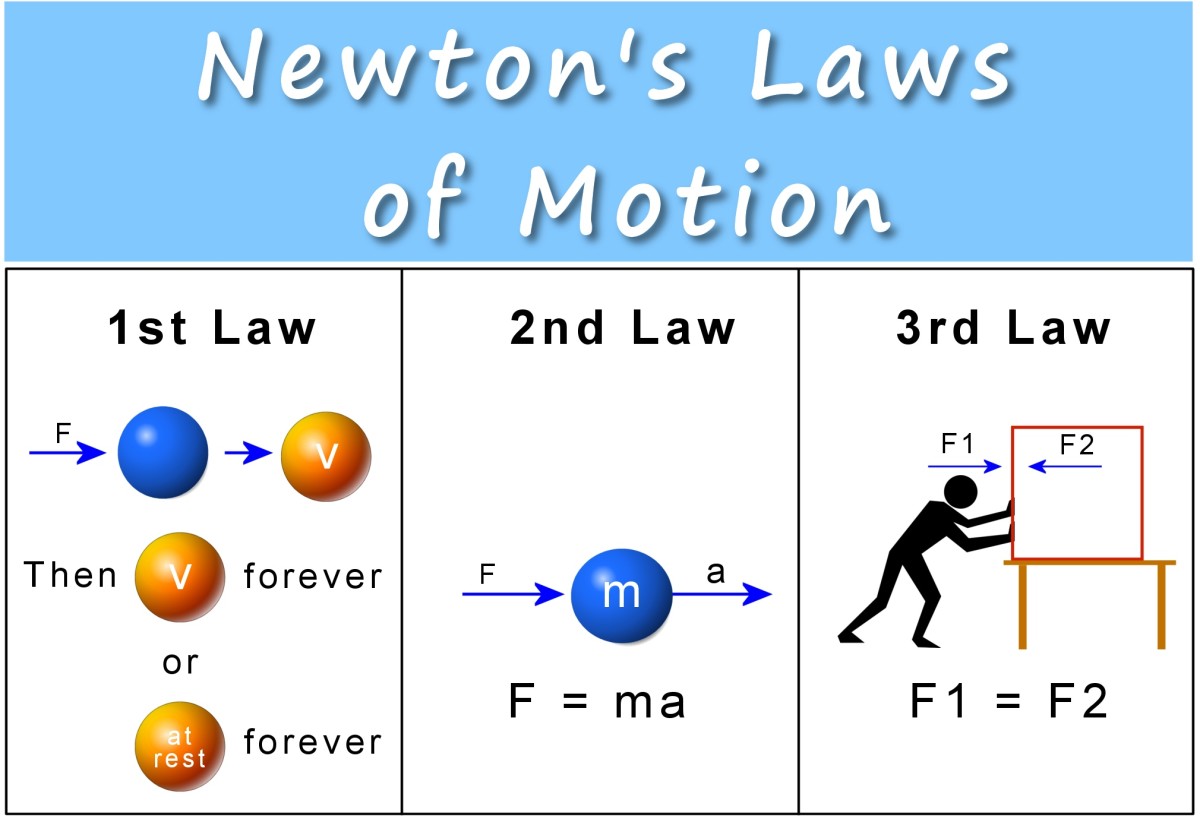
Newton’s First Law, often referred to as the Law of Inertia, states that an object at rest will stay at rest, and an object in motion will stay in motion with the same speed and in the same direction, unless acted upon by an unbalanced external force. This principle is not just observable in everyday life; it is a critical consideration in the engineering and operational dynamics of all flight technology.
Maintaining Course: Inertia and Stable Flight Paths
In the context of flight technology, the law of inertia explains why an aircraft or drone, once airborne and achieving a stable velocity, tends to maintain that velocity and direction. While this might seem intuitive, it underscores the constant battle against external forces that seek to alter that state of motion. For a drone hovering in place, its state is “at rest” relative to the air around it. Any gust of wind represents an unbalanced external force that will attempt to shift its position. Advanced flight controllers and Inertial Measurement Units (IMUs) continuously sense these disturbances and command motor adjustments to generate counter-forces, bringing the drone back to its desired static position, effectively “resisting” the change in motion dictated by inertia. Similarly, when a drone is flying at a constant speed and altitude, its flight control system works to maintain that state, overcoming air resistance and minor atmospheric fluctuations to prevent deviation from its intended trajectory. This constant corrective action is a direct application of overcoming inertia to maintain a stable flight path.
Overcoming Resistance: Propulsion and Initial Movement
Inertia also dictates the need for propulsion to initiate movement and to sustain it against resistive forces. An aircraft on a runway or a drone on the ground is “at rest.” To overcome this inertia and begin moving, a significant amount of thrust must be generated by its engines or propellers. This initial acceleration phase is a clear demonstration of an unbalanced force (thrust) acting on the mass of the vehicle to change its state from rest to motion. Once airborne, to maintain a constant velocity, the flight system must continuously generate enough thrust to precisely counteract the drag and air resistance forces. If thrust equals drag, the net force is zero, and the vehicle maintains a constant velocity – a perfect illustration of the First Law at work, where the “object in motion” continues “with the same speed and in the same direction.” Any reduction in thrust below the drag force will lead to deceleration, while an increase will lead to acceleration, both changes in motion requiring an unbalanced force.
Force, Mass, and Acceleration: Newton’s Second Law Driving Flight Dynamics
Newton’s Second Law of Motion is arguably the most quantitative of the three, stating that the acceleration of an object is directly proportional to the net force acting upon it and inversely proportional to its mass (F=ma). This mathematical relationship is fundamental to understanding how flight vehicles accelerate, decelerate, climb, descend, and maneuver, directly linking the power systems to the dynamic response of the aircraft.
Thrust and Lift Generation: Engineering the ‘F=ma’
For any flight system, the generation of thrust and lift are direct manifestations of F=ma. Propellers, jet engines, or rotor blades generate force by expelling air or gas. The magnitude of this force (F) directly determines the acceleration (a) of the aircraft, given its mass (m). For a multirotor drone, increasing the speed of the propellers generates more thrust. If this collective thrust exceeds the drone’s weight (force due to gravity), there is a net upward force, causing the drone to accelerate upwards (climb). Conversely, reducing thrust below weight results in downward acceleration (descent). When flying forward, the horizontal component of thrust must be greater than aerodynamic drag to accelerate the drone in that direction. Engineering teams meticulously design propulsion systems – including motor power, propeller geometry, and battery capacity – to achieve specific thrust-to-weight ratios, ensuring the drone can achieve desired accelerations for takeoff, climbing, and agile flight, all governed by F=ma.
Dynamic Control and Agility: Responding to Operator Inputs
The Second Law is also paramount in dictating the agility and responsiveness of a flight system. When an operator commands a drone to pitch forward, the flight controller rapidly adjusts the speeds of specific motors, creating an unbalanced torque and a net force that causes the drone to rotate and accelerate in the desired direction. The speed at which this maneuver can be executed (the acceleration) is directly dependent on how quickly and effectively the propulsion system can generate the necessary forces. High-performance racing drones, for instance, are designed with exceptionally low mass relative to their thrust capabilities, allowing them to achieve extreme accelerations and decelerations, enabling lightning-fast changes in direction and velocity that are critical for competitive advantage. The instantaneous manipulation of forces to induce precise accelerations across multiple axes is the essence of modern flight control.
Payload and Performance: Mass Considerations in Drone Design
The inverse relationship between mass and acceleration highlighted by F=ma is crucial in payload management and aircraft design. Adding mass to a drone – be it a camera, a sensor package, or cargo – directly reduces the acceleration it can achieve for a given amount of thrust. This means heavier drones will climb slower, accelerate less rapidly, and consume more energy to maintain altitude or speed. Engineers must carefully balance structural integrity and mission-specific requirements with the desire for agility and endurance, always considering the impact of mass on performance governed by Newton’s Second Law. The maximum payload capacity of a UAV is a direct calculation of the additional mass it can carry while still generating sufficient force to overcome gravity and perform its intended functions within acceptable acceleration limits.
Action and Reaction: Newton’s Third Law Powering Propulsion and Stabilization
Newton’s Third Law states that for every action, there is an equal and opposite reaction. This deceptively simple principle is the fundamental mechanism behind all forms of propulsion in flight, dictating how aircraft generate the necessary forces to lift off and maneuver, and also profoundly influencing stabilization systems.
Propeller Thrust: Expelling Air for Forward Motion
The most evident application of Newton’s Third Law in flight technology is the generation of thrust by propellers and jet engines. A propeller blade, designed with an airfoil shape, acts as a rotating wing. As it spins, it pushes a mass of air downwards and/or backwards (the action). According to the Third Law, this action generates an equal and opposite reaction force, which is the upward or forward thrust that propels the aircraft. For a quadcopter, each propeller pushes air downwards, creating an upward reaction force (lift). By carefully controlling the speed of each individual propeller, the flight controller can generate differential lift and thrust vectors across the drone, allowing it to move in any direction, rotate, or hover stably. Similarly, a jet engine expels hot gases at high velocity backwards (action), generating an equal and opposite forward thrust (reaction) that propels the aircraft.
Gyroscopic Stability and Control Surfaces: Counteracting Forces
While not a direct application of propulsion, the Third Law is also at play in the physics governing gyroscopic effects and stabilization systems. Though flight control surfaces (like ailerons, rudders, elevators on fixed-wing aircraft) and propeller pitch changes (on helicopters) redirect airflow to create forces that cause the aircraft to rotate or translate, the underlying principle is the same: the air exerting force on the control surface is an action, and the reaction is the force exerted by the control surface on the air, which in turn causes the aircraft to move. Even in advanced stabilization, when a drone experiences an unwanted rotation (e.g., due to wind), its IMU detects this action, and the flight controller commands the propellers to create an opposing rotational force (reaction) to counteract it, returning the drone to its desired orientation.
Vectoring Thrust: Advanced Maneuverability
Advanced flight technologies, particularly in VTOL (Vertical Take-Off and Landing) aircraft and some high-performance drones, utilize thrust vectoring – the ability to direct the angle of the engine’s thrust. This allows for incredibly agile maneuvers, where the direction of the expelled air (action) can be precisely controlled to generate reaction forces in specific directions, enabling faster turns, sideways flight, or even highly dynamic acrobatic movements. The precision control over the “action” of expelling air directly translates to precision control over the “reaction” force acting on the aircraft, expanding the envelope of flight performance.
Integrating Newton’s Laws into Modern Flight Technology
The seamless integration of Newton’s laws is the cornerstone of modern flight technology. From the initial design phase to the real-time execution of complex flight missions, these principles are continuously at play, interpreted and managed by sophisticated electronic systems.
Inertial Measurement Units (IMUs) and Sensor Fusion
IMUs, comprising accelerometers and gyroscopes, are fundamental to modern flight control. Accelerometers directly measure the acceleration (F/m) of the aircraft, providing data for Newton’s Second Law. Gyroscopes measure angular velocity, indicating changes in orientation, which are constantly monitored to detect deviations from desired states, directly addressing Newton’s First Law. Sensor fusion algorithms combine this data with GPS, magnetometers, and barometers to provide the flight controller with a comprehensive understanding of the aircraft’s state of motion, enabling it to calculate the precise forces required to maintain stability or execute maneuvers in accordance with all three laws.
Autonomous Flight Algorithms and Predictive Control
Autonomous flight systems leverage Newton’s laws to predict future states and plan optimal trajectories. For example, knowing the drone’s current mass, velocity, and the forces its propulsion system can generate (F=ma), an autonomous algorithm can calculate the exact thrust adjustments needed to reach a waypoint, avoid an obstacle, or perform a soft landing. Predictive control systems use these physical laws to anticipate how external forces (like wind shear) will affect the drone’s motion and proactively apply corrective forces, ensuring stable and efficient flight even in challenging conditions.
Obstacle Avoidance and Dynamic Re-routing
Even in sophisticated features like obstacle avoidance, Newton’s laws dictate the practical limits and requirements. When an obstacle is detected, the drone must decelerate and potentially accelerate in a new direction. The speed at which it can do this safely is constrained by its mass and the maximum forces its propulsion system can generate (Newton’s Second Law). The flight path planning algorithms must factor in these physical limitations, ensuring that any re-routing maneuver adheres to the drone’s dynamic capabilities, which are fundamentally governed by Newton’s laws of motion.
In conclusion, Newton’s three laws of motion are not merely historical scientific tenets but living, breathing principles that are engineered into every component and line of code within contemporary flight technology. They empower engineers to design robust, agile, and intelligent aerial vehicles, making the skies a stage for endless innovation driven by the timeless laws of physics.