
The intricate dance of autonomous flight, the precision of a stable hover, or the fluid motion of a drone capturing breathtaking aerial footage – these feats are not achieved by chance. They are the result of sophisticated flight technology, a complex interplay of hardware and software components working in concert, much like the different parts of a brain coordinating an organism’s actions. To truly understand how modern drones operate, one must delve into the “nervous system” of their flight technology, identifying which critical components control what aspects of their remarkable capabilities.
The Central Command: Flight Controllers and Their Processors
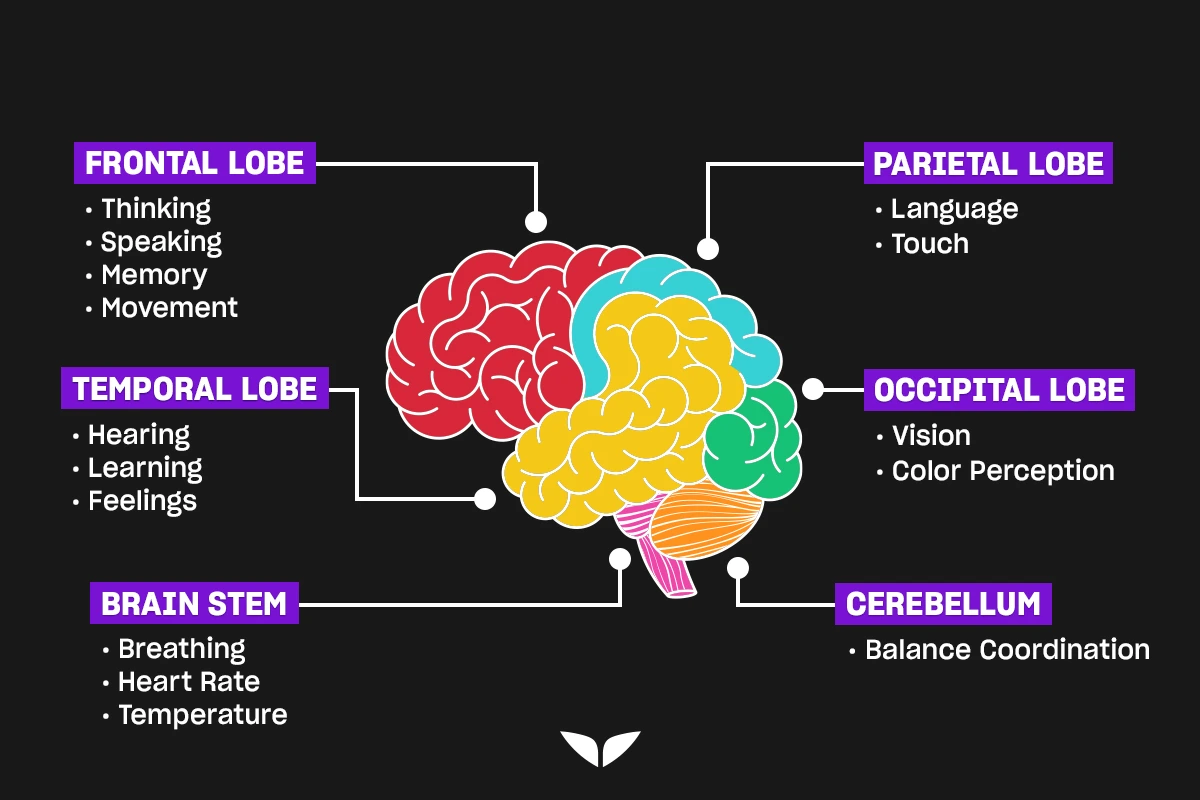
At the core of any advanced drone’s flight technology lies the flight controller (FC). This single board serves as the central processing unit, the “brain stem” and “cerebellum” rolled into one, responsible for interpreting commands, processing data, and executing the myriad calculations necessary for stable and controlled flight. Without it, a drone would be an inert collection of parts.
The Microcontroller Unit (MCU): Processing Power
The heart of the flight controller is its Microcontroller Unit (MCU). This tiny yet powerful computer chip is tasked with an immense workload: reading input from multiple sensors hundreds, if not thousands, of times per second; executing complex algorithms for stabilization, navigation, and control; and outputting precise commands to the drone’s motors. For instance, in a quadcopter, the MCU continuously adjusts the speed of each individual motor to maintain altitude, direction, and attitude, responding instantly to environmental changes or pilot input. The speed and efficiency of the MCU directly impact the drone’s responsiveness and stability, especially in dynamic environments or during high-performance maneuvers. Modern FCs often employ 32-bit MCUs running at high clock speeds, capable of handling sophisticated control loops and complex computational tasks required for autonomous flight and advanced features like object tracking or intelligent flight modes.
Firmware and Software: The Operational Intelligence
While the MCU provides the raw processing power, it is the firmware and associated software that imbue the flight controller with intelligence. Firmware, such as ArduPilot, PX4, or Betaflight, is the low-level operating system that defines the drone’s fundamental behavior. It contains the control algorithms (PID controllers for stabilization), safety protocols, and the logic for various flight modes (e.g., GPS hold, altitude hold, manual, acrobatic). This is akin to the instinctual and learned responses stored within a biological brain. Beyond the core firmware, higher-level software applications, often running on a companion computer or a ground control station (GCS), provide capabilities for mission planning, waypoint navigation, remote sensing data processing, and advanced artificial intelligence (AI) functions like object recognition or obstacle avoidance planning. These software layers collectively dictate the drone’s capabilities, from simple line-of-sight flying to complex autonomous missions, forming the “cognitive functions” that elevate a drone from a simple machine to an intelligent aerial platform.
Sensory Perception: Understanding the Environment
For a drone to fly autonomously, navigate safely, or maintain a stable position, it must first be able to “perceive” its environment and its own state within that environment. This crucial role is performed by an array of sophisticated sensors, acting as the drone’s eyes, ears, and proprioceptors.
Inertial Measurement Units (IMUs): Orientation and Motion
The cornerstone of drone stabilization is the Inertial Measurement Unit (IMU). Comprising accelerometers and gyroscopes, the IMU provides essential data about the drone’s orientation and motion in three-dimensional space. Accelerometers detect linear acceleration along the X, Y, and Z axes, informing the flight controller about gravity and translational movements. Gyroscopes measure angular velocity, or the rate of rotation around these axes, which is critical for understanding pitch, roll, and yaw. By continuously fusing data from these two types of sensors, the flight controller can determine the drone’s current attitude with remarkable precision, enabling it to counteract disturbances (like wind) and maintain a level flight or execute precise maneuvers. Without accurate IMU data, stable flight would be impossible, as the drone would quickly lose orientation and become uncontrollable.
Barometers and GPS: Altitude and Position
While the IMU handles orientation, barometers and Global Positioning System (GPS) modules provide vital information regarding the drone’s absolute altitude and global position. A barometer measures atmospheric pressure, which correlates directly with altitude. This allows the drone to maintain a consistent height above the ground, particularly useful for tasks requiring precise altitude control or for avoiding ground collisions during descent. GPS, on the other hand, provides highly accurate latitude, longitude, and ground speed data. By triangulating signals from multiple satellites, the GPS module enables drones to perform functions like waypoint navigation, return-to-home capabilities, and maintain a fixed position (GPS hold) even in windy conditions. The combination of barometer and GPS data is fundamental for complex autonomous missions where precise spatial awareness is paramount.
Vision and Ranging Sensors: Proximity and Obstacle Avoidance
To operate safely in complex environments, drones increasingly rely on vision and ranging sensors. Ultrasonic sensors, similar to those used by bats, emit sound waves and measure the time it takes for them to return, providing short-range distance measurements ideal for precise hovering close to the ground or obstacle detection. LiDAR (Light Detection and Ranging) sensors use laser pulses to create detailed 3D maps of the environment, offering superior accuracy and range for obstacle avoidance and mapping applications. Optical flow sensors, typically downward-facing cameras, track movement on the ground to provide highly accurate positional data in GPS-denied environments (like indoors) or at low altitudes. Stereo vision cameras, mimicking human eyes, capture two images from slightly different angles, allowing the drone to calculate depth and identify obstacles with high fidelity, paving the way for advanced obstacle avoidance and autonomous navigation in complex, dynamic spaces.
Magnetometers: Heading and Direction
Often referred to as a compass, the magnetometer detects the Earth’s magnetic field to provide the drone with its absolute heading. While gyroscopes measure angular rotation, they can drift over time. The magnetometer provides a fixed reference point, allowing the flight controller to correct for this drift and maintain an accurate sense of direction. This is crucial for precise navigation, executing turns, and ensuring that autonomous flight paths are followed correctly. Without a reliable magnetometer, a drone might veer off course, especially during long-distance missions or in scenarios requiring accurate compass-based movements.
The Motor System: Actuation and Movement
Just as muscles translate neurological commands into physical action, a drone’s motor system transforms electrical signals from the flight controller into the physical forces of thrust and lift, propelling the aircraft through the air and enabling its every movement.

Electronic Speed Controllers (ESCs): Powering Propulsion
Electronic Speed Controllers (ESCs) are the vital link between the flight controller and the brushless motors. They receive signals from the FC, interpreting the desired motor speed and direction, and then convert the drone’s battery power into the precise three-phase electrical current required to drive the motors. Each motor typically has its own ESC, allowing for independent control of thrust. The efficiency and responsiveness of the ESCs are paramount for smooth and precise flight, as any delay or inconsistency in motor control can lead to instability or reduced performance. Advanced ESCs incorporate sophisticated algorithms to optimize motor performance, improve efficiency, and protect against overcurrent or overheating.
Motors and Propellers: Generating Thrust and Lift
The brushless motors, coupled with appropriately designed propellers, are the primary actuators that generate thrust and lift. The flight controller, via the ESCs, modulates the rotational speed of each motor. By precisely varying the speed of individual motors, the drone can achieve a multitude of movements:
- Ascent/Descent: Increasing or decreasing the collective thrust of all motors.
- Pitch (Nose Up/Down): Adjusting the thrust of front and rear motors differentially.
- Roll (Tilt Left/Right): Adjusting the thrust of side motors differentially.
- Yaw (Rotate Left/Right): Exploiting the torque reaction of the propellers. For a quadcopter, this is achieved by spinning two diagonal motors slightly faster and the other two diagonal motors slightly slower, exploiting their opposite rotational directions to induce a net torque.
The design of the propellers—their diameter, pitch, and number of blades—is critical for efficiency, thrust generation, and overall flight characteristics, directly influencing the drone’s speed, lift capacity, and battery life.
Communication and Interface: The Peripheral Nervous System
For a drone to be controlled, whether by a human pilot or an autonomous system, there must be robust communication channels. These systems act as the “peripheral nerves,” transmitting commands and receiving vital feedback.
Radio Transmitters and Receivers: Pilot Input
The primary means of human control for most drones involves a radio transmitter held by the pilot and a receiver on board the drone. The transmitter converts pilot stick movements and switch actuations into radio signals, which are then wirelessly sent to the drone’s receiver. The receiver decodes these signals and relays them to the flight controller, translating human intent into actionable commands. Different radio protocols (e.g., SBUS, PPM, CRSF) offer varying levels of latency, range, and reliability, directly impacting the responsiveness and control fidelity experienced by the pilot.
Telemetry Modules: Real-time Feedback
Beyond receiving commands, a critical aspect of drone operation is the ability to send data back to the ground. Telemetry modules facilitate this two-way communication, transmitting real-time flight data such as battery voltage, altitude, GPS coordinates, speed, and even camera gimbal status back to the pilot’s remote control or a ground control station. This feedback is invaluable for monitoring the drone’s health, ensuring safe operation, and making informed decisions during flight, much like sensory feedback informs a biological brain.
Ground Control Stations (GCS) and Apps: User Interface
For more complex operations, especially autonomous missions, Ground Control Stations (GCS) – software applications running on laptops, tablets, or smartphones – provide a comprehensive interface for interacting with the drone. A GCS allows operators to plan intricate flight paths, define waypoints, set mission parameters, monitor all telemetry data on a map, and even control camera functions. These applications transform raw data into an intuitive visual representation, empowering operators to manage sophisticated aerial tasks with ease and precision.
Advanced Cognitive Functions: Autonomy and Intelligence
As drone technology evolves, flight systems are moving beyond mere stabilization and control to embody higher-level “cognitive functions,” enabling greater autonomy and intelligent decision-making, akin to the frontal lobe in a biological brain.
Autonomous Navigation and Waypoint Following
Leveraging GPS, barometers, and sophisticated path-planning algorithms, drones can execute fully autonomous missions based on pre-programmed waypoints. The flight controller uses the positional data to guide the drone along a specified path, adjusting for environmental factors and ensuring precise execution of the mission. This capability is fundamental for applications like aerial surveying, infrastructure inspection, and precision agriculture, where repeatability and accuracy are paramount.
Object Recognition and Tracking
Equipping drones with advanced vision systems and onboard AI processors enables them to identify and track specific objects or individuals in real time. This “smart vision” allows for features like “follow-me” mode, where the drone autonomously tracks a subject, or intelligent search-and-rescue operations where it can identify specific targets. The AI processes visual data, learns patterns, and makes dynamic flight adjustments to maintain tracking, showcasing a sophisticated level of environmental interaction.
Simultaneous Localization and Mapping (SLAM)
For operating in GPS-denied or unknown environments, SLAM algorithms allow drones to build a map of their surroundings while simultaneously localizing themselves within that newly created map. Using a combination of vision, LiDAR, or other ranging sensors, the drone continuously gathers data, processes it to understand its position relative to known features, and updates its environmental map. This represents a significant step towards truly autonomous exploration and operation in complex, dynamic spaces, much like an animal exploring and mapping its territory.
Adaptive Control and Self-Correction
Modern flight technology incorporates adaptive control algorithms that enable drones to learn and adjust their flight parameters in real-time. This means the drone can compensate for changes in payload, wear and tear on components, or unexpected environmental disturbances like strong wind gusts. By continuously monitoring its performance and comparing it against desired outcomes, the flight controller can “learn” and refine its control loops, leading to more stable, efficient, and resilient flight even under challenging conditions. This self-correction capability mirrors the brain’s ability to adapt motor skills based on feedback, ensuring optimal performance and safety across a wide range of operational scenarios.
In essence, the “brain” of a drone’s flight technology is a marvel of engineering, a highly integrated system where each component plays a specific, indispensable role. From the raw processing power of the MCU to the keen perception of its sensors, the precise actuation of its motors, and the intelligent decision-making of its software, these parts collectively enable the complex behaviors and remarkable capabilities that define modern unmanned aerial systems. Understanding this intricate internal control system is key to appreciating the profound impact drones are having across countless industries and applications.