
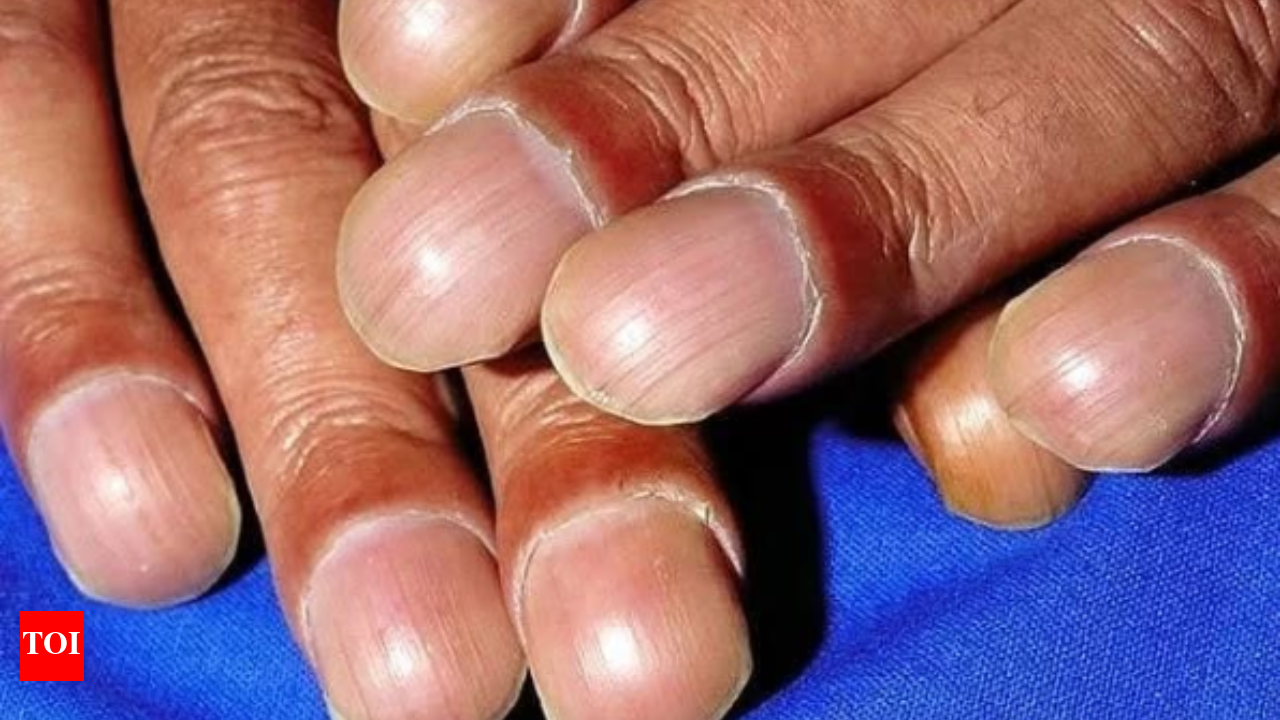
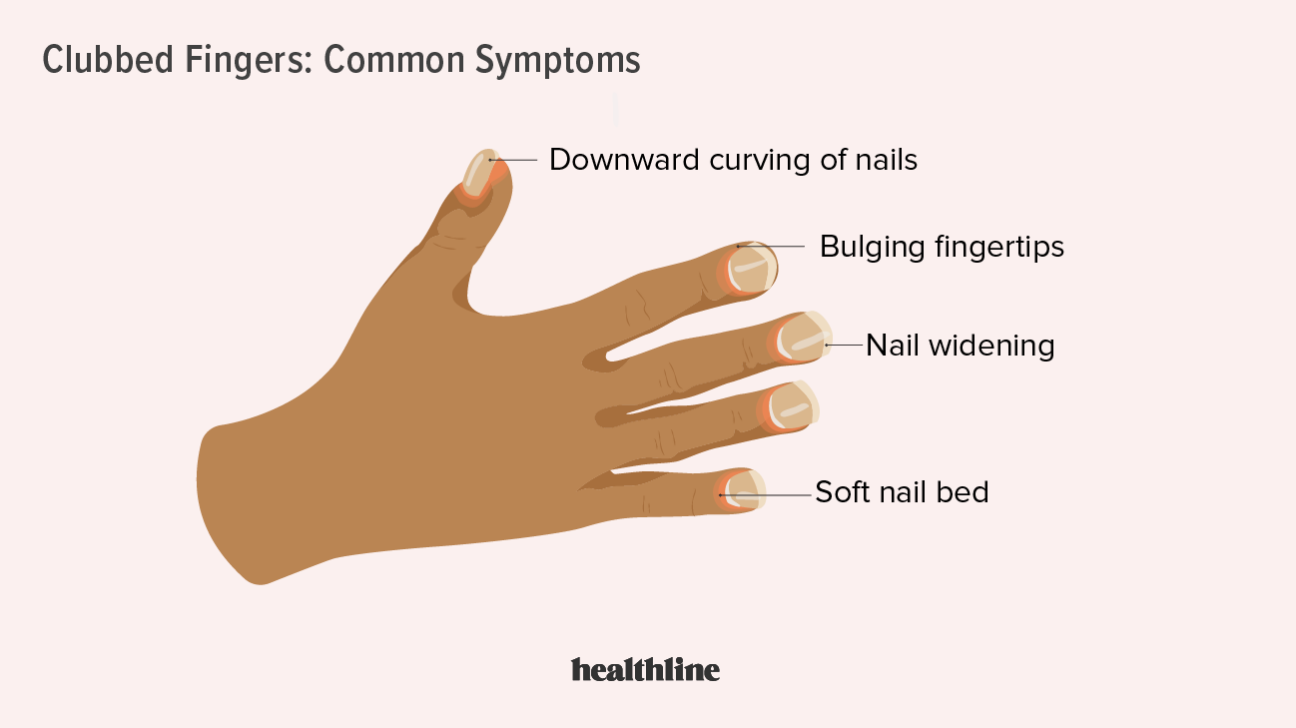
In the intricate world of advanced flight technology, precision, reliability, and autonomy are paramount. Unmanned Aerial Vehicles (UAVs) rely on a symphony of sensors, sophisticated algorithms, and robust flight systems to navigate complex environments, perform intricate maneuvers, and execute critical missions. When we consider the human body, the term “clubbing of fingers” refers to a specific physical change, a visible symptom often indicative of an underlying health issue affecting systemic processes. Paradoxically, a similar concept, a kind of “digital clubbing,” can manifest in drone flight systems – a subtle yet critical anomaly in sensor data that, if not understood and mitigated, can severely compromise performance and safety.

This article delves into what “clubbing of fingers” metaphorically means in the context of flight technology, identifying it as a phenomenon where multiple sensor data streams, instead of providing independent and accurate inputs, exhibit correlated errors or biases, leading to a distorted perception of the drone’s state or environment. Much like a medical diagnosis, recognizing this digital “clubbing” is crucial for maintaining the health and operational integrity of sophisticated UAVs.
The Phenomenon of Sensor Data “Clubbing”
The backbone of any advanced UAV is its sensor array, which includes GPS, Inertial Measurement Units (IMUs), altimeters, vision systems, and obstacle detection sensors. These components act as the “fingers” of the drone, each providing unique data points that, when fused, create a comprehensive understanding of the aircraft’s position, attitude, and surroundings. However, when these distinct data streams begin to show similar, yet erroneous, deviations – a digital “clubbing” – the integrity of this understanding is compromised.
Discrepancy in Redundant Sensor Systems
Modern UAVs employ redundant sensor systems to enhance reliability. For instance, multiple GPS receivers, or a combination of GPS with RTK (Real-Time Kinematic) or PPK (Post-Processed Kinematic) systems, aim to provide superior positional accuracy. Similarly, IMUs often contain redundant accelerometers and gyroscopes. The principle is that if one sensor provides faulty data, others can compensate or act as a check. However, “clubbing” emerges when these ostensibly independent or redundant sensors start failing in a correlated manner. This could be due to shared environmental interference (e.g., electromagnetic noise affecting multiple digital compasses simultaneously), a systemic software bug applying a consistent bias to readings, or even subtle manufacturing defects within a batch of sensors. Instead of revealing discrepancies that can be corrected, the “clubbed” data streams present a unified, but inaccurate, front.
Data Fusion Challenges and Misinterpretation
Flight controllers rely on complex data fusion algorithms, such as Kalman filters, to synthesize information from various sensors into a single, reliable estimate of the drone’s state. When “clubbing” occurs, these algorithms face a significant challenge. Instead of uncorrelated noise or distinct outliers that can be easily filtered or rejected, the system receives multiple “fingered” inputs that appear consistent with each other, but are collectively wrong. The fusion algorithm might then interpret this grouped anomaly as a true state, believing it has a highly confident measurement, when in fact, it is confidently wrong. This misinterpretation can cascade through the entire flight system, affecting everything from basic stability to complex autonomous operations.
Operational Impact on UAV Performance
The consequences of “clubbing” in sensor data are far-reaching, directly impacting the fundamental capabilities of a drone. From precise navigation to stable imaging, every aspect of performance can degrade.
Compromised Navigation and Position Hold
One of the most critical impacts of sensor “clubbing” is on navigation. If GPS signals, even from multiple receivers, are collectively biased by satellite signal degradation, multipath errors, or spoofing attempts, the drone’s perceived geographical position can drift significantly. This poses a severe risk for applications requiring high precision, such as mapping, surveying, agricultural spraying, or autonomous delivery systems. A drone programmed to follow a centimeter-accurate flight path might stray metres off course, potentially leading to inaccurate data collection, collisions with obstacles, or violation of airspace regulations. Similarly, maintaining a stable position in “position hold” mode becomes challenging, leading to undesirable drifts and constant corrections that consume power and reduce operational efficiency.
Instability in Flight Control and Stabilization
The stability of a UAV is intricately linked to its IMU data. Accurate readings from accelerometers and gyroscopes are vital for the flight controller to understand the drone’s attitude (roll, pitch, yaw) and apply corrective actions to maintain a level and stable flight. If IMU data suffers from “clubbing” – for example, if multiple redundant gyroscopes are all subtly biased by temperature fluctuations or vibrations – the drone’s estimated attitude will be consistently incorrect. This can manifest as persistent, subtle wobbles, unwanted drifts, or even jerky movements as the flight controller attempts to stabilize based on flawed information. For aerial cinematography, this translates into jittery footage, making smooth, cinematic shots impossible. For industrial inspections, it can lead to blurry images and missed defects.
Obstacle Avoidance System Degradation
Obstacle avoidance systems are essential for safe autonomous flight, relying on sensors like LIDAR, ultrasonic, and vision cameras to detect objects in the drone’s path. If these various distance sensors were to experience a form of “clubbing” – for instance, widespread environmental interference causing them all to register a false positive at a certain range, or a shared blind spot due to payload obstruction – the drone’s perception of its surroundings would be dangerously flawed. It might falsely detect an obstacle where none exists, leading to unnecessary evasive maneuvers, or worse, fail to detect a real threat because the “clubbed” data masks it. The integrity of obstacle maps and real-time collision detection relies on truly independent and accurate sensor inputs.
Advanced Strategies to Prevent and Diagnose “Clubbing”
Mitigating the risks of “clubbing” requires a multi-faceted approach, integrating advanced hardware, sophisticated software, and diligent operational practices.
Multi-Modal Sensor Redundancy and Diversity
True resilience against “clubbing” doesn’t just come from adding more of the same sensor; it comes from diversity. Implementing multi-modal redundancy means integrating different types of sensors whose failure modes are independent. For example, complementing GPS/RTK with visual odometry, optical flow sensors, and even barometric altimeters means that a singular issue affecting one sensor type is less likely to affect others. A sophisticated flight controller can then cross-reference these diverse inputs, quickly identifying when a particular “finger” (or a group of similar “fingers”) shows signs of “clubbing” by comparing it against data from unaffected, dissimilar sensors.
Intelligent Data Fusion and Anomaly Detection
Next-generation flight control systems are incorporating more intelligent data fusion algorithms. These are not merely averaging sensor readings but employing machine learning and AI techniques to detect subtle patterns of anomaly. Such systems can learn what “normal” sensor behavior looks like across various flight conditions and instantaneously flag deviations that suggest “clubbing.” Advanced Kalman filters can be tuned with adaptive noise covariance, allowing them to dynamically adjust their trust in sensor readings based on real-time statistical analysis and outlier rejection. This allows for real-time diagnosis, enabling the system to temporarily deprioritize or compensate for “clubbed” sensor data until the issue is resolved.
Pre-Flight Diagnostics and Calibration
Prevention is often the best cure. Comprehensive pre-flight diagnostic routines are critical for identifying potential “clubbing” symptoms before the drone even leaves the ground. Automated checks can analyze sensor data consistency, look for persistent biases or drifts when the drone is stationary, and perform calibration sequences that ensure all “fingers” (sensors) are accurately tuned and reporting within expected parameters. Regularly updated firmware and calibration files are also crucial, addressing known sensor quirks and environmental compensation profiles.
The Future of Resilient Flight Systems
The concept of “clubbing of fingers” in flight technology underscores the continuous pursuit of fault tolerance and intelligent system design. As drones become more autonomous and operate in increasingly complex and safety-critical environments, the ability to self-diagnose and adapt to anomalous sensor data will define the next generation of resilient flight systems. Research is rapidly advancing in areas like cognitive flight systems that can not only detect “clubbing” but also understand its root cause, adapt flight strategies, or even reconfigure sensor usage on the fly. Ultimately, ensuring the “health” of sensor data is not just about performance; it’s about safeguarding the future of autonomous aerial operations, making them safer, more reliable, and truly intelligent.