
C++ stands as one of the most powerful, versatile, and enduring programming languages in the world of computer science. Developed by Bjarne Stroustrup at Bell Labs in the early 1980s, it emerged as an extension of the C language, incorporating object-oriented programming (OOP) features alongside C’s robust system-level capabilities. This hybrid nature allows C++ to bridge the gap between high-level abstraction and low-level hardware interaction, making it an indispensable tool for developing performance-critical applications. Its efficiency, strong type-checking, and direct memory manipulation capabilities ensure that applications built with C++ run with minimal overhead, a crucial factor in domains demanding real-time processing and resource optimization—qualities that are paramount in cutting-edge drone technology and innovation.
The Foundation of Advanced Drone Technology
In the intricate world of drones, where milliseconds can define success or failure, the choice of programming language is critical. C++ provides the robust, efficient, and reliable backbone necessary for the sophisticated technologies that drive modern unmanned aerial vehicles (UAVs). Its ability to manage system resources directly and execute code with unparalleled speed makes it the language of choice for developing core flight systems, sensor integration, and complex algorithmic processing required for autonomous operations.
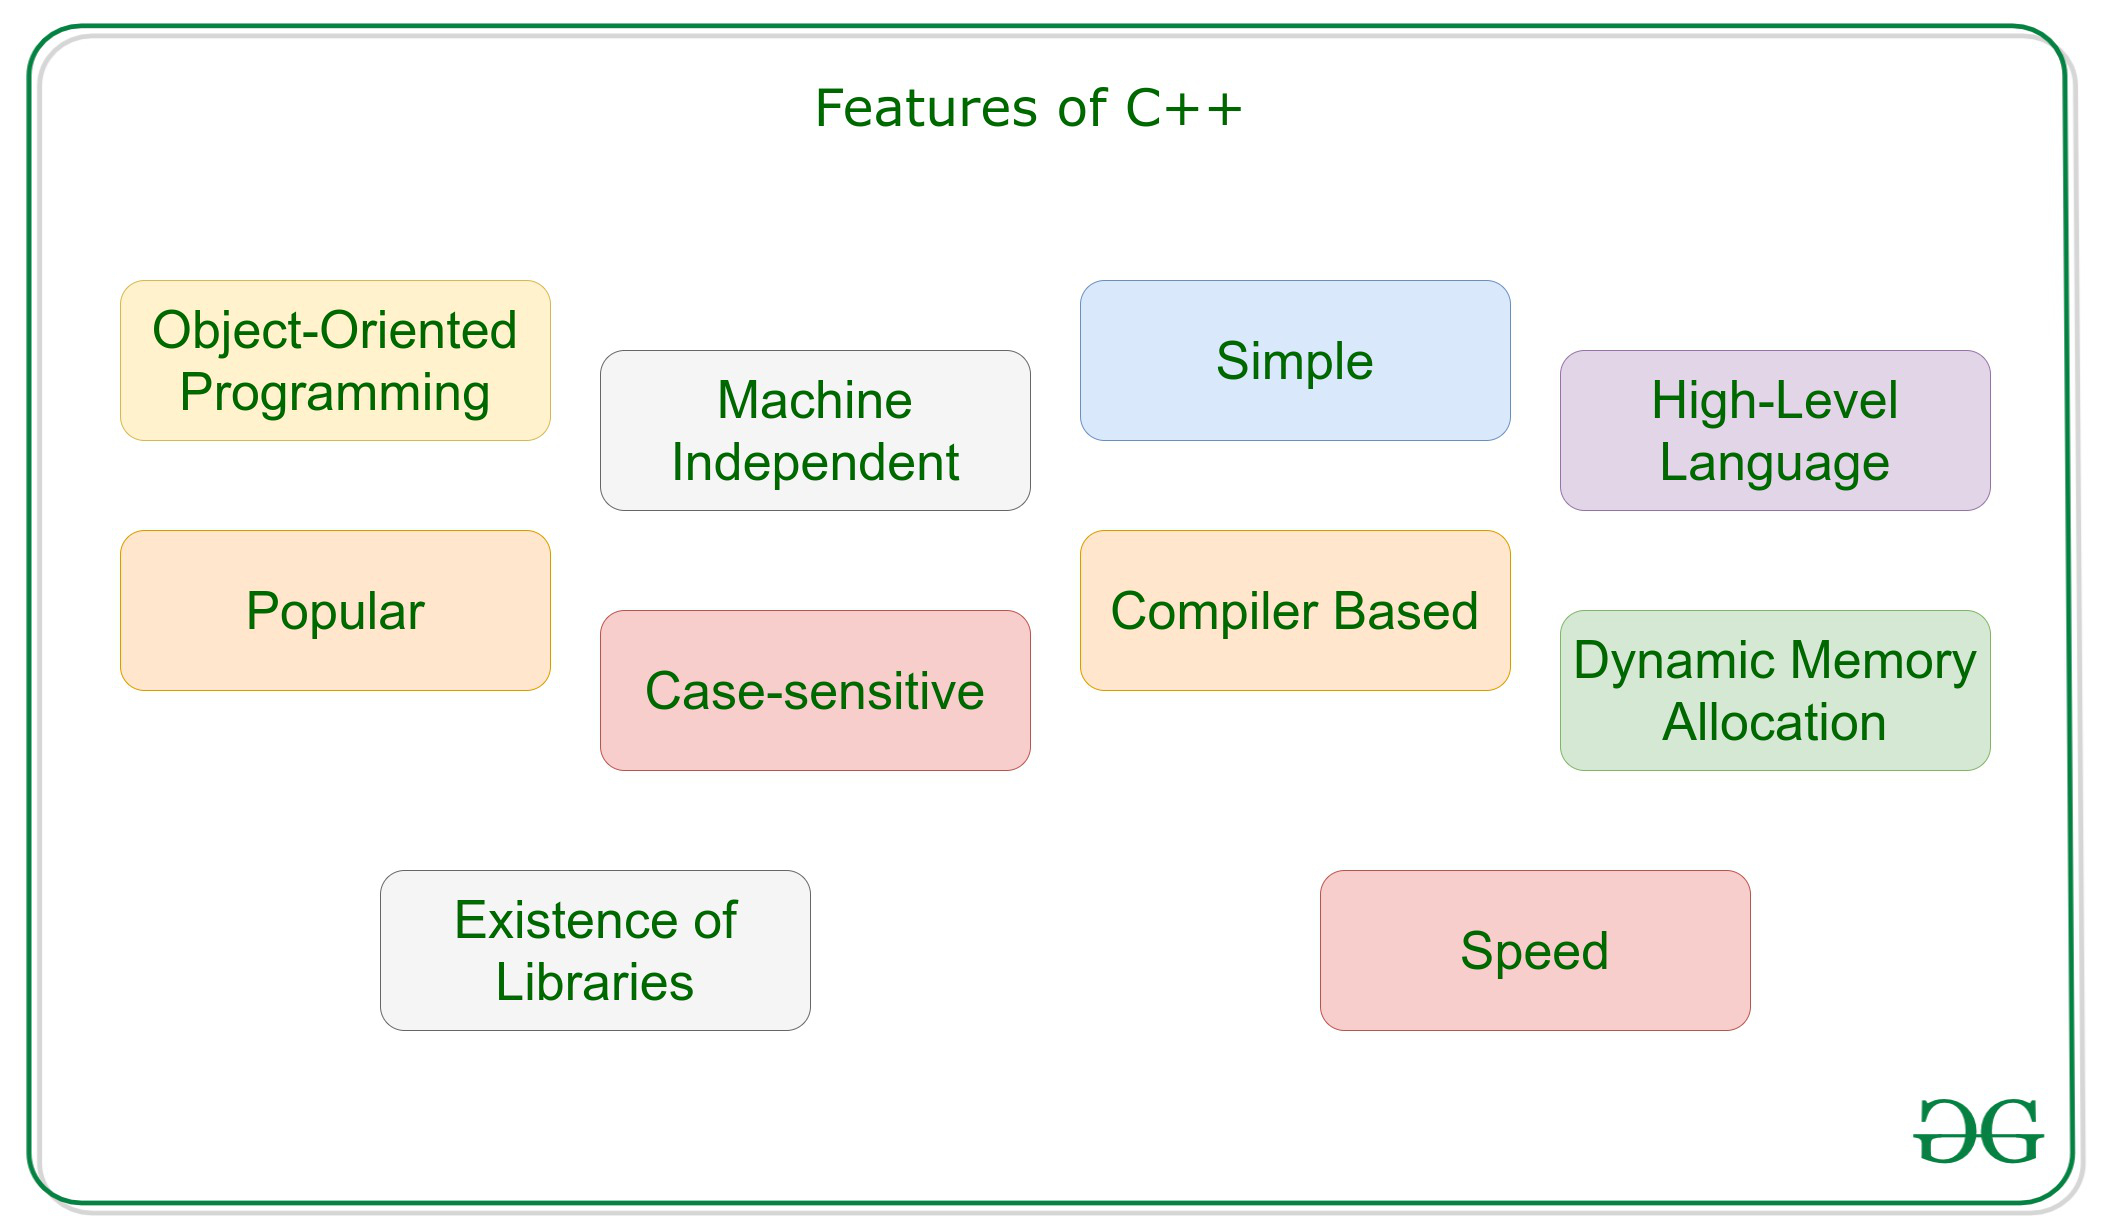
At its core, C++ offers a unique blend of features. It supports object-oriented programming (OOP) paradigms, allowing developers to design modular, reusable, and scalable codebases. This is invaluable in drone development, where components like navigation systems, sensor interfaces, and communication modules can be encapsulated and managed independently. Furthermore, C++’s close-to-hardware access enables fine-tuned control over processors and peripherals, which is essential for embedded systems like flight controllers. The language’s powerful standard library, coupled with a vast ecosystem of third-party libraries for mathematics, robotics, and image processing, further augments its utility, providing a rich set of tools for innovation in drone technology. Without C++’s foundational capabilities, many of the advanced features we associate with contemporary drones—from AI-powered tracking to complex mapping operations—would be significantly more challenging, if not impossible, to implement efficiently.
C++ and Autonomous Flight Systems
The promise of autonomous flight, once a futuristic concept, is now a reality largely thanks to the processing power and precise control enabled by languages like C++. Developing drones that can navigate complex environments, avoid obstacles, and execute intricate missions without human intervention requires a programming language capable of managing real-time data streams and making swift, accurate decisions.
Real-Time Operating Systems (RTOS) and Flight Controllers
At the heart of every autonomous drone is its flight controller, which relies on a Real-Time Operating System (RTOS) to manage critical tasks with predictable timing. C++ is extensively used to develop these RTOS kernels and the firmware that runs on them. These systems are responsible for reading sensor inputs (IMUs, GPS, barometers), executing control algorithms, and sending commands to the motors. The low-latency and deterministic behavior of C++ code are paramount here, ensuring that flight stability and responsiveness are maintained, even under rapidly changing conditions. Projects like ArduPilot and PX4, widely adopted open-source flight stacks, leverage C++ for their core functionalities, demonstrating its crucial role in building the fundamental intelligence of autonomous aerial platforms.
Navigation and Control Algorithms
Advanced navigation and control algorithms are the brains behind a drone’s ability to fly autonomously. This includes PID (Proportional-Integral-Derivative) controllers for stable flight, Kalman filters for sensor fusion, and sophisticated path planning algorithms. These algorithms require immense computational efficiency to process vast amounts of data from multiple sensors (GPS, accelerometers, gyroscopes, magnetometers) in real-time and translate them into precise motor commands. C++ excels in this domain, providing the performance necessary to execute these complex mathematical operations quickly and reliably. From maintaining altitude and heading to executing intricate maneuvers, C++ code ensures that these crucial calculations are performed with the speed and accuracy demanded by high-performance autonomous systems.
Obstacle Avoidance and Path Planning
For drones to operate safely and effectively in dynamic environments, they must possess robust obstacle avoidance and path planning capabilities. This involves processing data from LiDAR, ultrasonic sensors, and vision systems to create a real-time understanding of the surrounding environment. C++ is instrumental in developing the algorithms that interpret this sensor data, identify potential collisions, and recalculate optimal flight paths on the fly. Its speed allows for rapid analysis of complex spatial information and immediate decision-making, enabling drones to navigate through dense foliage, around buildings, or in close proximity to other objects without incident. Libraries for computer vision (like OpenCV, often used with C++) and robotics frameworks (like ROS, heavily C++-based) provide essential tools for implementing these sophisticated perception and planning systems.
Powering AI and Machine Learning in Drones
The integration of Artificial Intelligence (AI) and Machine Learning (ML) has revolutionized drone capabilities, moving beyond pre-programmed flight paths to intelligent decision-making and interaction. C++ plays a pivotal role in bringing these AI-powered innovations to fruition on resource-constrained drone hardware.
Onboard Vision Processing for AI Follow Mode
Features like “AI Follow Mode” and object tracking rely heavily on onboard vision processing. Drones equipped with cameras and powered by C++-optimized algorithms can identify, track, and predict the movement of subjects or objects in real-time. This involves executing complex convolutional neural networks (CNNs) and other ML models directly on the drone’s companion computer. C++ provides the necessary performance to run these computationally intensive models efficiently, ensuring smooth tracking, accurate object recognition, and immediate response. Developers leverage C++ with libraries such as TensorFlow Lite or PyTorch Mobile, often wrapped or integrated for C++ environments, to deploy trained models for tasks like person following, wildlife monitoring, or infrastructure inspection.
Swarm Robotics and Collaborative Systems
The concept of drone swarms, where multiple UAVs operate collaboratively to achieve a common goal, represents a significant leap in drone innovation. Developing the communication protocols, task allocation algorithms, and decentralized decision-making logic for such complex systems often falls to C++. Its efficiency in network programming and handling concurrent operations makes it ideal for managing the intricate interactions within a drone swarm. C++ allows for the low-latency communication and robust data exchange critical for ensuring that individual drones can coordinate their actions, share sensor data, and react cohesively to environmental changes, opening new possibilities for large-scale mapping, search and rescue, and reconnaissance missions.
Machine Learning Model Deployment
While many ML models are developed and trained using languages like Python, their deployment on embedded drone hardware often requires the efficiency of C++. Inference engines that run trained models are frequently implemented in C++ to minimize latency and optimize resource usage. This enables drones to perform tasks such as real-time anomaly detection in agricultural fields, advanced object classification for delivery services, or predictive maintenance analytics in industrial inspections, all processed onboard without relying on a constant connection to powerful ground stations.
Mapping, Remote Sensing, and Data Processing
Drones have become indispensable tools for generating high-resolution maps and conducting remote sensing operations across various industries. The sheer volume and complexity of data acquired through these missions demand robust processing capabilities, where C++ again proves its mettle.
High-Resolution Data Acquisition and Processing
Modern drones carry sophisticated sensors such as LiDAR, multispectral cameras, and high-resolution photogrammetry setups. The data streamed from these sensors often needs to be processed, filtered, and aggregated in real-time or near real-time. C++ is adept at handling large datasets and performing intensive mathematical computations required for tasks like point cloud registration, image stitching, and sensor data synchronization. This ensures that the raw data collected by the drone is accurately captured and pre-processed for subsequent analysis, laying the groundwork for precise mapping and environmental monitoring.
SLAM (Simultaneous Localization and Mapping)
SLAM algorithms are fundamental for drones operating in GPS-denied environments or those requiring extremely precise spatial awareness. SLAM enables a drone to build a map of an unknown environment while simultaneously tracking its own position within that map. This computationally intensive process involves fusing data from cameras, LiDAR, and IMUs, often requiring optimization techniques to run efficiently on embedded systems. C++ is the language of choice for implementing high-performance SLAM frameworks due to its control over memory and execution speed, allowing drones to create detailed 3D models of their surroundings and navigate them autonomously.
Post-Processing and Analytics
Beyond onboard processing, C++ is also heavily utilized in the development of sophisticated ground control station software and desktop applications for advanced data interpretation. After a drone mission, the collected data often undergoes further analysis for tasks such as creating digital elevation models (DEMs), orthomosaic maps, or performing precise volumetric calculations. Developers build robust C++ applications to handle these post-processing tasks, providing powerful tools for geospatial analysis, 3D modeling, and extracting valuable insights from drone-acquired data.

The Future of Drone Innovation with C++
As drone technology continues its rapid evolution, pushing the boundaries of autonomy, intelligence, and performance, C++ remains an indispensable language. Its inherent efficiency, coupled with its capacity for low-level control and high-level abstraction, positions it perfectly for tackling the challenges of future drone innovations. From ultra-lightweight micro-drones performing complex inspections to massive cargo UAVs navigating global supply chains, C++ will continue to be the language powering the critical real-time systems, advanced AI algorithms, and sophisticated data processing pipelines that define the next generation of aerial robotics. Its enduring relevance underscores its role not just as a programming language, but as a foundational technology driving relentless innovation in the drone industry.