
In the intricate world of flight technology, precision, reliability, and efficiency are paramount. Every component, from a tiny sensor to a powerful motor, operates on electrical signals and power, which are rarely perfectly constant. Understanding how to accurately quantify these varying electrical magnitudes is crucial for designing, evaluating, and optimizing drone systems. This is where the concept of Root Mean Square (RMS) becomes indispensable. Far from being an obscure mathematical term, RMS is a fundamental measurement that underpins much of the sophisticated engineering behind modern flight technology, ensuring everything from stable navigation to accurate sensor readings.

The Fundamental Concept of RMS: Measuring the “Effective” Value
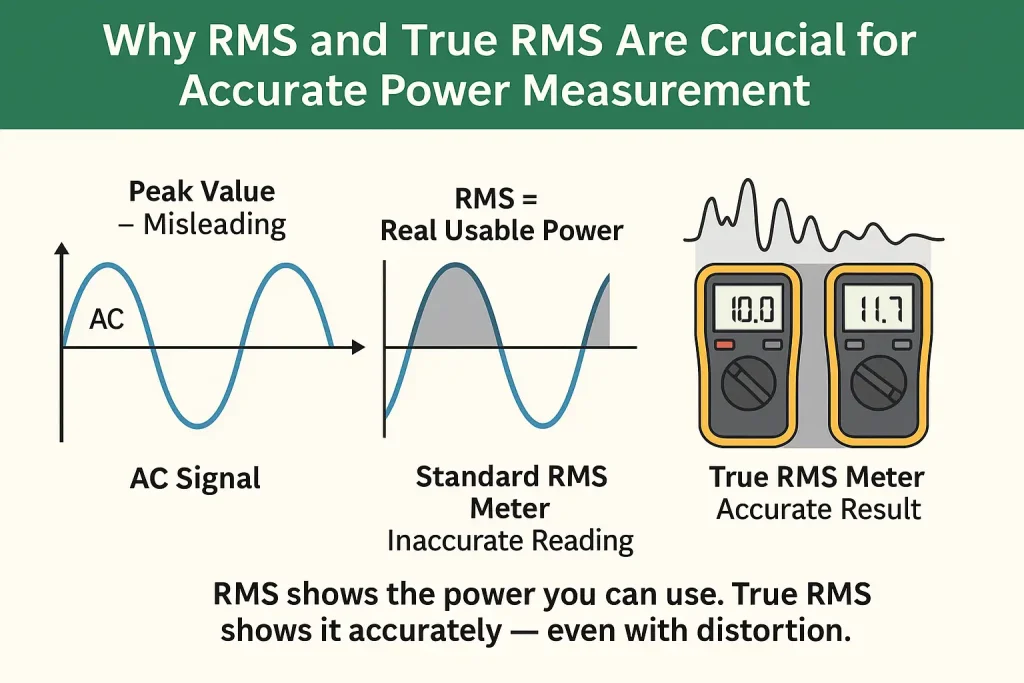
At its core, RMS is a statistical measure of the magnitude of a varying quantity. For electrical signals like voltage or current, it provides an “effective” value that is equivalent to the DC (direct current) value that would produce the same amount of power or heating effect in a resistive load. While average values might work for purely DC signals, they fall short for alternating current (AC) or fluctuating DC signals, where the average might be zero (for symmetrical AC) even though significant power is being delivered.
Mathematically, the RMS value is calculated by taking the square root of the mean (average) of the squares of the instantaneous values of a quantity over a specified period. This three-step process – Squaring, Averaging (Mean), and taking the Square Root – effectively smooths out the variations and emphasizes the larger deviations from zero, yielding a single, meaningful number.
Why Not Just Use Average or Peak?
For signals that vary, neither the average nor the peak value provides a complete picture of the signal’s true impact on a system. A sinusoidal AC voltage, for instance, has a peak voltage significantly higher than its RMS voltage, and its average voltage over a full cycle is zero. However, it still delivers power. The RMS value accurately reflects this power delivery potential. In flight technology, where pulsed DC signals (like those driving motors) or noisy sensor outputs are common, relying solely on peak or average values could lead to critical miscalculations regarding power consumption, heat dissipation, or signal quality, ultimately compromising flight performance and safety.
The RMS value, therefore, offers a standardized way to compare the energy content or heating effect of different waveforms. It’s the metric that tells you the true “strength” of an electrical signal, regardless of its shape, making it invaluable for precise engineering.
RMS in Power Systems and Motor Control
The efficiency and reliability of a drone’s propulsion system—encompassing batteries, Electronic Speed Controllers (ESCs), and motors—are directly tied to how electrical power is managed. Here, RMS is not just a theoretical concept; it’s a practical necessity for safe and optimal operation.
ESCs and Motor Efficiency
Brushless DC (BLDC) motors, ubiquitous in modern drones, are driven by ESCs that convert the battery’s DC voltage into a rapidly switching, three-phase AC signal. This signal, while appearing AC to the motor, is fundamentally a pulsed DC waveform generated by pulse-width modulation (PWM). The voltage and current delivered to the motor are far from constant; they are rapidly switching on and off to control motor speed and torque.
Measuring the average voltage or current in such a system would be misleading. The RMS current, however, accurately represents the effective current responsible for heating the motor windings and delivering torque. Overestimating or underestimating this RMS current can lead to several problems:
- Overheating: If the RMS current drawn by the motor exceeds its design limits, windings can overheat, leading to insulation breakdown, reduced efficiency, and premature motor failure.
- Battery Performance: Batteries are rated for continuous and burst discharge currents, often specified as RMS values. Exceeding these RMS ratings can severely shorten battery lifespan, reduce flight time, and even pose fire risks. Understanding the RMS current draw of the entire propulsion system is crucial for selecting appropriate batteries.
- System Sizing: Engineers use RMS values to correctly size ESCs, wires, and connectors, ensuring they can safely handle the actual power flowing through them without undue resistance or heat generation.
Power Ripple and Stability
Beyond the motors, RMS is vital for evaluating the stability of power delivery to sensitive flight technology components like the flight controller, GPS module, and various sensors. Even from a “DC” battery, power lines can exhibit ripple—small, unwanted AC components superimposed on the DC voltage, often caused by the switching action of ESCs or other power regulators.
The RMS value of this ripple voltage provides a quantifiable measure of its magnitude. Excessive ripple can introduce noise into sensitive electronic circuits, interfere with sensor readings, or even cause instability in the flight controller’s operation. By designing power filters and regulators to minimize the RMS ripple voltage, engineers ensure a cleaner, more stable power supply, which directly translates to more reliable flight control and navigation.
RMS for Sensor Data and Signal Integrity
Drones are equipped with an array of sophisticated sensors—Inertial Measurement Units (IMUs), GPS receivers, barometers, magnetometers, and obstacle avoidance sensors—all of which generate electrical signals that are processed by the flight controller. The quality and integrity of these signals are paramount for accurate flight. RMS plays a critical role in quantifying signal noise and ensuring data reliability.

Noise Floor in IMUs and GPS
IMUs, which typically include accelerometers and gyroscopes, are fundamental for flight stabilization. They constantly measure the drone’s angular velocity and linear acceleration. However, all electronic sensors inherently produce a certain level of electrical noise. This noise appears as random fluctuations in the sensor output, even when the drone is perfectly still.
The “noise floor” of an IMU or GPS receiver is often quantified by its RMS value. A lower RMS noise floor indicates a cleaner, more precise sensor. For instance, the RMS value of the noise in a gyroscope’s output directly affects the accuracy of attitude estimation. High RMS noise can lead to “drift” in the drone’s reported orientation, making stable flight difficult and impacting navigation accuracy.
Similarly, GPS receivers are susceptible to environmental noise and signal interference. The RMS error in GPS position data (often expressed as horizontal or vertical position accuracy) reflects the effective magnitude of these errors over time, indicating the reliability of the reported location. Engineers strive to select sensors with low RMS noise and implement digital filtering techniques that reduce the RMS value of noise in the processed sensor data, thus improving the overall signal-to-noise ratio.
Signal Processing for Accuracy
Flight controllers continuously sample sensor data at high rates. Before this data can be used for control algorithms, it often undergoes filtering and signal processing. One common application of RMS here is in analyzing the characteristics of these filters. For example, a filter might be designed to reduce the RMS value of high-frequency noise while preserving the RMS value of the actual movement signal.
By understanding the RMS characteristics of different signals and noise sources, flight engineers can:
- Optimize Filter Design: Tailor digital filters to effectively suppress noise without introducing unacceptable latency or distorting true motion data.
- Improve Control Loop Performance: Ensure that the flight control algorithms receive clean, reliable data, which is essential for precise control and agile maneuvers.
- Diagnose Issues: Analyze the RMS levels of various signals during flight testing to identify sources of interference or unexpected sensor behavior.
Applying RMS to Flight Stabilization and Navigation
The ultimate goal of all these measurements and analyses is to achieve superior flight performance. RMS, in its various applications, directly contributes to robust flight stabilization and accurate navigation.
Enhancing Stabilization Systems
Flight stabilization relies on a rapid and accurate feedback loop: sensors measure the drone’s orientation and motion, the flight controller calculates necessary adjustments, and ESCs/motors execute those adjustments. If the sensor data is noisy (high RMS noise), the flight controller might misinterpret the drone’s state, leading to “jittery” or unstable flight. Conversely, if the power supply to the IMU has high RMS ripple, the sensor itself might generate inaccurate readings.
By minimizing RMS noise in sensor data and power lines, engineers can ensure that the stabilization algorithms receive the cleanest possible information. This allows the flight controller to make more precise and timely adjustments, resulting in smoother, more stable flight, even in challenging conditions. This contributes directly to a better user experience, whether for cinematic shots or industrial inspections.
Improving Navigation Accuracy
For navigation tasks, especially autonomous flight, mapping, and remote sensing, accurate positioning and orientation are critical. GPS data with low RMS error means more precise coordinates for waypoints and mapping grids. IMU data with low RMS noise means more accurate attitude estimates, which are essential for correcting sensor readings (like from a camera gimbal) and ensuring the drone maintains its intended trajectory.
Advanced navigation systems might also use sensor fusion algorithms that combine data from multiple sensors (GPS, IMU, magnetometer, barometer). Understanding the RMS characteristics of each sensor’s error allows the fusion algorithm to weigh the contributions of each sensor appropriately, further improving overall navigation accuracy.
The Practical Implications for Drone Performance
For drone operators, designers, and enthusiasts, understanding RMS might seem deeply technical, but its practical implications are far-reaching. It translates directly into:
- Reliability: Systems designed with RMS principles in mind are less prone to unexpected failures, overheating, and data corruption.
- Performance: A drone with clean sensor data and stable power delivery will fly smoother, respond more precisely, and navigate more accurately.
- Longevity: Properly sized components based on RMS current ratings will last longer, reducing the total cost of ownership.
- Safety: Accurate measurements of power and signal integrity lead to safer drone operation, mitigating risks associated with component failure or loss of control.
In essence, “what is an RMS” leads to “how good is my drone?” It’s a foundational concept that, while often unseen by the end-user, is meticulously applied by engineers to ensure that the sophisticated dance of flight technology unfolds flawlessly, from the quiet hum of a stabilized hover to the precise execution of an autonomous mission.