
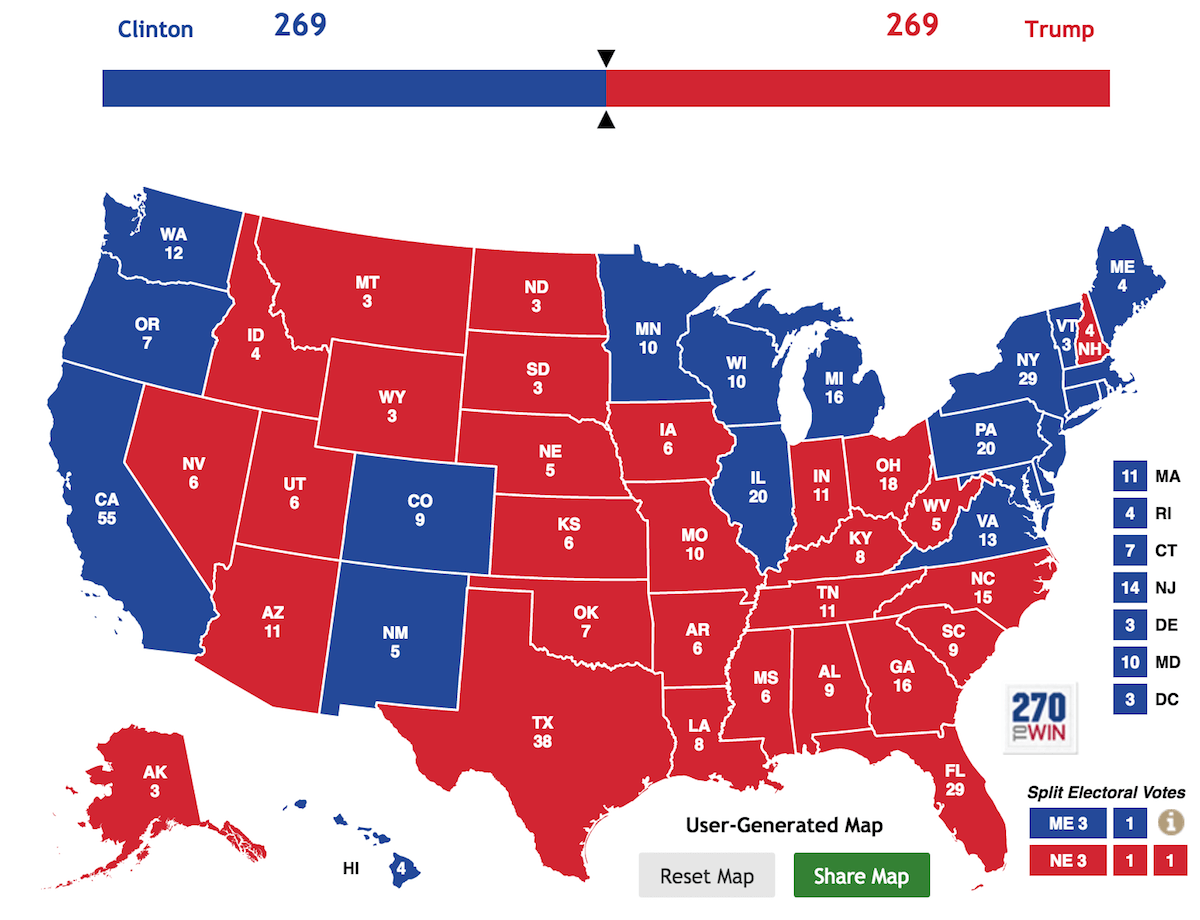
In the realm of advanced technology and innovation, the concept of a clear, decisive outcome is paramount. Whether designing autonomous systems, developing sophisticated AI, or orchestrating distributed networks, engineers and researchers consistently grapple with scenarios where a critical threshold of consensus, data certainty, or operational approval is not met. Just as a political system might face ambiguity when “no one gets 270 electoral votes,” technological frameworks must be robust enough to navigate situations where a definitive “go/no-go” signal, a strong predictive confidence, or a unanimous agreement across distributed nodes remains elusive. This metaphorical “270-vote” threshold represents the minimum required certainty or agreement for a system to proceed with a predefined action or to declare a clear state. The failure to achieve this benchmark necessitates sophisticated contingency planning and built-in resilience mechanisms, exploring what happens when clear directives evaporate.
The Analogy of Consensus in Autonomous Systems
The idea of “270 electoral votes” serves as a powerful analogy for the consensus mechanisms embedded within advanced technological systems. In an era increasingly defined by automation and artificial intelligence, decisions are often not made by a single entity but emerge from a complex interplay of sensors, algorithms, and distributed agents. When a clear majority or a critical confidence level, akin to 270 electoral votes, is not attained, the system enters a state of operational limbo, demanding pre-programmed protocols for resolution.
Decision Thresholds in AI and Robotics
Consider an autonomous vehicle navigating a complex urban environment. Its decision to proceed, brake, or change lanes is not a simple reflexive action but a culmination of data fusion from lidar, radar, cameras, and ultrasonic sensors, processed by multiple AI models. Each sensor feed, each algorithm’s output, contributes a “vote” towards a particular action. If the aggregate confidence score for a critical action – say, executing an emergency maneuver – falls below a predetermined safety threshold (our “270 electoral votes”), the system faces a dilemma. It’s not that the system doesn’t know what to do at all, but rather that its certainty is insufficient to commit to the most optimal or aggressive response. In such cases, systems are programmed to default to conservative actions: reducing speed, increasing following distance, requesting human oversight, or initiating a controlled stop.
Similarly, in industrial robotics, for a high-precision manufacturing task, multiple computer vision systems and tactile sensors might need to independently confirm alignment or component integrity. If these systems provide conflicting data, or if no single interpretation achieves the necessary “270-vote” level of validation, the robotic arm will pause. It will not proceed with a potentially erroneous action, safeguarding against material damage or production errors. This inherent caution highlights the importance of clearly defined thresholds and the consequences of their non-attainment.
Decentralized Governance and Distributed Consensus
The parallel extends profoundly into decentralized technologies, particularly in blockchain and distributed ledger systems. Here, “votes” are often cryptographic signatures or computational proofs from numerous independent nodes. In a proof-of-stake or delegated proof-of-stake blockchain, for instance, a proposal for a network upgrade or a transaction validation requires approval from a supermajority of staked tokens or elected validators. If a significant proposal fails to garner the necessary support—our metaphorical “270 electoral votes”—it does not pass. The network maintains its current state, and the proposed changes are rejected or sent back for reconsideration.
Beyond blockchain, decentralized autonomous organizations (DAOs) represent a cutting-edge form of governance where decisions are made by token holders. Proposals range from treasury allocation to strategic direction. If a proposal fails to reach its quorum and approval threshold—the DAO’s equivalent of “270 electoral votes”—it remains unexecuted. This ensures that significant changes or resource deployments only occur when there is sufficient, demonstrable community consensus, preventing rushed or unpopular decisions that could fragment the organization or compromise its integrity. The inability to reach consensus simply means the status quo persists, rather than leading to a chaotic state.
Contingency Protocols and Fallback Mechanisms
When a technological system fails to achieve its “270 electoral votes” of certainty or consensus, it doesn’t simply halt indefinitely. Sophisticated systems are designed with layered contingency protocols and robust fallback mechanisms to ensure continued operation, albeit under altered parameters, or to safely disengage. These mechanisms are crucial for maintaining stability and preventing critical failures in ambiguous scenarios.
Manual Overrides and Human-in-the-Loop Interventions

One of the most common and effective fallback mechanisms, particularly in high-stakes autonomous systems, is the human-in-the-loop intervention. When AI decision-making algorithms cannot reach a “270-vote” confidence level for a critical action—be it in air traffic control, medical diagnostics, or critical infrastructure management—the system is designed to flag the ambiguity and escalate the decision to a human operator. This is not a failure of automation but a deliberate design choice recognizing the current limits of AI and the irreplaceable value of human judgment in novel, complex, or ethically charged situations.
For instance, in AI-powered cybersecurity systems, if an anomaly detection algorithm identifies suspicious activity but cannot confidently classify it as a threat (failing its “270-vote” threat confidence), it will alert a human analyst. The analyst can then review the data, apply their nuanced understanding, and make the definitive judgment or initiate further investigation. Similarly, in autonomous flight systems, if sensor data is compromised or conflicting, leading to insufficient confidence for autonomous navigation, control can be seamlessly transferred to a remote pilot or an onboard human pilot, averting a potential crisis.
Recalibration and Iterative Learning Cycles
Another sophisticated response to failing the “270-vote” threshold is initiating a recalibration or an iterative learning cycle. When an AI model’s predictive power or a sensor array’s data fusion falls short of the required certainty, the system can be programmed to gather more data, refine its parameters, or even actively seek clarification.
Consider a machine learning model used for predictive maintenance in industrial equipment. If its initial analysis of sensor data doesn’t provide the “270-vote” confidence level to recommend a specific maintenance action, the system won’t make a rash decision. Instead, it might trigger additional diagnostic tests, request more frequent data logging, or initiate a deeper dive into historical performance data. This iterative process allows the system to gather further “evidence” or “votes” to either reach the necessary confidence threshold or to confirm that the ambiguity persists, requiring human intervention. In some advanced AI systems, this can even involve active learning strategies, where the AI proactively queries human experts or performs targeted experiments to resolve the ambiguity and strengthen its future decision-making capabilities.
Implications for Future Tech Development
The challenge of not reaching a decisive “270 electoral votes” in technological systems underscores fundamental principles of robust system design and points towards future directions in AI and autonomous functionality. Addressing these scenarios is not merely about error handling; it’s about building intelligence that can thrive in uncertainty and adapt to the unpredictable nature of real-world environments.
Robustness and Resilience in System Design
The necessity of planning for “no clear winner” scenarios drives the demand for inherently robust and resilient system architectures. This involves designing fault-tolerant systems, redundant sensor arrays, and diverse AI models that can cross-validate outputs. Instead of relying on a single point of truth or a monolithic decision engine, future systems will increasingly leverage distributed intelligence, where multiple independent agents contribute their “votes” and where dissent or ambiguity can be managed gracefully. The emphasis shifts from simply achieving an outcome to ensuring that any outcome—or lack thereof—is handled with maximum safety and stability. This includes developing sophisticated arbitration logic that can weigh conflicting inputs, prioritize safety over efficiency when certainty is low, and smoothly transition between autonomous and supervised modes.
Moreover, the principles of formal verification and explainable AI (XAI) gain heightened importance. When a system cannot reach a “270-vote” consensus, understanding why that consensus was not achieved—what specific data points were ambiguous, which models disagreed, and why—becomes crucial for diagnosis, improvement, and building trust. Future development will focus on creating systems that can articulate their uncertainties and the reasons behind them, enabling more effective human collaboration and system evolution.
The Evolving Role of AI in Ambiguous Scenarios
As AI continues to advance, its ability to navigate ambiguous scenarios without explicit human intervention will become a key differentiator. Current systems often defer to humans when clarity is lacking. However, future AI research is exploring methods for AI to resolve its own internal “electoral deadlocks.” This includes meta-learning techniques where AI learns not just to perform tasks but also to understand the limits of its own knowledge and decision-making capabilities. An AI that can intelligently seek out additional information, formulate hypotheses to test conflicting data, or even gracefully acknowledge its inability to make a confident decision and suggest alternative approaches, represents the next frontier.
This evolution will move beyond simple conservative fallback actions to dynamic, context-aware responses that can proactively manage risk and even learn from ambiguous outcomes. The goal is to build autonomous systems that, when facing a “no one gets 270 electoral votes” situation, don’t just stop or defer, but can intelligently adapt, re-strategize, and even innovate pathways to resolution, pushing the boundaries of true machine intelligence and resilience.