
In the intricate world of Flight Technology, where precision, stability, and control are paramount, understanding fundamental physical principles is not merely academic—it is operational. At the very core of how any aerial vehicle, from a micro-drone to an advanced UAV, maintains its orientation, navigates its path, and resists external disturbances lies a concept so fundamental it shapes every aspect of flight: inertia. Inertia is not a standalone law, but rather the central tenet of Newton’s First Law of Motion, often referred to as the Law of Inertia. This principle dictates how objects behave in the absence of external forces, and its implications are woven into the very fabric of modern flight technology, from sensor design to complex stabilization algorithms.
The Foundational Principle: Newton’s First Law of Motion
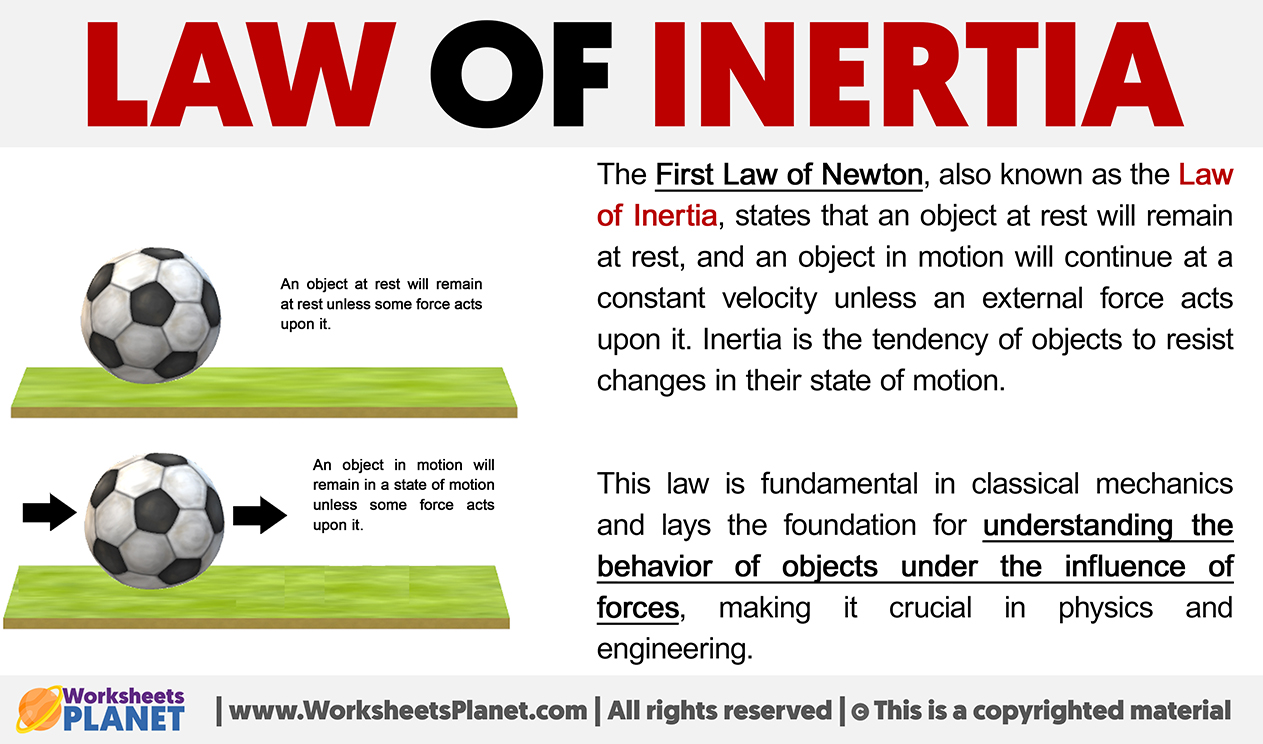
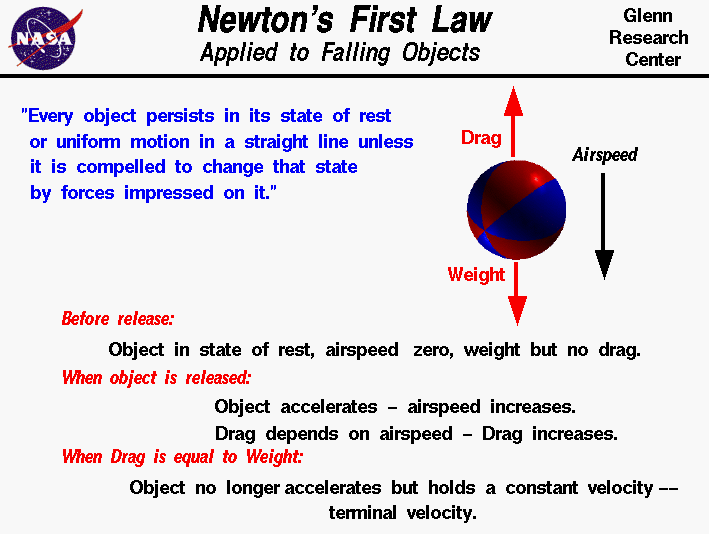
Sir Isaac Newton’s monumental contributions to physics laid the groundwork for understanding motion, and his First Law provides the bedrock for comprehending inertia. It states: “An object at rest stays at rest and an object in motion stays in motion with the same speed and in the same direction unless acted upon by an unbalanced force.” This simple yet profound statement encapsulates the essence of inertia, making it a cornerstone for predicting and controlling the behavior of any physical system, especially dynamic ones like airborne platforms.
Defining Inertia
Inertia is the inherent property of an object to resist changes in its state of motion. If a drone is hovering perfectly still, inertia ensures it will remain motionless unless a force—like a gust of wind, a motor thrust, or a collision—acts upon it. Conversely, if that drone is cruising at a constant velocity, inertia dictates it will continue at that speed and direction unless acted upon by an external force. This resistance to change applies to both linear motion (translational inertia) and rotational motion (rotational inertia). For flight technology engineers, inertia is not just a passive property; it is a force to be managed, measured, and exploited. It dictates how much effort a flight controller must exert to initiate a turn, stop a drift, or compensate for turbulence.
Mass and Inertia: An Inseparable Link
The magnitude of an object’s inertia is directly proportional to its mass. A heavier drone possesses greater inertia than a lighter one. This has direct implications for flight characteristics. A heavier drone will be more stable against minor perturbations, requiring larger forces to alter its path or attitude. However, this increased inertia also means it will require more powerful motors and larger control surface deflections (or propeller speed changes) to accelerate, decelerate, or maneuver. For racing drones, minimizing mass is crucial to reduce inertia, allowing for rapid changes in direction and acceleration. Conversely, a large, heavy cargo drone might leverage its higher inertia for smoother, more stable flight in less turbulent conditions, but at the cost of agility. Understanding this relationship is critical for everything from power system design to flight performance tuning, balancing the need for stability against the desire for maneuverability.
Inertia’s Indispensable Role in Flight Dynamics
The dynamic nature of flight means that aerial vehicles are constantly battling or harnessing inertial forces. Every adjustment, every correction, and every desired movement is a direct interaction with the principles of inertia.
Resisting Change: The Essence of Flight Stability
A primary goal of any flight technology system is stability. An unstable aircraft is uncontrollable. Inertia plays a critical role here. When a drone encounters a sudden crosswind, its inertia resists the immediate change in its lateral motion. While this resistance is beneficial in dampening instantaneous jitters, continuous external forces would eventually overcome it. This is where active stabilization systems, powered by advanced flight controllers, come into play. These systems constantly measure the drone’s attitude and motion, comparing them against desired parameters. When a deviation occurs due to an external force acting against the drone’s inertia, the flight controller rapidly calculates and applies corrective forces (by adjusting motor speeds) to restore the desired state. Without an understanding of how inertia causes the drone to react to these forces, effective stabilization would be impossible. The responsiveness of these systems is calibrated precisely to counteract the drone’s inherent inertia.
Understanding Rotational Inertia
Beyond linear motion, rotational inertia is equally, if not more, critical for flight technology. Rotational inertia, or moment of inertia, describes an object’s resistance to changes in its rotational motion. For a drone, this means resisting changes in its pitch, roll, and yaw. The distribution of mass within a drone (its geometry and where its components are placed) significantly affects its rotational inertia. A drone with its mass concentrated towards the center will have a lower moment of inertia, making it more agile and responsive to rotational commands. Conversely, a drone with weight distributed further from its center will have a higher moment of inertia, making it more stable but less agile. Gimbal systems for cameras on drones exploit this principle; by using gyroscopes (which inherently resist changes to their plane of rotation due to rotational inertia) and counterweights, gimbals can isolate cameras from the drone’s rotational movements, providing stable, level footage even during aggressive maneuvers. Engineering a drone’s airframe and component layout to achieve the optimal rotational inertia characteristics for its intended purpose is a key design challenge in flight technology.
Inertial Measurement Units (IMUs): The Brains of Flight Technology
The practical application of Newton’s First Law in modern flight technology is most vividly demonstrated through Inertial Measurement Units (IMUs). These sophisticated sensor packages are the cornerstone of navigation, stabilization, and control systems in virtually every UAV.
Accelerometers and Gyroscopes in Action
An IMU typically consists of two primary types of sensors that directly measure inertial properties:
- Accelerometers: These sensors measure non-gravitational acceleration. They detect changes in linear velocity. When a drone accelerates, decelerates, or experiences a force (like gravity or a push), the accelerometer senses this change in motion against its own internal inertial mass. By measuring these accelerations along multiple axes, the flight controller can determine how external forces are attempting to alter the drone’s linear motion.
- Gyroscopes: Gyroscopes measure angular velocity, which is the rate of rotation around an axis. Leveraging the principle of rotational inertia, gyroscopes detect how quickly a drone is pitching, rolling, or yawing. They provide critical data about the drone’s rotational state, which is essential for maintaining a stable attitude. A rotating mass within the gyroscope resists changes in its plane of rotation, and the forces required to make it change provide the measurement.
Together, these sensors provide a real-time, high-frequency stream of data about the drone’s instantaneous motion, making the invisible forces of inertia quantifiable and usable for computation.
Sensor Fusion and State Estimation
The raw data from accelerometers and gyroscopes, while crucial, often contains noise and drift. This is where advanced algorithms, commonly known as sensor fusion, come into play. Techniques like Kalman filters or complementary filters combine the data from accelerometers, gyroscopes, and often magnetometers (electronic compasses), and sometimes even GPS, to produce a highly accurate and reliable estimate of the drone’s current attitude (pitch, roll, yaw), velocity, and sometimes position. Gyroscopes excel at tracking rapid changes in orientation but suffer from drift over time. Accelerometers provide a reliable reference for “down” (gravity) and linear acceleration but are susceptible to noise from vibrations. By cleverly merging these inputs, sensor fusion algorithms can leverage the strengths of each sensor to overcome their individual weaknesses, providing the flight controller with a robust and precise understanding of the drone’s “state”—its exact orientation and movement in space. This accurate state estimation, directly derived from inertial measurements, is foundational for all automated flight behaviors, from simple hovering to complex autonomous missions.
Navigation and Control: Leveraging Inertia for Precision
The integration of inertial data is not just for keeping a drone stable; it is fundamental to its ability to navigate accurately and execute precise maneuvers, forming the backbone of advanced flight control systems.
Inertial Navigation Systems (INS)
For precise navigation, especially in environments where GPS signals might be weak, jammed, or unavailable, Inertial Navigation Systems (INS) are indispensable. An INS uses the continuous data stream from an IMU (accelerometers and gyroscopes) to calculate a drone’s position, velocity, and attitude relative to a known starting point. By integrating accelerometer data over time, the system can determine changes in velocity, and by integrating velocity, it can determine changes in position. Similarly, gyroscope data is integrated to track changes in orientation. While an INS is incredibly accurate over short periods, the small errors in acceleration and angular rate measurements accumulate over time, leading to “drift.” Therefore, in most modern UAVs, INS data is fused with external navigation aids like GPS (Global Positioning System) or visual odometry. The INS provides high-frequency, short-term accuracy, filling in the gaps between less frequent GPS updates and providing robust positioning during GPS outages. This hybrid approach offers both high precision and long-term stability, enabling autonomous flight in diverse and challenging conditions.
Autonomy and Predictive Control
Autonomous flight, the pinnacle of modern flight technology, relies heavily on the principles of inertia. For a drone to follow a pre-programmed path, maintain a specific altitude, or execute complex maneuvers like “follow-me” modes, its flight controller must accurately predict its future state based on current motion and applied forces. Inertial data provides the real-time feedback loop necessary for these predictive models. Control algorithms constantly analyze the drone’s inertial state and compare it to the desired state. Based on the drone’s mass and moment of inertia, the controller calculates the exact motor thrust adjustments required to overcome inertia and achieve the desired change in motion. For instance, to stop a drone moving forward, the controller must apply a backward force for a specific duration, anticipating how the drone’s inertia will cause it to decelerate. This sophisticated interplay between sensing inertial forces, computing control inputs, and predicting outcomes defines the intelligence of autonomous flight systems.
Overcoming Inertia: Propulsion and Maneuverability
While inertia dictates an object’s resistance to change, propulsion systems are designed specifically to generate the forces necessary to overcome this resistance, enabling flight and maneuverability.
Propulsive Forces and Overcoming Resistance
For a drone to take off, accelerate, or change direction, its propellers must generate sufficient thrust to overcome its mass inertia and any opposing forces like drag. When a drone hovers, the total upward thrust generated by its propellers precisely balances the downward force of gravity acting on its mass. To climb, the thrust must exceed gravity, accelerating the drone upwards by overcoming its inertia. To move forward, horizontal thrust must be generated. The efficiency of the propulsion system—how much force it can generate per unit of power—is critical because greater inertia (from a heavier drone) demands more powerful and energy-intensive thrust to achieve desired flight performance. Engineers meticulously design propellers, motors, and battery systems to deliver the necessary power to overcome the drone’s inertia and perform its intended tasks, whether it’s lifting heavy payloads or achieving high speeds.

Rapid Maneuvers and Control Authority
The ability of a drone to execute rapid maneuvers, such as tight turns or sudden stops, is a testament to the effective interplay between powerful propulsion systems and sophisticated flight control algorithms that understand and leverage inertia. For a racing drone, minimizing rotational inertia is key to achieving extreme agility. The flight controller must have precise “control authority”—the ability to rapidly change individual motor speeds to generate differential thrust that applies torques to overcome the drone’s rotational inertia, thus quickly changing its pitch, roll, or yaw. This rapid response requires not only powerful motors but also low-latency sensors (IMUs) and fast processing flight controllers. In larger UAVs, while agility might be less of a priority, understanding the drone’s inertial characteristics allows for smooth, controlled maneuvers even with significant payloads, preventing overshoots or unstable oscillations.
In conclusion, Newton’s First Law of Motion, the Law of Inertia, is far more than a theoretical concept in the realm of flight technology. It is a fundamental principle that underpins everything from the physical design of an airframe and the selection of its propulsion system to the sophisticated algorithms that drive its stabilization, navigation, and autonomous capabilities. By continuously measuring, calculating, and strategically overcoming or harnessing inertia, flight technology engineers empower drones and UAVs to perform with remarkable precision, stability, and intelligence in the skies above.