
In the dynamic world of drone technology and innovation, staying abreast of the latest tools and frameworks is paramount for developers and engineers pushing the boundaries of autonomous flight, AI-powered systems, and advanced remote sensing. Among these critical tools, Python stands out as an indispensable programming language, serving as the backbone for a vast array of cutting-edge applications in the unmanned aerial vehicle (UAV) domain. Understanding the current state of Python development, particularly its latest stable version, is not merely a matter of curiosity but a strategic imperative for optimizing performance, leveraging new features, and maintaining robust, future-proof drone systems.
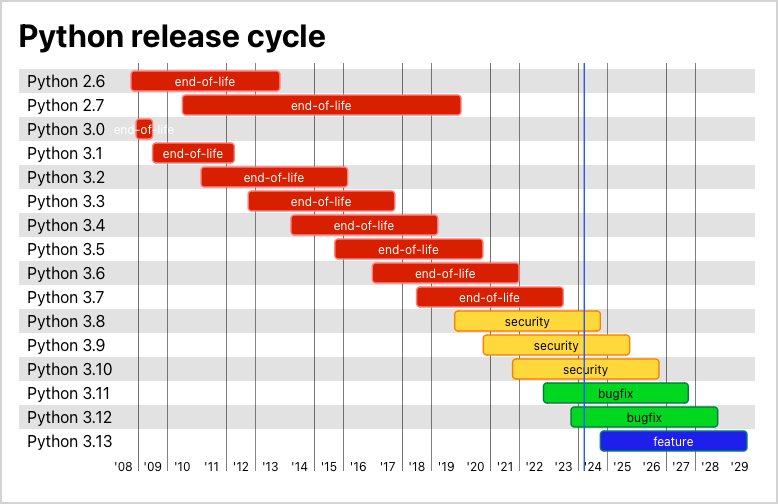
As of early 2024, the latest stable release of Python is Python 3.12. This version represents the culmination of continuous development efforts, bringing significant enhancements and optimizations over its predecessors. While Python 3.13 is already in beta and slated for release later in the year, 3.12 is the current benchmark for production-ready applications, offering improved performance, new syntax features, and refined error handling that directly impact the efficiency and reliability of drone-related software. For anyone working on AI follow modes, sophisticated navigation algorithms, real-time data processing for mapping, or advanced remote sensing applications, the transition to or development with Python 3.12 offers tangible benefits.
Python’s Indispensable Role in Drone Tech & Innovation
Python’s versatility, extensive library ecosystem, and readability have cemented its position as a go-to language for innovative drone technologies. From the ground station software that commands complex missions to the on-board intelligence that enables autonomous decision-making, Python provides the flexibility and power needed to tackle the unique challenges of aerial robotics.
Powering Autonomous Flight and AI
The vision of fully autonomous drones capable of navigating complex environments, avoiding obstacles dynamically, and performing intricate tasks without human intervention is largely realized through Python. Machine learning and artificial intelligence, the cornerstones of autonomous flight, are predominantly developed using Python. Libraries like TensorFlow, PyTorch, and scikit-learn, all primarily Python-based, are instrumental in training neural networks for object recognition, predictive control, and intelligent path planning.
For instance, an AI follow mode, which allows a drone to automatically track a subject, relies on real-time computer vision processing to identify and lock onto the target. Python, with its rich set of imaging libraries like OpenCV and Pillow, enables the rapid development and deployment of such vision algorithms. Furthermore, the development of sophisticated decision-making engines for autonomous drones, which involve processing sensor fusion data from GPS, IMUs, lidar, and cameras, often utilizes Python for its ease of prototyping and integration with hardware interfaces. The language’s ability to quickly iterate on complex algorithms makes it ideal for the fast-paced research and development cycles inherent in creating smarter, more adaptive drone AI.
Enabling Advanced Data Processing and Remote Sensing
Drones are increasingly deployed as platforms for data acquisition, collecting vast amounts of imagery, spectral data, and environmental readings. Python excels in the subsequent processing, analysis, and interpretation of this data, making it invaluable for remote sensing and mapping applications. Whether it’s processing gigabytes of orthomosaic imagery for agricultural analysis, generating 3D models from photogrammetry data for construction site monitoring, or analyzing thermal camera feeds for search and rescue operations, Python provides the tools.
Libraries such as NumPy and SciPy handle numerical computations with remarkable efficiency, while Pandas facilitates data manipulation and analysis. GeoPandas extends these capabilities to geospatial data, allowing developers to work seamlessly with geographical information systems (GIS) data directly within Python. For more specialized remote sensing tasks, libraries like GDAL/OGR provide robust support for various raster and vector geospatial formats. The ability to script complex data workflows, automate repetitive tasks, and integrate with powerful visualization tools like Matplotlib and Plotly makes Python an essential component of any advanced drone-based data analysis pipeline, transforming raw sensor input into actionable intelligence.
The Significance of Staying Current with Python Versions
For drone developers, the choice of Python version is not a trivial one. The continuous evolution of the language brings forth improvements that can significantly impact the performance, security, and maintainability of drone-related software. Adopting the latest stable version, such as Python 3.12, is often a strategic decision that pays dividends in the long run.
Performance Enhancements and Real-Time Operations
Each new major Python release typically includes substantial performance improvements. Python 3.12, for instance, introduced a more optimized interpreter, leading to noticeable speedups in execution. For drone applications, where real-time processing of sensor data, rapid execution of control algorithms, and swift decision-making are critical, even marginal performance gains can be transformative. Faster code translates directly into quicker response times for autonomous systems, more efficient data processing on resource-constrained embedded systems, and an overall more reliable and responsive drone operation.
These performance enhancements are particularly crucial for tasks like real-time object detection and tracking, simultaneous localization and mapping (SLAM), and complex trajectory planning, all of which demand significant computational resources. Leveraging the latest Python version ensures that developers are working with the most efficient runtime available, potentially reducing the need for more powerful (and heavier, thus less energy-efficient) on-board computing hardware, or enabling more sophisticated algorithms on existing hardware.
Ecosystem Evolution and Library Compatibility
The strength of Python in drone tech lies heavily in its vast ecosystem of third-party libraries. However, this ecosystem is constantly evolving. Major machine learning frameworks (TensorFlow, PyTorch), scientific computing libraries (NumPy, SciPy), and computer vision tools (OpenCV) frequently update, often dropping support for older Python versions and introducing features that rely on newer Python constructs.
By staying updated to the latest Python version, drone developers ensure compatibility with the most recent versions of these critical libraries. This access to cutting-edge library features means being able to utilize the latest advancements in AI models, optimization techniques, and data processing algorithms, which can directly translate into superior drone performance and capabilities. Conversely, sticking with an older Python version can lead to dependency hell, making it difficult to integrate new libraries, resolve conflicts, and leverage the community’s latest innovations.
Security, Maintainability, and Future-Proofing
Security is paramount in drone operations, especially for applications involving sensitive data or critical infrastructure. New Python versions routinely include security patches and improvements that address vulnerabilities discovered in previous releases. Deploying drone software on an outdated Python version can expose systems to known security risks, potentially compromising data integrity, operational control, or even the drone’s physical safety.
Furthermore, developing with the latest Python version simplifies code maintenance. It ensures access to the latest development tools, debugging features, and community support. Newer versions often introduce syntax improvements and quality-of-life enhancements that lead to cleaner, more readable, and easier-to-maintain codebases. This is crucial for long-term projects and collaborative development environments common in drone innovation. By aligning with the current stable release, developers effectively future-proof their applications, making it easier to upgrade in the future and ensuring their software remains compatible with upcoming technologies and standards.
Navigating Python’s Release Cycle for Drone Development
Understanding Python’s release cycle is essential for strategic planning in drone software development. While the allure of the absolute latest version is strong, a measured approach is often best to ensure stability and compatibility.
Understanding Major and Minor Releases
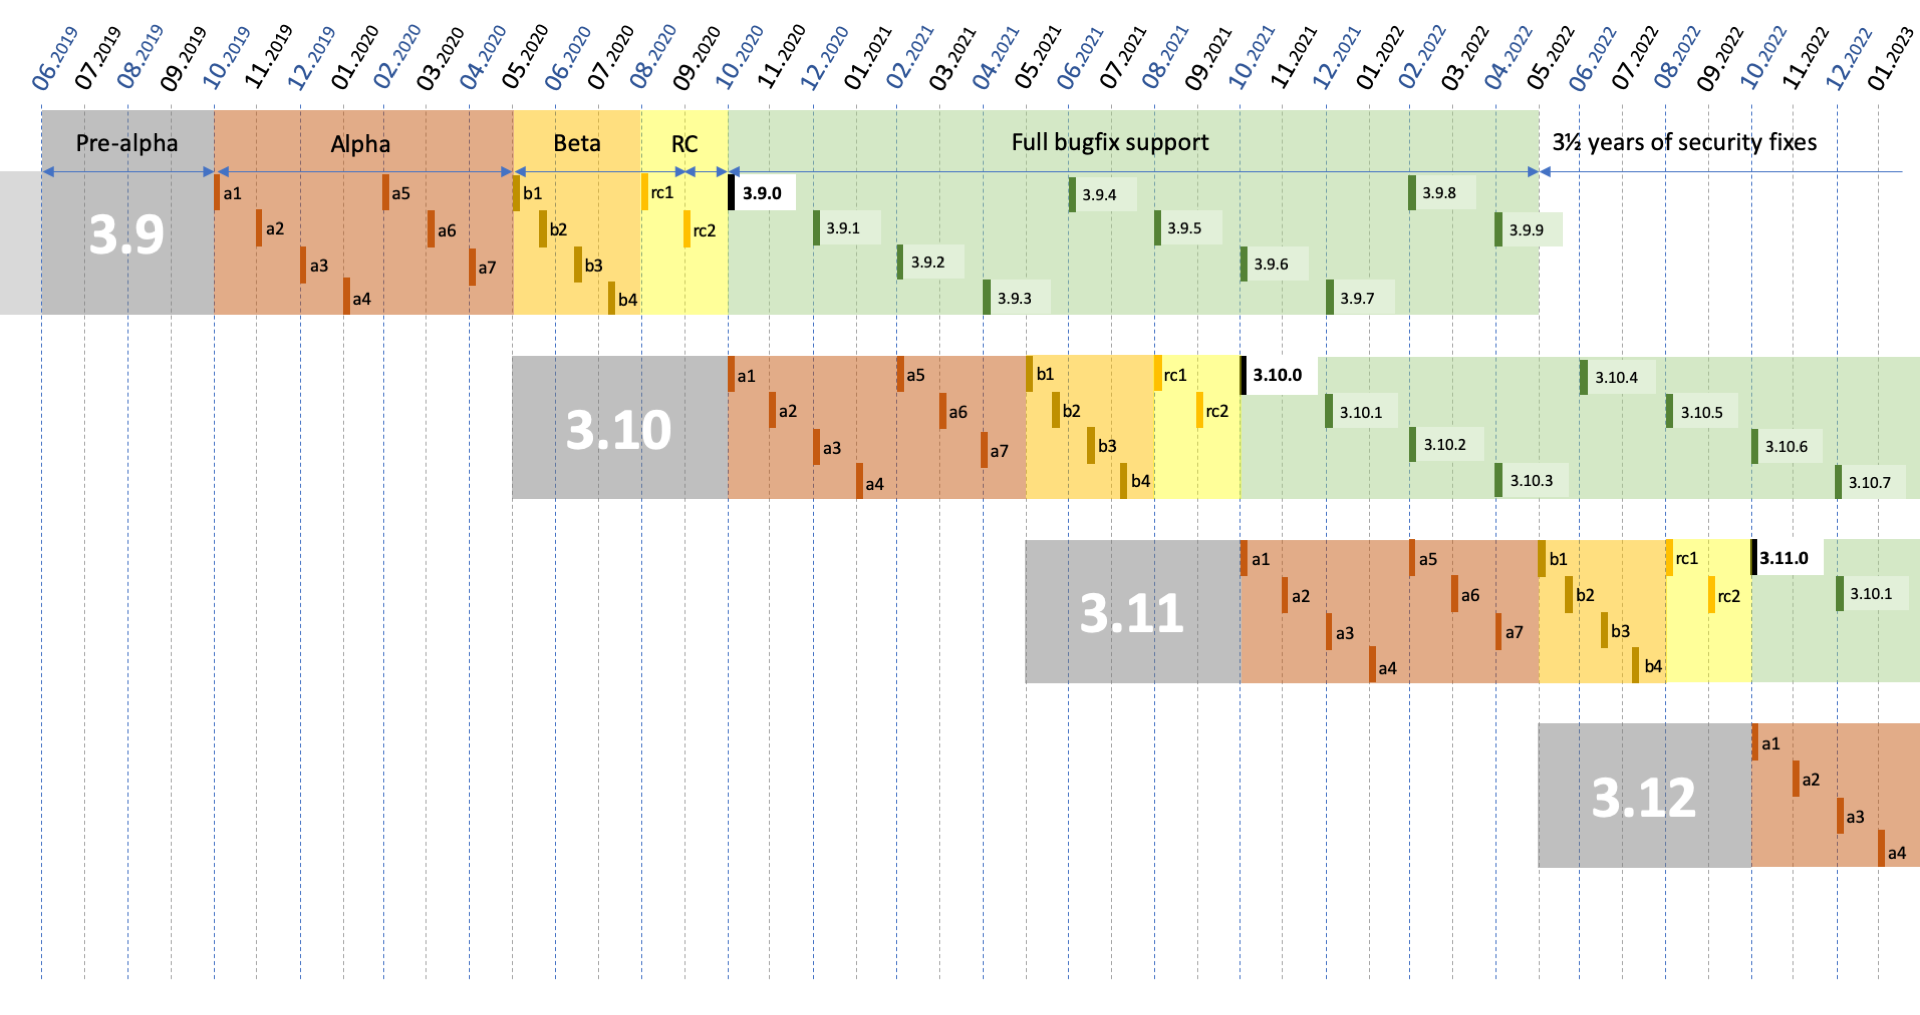
Python follows a predictable release schedule, typically releasing a new major version (e.g., 3.X) annually in October, with subsequent minor bugfix releases (e.g., 3.12.1, 3.12.2, 3.12.3) throughout the year. Each major release brings new features, performance improvements, and sometimes breaking changes. For drone development, particularly for mission-critical systems, it’s generally advisable to adopt the latest stable major release (like 3.12) after it has received a few minor bugfix updates, ensuring a degree of stability and widespread library support. The long-term support (LTS) versions are also critical considerations for projects requiring extended maintenance.
Best Practices for Version Management in Drone Projects
Effective version management is crucial. Developers should leverage tools like pyenv or conda to manage multiple Python versions on their development machines, allowing them to test code against different environments without conflicts. Virtual environments (venv or conda env) are non-negotiable for isolating project dependencies, ensuring that each drone application has its specific set of libraries and Python version, preventing conflicts and ensuring reproducibility. Rigorous testing, especially integration testing, is vital when upgrading Python versions to ensure that existing drone functionalities, particularly those involving hardware interfaces and real-time processing, remain stable and performant. Continuous integration/continuous deployment (CI/CD) pipelines should include checks for Python version compatibility and dependency resolution.
The Future of Python in Drone Innovation
The trajectory of Python in drone technology is one of increasing sophistication and integration. As drones become more autonomous, intelligent, and interconnected, Python’s role will only grow. Future Python versions promise further performance enhancements, better concurrency models, and more robust type-hinting capabilities, all of which will empower drone developers to build even more complex and reliable systems.
The ongoing developments in machine learning, particularly in areas like reinforcement learning for adaptive control and edge AI for on-board processing, will continue to lean heavily on Python. Furthermore, as drone swarms and collaborative autonomous systems become more prevalent, Python’s strengths in rapid prototyping and network communication will be invaluable for orchestrating these complex aerial ballets. By keeping a keen eye on the latest Python versions and actively integrating new features and optimizations, the drone community will continue to unlock unprecedented capabilities, pushing the boundaries of what is possible in aerial robotics and remote sensing.