
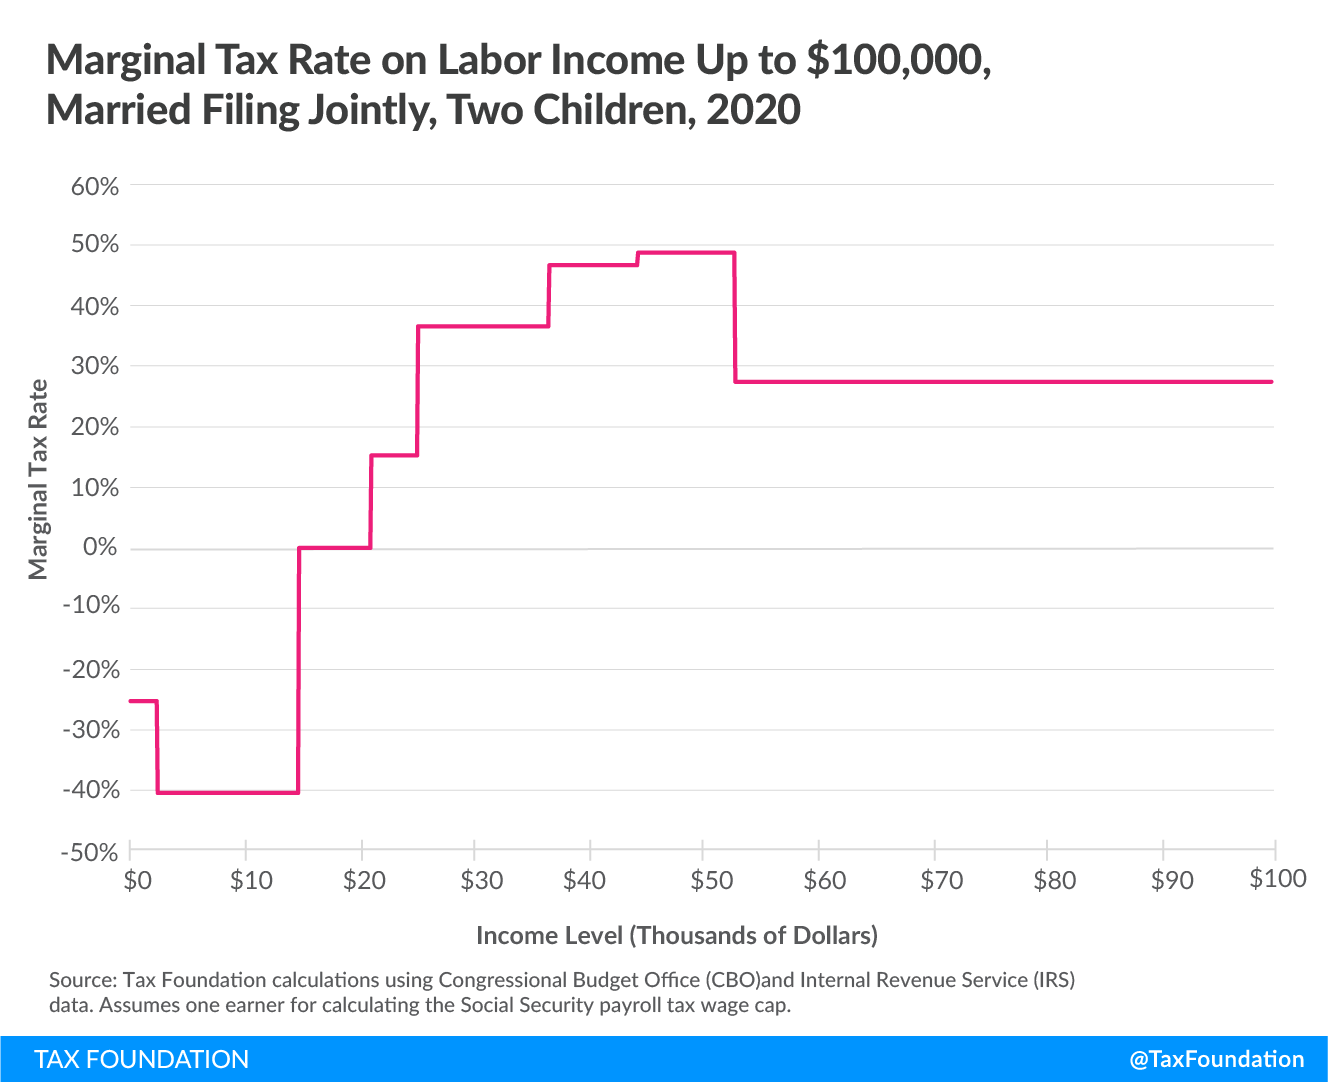
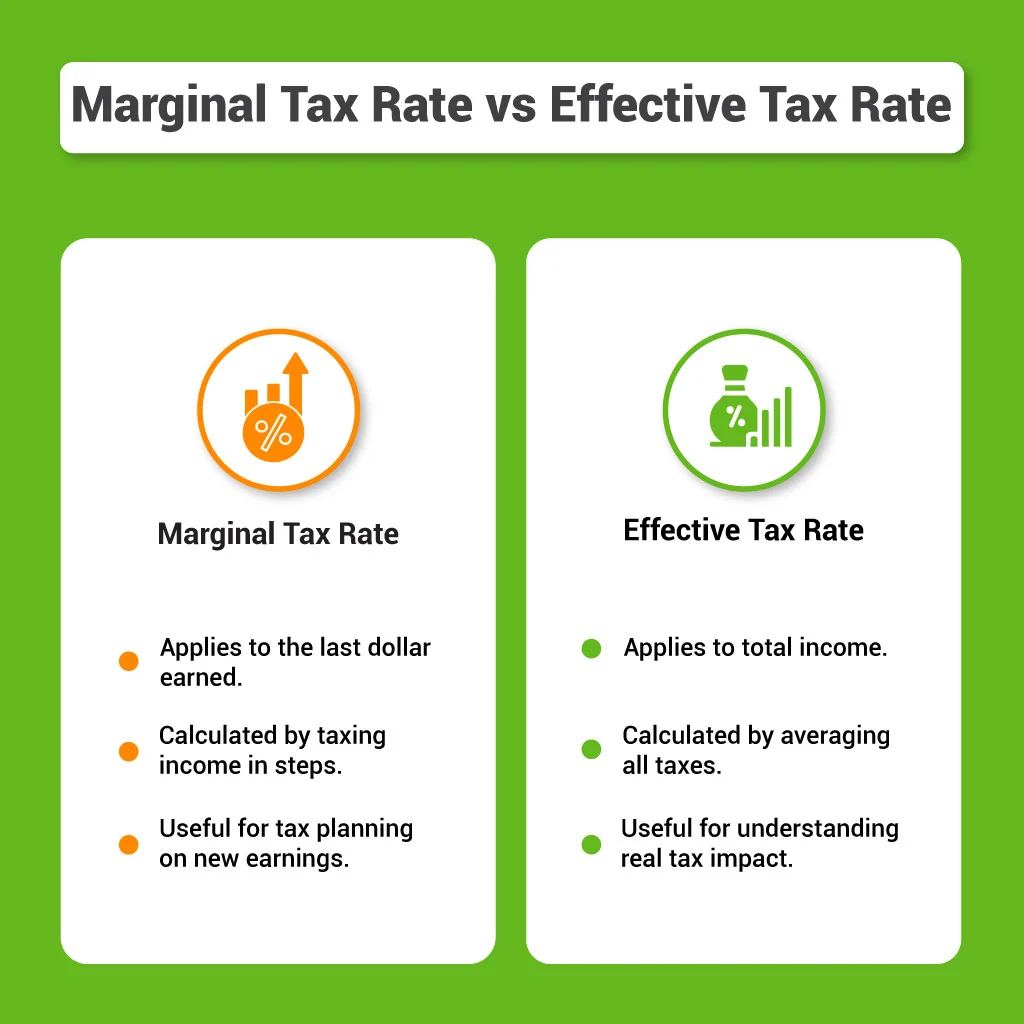
In the dynamic world of drone technology and innovation, understanding your “marginal tax rate” is not about financial levies, but rather a crucial metaphor for evaluating the point at which additional investment in technology, features, or complexity yields diminishing returns. Just as a financial marginal tax rate defines the tax on your next dollar of income, the technological marginal tax rate in drones refers to the additional cost, effort, or resource expenditure required to achieve the next increment of performance, capability, or efficiency. For innovators, developers, and commercial operators, identifying this threshold is paramount to optimizing development, ensuring cost-effectiveness, and preventing over-engineering.
The Economic Metaphor in Drone Tech & Innovation
The concept of a marginal tax rate, typically applied to economics and personal finance, finds a compelling parallel in the relentless pursuit of advancement within drone technology. Here, the “income” can be seen as performance metrics, new features, or operational efficiency. The “tax” represents the increasing difficulty, cost, and complexity of achieving those incremental gains.
Transposing “Marginal Tax” to Technological Investment
Every decision in drone innovation—from refining AI algorithms for autonomous flight to integrating more sophisticated sensors for remote sensing—involves a trade-off. Initially, significant improvements can be made with relatively modest investments. Adding a basic obstacle avoidance system, for instance, provides a substantial leap in safety and capability. However, as systems become more advanced, the effort required to achieve even a tiny improvement can skyrocket. This is the essence of the “marginal tax.” Going from 95% to 98% accuracy in a complex task might demand disproportionately more processing power, specialized sensor fusion, and intricate software development than achieving the initial 50% to 90% leap. Understanding this diminishing return helps guide strategic resource allocation, ensuring that R&D budgets are spent where they deliver the most impactful value.
The Pursuit of Incremental Improvement
Innovation is inherently about pushing boundaries. Yet, unbridled pursuit of perfection without considering the marginal cost can lead to bloated projects, excessive development cycles, and ultimately, products that are either too expensive, too complex, or too late to market. For instance, enhancing the responsiveness of an AI follow mode from sub-second latency to microsecond latency might seem like a noble goal, but if the human eye or the practical application cannot discern the difference, the enormous engineering effort expended represents a high “marginal tax” with little real-world benefit. The question then becomes: where is the sweet spot between cutting-edge and practical utility? Identifying your “marginal tax rate” allows innovators to consciously choose where to draw the line, focusing on impactful improvements rather than chasing every conceivable fractional gain.
Identifying Diminishing Returns in Autonomous Systems
The drone industry, particularly in areas like autonomous flight, mapping, and remote sensing, is ripe with examples where the “marginal tax rate” becomes critical. These systems rely on a confluence of hardware and software, where small tweaks can have cascading effects on performance, cost, and complexity.
AI Follow Mode: Precision vs. Practicality
Consider AI follow mode, a hallmark of intelligent drone operation. Early iterations focused on basic target recognition and tracking. Subsequent developments added predictive algorithms, dynamic obstacle avoidance, and multi-target tracking. Each step improved the user experience and capability. However, there reaches a point where further increases in tracking precision or environmental adaptability, while technically feasible, offer minimal practical advantage. Improving an already robust follow system to perfectly anticipate every subtle, unpredictable human movement might require an exponential increase in processing power and sensor data analysis. For a casual user capturing sports or outdoor activities, the difference between 98% and 99.5% accuracy might be imperceptible, yet the “marginal tax” in terms of development cost, battery drain from increased computation, and sensor weight could be substantial. Developers must ask: does this marginal improvement justify the computational overhead and power consumption, especially for battery-constrained devices?
Mapping and Remote Sensing: Resolution Beyond Utility
In mapping and remote sensing, the drive for higher Ground Sample Distance (GSD) and richer spectral data is constant. A lower GSD (higher resolution) can reveal finer details, while additional spectral bands offer deeper insights into environmental conditions. However, the “marginal tax” here becomes evident quickly. Doubling resolution (halving GSD) doesn’t just double the data; it quadruples it, leading to exponential increases in flight time, data storage requirements, processing power for photogrammetry, and the computational burden for analysis. For many applications, such as agricultural field health assessment or construction progress monitoring, a certain GSD might be perfectly adequate. Pushing for a significantly lower GSD might uncover details that are either irrelevant to the specific analytical task or too time-consuming to process and act upon effectively. The cost of acquiring and processing marginally better data often outweighs the value of the extra information.
Onboard Processing: The Computation-Benefit Curve
The ability of drones to perform complex computations onboard—for real-time decision-making, object recognition, or immediate data analysis—is a frontier of innovation. From edge AI processors to dedicated vision processing units (VPUs), hardware continuously evolves. Yet, integrating more powerful processors inevitably adds weight, consumes more power, and generates more heat, directly impacting flight time and overall system design. The “computation-benefit curve” illustrates this perfectly: initial increases in processing power lead to significant leaps in capability (e.g., real-time 4K video analysis). However, as processing demands escalate for highly complex tasks, the marginal gain in performance might not justify the dramatic increase in power consumption and thermal management challenges. At what point does pushing for more onboard compute become less efficient than offloading tasks to ground stations or cloud processing, even with the latency implications? This is a core “marginal tax” decision point for innovators.
Navigating the Cost-Benefit Threshold
Identifying and strategically navigating the “marginal tax rate” is about striking a balance. It’s about understanding that perfect may be the enemy of good, and that beyond a certain point, more resources do not necessarily translate to proportionally better outcomes for specific applications.
Project-Specific “Brackets”: When More Isn’t Better
Just as income tax brackets vary, the “marginal tax bracket” for drone innovation is highly project-specific. What constitutes diminishing returns for a cinematic drone might be essential for a precision inspection UAV. For a drone designed for search and rescue, absolute reliability and robust autonomy might justify a very high “marginal tax” for every increment of system resilience. Conversely, for a consumer drone focused on ease of use and affordability, excessive features that add complexity or cost without a clear, universally beneficial outcome would be subject to a very high “marginal tax.” Innovators must define their specific application’s critical performance indicators and assess whether each proposed improvement genuinely moves the needle in a meaningful way for their target user or mission. It’s about tailoring the technology to the need, rather than pursuing technology for technology’s sake.
The Hidden Costs: Complexity, Weight, and Power Draw
The “marginal tax” extends beyond monetary cost. Every additional sensor, every more complex algorithm, every extra line of code, carries hidden costs. Increased complexity translates to more points of failure, more rigorous testing requirements, and greater challenges in maintenance and updates. Added weight from components or larger batteries reduces flight time or payload capacity. Higher power draw shortens operational duration and demands more sophisticated power management systems. These factors can quickly erode the perceived benefit of a marginal performance gain. A drone that boasts slightly better object recognition but suffers from significantly reduced flight time or requires constant, complex calibration may actually offer a poorer overall user experience or operational efficiency. The true “marginal tax rate” accounts for this holistic impact on the system.
Strategies for Optimal Innovation
To effectively manage the “marginal tax rate” in drone innovation, a strategic approach focused on efficiency, user value, and adaptability is essential.
Modular Design and Scalability
Adopting a modular design philosophy allows for components and software functionalities to be added or upgraded independently. This approach helps in deferring the “marginal tax” until absolutely necessary. Instead of building an all-encompassing, maximally complex system from the outset, developers can create a robust core and then add specialized modules only when specific applications demand higher levels of performance. This strategy also enables scalability, allowing different configurations of a drone platform to cater to varying “marginal tax brackets” and user needs, from basic to ultra-premium. A user who only needs basic GPS navigation doesn’t pay the “marginal tax” for advanced RTK/PPK systems unless their specific application truly requires it.
User-Centric Development
A deep understanding of the end-user’s actual needs and pain points is perhaps the most potent tool for combating high “marginal tax rates.” By focusing on problem-solving rather than feature accumulation, innovators can prioritize developments that deliver tangible, impactful value. This involves extensive user research, feedback loops, and iterative prototyping. If users consistently highlight a need for longer flight times over marginally better camera stability, then development resources should be directed accordingly. The “marginal tax” for a feature that no one truly needs or appreciates is effectively infinite, as it provides no return on investment.

Leveraging Open-Source and Community Innovations
The vibrant open-source community surrounding drone technology, particularly in areas like flight controllers (e.g., ArduPilot, PX4) and computer vision libraries (e.g., OpenCV), offers a unique way to mitigate the “marginal tax.” By building upon established, well-tested open-source components, innovators can achieve significant capabilities without incurring the full development cost and complexity from scratch. This allows resources to be focused on novel integrations, proprietary algorithms that differentiate a product, or refinements that address specific niche requirements. Collaborating with the community, sharing insights, and contributing back can further reduce the collective “marginal tax” burden for the entire ecosystem, fostering faster, more efficient innovation across the board.
In conclusion, understanding “what is my marginal tax rate” in drone technology is about prudent innovation. It’s about making conscious choices to invest resources where they yield the greatest practical benefit, avoiding the trap of diminishing returns, and building solutions that are both technologically advanced and realistically viable for their intended purpose.